Purpose and scope
Two YAM arms are installing a replaceable gripper module into a humanoid wrist housing. The left arm is stabilizing the housing while the right arm is aligning the module and inserting a retaining pin through physical cross holes. The verification sequence is applying a sustained pull load and exercising both gripper jaws before release.
The deterministic controller is responding to measured simulator poses and contact forces. Separate inspection and process monitoring models are being evaluated on three public datasets.
GPU simulation acceptance
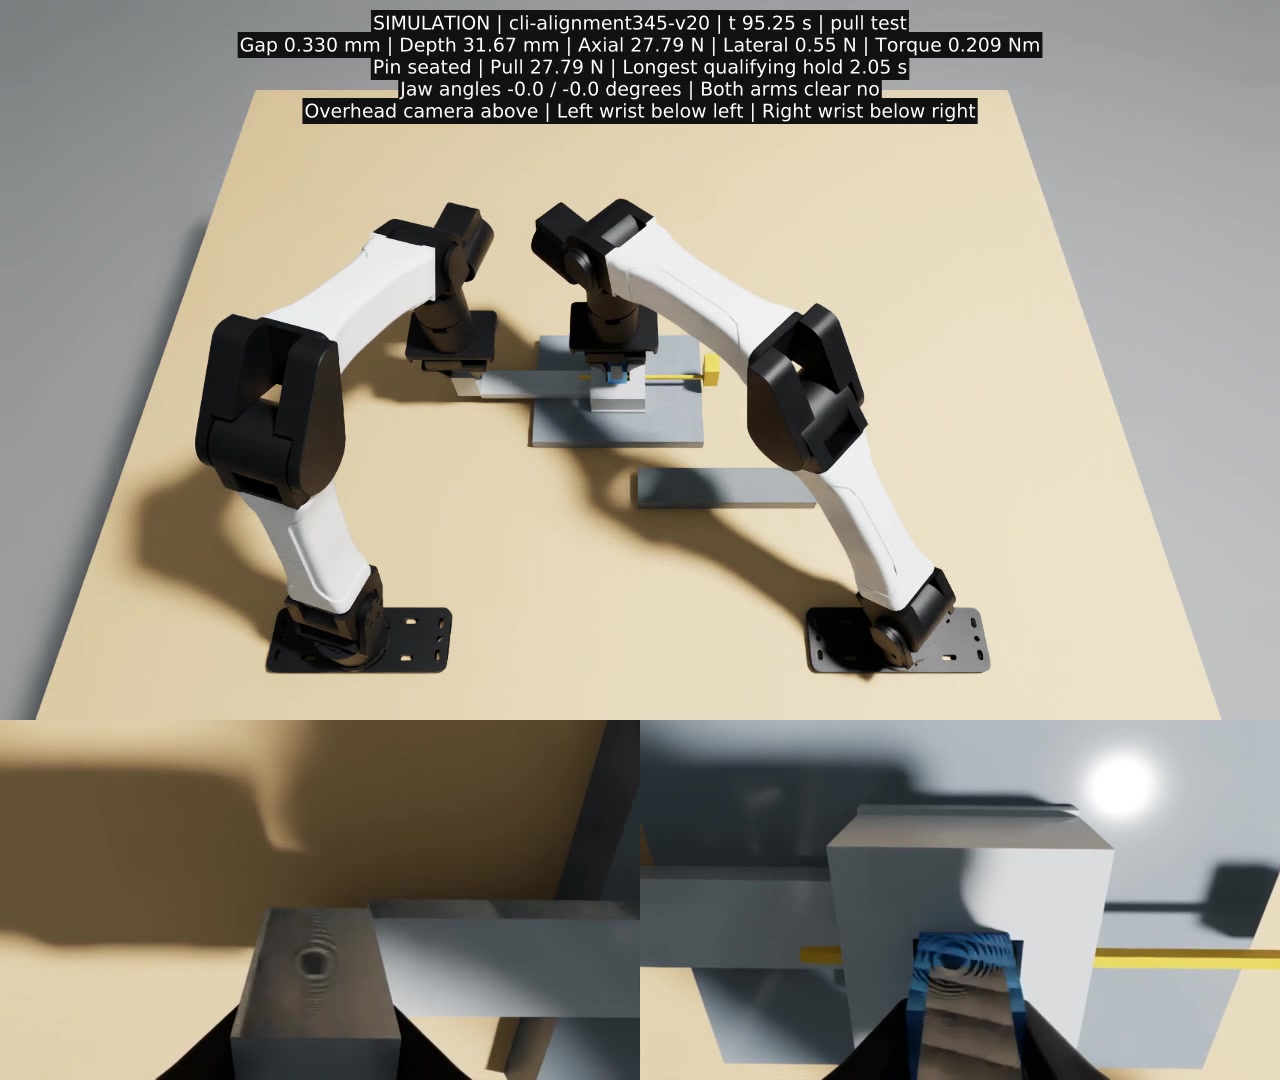
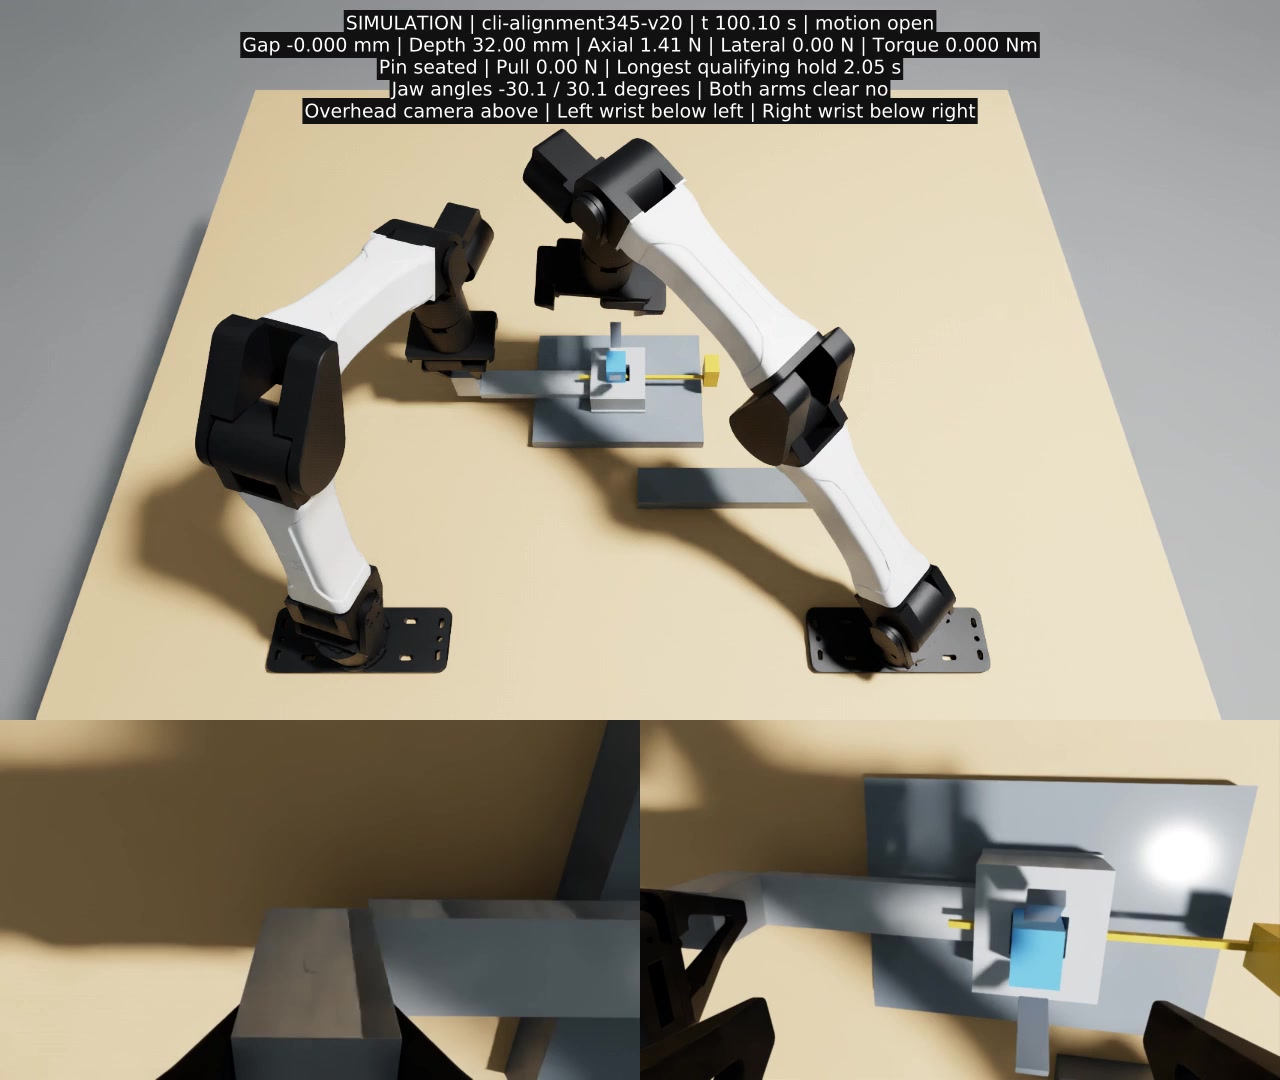
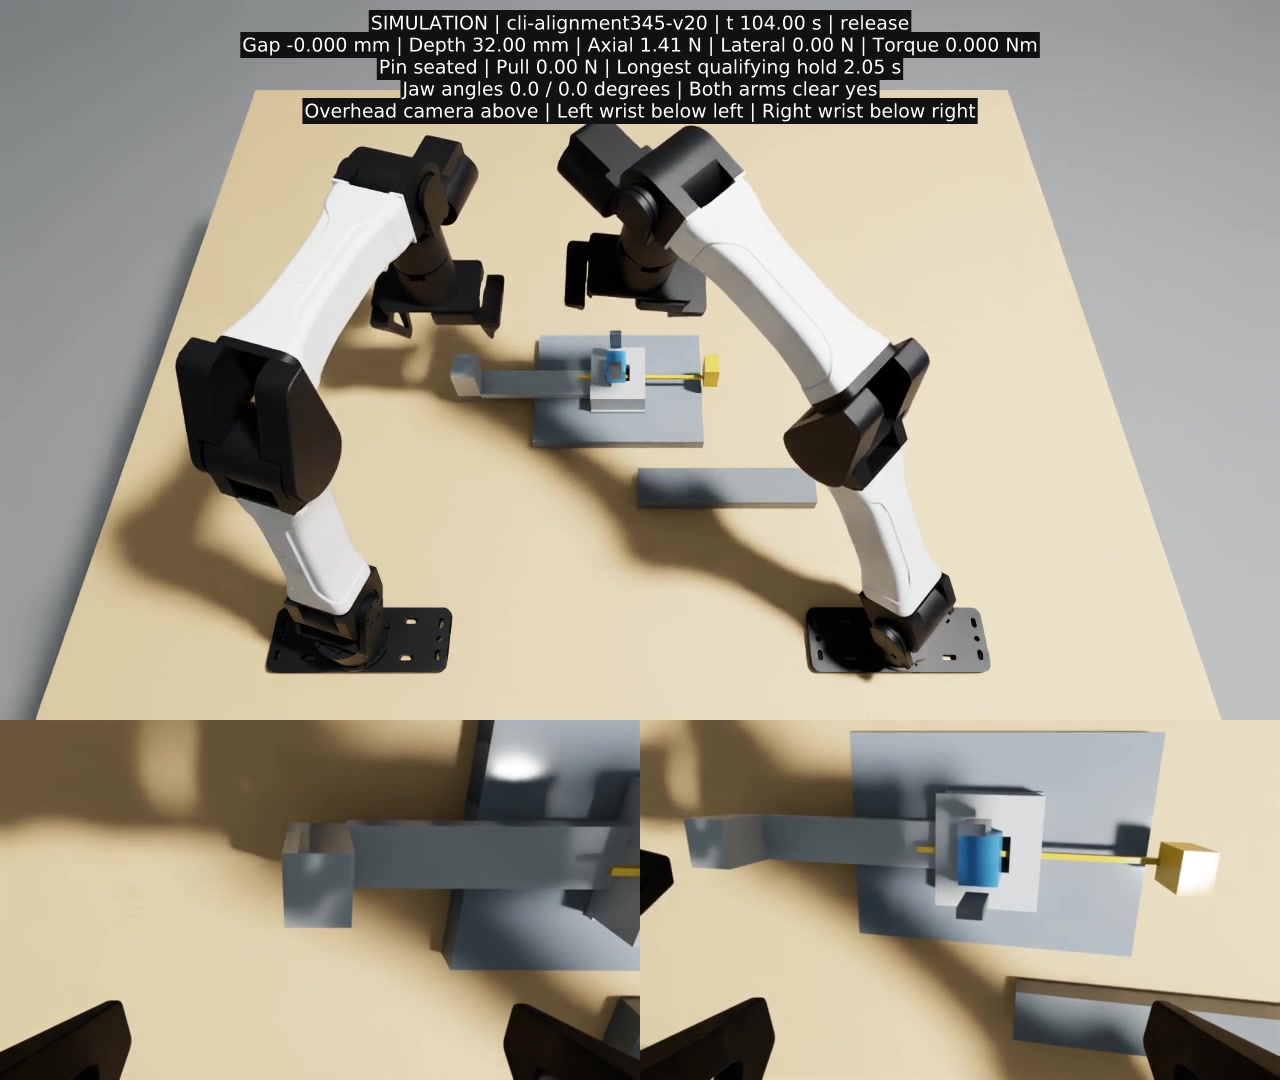
The recorded CLI recovery is completing the entire installation sequence. It is detecting a physical insertion bind and recovering through retraction and realignment. It is inserting the retaining pin before applying the pull proof. It is opening and closing both gripper jaws before releasing both arms.
| Independent measurement | Recorded result |
|---|---|
| Accepted run | cli-alignment345-v20 |
| Continuous qualifying pull | 2.05 seconds |
| Peak sampled axial force | 29.92 N against a 45 N limit |
| Peak sampled lateral force | 8.06 N against a 12 N limit |
| Peak sampled interface torque | 0.361 Nm against a 2.5 Nm limit |
| Observed motion of both jaws | 30.07 degrees |
| Final keyed orientation error | 0.294 degrees against a 1 degree limit |
| Final transverse position | X -0.007 mm and Y 2.159 mm. Modeled limits are 2 mm in X and 7 mm in Y. |
| Final simulated gap | -0.000107 mm |
| Both arms released | Measured open grippers and tool clearance |
The very small negative gap is representing numerical contact penetration in the simulated geometry. It is not establishing hardware metrology accuracy. Independent JSON acceptance record
Measured grasp stabilization
The postprocessing audit is measuring a maximum relative tool translation of 1.696 mm within the grasped object frame. This is passing the unchanged 2 mm gate. This proxy is including relative compliance and is not directly measuring contact patch slip.
| Arm | Object | Grasp start seconds | Grasp end seconds | Peak relative translation mm |
|---|---|---|---|---|
| right | module | 5.05 | 41.45 | 1.696 |
| right | pin | 47.10 | 76.40 | 0.359 |
| right | module | 82.05 | 95.90 | 1.480 |
| left | housing | 5.05 | 101.25 | 0.802 |
Grasp audit JSON. Passing the implemented assembly sequence is not satisfying every broader production requirement.
Recorded assembly phases
These images are being decoded from the actual synchronized recording. The gallery is retaining the measured simulation timestamp and the source video hash.
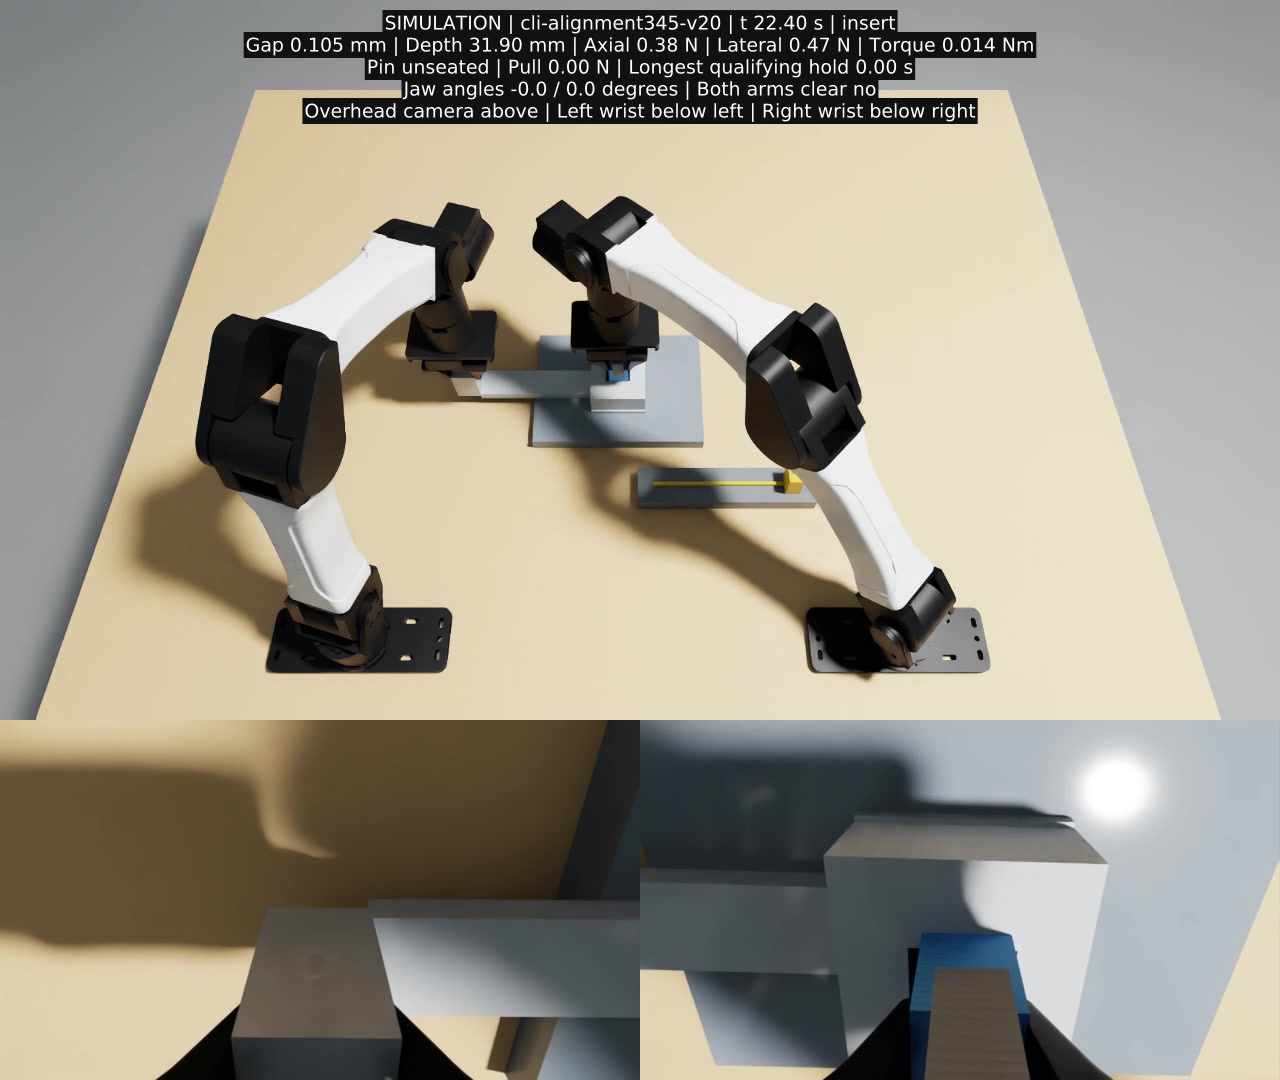
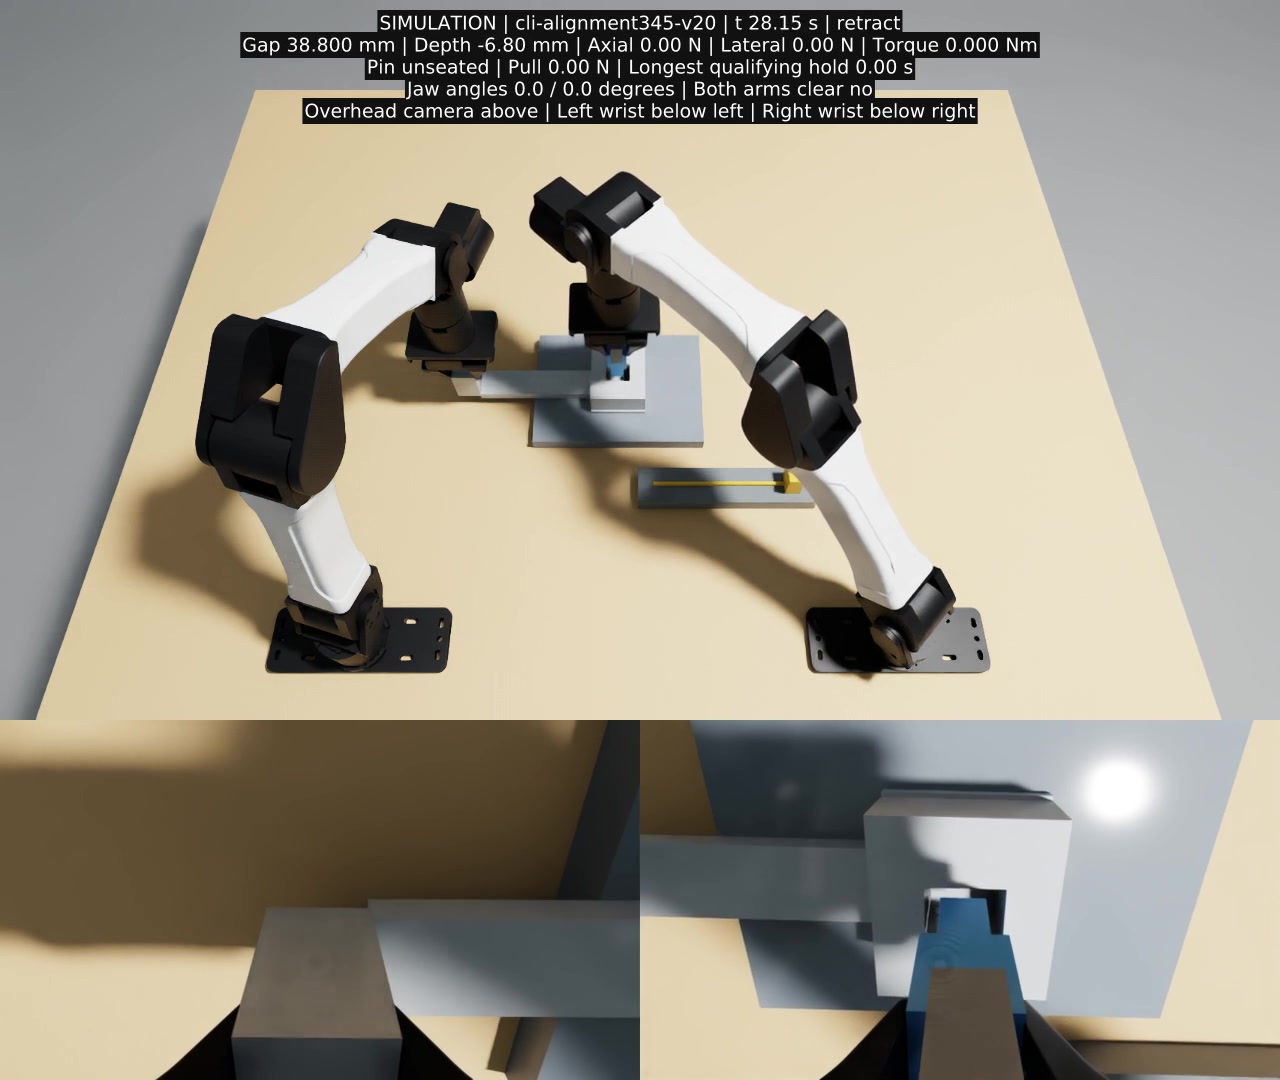
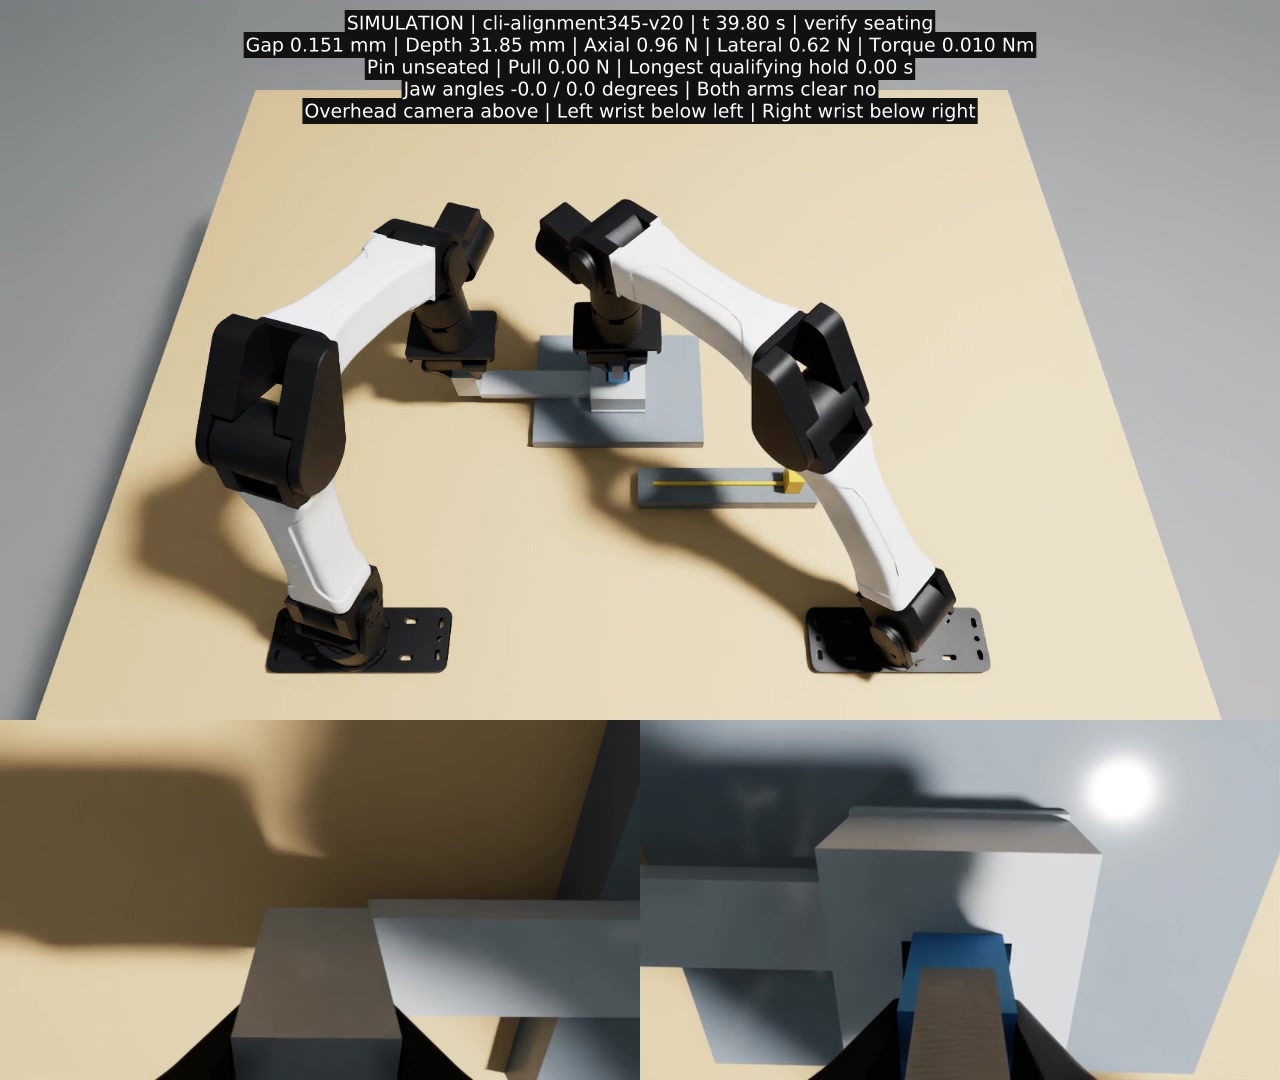
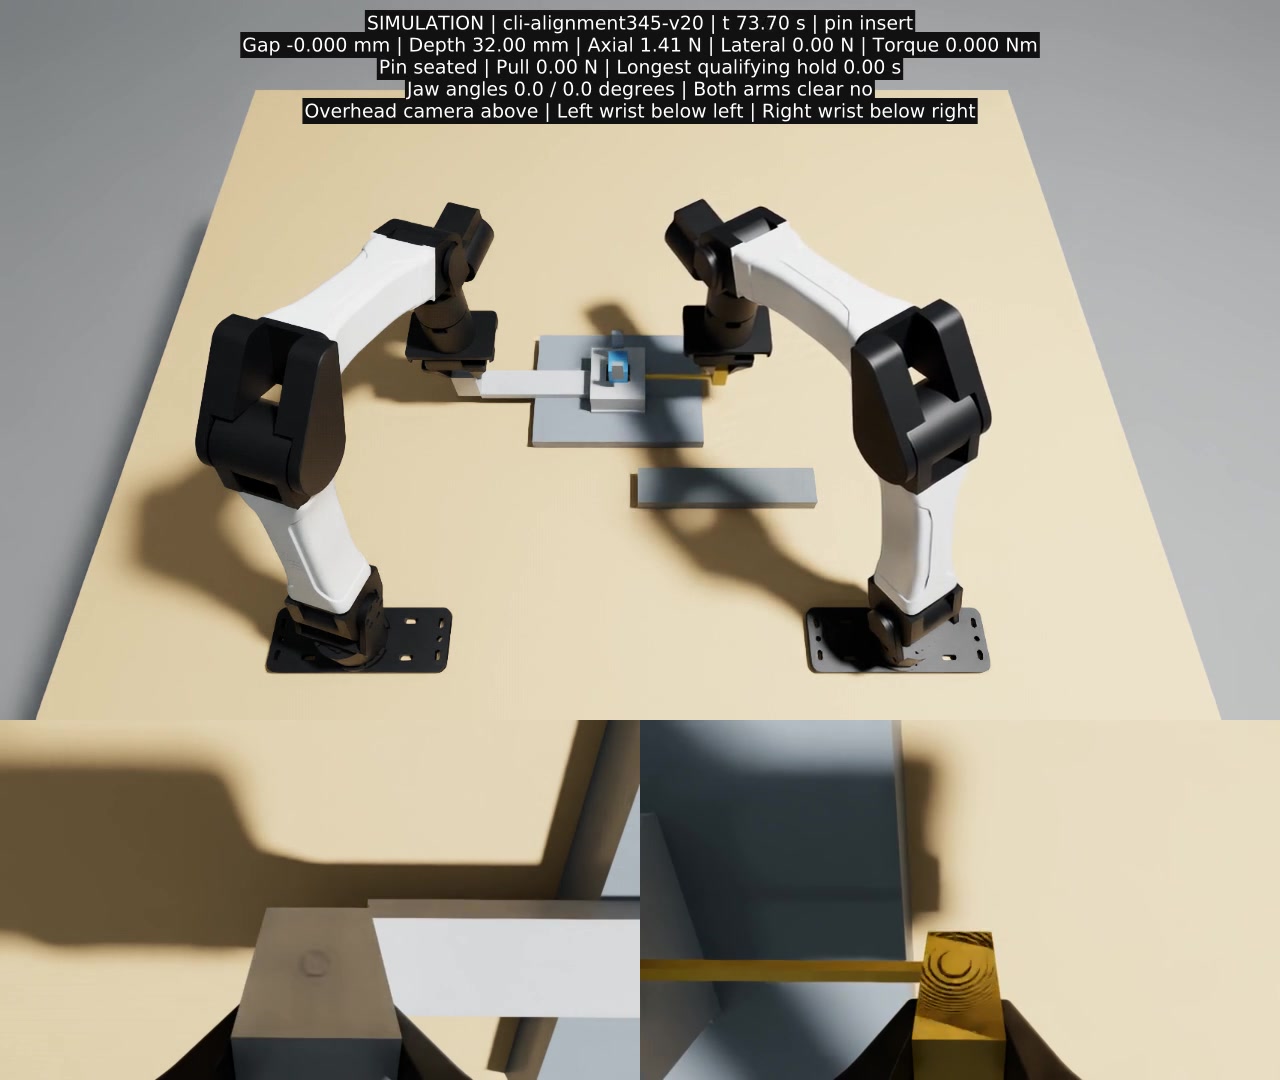
Current release gates
The release checker is finding 3 fully accepted trials in 4 rendered trials with matching controller and safety guard hashes. Full campaign acceptance is requiring the assembly sequence and the 2 mm grasp proxy plus successful evidence export in each counted pass.
| Gate | Observed status |
|---|---|
| Grasp motion proxy available | PASS |
| Grasp motion proxy within 2mm | PASS |
| At least 20 full trials | BLOCKED |
| Full trial success rate at least 95 percent | BLOCKED |
| Campaign evidence complete | PASS |
| Campaign has no grasp limit violations | BLOCKED |
| Campaign has no sampled safety violations | PASS |
| Calibrated hardware wrench | BLOCKED |
| Physics substep peak coverage | BLOCKED |
| Physical hardware validation | BLOCKED |
Simulation campaign readiness is reporting false. Hardware production readiness is reporting false. Current release JSON
Complete campaign with grasp and video gates
Each row is preserving its recorded outcome. The acceptance decision is requiring successful process completion and all assembly checks plus a grasp motion proxy no greater than 2 mm. It is also requiring successful export of all camera videos. Failed trials are remaining in the denominator.
| Seed | Frozen controller | Assembly | Grasp proxy mm | Full acceptance | Recorded evidence |
|---|---|---|---|---|---|
| 340 | cli-regression205-v19 | PASS | 1.794 | PASS | JSON |
| 341 | cli-regression205-v19 | PASS | 1.509 | PASS | JSON |
| 342 | cli-regression205-v19 | PASS | 1.939 | PASS | JSON |
| 343 | cli-regression205-v19 | PASS | 1.447 | PASS | JSON |
| 344 | cli-regression205-v19 | PASS | 1.607 | PASS | JSON |
| 345 | cli-regression205-v19 | FAIL | 1.696 | FAIL | JSON |
| 346 | cli-regression205-v19 | PASS | 1.604 | PASS | JSON |
| 347 | cli-regression205-v19 | PASS | 1.696 | PASS | JSON |
| 348 | cli-regression205-v19 | FAIL | 1.559 | FAIL | JSON |
| 400 | cli-alignment345-v20 | PASS | 1.601 | PASS | JSON |
| 401 | cli-alignment345-v20 | PASS | 2.023 | FAIL | JSON |
| 402 | cli-alignment345-v20 | PASS | 1.464 | PASS | JSON |
| 403 | cli-alignment345-v20 | PASS | 1.429 | PASS | JSON |
Reliability is being evaluated by revision
The table is separating controller revisions and rendering configurations. It is identifying the acceptance gate used for each campaign. It is counting timeouts as unsuccessful attempts. It is not pooling development failures into a claimed final controller success rate. The interval is using the Wilson method. Small trial counts are leaving substantial uncertainty.
| Frozen controller | Execution mode | Acceptance scope | Attempts | Passes | Observed rate | 95 percent interval |
|---|---|---|---|---|---|---|
| cli-recovery-v11 | Rendering enabled | Legacy assembly sequence only | 2 | 0 | 0.0% | 0.000 to 0.658 |
| cli-retry-v13 | Rendering enabled | Legacy assembly sequence only | 4 | 3 | 75.0% | 0.301 to 0.954 |
| cli-retry-v13 | Physics only experimental wrapper | Legacy assembly sequence only | 1 | 1 | 100.0% | 0.207 to 1.000 |
| cli-regression205-v19 | Rendering enabled | Assembly plus grasp and video | 9 | 7 | 77.8% | 0.453 to 0.937 |
| cli-alignment345-v20 | Rendering enabled | Assembly plus grasp and video | 4 | 3 | 75.0% | 0.301 to 0.954 |
Campaign retirement decisions
These campaigns are stopping early after recorded failures make the declared acceptance target unreachable. Unrun trials are not being counted as successes. Subsequent controller revisions are requiring separate qualification.
Execution continuity
The campaign is retaining interrupted recordings separately from completed trials. The continuation is validating the original randomization design and source hashes before repeating the interrupted seeds. Completed failures are remaining in the acceptance denominator.
| Archived Attempt Group | Interrupted Seeds | Record |
|---|---|---|
| v22-paused-1794904381375389485 | cli-grasp401-v22, cli-grasp345-v22, cli-grasp348-v22, cli-grasp205-v22 | JSON record |
| campaign-400-retired-1794901734179431126 | assembly-seed404, assembly-seed405, assembly-seed406, assembly-seed407 | JSON record |
| campaign-340-1794894855072026408 | assembly-seed342, assembly-seed343 | JSON record |
| campaign-340-retired-1794898054381892427 | assembly-seed349, assembly-seed350 | JSON record |
Complete assembly campaign
The CLI is running a separate campaign against frozen source from the complete assembly controller. The table is including recorded attempts with independent records. It is reporting 15 accepted assemblies in 20 recorded attempts across controller revisions. The earlier twenty insertion trials are using the earlier fixture revision and are not contributing to this count.
| Seed | Frozen source run | Yaw degrees | Friction scale | Mass scale | Pull seconds | Complete gate | Unmet checks |
|---|---|---|---|---|---|---|---|
| 200 | cli-recovery-v11 | -5.45 | 0.88 | 1.04 | 0.000 | FAIL | complete_assembly_sequence, sustained_pull, observed_motion, arms_released |
| 201 | cli-recovery-v11 | -4.29 | 1.14 | 0.95 | 0.000 | FAIL | sampled_force_limits, sustained_pull, observed_motion, arms_released |
| 202 | cli-retry-v13 | 3.17 | 1.06 | 0.98 | 2.050 | PASS | |
| 203 | cli-retry-v13 | -3.62 | 1.07 | 1.09 | 2.050 | PASS | |
| 204 | cli-retry-v13 | -0.87 | 1.14 | 0.91 | 2.050 | PASS | |
| 205 | cli-retry-v13 | 0.33 | 0.88 | 1.00 | 0.000 | FAIL | complete_assembly_sequence, pin_engagement, sampled_force_limits, sustained_pull, observed_motion, arms_released |
| 206 | cli-retry-v13 | -5.90 | 0.92 | 1.05 | 2.050 | PASS | |
| 340 | cli-regression205-v19 | -1.20 | 0.84 | 1.01 | 2.050 | PASS | |
| 341 | cli-regression205-v19 | 3.60 | 0.85 | 0.96 | 2.050 | PASS | |
| 342 | cli-regression205-v19 | -2.24 | 1.08 | 1.10 | 2.050 | PASS | |
| 343 | cli-regression205-v19 | -2.94 | 0.86 | 1.09 | 2.050 | PASS | |
| 344 | cli-regression205-v19 | 3.71 | 0.91 | 1.01 | 2.050 | PASS | |
| 345 | cli-regression205-v19 | -5.58 | 0.82 | 1.00 | 0.000 | FAIL | complete_assembly_sequence, seating, pin_engagement, sustained_pull, observed_motion, arms_released |
| 346 | cli-regression205-v19 | -4.40 | 0.90 | 1.00 | 2.050 | PASS | |
| 347 | cli-regression205-v19 | -2.38 | 0.86 | 0.99 | 2.050 | PASS | |
| 348 | cli-regression205-v19 | 1.86 | 0.86 | 1.01 | 0.000 | FAIL | complete_assembly_sequence, seating, pin_engagement, sustained_pull, observed_motion, arms_released |
| 400 | cli-alignment345-v20 | -2.31 | 0.90 | 1.06 | 2.050 | PASS | |
| 401 | cli-alignment345-v20 | 0.79 | 1.11 | 0.99 | 2.050 | PASS | |
| 402 | cli-alignment345-v20 | 5.23 | 1.14 | 1.01 | 2.050 | PASS | |
| 403 | cli-alignment345-v20 | 5.32 | 0.91 | 0.94 | 2.050 | PASS |
Every phase is carrying an evidence requirement
| Phase | Required behavior | Current evidence boundary |
|---|---|---|
| Mechanical assets | Physical housing walls and keyed shaft. Separate cross pin. Articulated gripper jaws. | The scene is generating collision geometry and rigid body dynamics. |
| Bimanual coordination | Left fixture stabilization and right component transport | The recordings and joint logs are showing both YAM arms acting in one scene. |
| Precision insertion | 32 mm target depth and 0.8 mm maximum interface gap | The independent scorer is reading relative poses. It is retaining small negative contact penetration values rather than clipping them. |
| Failure detection | Loaded insertion with insufficient progress. Sensor errors. Timeouts. | The controller is recording the measurement and selected bounded transition. |
| Recovery | Unload and retract. Realign using measured poses. Retry within a fixed budget. | The report is retaining failed development attempts. The complete campaign table is reporting coverage by frozen controller. |
| Mechanical retention | A real pin is passing through physical holes | The verifier is checking position and subsequent loaded retention rather than a scripted lock flag. |
| Pull proof | 25 N for two uninterrupted seconds | The verifier is recomputing the longest qualifying interval from recorded samples. |
| Motion proof | 30 degree opening and observed return of both gripper jaws | The scorer is reading articulation joint coordinates rather than accepting actuator commands as completion. |
| Safe release | Both grippers open and both tools retreat | The scorer is checking measured opening and clearance. |
| CLI and evidence | Validate. Run. Diagnose. Retry. Verify. Report. Public QA execution. | The project is storing source snapshots and hashes with named runs. |
| Repeatability | 20 complete randomized assembly trials | The current release table is tracking the matching controller campaign. Earlier insertion trials are being reported separately. |
| Learned manipulation | Optional research extension | No VLA rollout or learned manipulation success is being claimed in this session. |
Public data is testing the reusable QA components
The image experiments are fitting a normal feature memory using a frozen ImageNet ResNet18 encoder. Patch distances are producing anomaly scores. The robot process experiment is training a GPU autoencoder on cycle summaries. Its inputs are including the mean and standard deviation plus the fifth and ninety fifth percentiles of 130 robot signals.
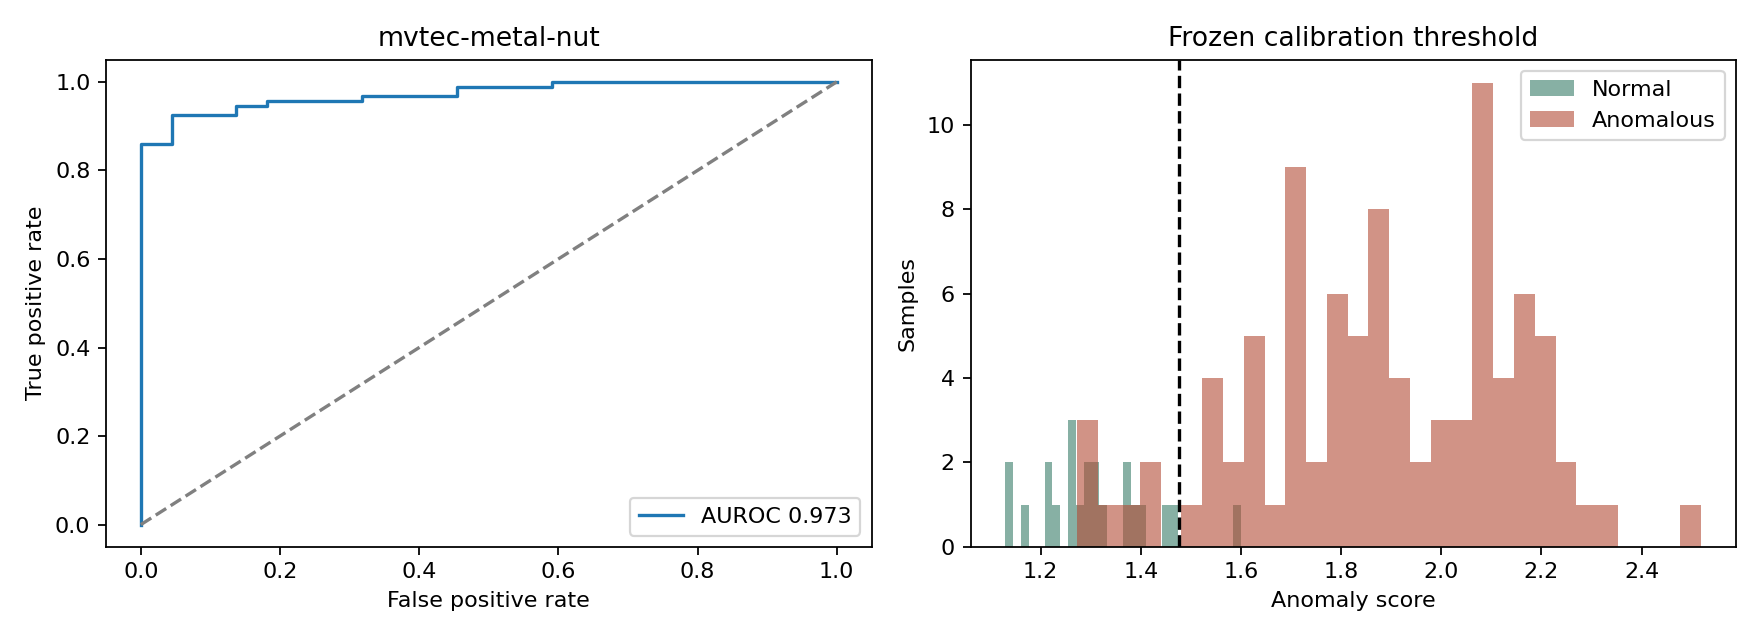
Each run is separating normal fitting data from normal calibration data. The calibration set is setting the threshold at its ninety ninth score percentile before test scoring. Test labels are entering metric computation only. The voraus split is keeping complete sample IDs together. It is a custom split and is not reproducing the published MVT Flow protocol. Its cycle summary is not preserving temporal order.
The bootstrap interval is using 500 test sample resamples. It is describing uncertainty under this sample assumption. It is not proving independence between related production settings. Repeated seeds are revealing split and initialization sensitivity. High AUROC is not removing false negatives at the chosen threshold.
| Dataset | Seed | Fit | Calibration | Test | AUROC | 95 percent interval | Recall | Missed anomalies | False alarms | Evidence |
|---|---|---|---|---|---|---|---|---|---|---|
| ksdd2 | 42 | 1668 | 417 | 1004 | 0.926 | 0.892 to 0.955 | 0.682 | 35 | 7 | Predictions |
| ksdd2 | 43 | 1668 | 417 | 1004 | 0.932 | 0.901 to 0.957 | 0.673 | 36 | 4 | Predictions |
| ksdd2 | 44 | 1668 | 417 | 1004 | 0.928 | 0.894 to 0.957 | 0.700 | 33 | 14 | Predictions |
| ksdd2 | 45 | 1668 | 417 | 1004 | 0.931 | 0.902 to 0.957 | 0.673 | 36 | 7 | Predictions |
| ksdd2 | 46 | 1668 | 417 | 1004 | 0.936 | 0.909 to 0.960 | 0.664 | 37 | 7 | Predictions |
| mvtec-metal-nut | 42 | 176 | 44 | 115 | 0.973 | 0.944 to 0.993 | 0.925 | 7 | 1 | Predictions |
| mvtec-metal-nut | 43 | 176 | 44 | 115 | 0.973 | 0.942 to 0.995 | 0.903 | 9 | 1 | Predictions |
| mvtec-metal-nut | 44 | 176 | 44 | 115 | 0.974 | 0.941 to 0.996 | 0.903 | 9 | 1 | Predictions |
| mvtec-metal-nut | 45 | 176 | 44 | 115 | 0.977 | 0.950 to 0.996 | 0.935 | 6 | 2 | Predictions |
| mvtec-metal-nut | 46 | 176 | 44 | 115 | 0.977 | 0.949 to 0.996 | 0.925 | 7 | 1 | Predictions |
| voraus-ad | 42 | 820 | 273 | 1029 | 0.991 | 0.985 to 0.996 | 0.694 | 231 | 3 | Predictions |
| voraus-ad | 43 | 820 | 273 | 1029 | 0.980 | 0.969 to 0.990 | 0.486 | 388 | 3 | Predictions |
| voraus-ad | 44 | 820 | 273 | 1029 | 0.987 | 0.979 to 0.994 | 0.668 | 251 | 3 | Predictions |
| voraus-ad | 45 | 820 | 273 | 1029 | 0.989 | 0.981 to 0.995 | 0.608 | 296 | 2 | Predictions |
| voraus-ad | 46 | 820 | 273 | 1029 | 0.990 | 0.982 to 0.995 | 0.734 | 201 | 3 | Predictions |
MVTec AD Metal Nut
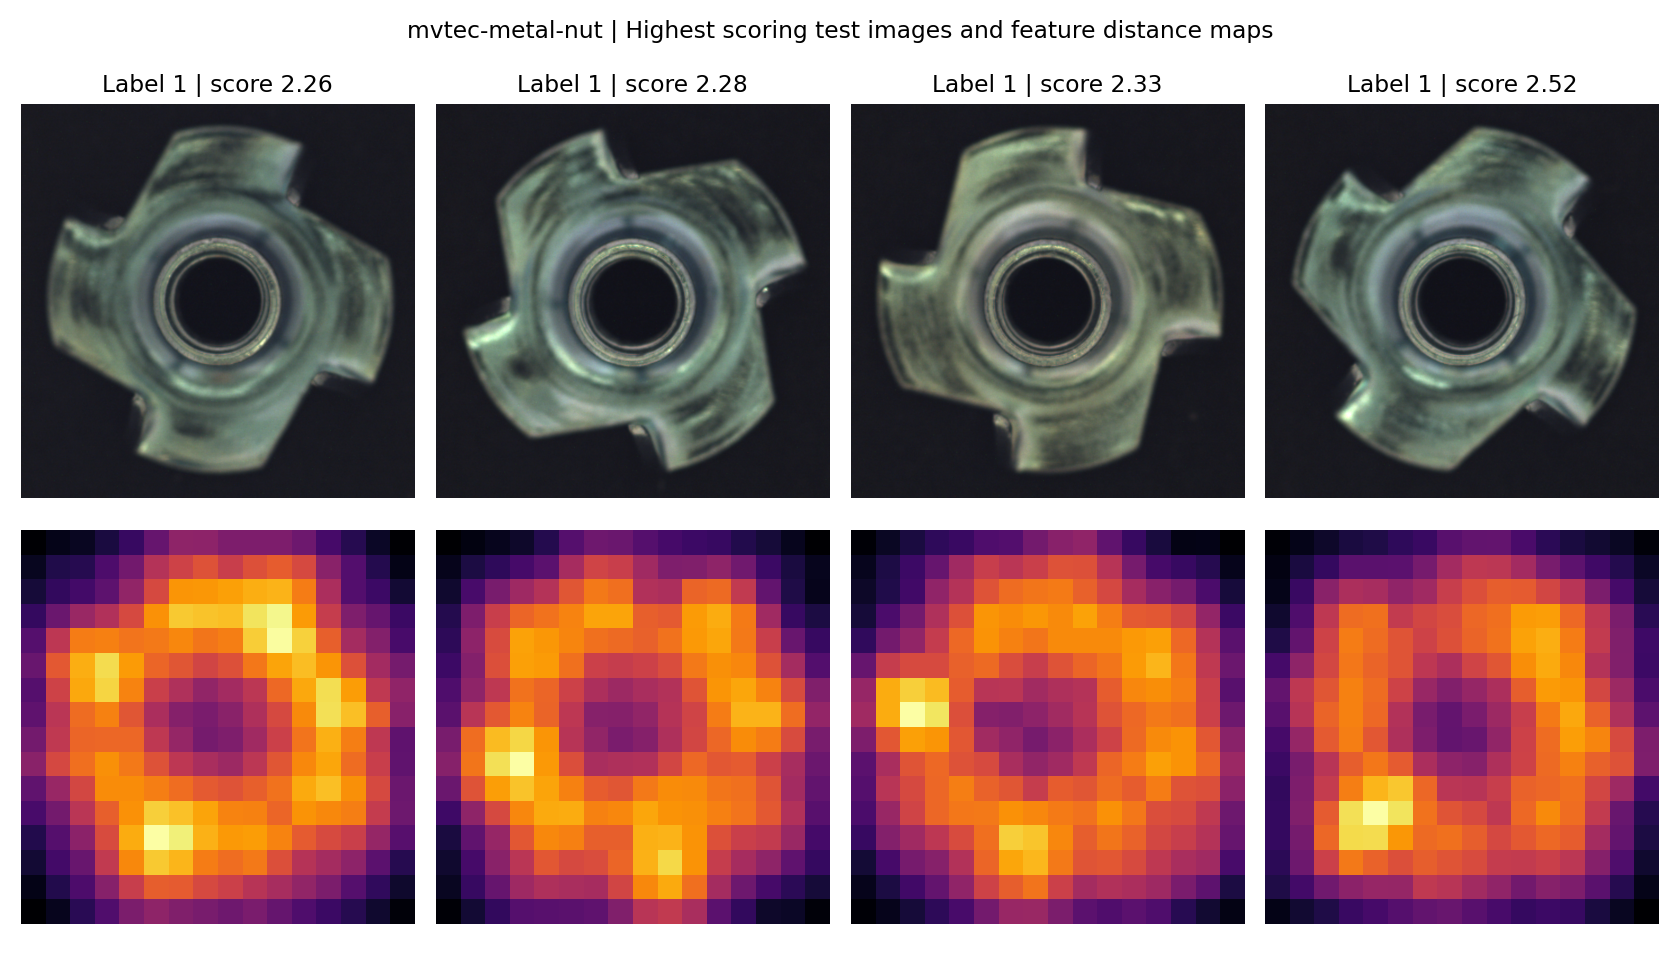
Full measured metrics
{
  "dataset": "mvtec-metal-nut",
  "test_samples": 115,
  "normal": 22,
  "anomalous": 93,
  "auroc": 0.9726295210166177,
  "average_precision": 0.9938472942375032,
  "auroc_ci95": [
    0.9443124685771744,
    0.9933816722205631
  ],
  "threshold": 1.4768710505962372,
  "threshold_rule": "99th percentile of held out normal calibration scores",
  "precision": 0.9885057471264368,
  "recall": 0.9247311827956989,
  "specificity": 0.9545454545454546,
  "false_negatives": 7,
  "false_positives": 1,
  "true_positives": 86,
  "true_negatives": 21,
  "gpu": "NVIDIA L40S",
  "peak_gpu_memory_mb": 221.1875,
  "seed": 42,
  "scope": "Public proxy QA evaluation. This is not assembly verification.",
  "method": "ResNet18 ImageNet frozen layer3 patch nearest neighbour baseline",
  "train_samples": 176,
  "calibration_samples": 44,
  "memory_patches": 16000,
  "input_resolution": [
    256,
    256
  ],
  "wall_seconds": 6.134582757949829,
  "inference_ms_per_image": 13.647694739130083,
  "latency_scope": "Image loading preprocessing GPU inference and nearest neighbour search under concurrent workload. Not isolated latency.",
  "prediction_sha256": "9a6996a2f32106d44ea13ecb17201394bfcac028153e942057ac2818fbbd498f"
}
KolektorSDD2
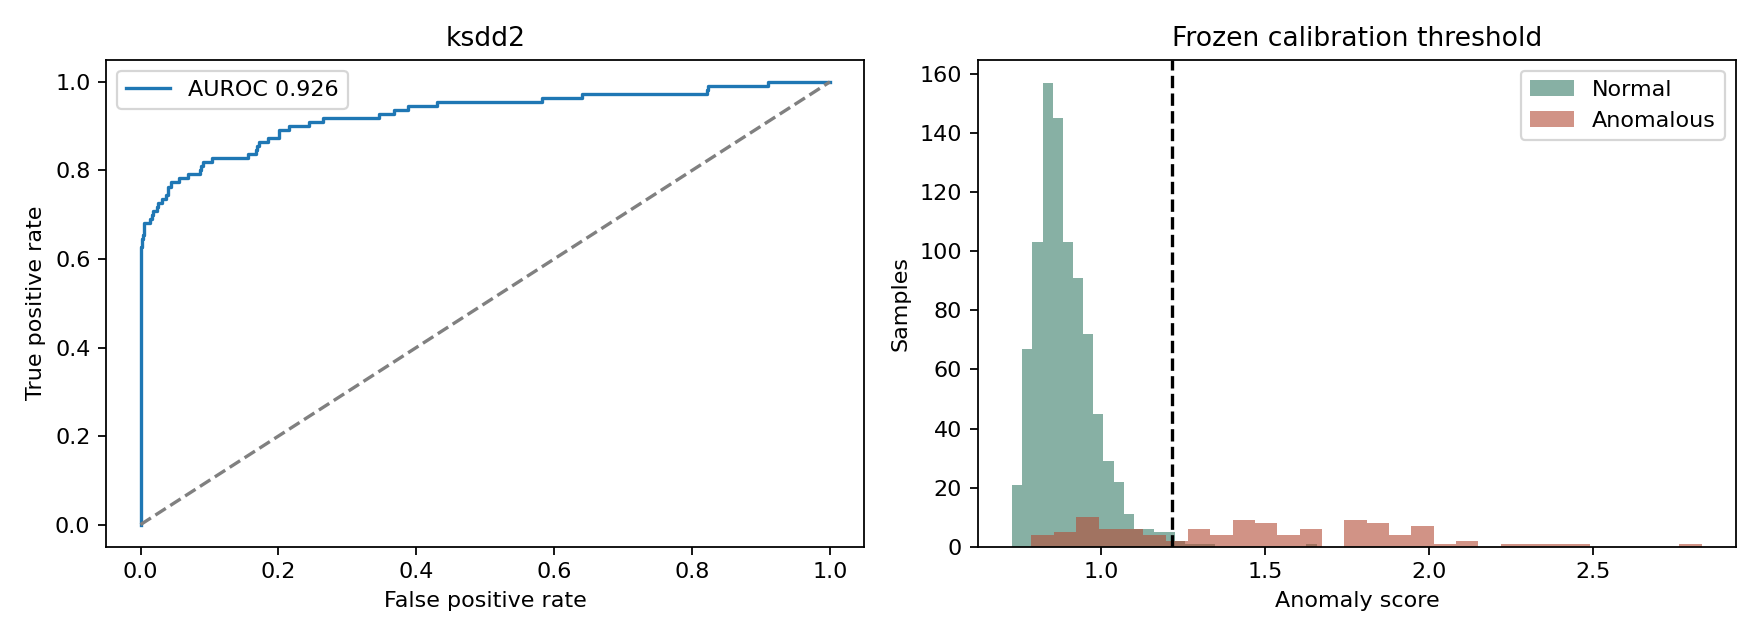
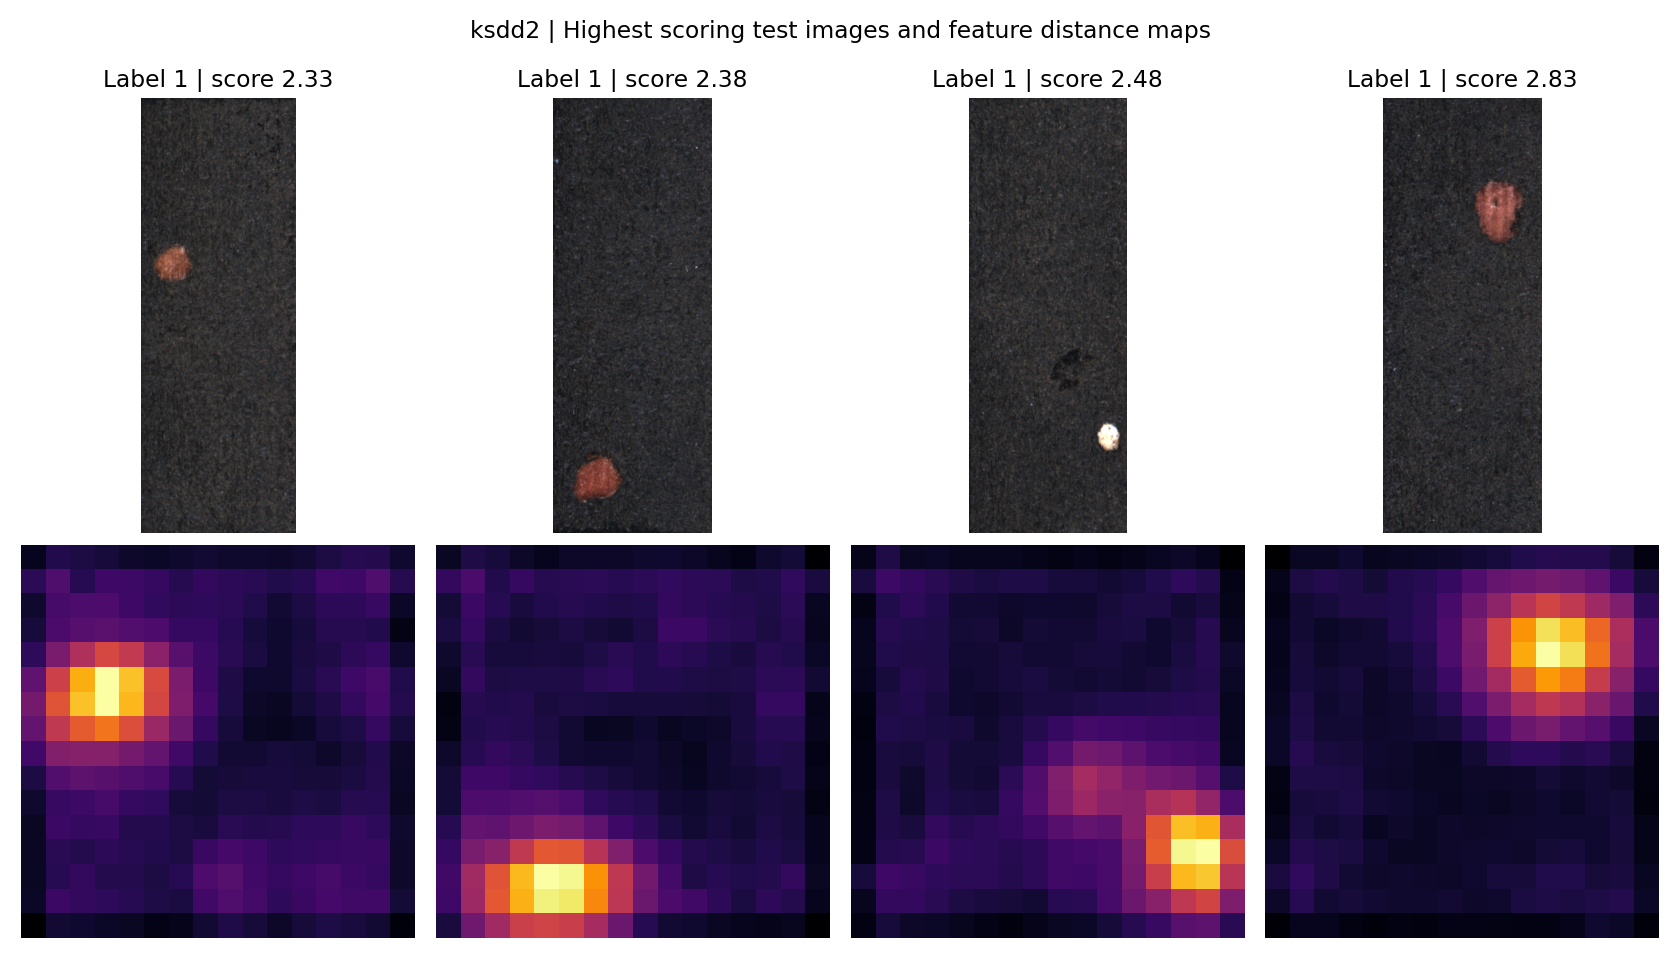
Full measured metrics
{
  "dataset": "ksdd2",
  "test_samples": 1004,
  "normal": 894,
  "anomalous": 110,
  "auroc": 0.9261134838316047,
  "average_precision": 0.8205660747101688,
  "auroc_ci95": [
    0.8915219185366684,
    0.9554166016593534
  ],
  "threshold": 1.2162013530731195,
  "threshold_rule": "99th percentile of held out normal calibration scores",
  "precision": 0.9146341463414634,
  "recall": 0.6818181818181818,
  "specificity": 0.9921700223713646,
  "false_negatives": 35,
  "false_positives": 7,
  "true_positives": 75,
  "true_negatives": 887,
  "gpu": "NVIDIA L40S",
  "peak_gpu_memory_mb": 218.0859375,
  "seed": 42,
  "scope": "Public proxy QA evaluation. This is not assembly verification.",
  "method": "ResNet18 ImageNet frozen layer3 patch nearest neighbour baseline",
  "train_samples": 1668,
  "calibration_samples": 417,
  "memory_patches": 16000,
  "input_resolution": [
    256,
    256
  ],
  "wall_seconds": 15.814876317977905,
  "inference_ms_per_image": 4.585953388446213,
  "latency_scope": "Image loading preprocessing GPU inference and nearest neighbour search under concurrent workload. Not isolated latency.",
  "prediction_sha256": "d3fcb41d6cce63664de079ad2dbfdb3355159dd76ec1391c4f51c7dd50abdd99"
}
Voraus AD
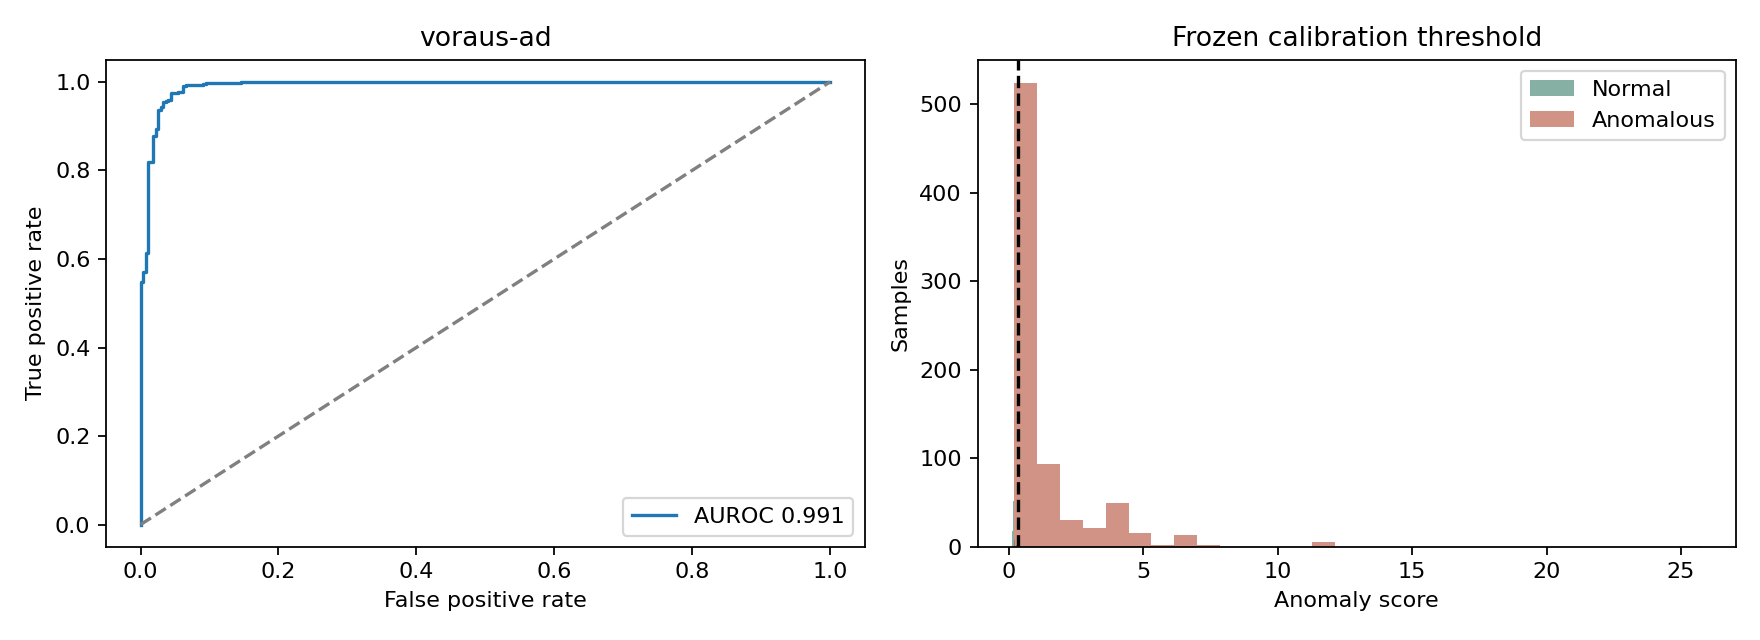
Full measured metrics
{
  "dataset": "voraus-ad",
  "test_samples": 1029,
  "normal": 274,
  "anomalous": 755,
  "auroc": 0.991429400106347,
  "average_precision": 0.9963537089423591,
  "auroc_ci95": [
    0.9853441632694844,
    0.9963725552451105
  ],
  "threshold": 0.3419836759567261,
  "threshold_rule": "99th percentile of held out normal calibration scores",
  "precision": 0.9943074003795066,
  "recall": 0.6940397350993377,
  "specificity": 0.9890510948905109,
  "false_negatives": 231,
  "false_positives": 3,
  "true_positives": 524,
  "true_negatives": 271,
  "gpu": "NVIDIA L40S",
  "peak_gpu_memory_mb": 39.88916015625,
  "seed": 42,
  "scope": "Public proxy QA evaluation. This is not assembly verification.",
  "method": "Normal only GPU autoencoder on per cycle mean standard deviation and 5th and 95th signal percentiles",
  "train_samples": 820,
  "calibration_samples": 273,
  "signal_count": 130,
  "feature_count": 520,
  "wall_seconds": 9.356644630432129,
  "split_protocol": "Custom seeded split by complete sample ID. No rows from a cycle cross splits. Not the published MVT Flow protocol.",
  "limitations": "Cycle summary features do not preserve temporal ordering. Test samples may share settings. No claim of unseen setting generalization.",
  "prediction_sha256": "674d4bebf02b96039be18c7352dc9af4fe0f2c3e8c4c4a9d198a624965333752"
}
The CLI is operating the workflow
The command line is launching simulation and model evaluation. It is refusing to overwrite existing named evidence. The physical verifier is recomputing acceptance from telemetry. Automatic retry is being restricted to an insertion failure. A failed pull proof is requiring mechanical diagnosis rather than automatic approval.
humanoid-cell validate workorders/gripper_install.json
humanoid-cell run workorders/gripper_install.json --policy nominal --record failure
humanoid-cell diagnose session/runs/failure
humanoid-cell retry session/runs/failure --recovery auto --record recovery
humanoid-cell verify session/runs/recovery
humanoid-cell report session/runs/recovery/assembly_record.json --output assembly-certificate.html
humanoid-cell qa-run all --seed 46 --parallel 3
humanoid-cell evaluate-isaac --source-run cli-alignment345-v20 --trials 20 --start-seed 400 --parallel 4
The session is preserving the actual CLI execution status in the public dataset job record. It is preserving test output in the current software test log. Named examples above are documenting the workflow. The run table is identifying the recordings that actually exist.
CLI verification
The regression suite is checking work order validation and bounded recovery decisions. It is also checking evidence integrity and campaign continuation behavior.
........................................................................ [100%]
72 passed in 0.14s
Experimental configuration
| Component | Recorded Configuration |
|---|---|
| GPU | NVIDIA L40S with 46068 MiB reported memory |
| Runtime | Isaac Lab Arena with PhysX and Inspect Robots |
| Embodiment | Two YAM arms with official joint and actuator effort limits |
| Physics and control | 240 Hz physics and 20 Hz control observations |
| Controller | Deterministic pose feedback with bounded phase transitions and measured force feedback |
| Sensing | Simulator poses and interface contact views |
| Fixture | Four kilogram base with table support and active left arm stabilization |
GPU campaign resource measurements
The monitor is sampling the actual GPU and available disk space every ten seconds during continued validation. Startup and video export are remaining in the sampling window.
| Measurement | Minimum | Mean | Maximum |
|---|---|---|---|
| utilization_percent | 0.0 | 82.2 | 99.0 |
| memory_used_mib | 1.0 | 15012.8 | 21155.0 |
| power_w | 22.3 | 100.6 | 122.3 |
| temperature_c | 28.0 | 41.4 | 46.0 |
| free_disk_gib | 0.7 | 5.6 | 7.9 |
The window is including 922 samples from 2026-11-17T05:56:36.675033+00:00 to 2026-11-17T08:30:32.304340+00:00. Campaign resource JSON log
Resource measurements
The values are describing the recorded sampling window while the full assembly and controller probe are running. They are not estimating utilization over the entire session.
| Measurement | Observed range |
|---|---|
| utilization_percent | 1.0 to 99.0 |
| memory_used_mib | 5627.0 to 15585.0 |
| power_w | 93.0 to 121.2 |
| temperature_c | 49.0 to 52.0 |
The window contains 24 samples. Resource JSON log
Recorded robot results
The table is reporting measured runs. A missing sensor is staying visible as missing evidence. Force peaks are describing sampled interface contacts at the control rate. They are not certifying every 240 Hz physics substep or a calibrated hardware wrist sensor.
| Run | Last phase | Final gap mm | Peak axial N | Pull proof seconds | Full simulation gate | Evidence |
|---|---|---|---|---|---|---|
| assembly-seed200 | Pull test | 0.240 | 19.873 | 0.000 | NOT ACCEPTED | JSON record |
| assembly-seed201 | Safe stop | 0.408 | 24.100 | 0.000 | NOT ACCEPTED | JSON record |
| assembly-seed202 | Release | -0.000 | 28.767 | 2.050 | PASS | JSON record |
| assembly-seed203 | Release | -0.000 | 31.952 | 2.050 | PASS | JSON record |
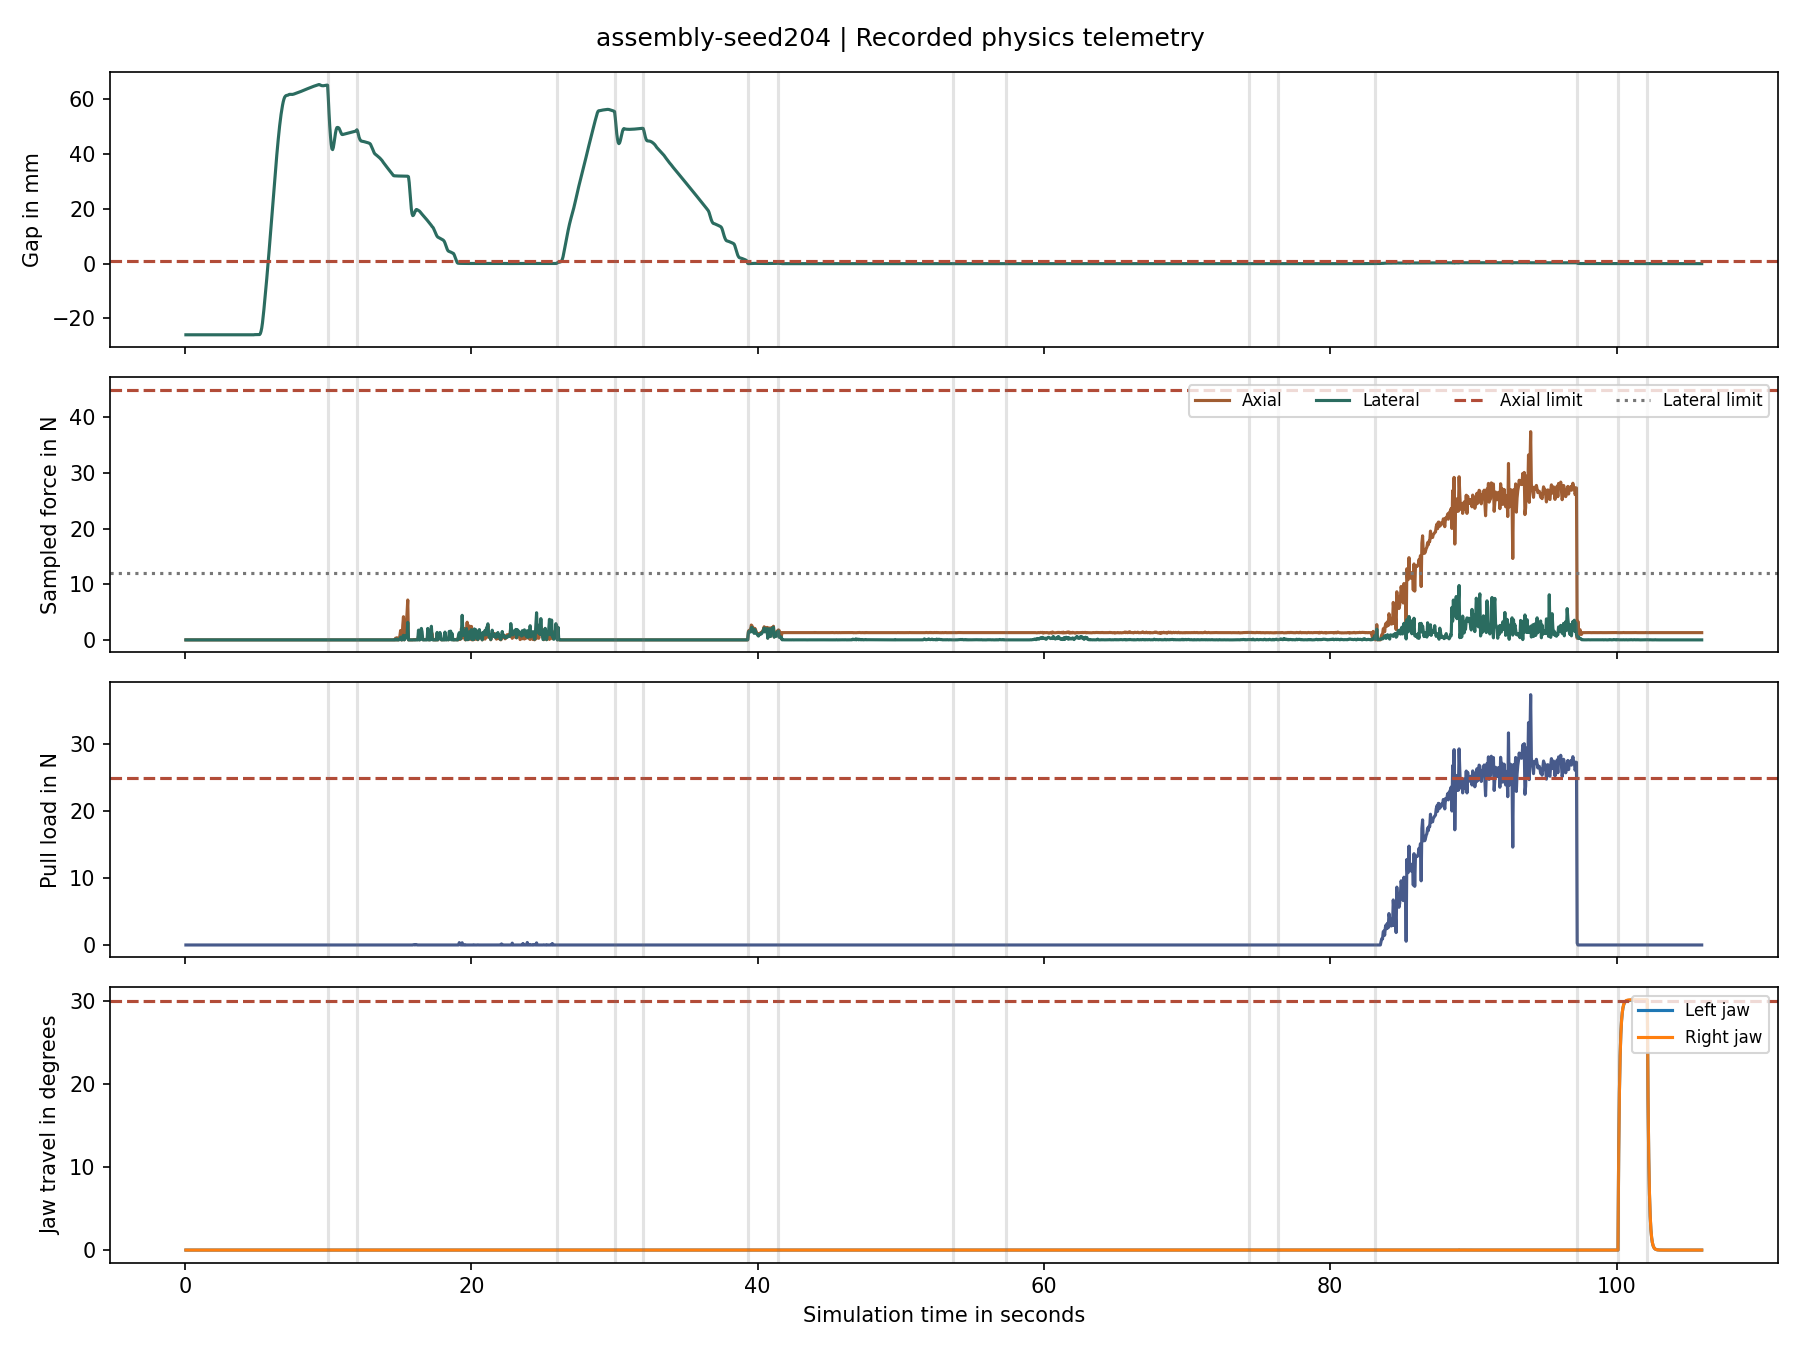
| assembly-seed204 | Release | -0.000 | 37.434 | 2.050 | PASS | JSON record |
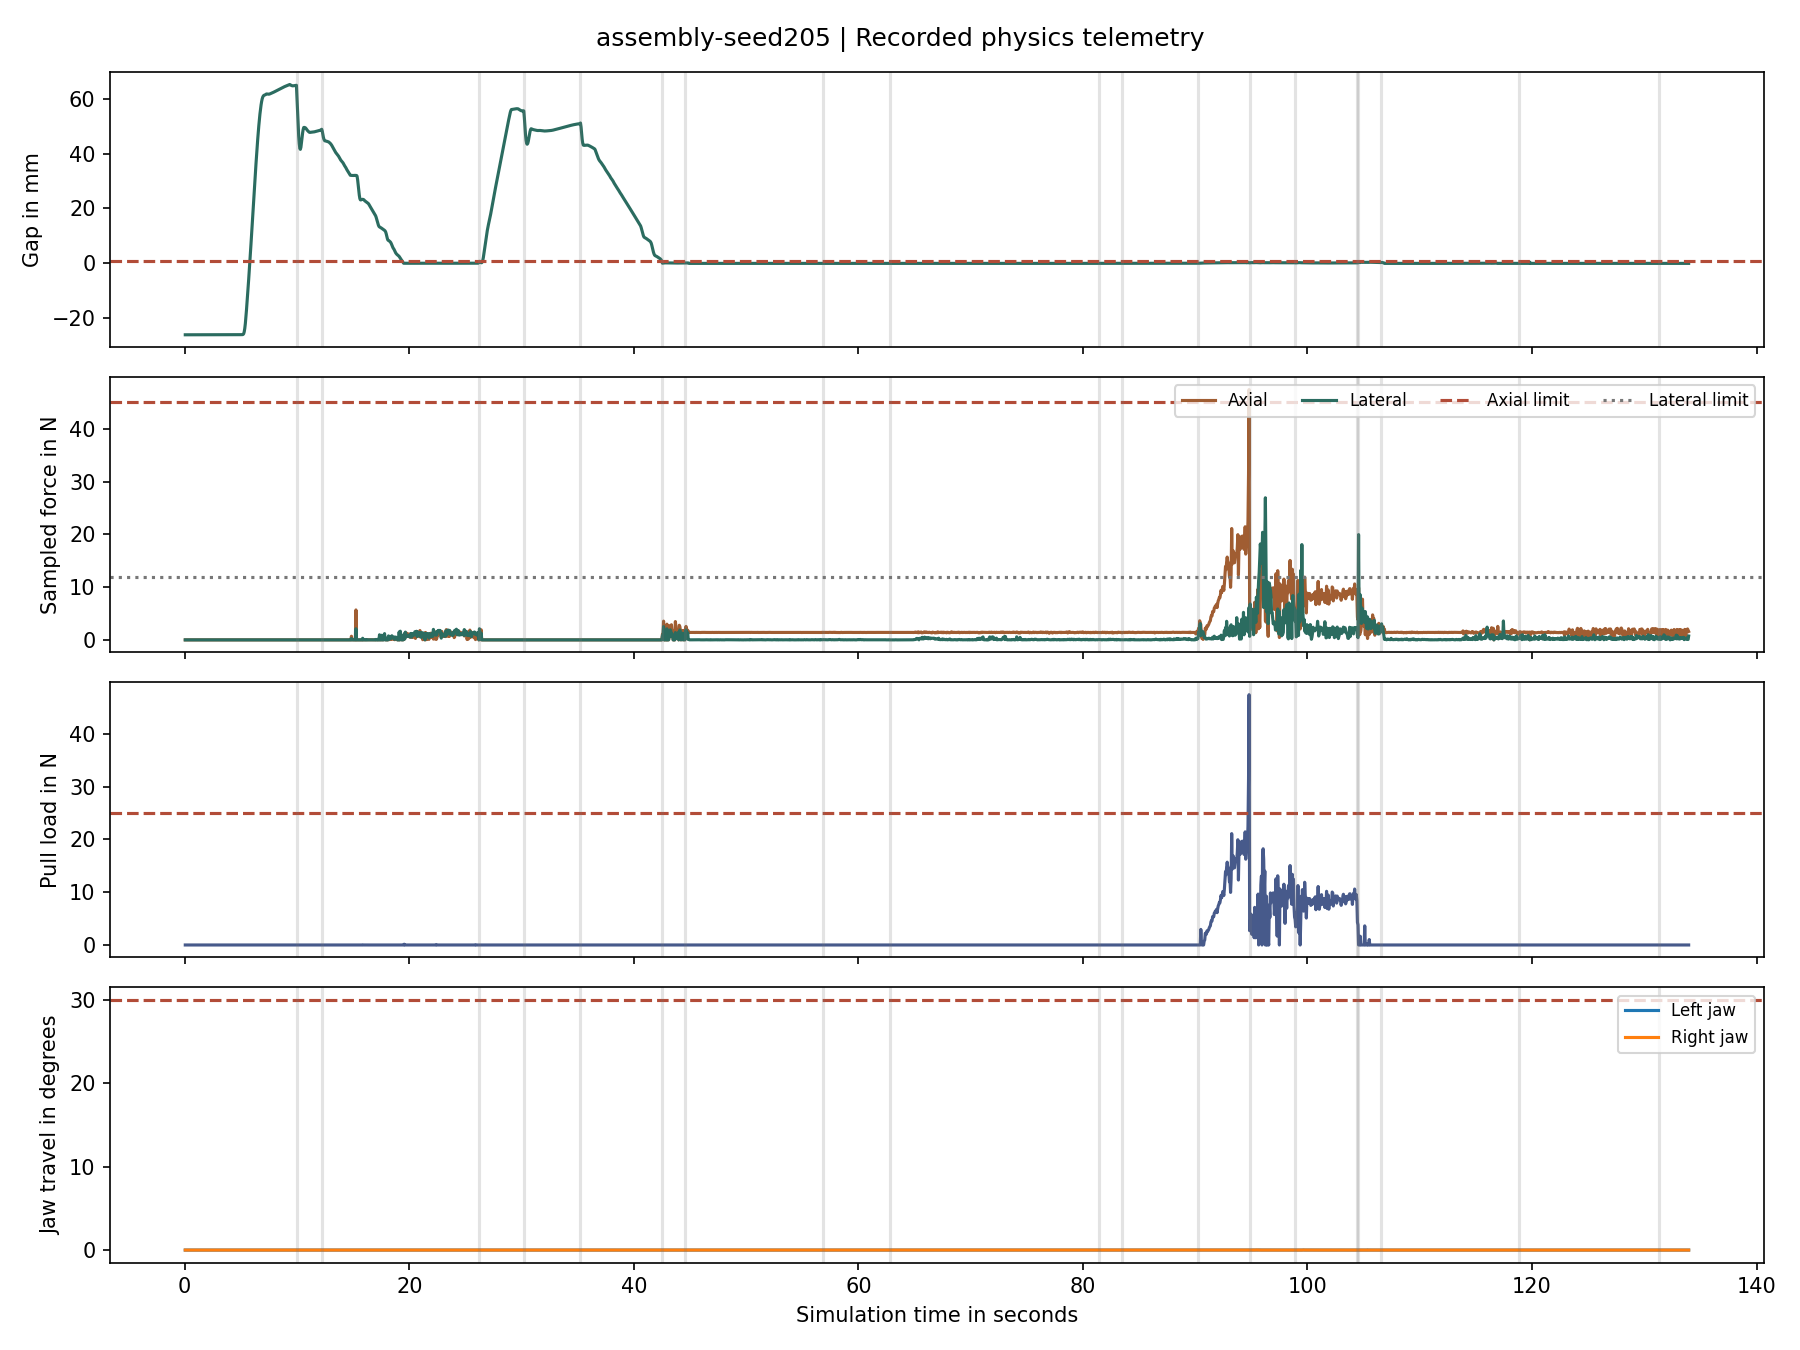
| assembly-seed205 | Pin insert | -0.000 | 47.436 | 0.000 | NOT ACCEPTED | JSON record |
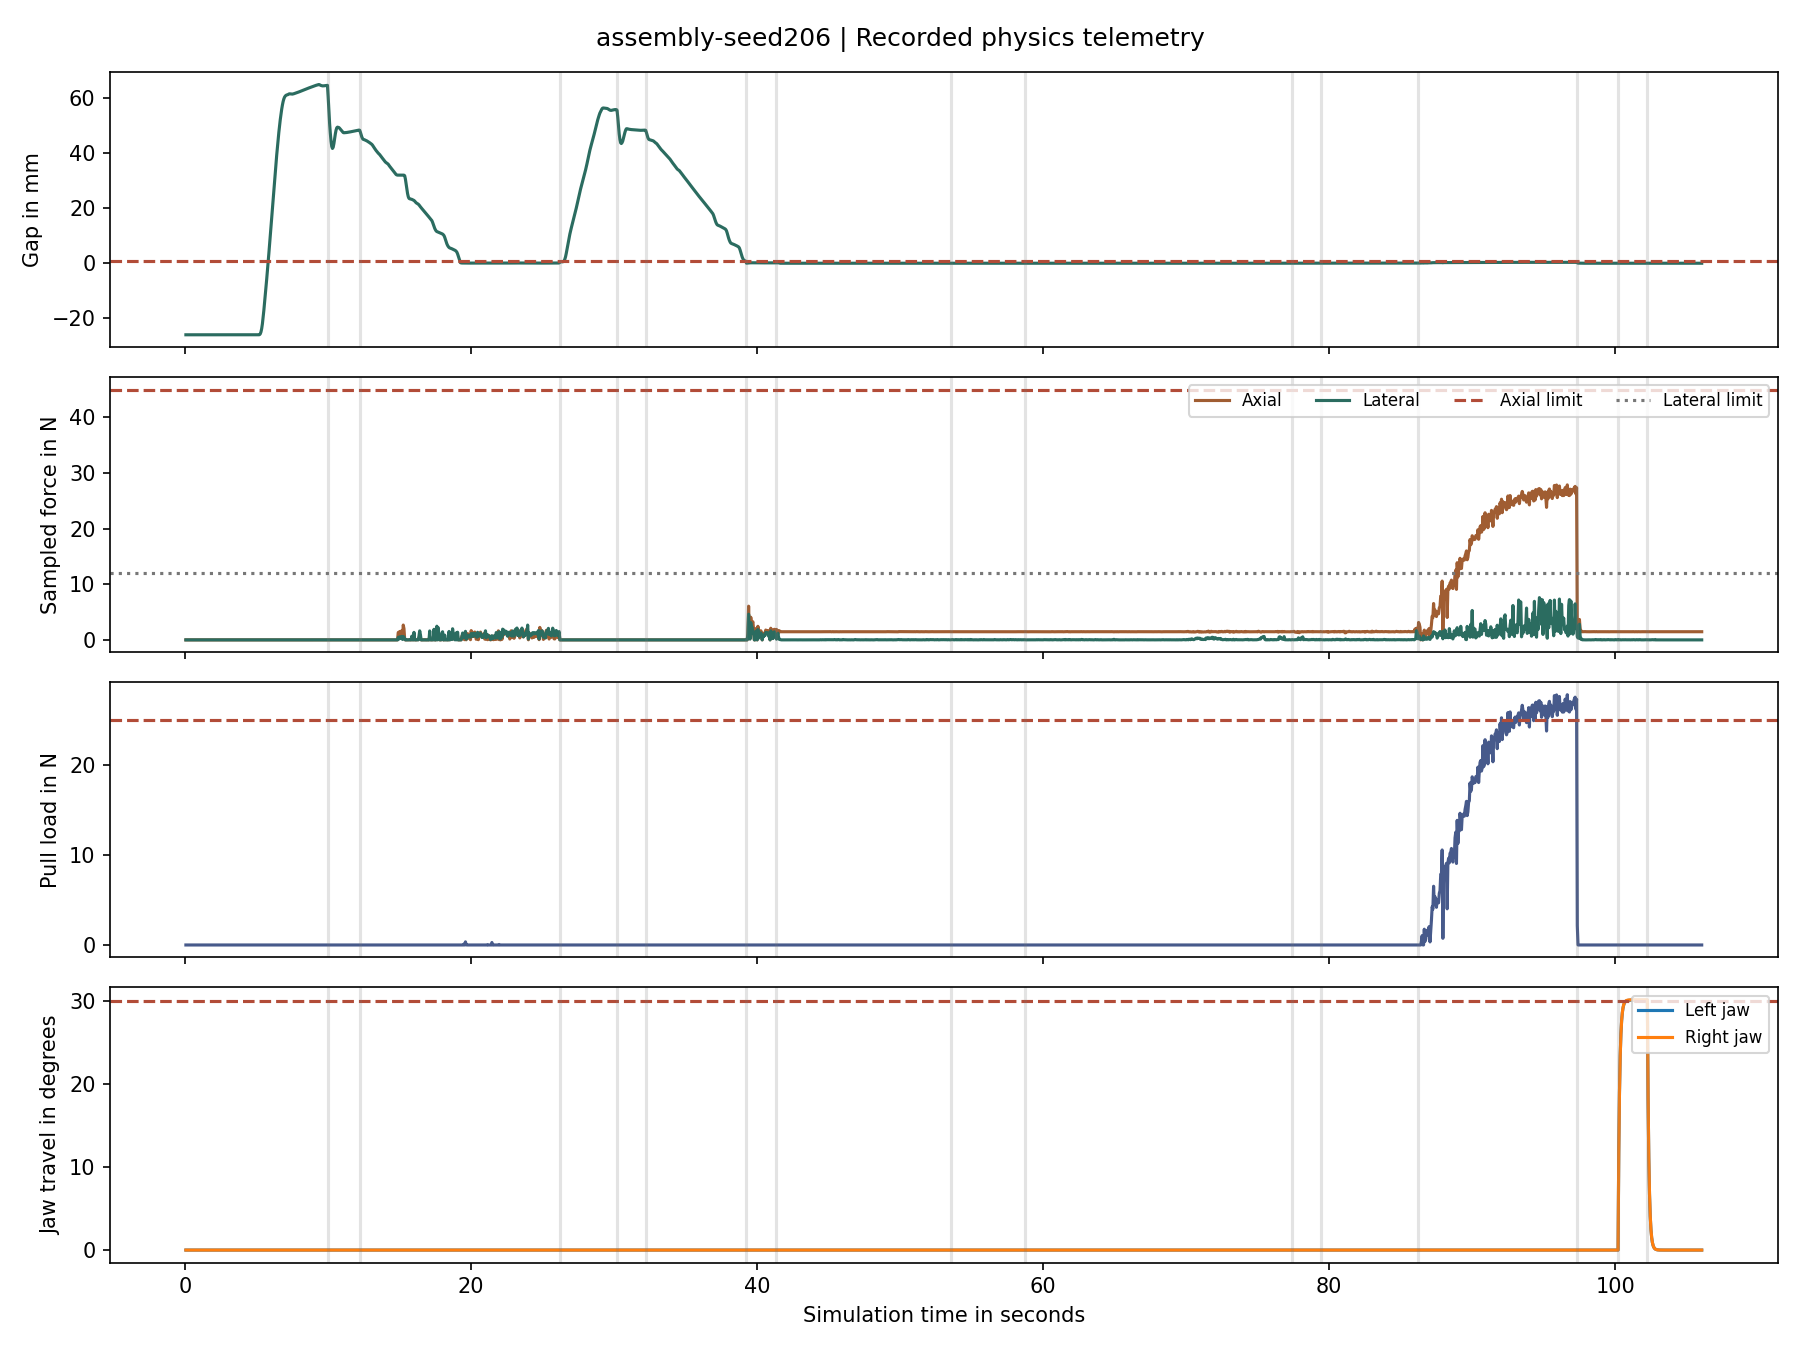
| assembly-seed206 | Release | -0.000 | 27.870 | 2.050 | PASS | JSON record |
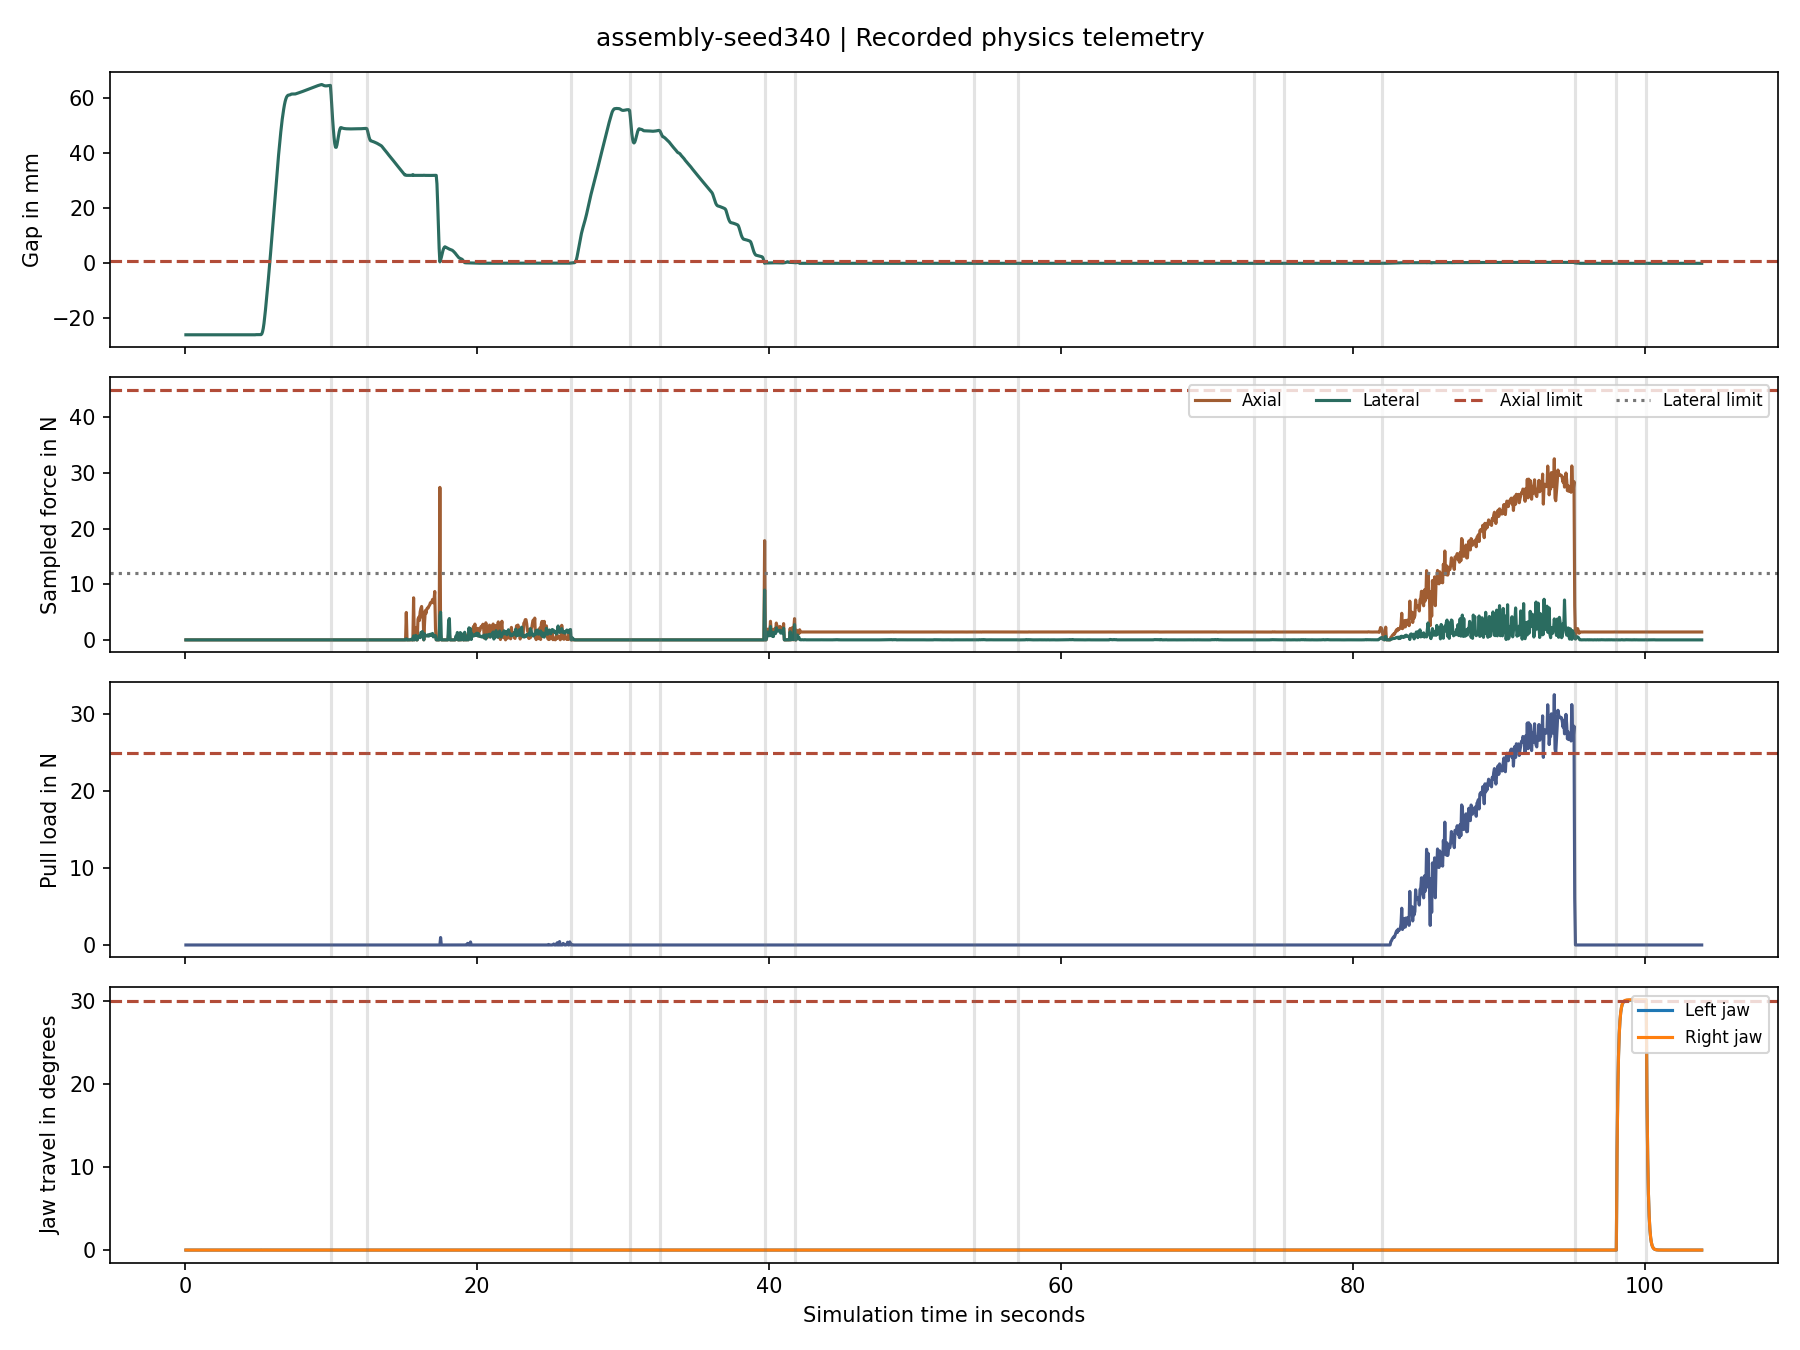
| assembly-seed340 | Release | -0.000 | 32.564 | 2.050 | PASS | JSON record |
| assembly-seed341 | Release | -0.000 | 29.192 | 2.050 | PASS | JSON record |
| assembly-seed342 | Release | -0.000 | 29.731 | 2.050 | PASS | JSON record |
| assembly-seed343 | Release | -0.000 | 30.238 | 2.050 | PASS | JSON record |
| assembly-seed344 | Release | -0.000 | 37.735 | 2.050 | PASS | JSON record |
| assembly-seed345 | Safe stop | 50.306 | 4.744 | 0.000 | NOT ACCEPTED | JSON record |
| assembly-seed346 | Release | -0.000 | 36.936 | 2.050 | PASS | JSON record |
| assembly-seed347 | Release | -0.000 | 29.834 | 2.050 | PASS | JSON record |
| assembly-seed348 | Safe stop | 44.633 | 9.413 | 0.000 | NOT ACCEPTED | JSON record |
| assembly-seed400 | Release | -0.000 | 30.080 | 2.050 | PASS | JSON record |
| assembly-seed401 | Release | -0.000 | 40.335 | 2.050 | PASS | JSON record |
| assembly-seed402 | Release | -0.000 | 28.772 | 2.050 | PASS | JSON record |
| assembly-seed403 | Release | -0.000 | 30.048 | 2.050 | PASS | JSON record |
| cli-alignment345-v20 | Release | -0.000 | 29.921 | 2.050 | PASS | JSON record |
| cli-alignment348-v20 | Release | -0.000 | 34.245 | 2.050 | PASS | JSON record |
| cli-grasp-v17 | Release | -0.000 | 28.428 | 2.050 | NOT ACCEPTED | JSON record |
| cli-grasp-v18 | Release | -0.000 | 28.562 | 2.050 | PASS | JSON record |
| cli-grasp-v19 | Release | -0.000 | 30.391 | 2.050 | PASS | JSON record |
| cli-grasp205-v21 | Release | -0.000 | 30.549 | 2.050 | NOT ACCEPTED | JSON record |
| cli-grasp345-v21 | Release | -0.000 | 35.460 | 2.050 | NOT ACCEPTED | JSON record |
| cli-grasp348-v21 | Release | -0.000 | 36.679 | 2.050 | NOT ACCEPTED | JSON record |
| cli-grasp401-v21 | Release | -0.000 | 32.134 | 2.050 | NOT ACCEPTED | JSON record |
| cli-hardened-v14 | Release | -0.000 | 33.094 | 2.050 | PASS | JSON record |
| cli-nominal-v10 | Safe stop | 53.938 | 18.647 | 0.000 | NOT ACCEPTED | JSON record |
| cli-recovery-v11 | Safe stop | 0.204 | 17.284 | 0.000 | NOT ACCEPTED | JSON record |
| cli-regression205-v16 | Safe stop | 0.090 | 34.323 | 1.650 | NOT ACCEPTED | JSON record |
| cli-regression205-v17 | Insert | 43.099 | 3.792 | 0.000 | NOT ACCEPTED | JSON record |
| cli-regression205-v18 | Safe stop | 0.057 | 38.107 | 0.250 | NOT ACCEPTED | JSON record |
| cli-regression205-v19 | Release | -0.000 | 37.142 | 2.050 | PASS | JSON record |
| cli-retry-v13 | Release | -0.000 | 33.094 | 2.050 | PASS | JSON record |
| cli-stabilized-v15 | Release | -0.000 | 36.618 | 2.050 | PASS | JSON record |
| feedback-v3 | Align | 50.996 | Not measured | 0.000 | NOT ACCEPTED | JSON record |
| feedback-v4 | Retract | 52.061 | Not measured | 0.000 | NOT ACCEPTED | JSON record |
| full-v9 | Safe stop | 0.159 | 17.942 | 0.000 | NOT ACCEPTED | JSON record |
| geometry-v2 | Approach | 38.233 | Not measured | 0.000 | NOT ACCEPTED | JSON record |
| pin-v6 | Safe stop | 1.922 | Not measured | 0.000 | NOT ACCEPTED | JSON record |
| pin-v7 | Safe stop | -0.004 | Not measured | 0.000 | NOT ACCEPTED | JSON record |
| pin-v8 | Safe stop | -0.002 | Not measured | 0.000 | NOT ACCEPTED | JSON record |
| pull-controller-probe-v12 | Safe stop | -0.000 | 28.087 | 2.000 | NOT ACCEPTED | JSON record |
| pull-controller-probe-v13 | Release | -0.000 | 28.087 | 2.000 | NOT ACCEPTED | JSON record |
| seating-v5 | Verify seating | 0.057 | Not measured | 0.000 | NOT ACCEPTED | JSON record |
Randomized insertion repeatability
The frozen campaign is varying initial yaw from minus six to plus six degrees. It is varying approach offset within three millimeters. Friction is varying by twenty percent and mass by ten percent. The controller is receiving simulator pose feedback. This is testing physical insertion repeatability with privileged sensing.
The recorded result is 20 passes in 20 completed trials. The Wilson 95 percent interval is 0.839 to 1.000. A small campaign is not establishing a production failure rate.
| Seed | Yaw degrees | Approach offset mm | Friction scale | Mass scale | Final gap mm | Peak sampled contact N | Insertion gate |
|---|---|---|---|---|---|---|---|
| 100 | -3.48 | -1.72 | 0.96 | 1.09 | 0.040 | 3.051 | PASS |
| 101 | 0.05 | -1.07 | 0.81 | 0.94 | 0.036 | 2.855 | PASS |
| 102 | -5.92 | 0.13 | 1.05 | 1.10 | 0.027 | 1.966 | PASS |
| 103 | 0.03 | -1.53 | 1.01 | 1.01 | 0.075 | 3.111 | PASS |
| 104 | 0.69 | 1.99 | 1.08 | 0.94 | 0.103 | 5.276 | PASS |
| 105 | -0.78 | -0.26 | 0.85 | 0.99 | 0.144 | 2.447 | PASS |
| 106 | -3.54 | -1.63 | 1.03 | 0.90 | 0.015 | 3.543 | PASS |
| 107 | -3.44 | -0.08 | 0.86 | 1.04 | 0.015 | 2.190 | PASS |
| 108 | -3.01 | 0.20 | 0.89 | 0.98 | 0.016 | 4.016 | PASS |
| 109 | -4.01 | -2.51 | 0.98 | 1.00 | 0.017 | 3.053 | PASS |
| 110 | -5.96 | 1.90 | 1.17 | 1.03 | 0.009 | 2.226 | PASS |
| 111 | -2.20 | 0.76 | 1.13 | 0.98 | 0.011 | 5.455 | PASS |
| 112 | 3.12 | -0.21 | 1.16 | 0.92 | 0.147 | 3.801 | PASS |
| 113 | -1.37 | 1.42 | 1.05 | 0.95 | 0.137 | 4.445 | PASS |
| 114 | 5.18 | 2.98 | 0.82 | 0.91 | 0.091 | 1.964 | PASS |
| 115 | 2.91 | -2.81 | 0.81 | 1.09 | 0.166 | 6.389 | PASS |
| 116 | -2.23 | 1.19 | 1.09 | 0.97 | 0.050 | 2.665 | PASS |
| 117 | 2.34 | -2.66 | 0.96 | 0.96 | 0.146 | 2.714 | PASS |
| 118 | -0.82 | 1.24 | 1.18 | 0.90 | 0.147 | 3.501 | PASS |
| 119 | 1.14 | -2.96 | 1.17 | 1.10 | 0.087 | 2.803 | PASS |
Engineering findings and corrections
The initial GPU pilot is ending with zero task score. Inspection is identifying missing production sensor and action bindings in the original adapter. The original release checker is looking only at final safety values. It is also trusting a simulator name and supplied video metadata too broadly.
The revised scene is separating the housing grasp from the insertion point. This is reducing interference between the two robot grippers. The first seated approach is still showing about five millimeters of remaining gap. Geometry inspection is identifying a shoulder and rim mismatch. The corrected rim is allowing the intended 32 mm insertion depth without relaxing the depth threshold.
The physical cross pin is then entering the mating holes. The first pull attempt is exposing excessive mechanical play and fixture motion. The tighter pin is reducing available play but is demanding more accurate alignment. Full orientation feedback and measured tool offsets are addressing pin tilt. Active left arm feedback is reacting to fixture movement.
The software checks are now examining complete telemetry. They are rejecting nonfinite measurements and discontinuous steps. They are requiring continuous pull evidence. The development twin is rejecting motion proof before a sustained pull test. Its friction parameter is affecting contact behavior. Invalid work orders are failing validation.
The recording pipeline is saving lossless PNG frames with pixel hashes. H264 export is verifying decoded frame counts. Earlier raw NumPy frames are being removed only after successful video verification. Source snapshots are identifying the code used by each newer run. The earliest development runs are retaining their logs without retroactively claiming stronger source provenance.
Controller hardening and regression evidence
The updated left arm controller is tracking the measured grasp transform in the housing frame. It is following housing motion while retaining the original grasp reference. The pull controller is loading more slowly and is unloading faster when the measured load trend predicts an overshoot. The original force and grasp limits are remaining unchanged.
Every stop transition is preserving measured joint targets. Safety faults are taking priority over retry suggestions. The campaign runner is exporting three camera views for every rendered trial and is checking decoded frame counts before compacting disposable frames. It is terminating the full process group on timeout.
Alignment reachability analysis
Trial 345 is ending in a bounded alignment timeout. Its final right wrist joint is measuring -96.972 degrees against a lower limit of -97.000 degrees. An offline inverse kinematics sweep is evaluating lower alignment poses from that recorded state. The calculation is identifying candidate reachable targets. It is not establishing physical recovery success.
| Alignment Height mm | Position Residual mm | Orientation Residual Degrees | Wrist Joint Degrees |
|---|---|---|---|
| 50.0 | 1.441 | 0.401 | -97.000 |
| 45.0 | 0.069 | 0.010 | -95.613 |
| 40.0 | 0.073 | 0.011 | -93.766 |
| 35.0 | 0.062 | 0.009 | -92.044 |
| 30.0 | 0.049 | 0.007 | -90.426 |
Grasp motion failure analysis
The recorded failure is occurring during the pull proof. The displacement decomposition is separating lateral grasp motion from axial compliance. It is using the same original grasp reference as the acceptance audit.
| Recorded Run | Phase | X Motion mm | Y Motion mm | Z Motion mm | Total Motion mm | Pull Load N |
|---|---|---|---|---|---|---|
| assembly-seed401 | Pull test | -0.001 | 2.004 | 0.277 | 2.023 | 29.68 |
| cli-alignment345-v20 | Insert | -0.053 | 1.695 | 0.001 | 1.696 | 0.00 |
| cli-alignment348-v20 | Pull test | 0.018 | 1.525 | 0.195 | 1.537 | 28.79 |
Pull grasp regression evaluation
The candidate controller is retaining the observed gripper orientation relative to the module while applying the pull load. The evaluation is repeating the exact recorded yaw and friction and mass settings from four difficult cases. These targeted regressions are testing the correction and are not replacing the independent qualification campaign.
| Recorded Run | Assembly Checks | Grasp Proxy mm | Final Yaw Degrees | Process Exit | Full Trial Gate |
|---|---|---|---|---|---|
| cli-grasp401-v21 | FAIL | 1.576 | 7.358 | 124 | FAIL |
| cli-grasp345-v21 | FAIL | 1.696 | 7.279 | 0 | FAIL |
| cli-grasp348-v21 | FAIL | 1.504 | 7.242 | 0 | FAIL |
| cli-grasp205-v21 | FAIL | 1.466 | 7.326 | 0 | FAIL |
What is still required before production release
The simulation acceptance contract is requiring at least twenty complete recovery trials with an observed acceptance rate of at least 95 percent. The current release table is reporting whether this gate is passing. It is requiring measured pull proof and jaw motion in each accepted run. It is requiring independent wrist wrench calibration and complete servo timing coverage. It is requiring collision and limit validation on the physical YAM hardware. It is requiring a cell specific inspection dataset and a documented process for handling uncertain or failed QA.
The public datasets are testing related capabilities. They are not representing this exact gripper interface. The image models are using a 256 by 256 input and may be losing very small defects. The current normal calibration threshold is favoring a low false alarm rate and is missing some anomalies. Those misses are remaining visible in the prediction files.
The interface wrench is coming from simulated contacts. It is not substituting for a calibrated six axis wrist sensor. The controller is depending on privileged simulator poses. A hardware release requires a validated perception and calibration path. An unattended production cell is also needing independent emergency stop behavior and a validated protective system.
Sources and reproducibility
The public image data is coming from MVTec AD and KolektorSDD2. The robot process data is coming from voraus AD. Dataset licensing is being assessed separately from model performance. Commercial deployment is requiring suitable data rights and cell specific validation.
Dataset URLs and archive hashes are appearing in the acquisition record. Each evaluation is retaining split membership and prediction records. Each recorded robot run is retaining telemetry and an independent assembly record. The final package is providing a SHA256 manifest so transferred files can be checked locally.
Recorded run: assembly-seed200
The run is ending in the Pull test phase. The independent verifier is reporting complete_assembly_sequence, sustained_pull, observed_motion, arms_released.
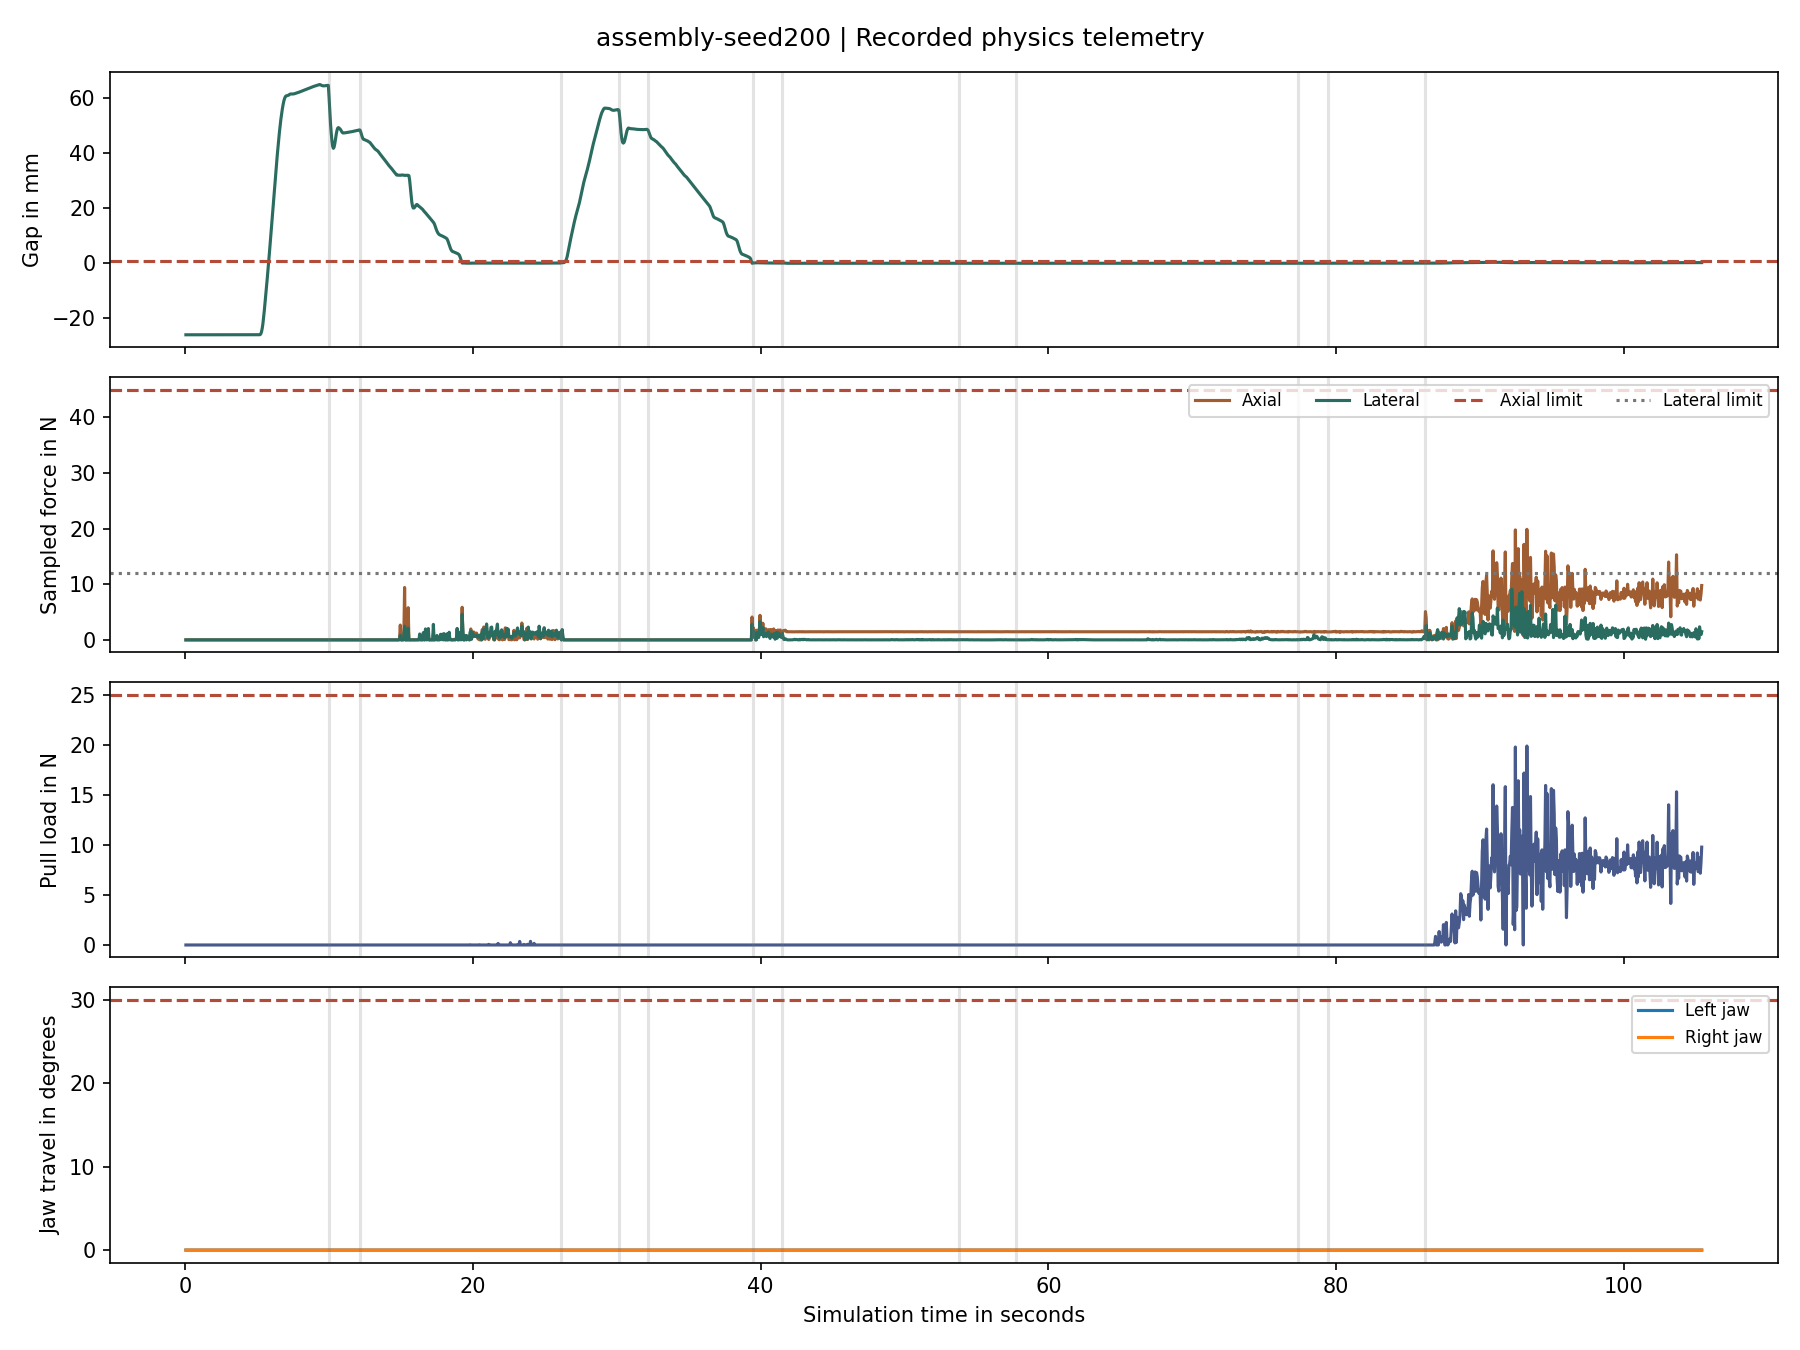
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.150000000000038,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 26.150000000000237,
      "phase": "retract",
      "reason": "Insertion timeout with unresolved gap"
    },
    {
      "time_s": 30.150000000000293,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 32.15000000000031,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 39.449999999999896,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 41.49999999999978,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 53.74999999999908,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 57.749999999998856,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 77.34999999999775,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 79.39999999999763,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 86.14999999999725,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": false,
    "seating": true,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": false,
    "observed_motion": false,
    "arms_released": false
  }
}
Recorded run: assembly-seed201
The run is ending in the Safe stop phase. The independent verifier is reporting complete_assembly_sequence, sampled_force_limits, sustained_pull, observed_motion, arms_released.
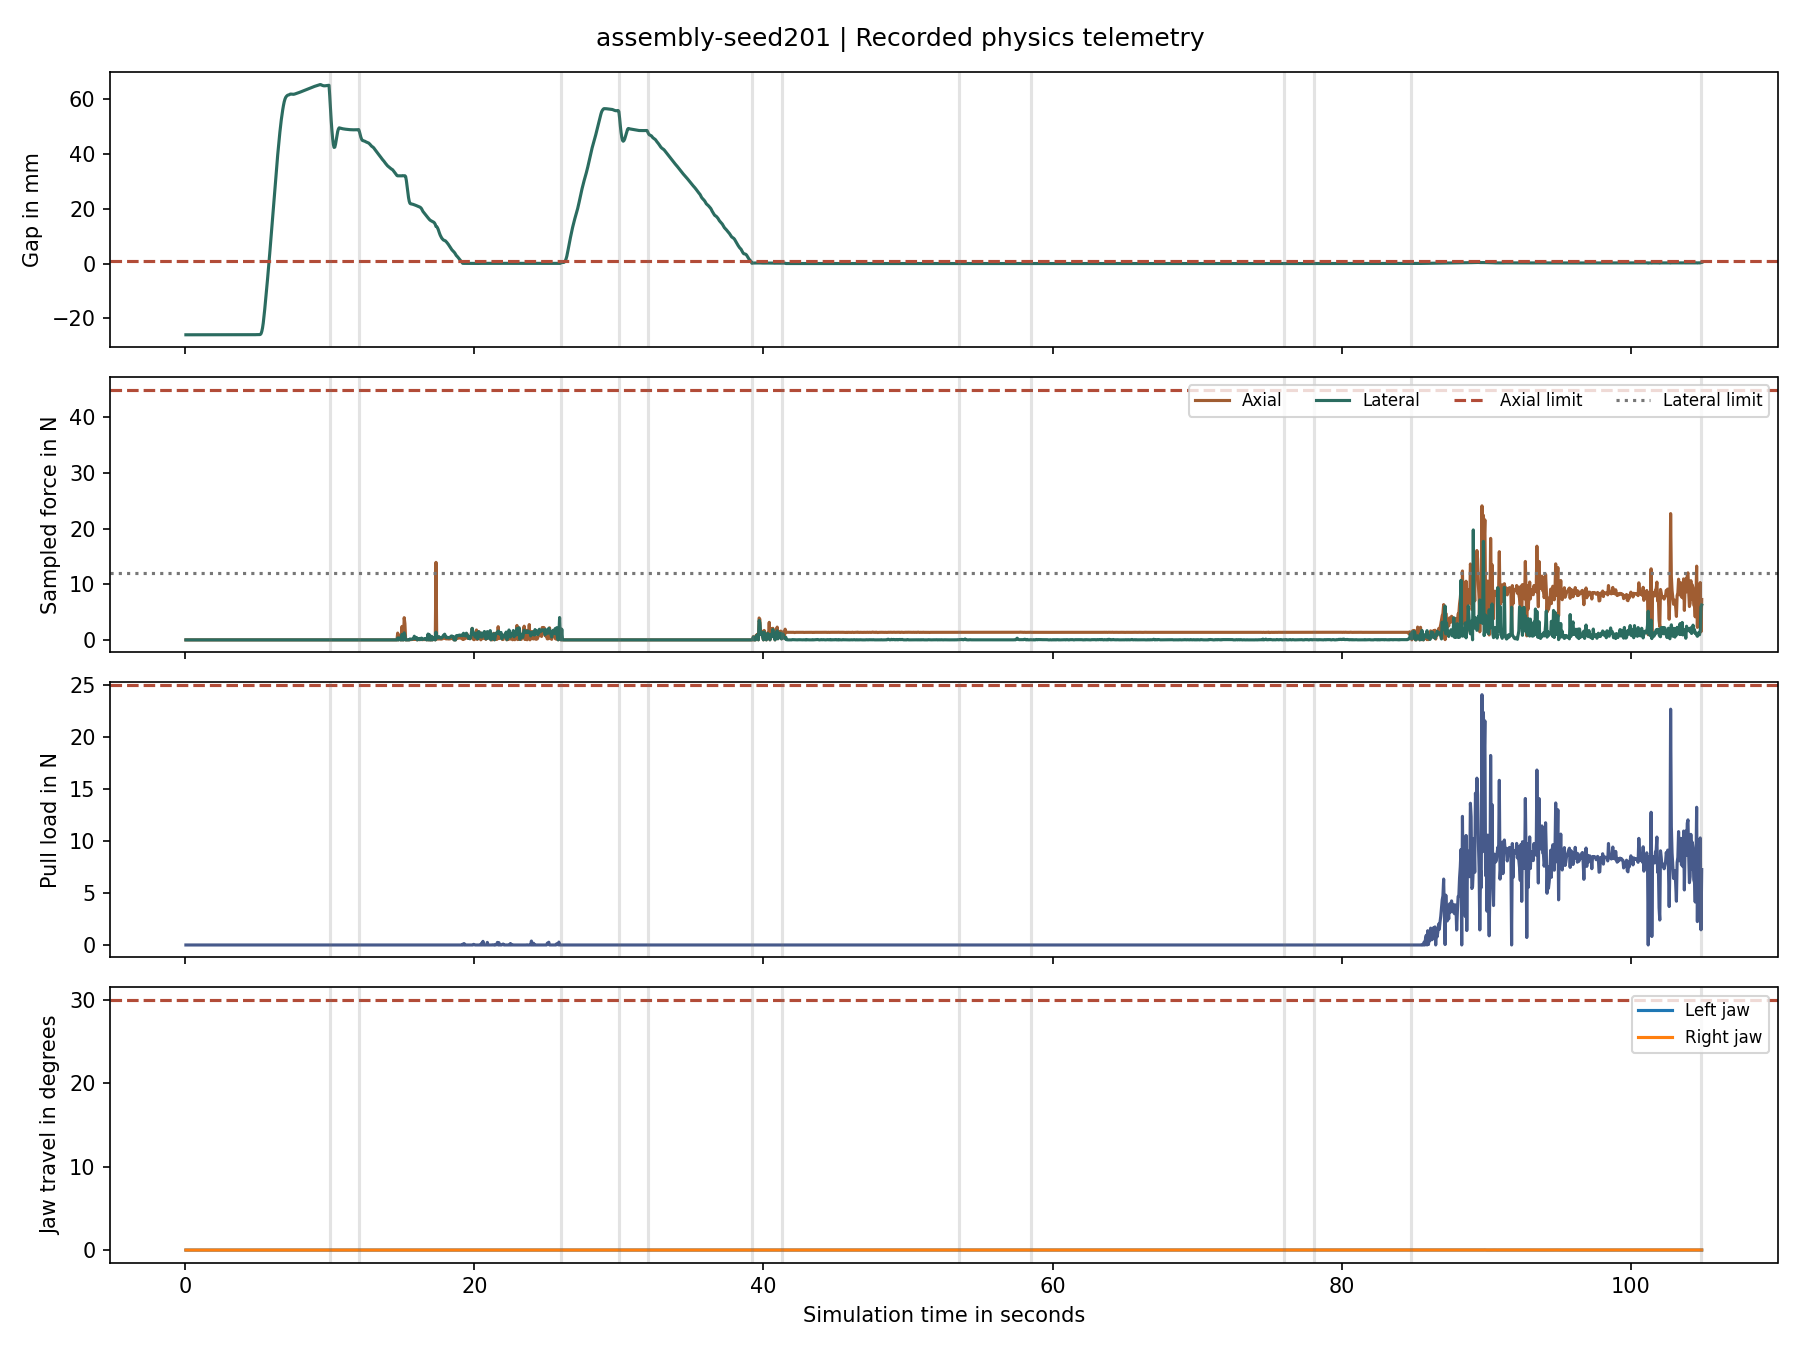
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.000000000000036,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 26.000000000000234,
      "phase": "retract",
      "reason": "Insertion timeout with unresolved gap"
    },
    {
      "time_s": 30.00000000000029,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 32.00000000000032,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 39.19999999999991,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 41.249999999999794,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 53.4999999999991,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 58.49999999999881,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 75.99999999999783,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 78.04999999999771,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 84.79999999999733,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 104.84999999999619,
      "phase": "safe_stop",
      "reason": "Pull proof timeout"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": false,
    "seating": true,
    "pin_engagement": true,
    "sampled_force_limits": false,
    "sampled_torque_limit": true,
    "sustained_pull": false,
    "observed_motion": false,
    "arms_released": false
  }
}
Recorded run: assembly-seed202
The run is ending in the Release phase. The independent verifier is reporting all implemented task checks passed.
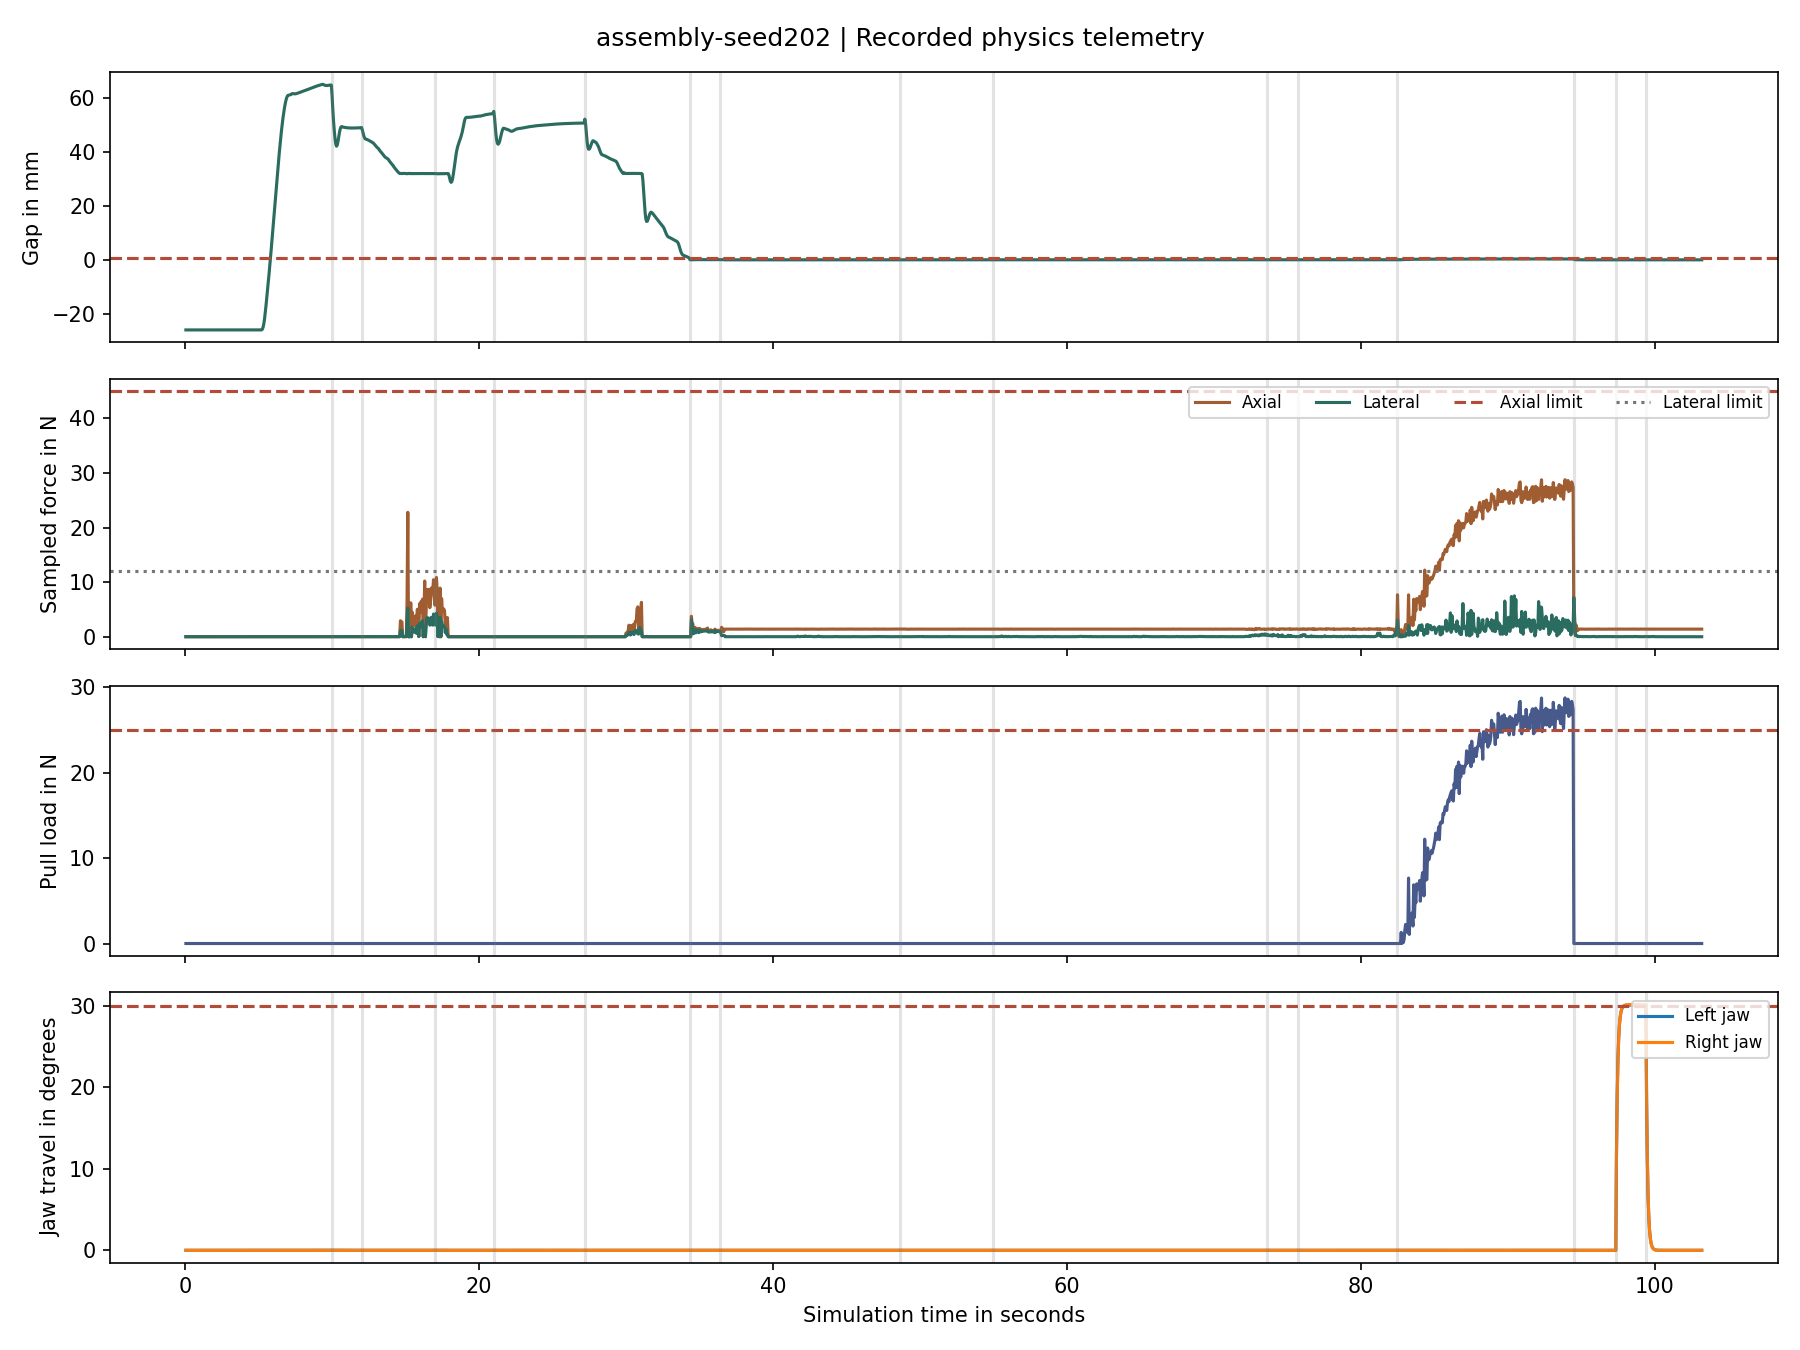
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.000000000000036,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 17.000000000000107,
      "phase": "retract",
      "reason": "Loaded insertion is showing less than 0.5 mm progress in one second"
    },
    {
      "time_s": 21.000000000000163,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 27.20000000000025,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 34.350000000000186,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 36.40000000000007,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 48.64999999999937,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 54.99999999999901,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 73.64999999999796,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 75.69999999999784,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 82.44999999999746,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 94.49999999999677,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 97.34999999999661,
      "phase": "motion_open",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 99.3999999999965,
      "phase": "motion_close",
      "reason": "Measured gripper joint travel is reaching 30 degrees"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": true,
    "seating": true,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": true,
    "observed_motion": true,
    "arms_released": true
  }
}
Recorded run: assembly-seed203
The run is ending in the Release phase. The independent verifier is reporting all implemented task checks passed.
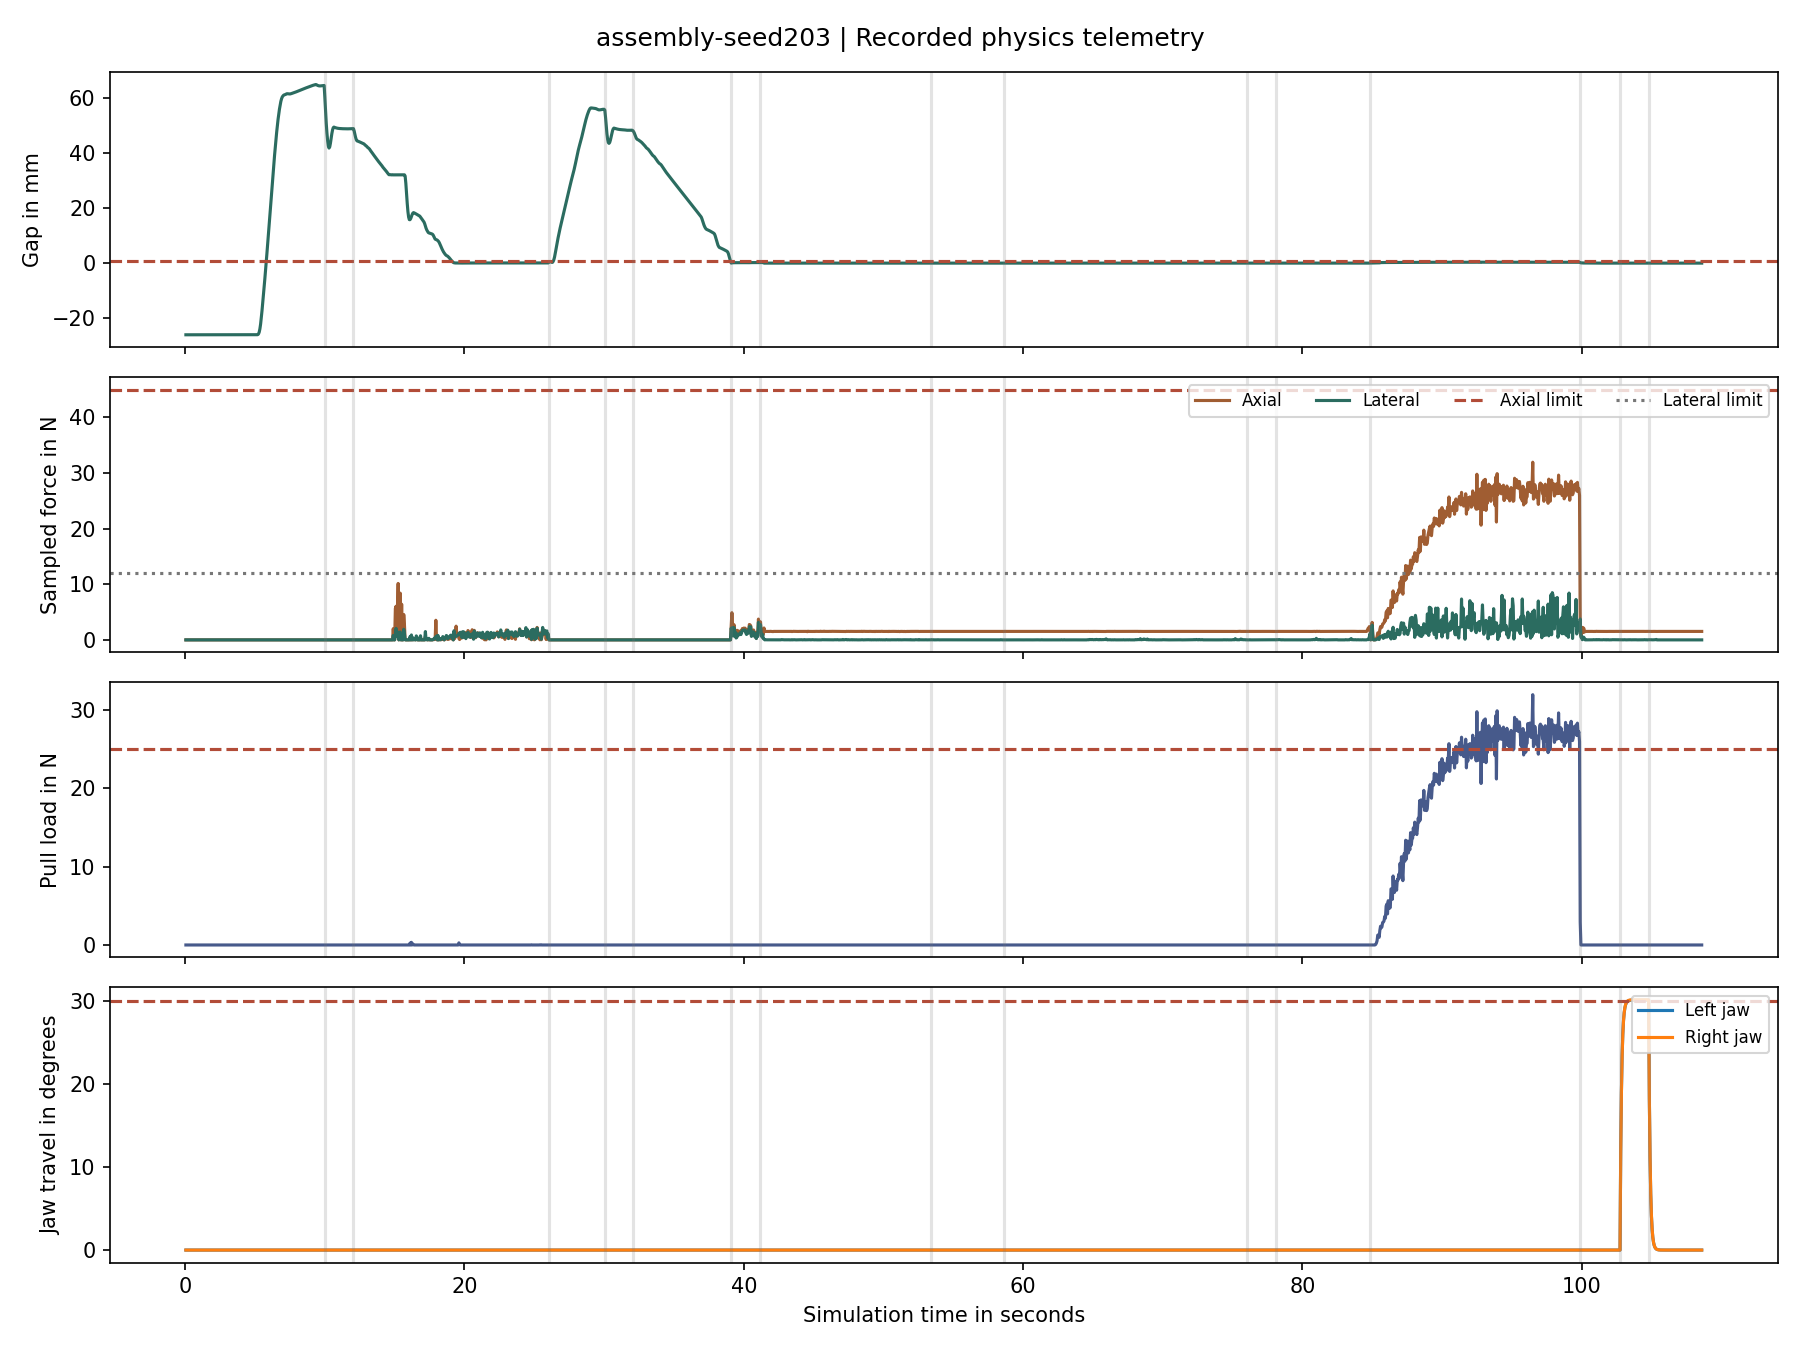
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.050000000000036,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 26.050000000000235,
      "phase": "retract",
      "reason": "Insertion timeout with unresolved gap"
    },
    {
      "time_s": 30.050000000000292,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 32.05000000000032,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 39.099999999999916,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 41.1499999999998,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 53.3999999999991,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 58.649999999998805,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 76.04999999999782,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 78.0999999999977,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 84.84999999999732,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 99.89999999999647,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 102.7499999999963,
      "phase": "motion_open",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 104.79999999999619,
      "phase": "motion_close",
      "reason": "Measured gripper joint travel is reaching 30 degrees"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": true,
    "seating": true,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": true,
    "observed_motion": true,
    "arms_released": true
  }
}
Recorded run: assembly-seed204
The run is ending in the Release phase. The independent verifier is reporting all implemented task checks passed.
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.000000000000036,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 26.000000000000234,
      "phase": "retract",
      "reason": "Insertion timeout with unresolved gap"
    },
    {
      "time_s": 30.00000000000029,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 32.00000000000032,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 39.3499999999999,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 41.399999999999785,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 53.64999999999909,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 57.34999999999888,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 74.29999999999792,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 76.3499999999978,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 83.09999999999742,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 97.24999999999662,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 100.09999999999646,
      "phase": "motion_open",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 102.14999999999634,
      "phase": "motion_close",
      "reason": "Measured gripper joint travel is reaching 30 degrees"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": true,
    "seating": true,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": true,
    "observed_motion": true,
    "arms_released": true
  }
}
Recorded run: assembly-seed205
The run is ending in the Pin insert phase. The independent verifier is reporting complete_assembly_sequence, pin_engagement, sampled_force_limits, sustained_pull, observed_motion, arms_released.
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.200000000000038,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 26.200000000000237,
      "phase": "retract",
      "reason": "Insertion timeout with unresolved gap"
    },
    {
      "time_s": 30.200000000000294,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 35.250000000000135,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 42.54999999999972,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 44.5999999999996,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 56.84999999999891,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 62.79999999999857,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 81.44999999999752,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 83.4999999999974,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 90.24999999999702,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 94.84999999999675,
      "phase": "retract",
      "reason": "Measured contact force exceeds 45 N"
    },
    {
      "time_s": 98.89999999999652,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 104.44999999999621,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 104.4999999999962,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 106.54999999999609,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 118.79999999999539,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 131.34999999999562,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": false,
    "seating": true,
    "pin_engagement": false,
    "sampled_force_limits": false,
    "sampled_torque_limit": true,
    "sustained_pull": false,
    "observed_motion": false,
    "arms_released": false
  }
}
Recorded run: assembly-seed206
The run is ending in the Release phase. The independent verifier is reporting all implemented task checks passed.
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.200000000000038,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 26.200000000000237,
      "phase": "retract",
      "reason": "Insertion timeout with unresolved gap"
    },
    {
      "time_s": 30.200000000000294,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 32.20000000000031,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 39.24999999999991,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 41.29999999999979,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 53.549999999999095,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 58.7499999999988,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 77.39999999999775,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 79.44999999999763,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 86.19999999999725,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 97.34999999999661,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 100.19999999999645,
      "phase": "motion_open",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 102.24999999999633,
      "phase": "motion_close",
      "reason": "Measured gripper joint travel is reaching 30 degrees"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": true,
    "seating": true,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": true,
    "observed_motion": true,
    "arms_released": true
  }
}
Recorded run: assembly-seed340
The run is ending in the Release phase. The independent verifier is reporting all implemented task checks passed.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.450000000000042,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 26.45000000000024,
      "phase": "retract",
      "reason": "Insertion timeout with unresolved gap"
    },
    {
      "time_s": 30.450000000000298,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 32.50000000000029,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 39.74999999999988,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 41.79999999999976,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 54.049999999999066,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 57.049999999998896,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 73.19999999999798,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 75.24999999999787,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 81.99999999999748,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 95.19999999999673,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 98.04999999999657,
      "phase": "motion_open",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 100.09999999999646,
      "phase": "motion_close",
      "reason": "Measured gripper joint travel is reaching 30 degrees"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": true,
    "seating": true,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": true,
    "observed_motion": true,
    "arms_released": true
  }
}
Recorded run: assembly-seed341
The run is ending in the Release phase. The independent verifier is reporting all implemented task checks passed.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
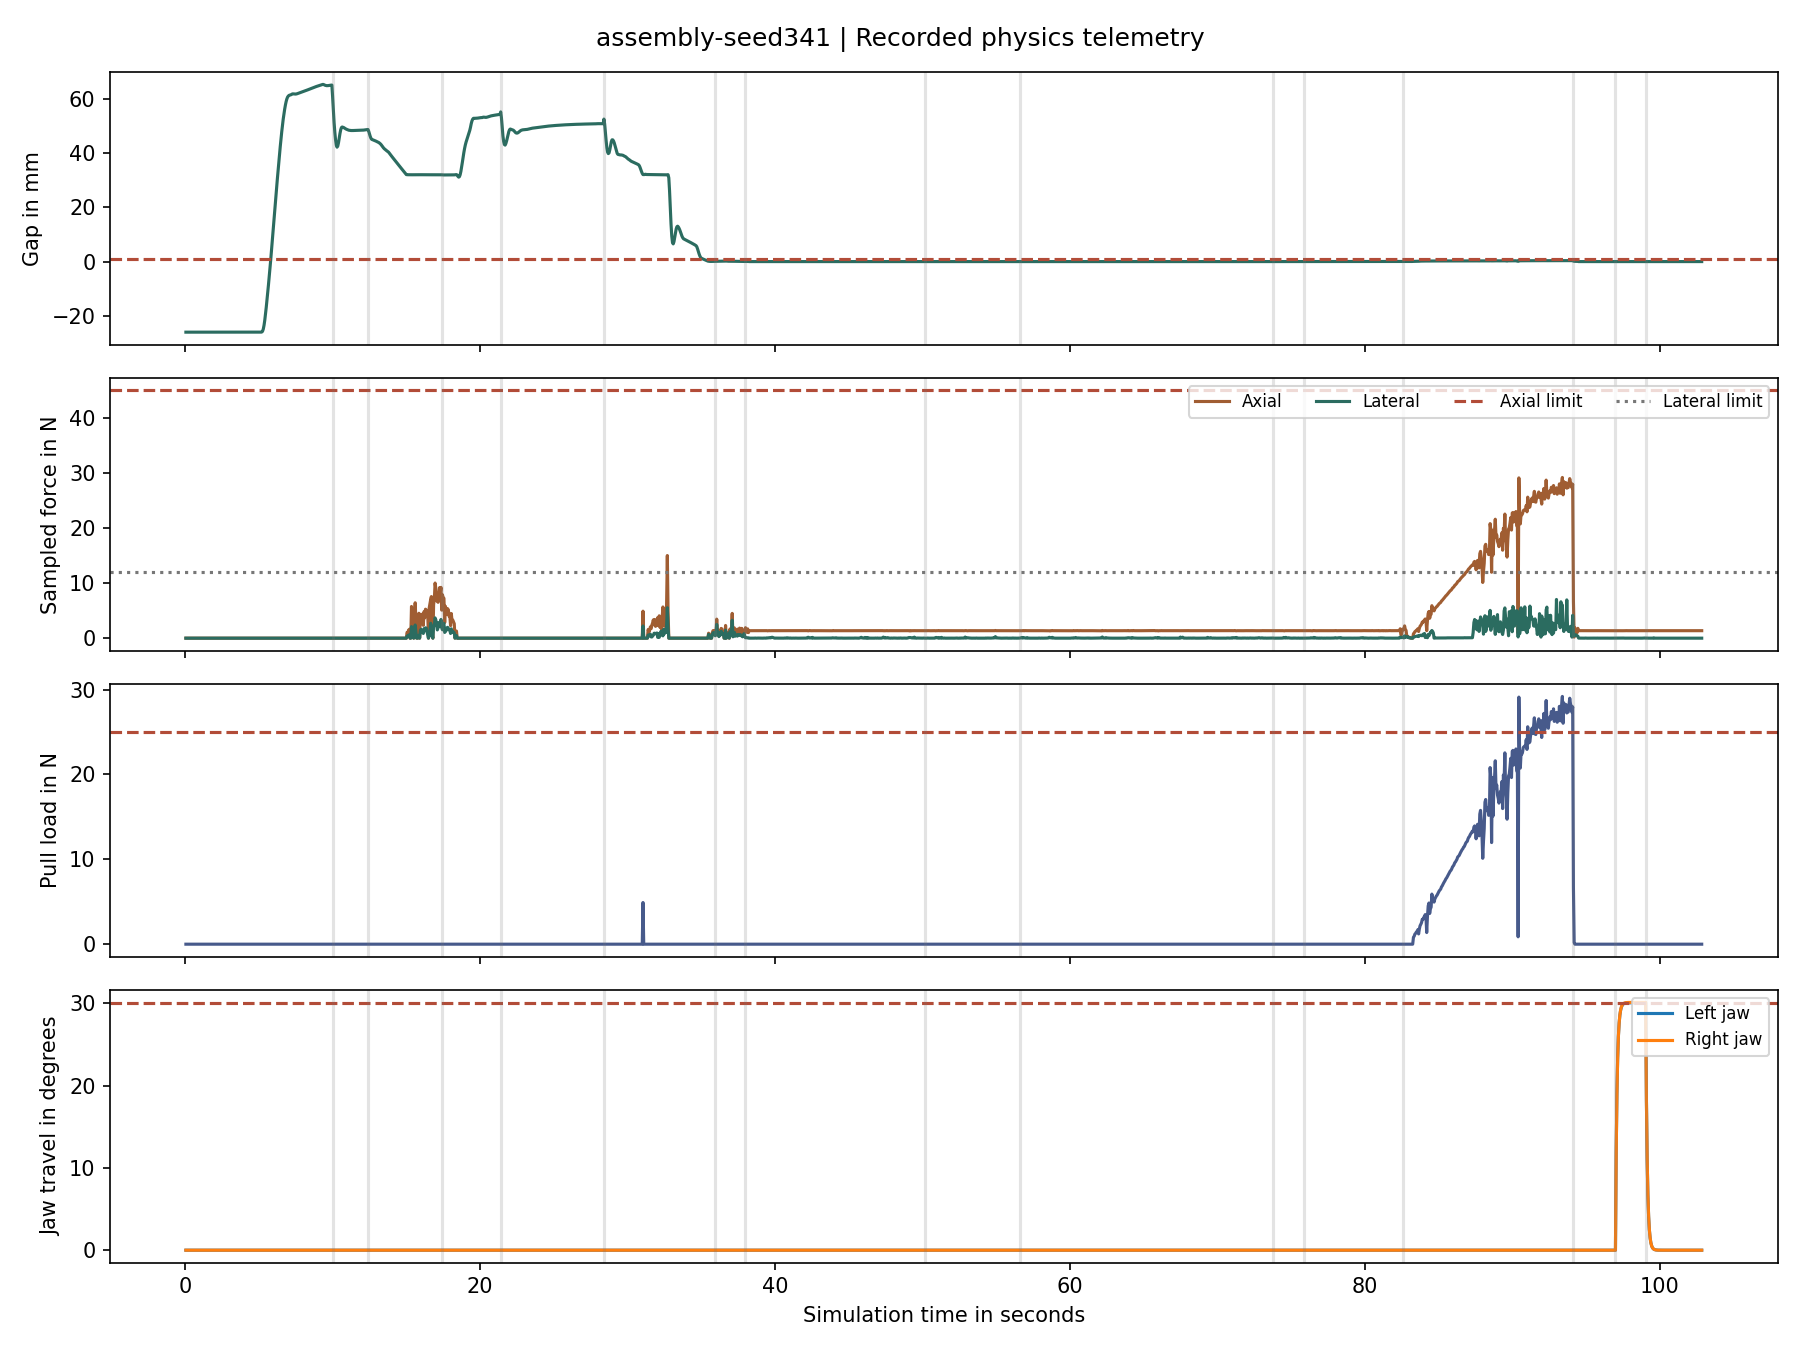
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.400000000000041,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 17.400000000000112,
      "phase": "retract",
      "reason": "Loaded insertion is showing less than 0.5 mm progress in one second"
    },
    {
      "time_s": 21.40000000000017,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 28.40000000000027,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 35.9000000000001,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 37.94999999999998,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 50.199999999999285,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 56.59999999999892,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 73.79999999999795,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 75.84999999999783,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 82.59999999999745,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 94.1499999999968,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 96.99999999999663,
      "phase": "motion_open",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 99.04999999999652,
      "phase": "motion_close",
      "reason": "Measured gripper joint travel is reaching 30 degrees"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": true,
    "seating": true,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": true,
    "observed_motion": true,
    "arms_released": true
  }
}
Recorded run: assembly-seed342
The run is ending in the Release phase. The independent verifier is reporting all implemented task checks passed.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
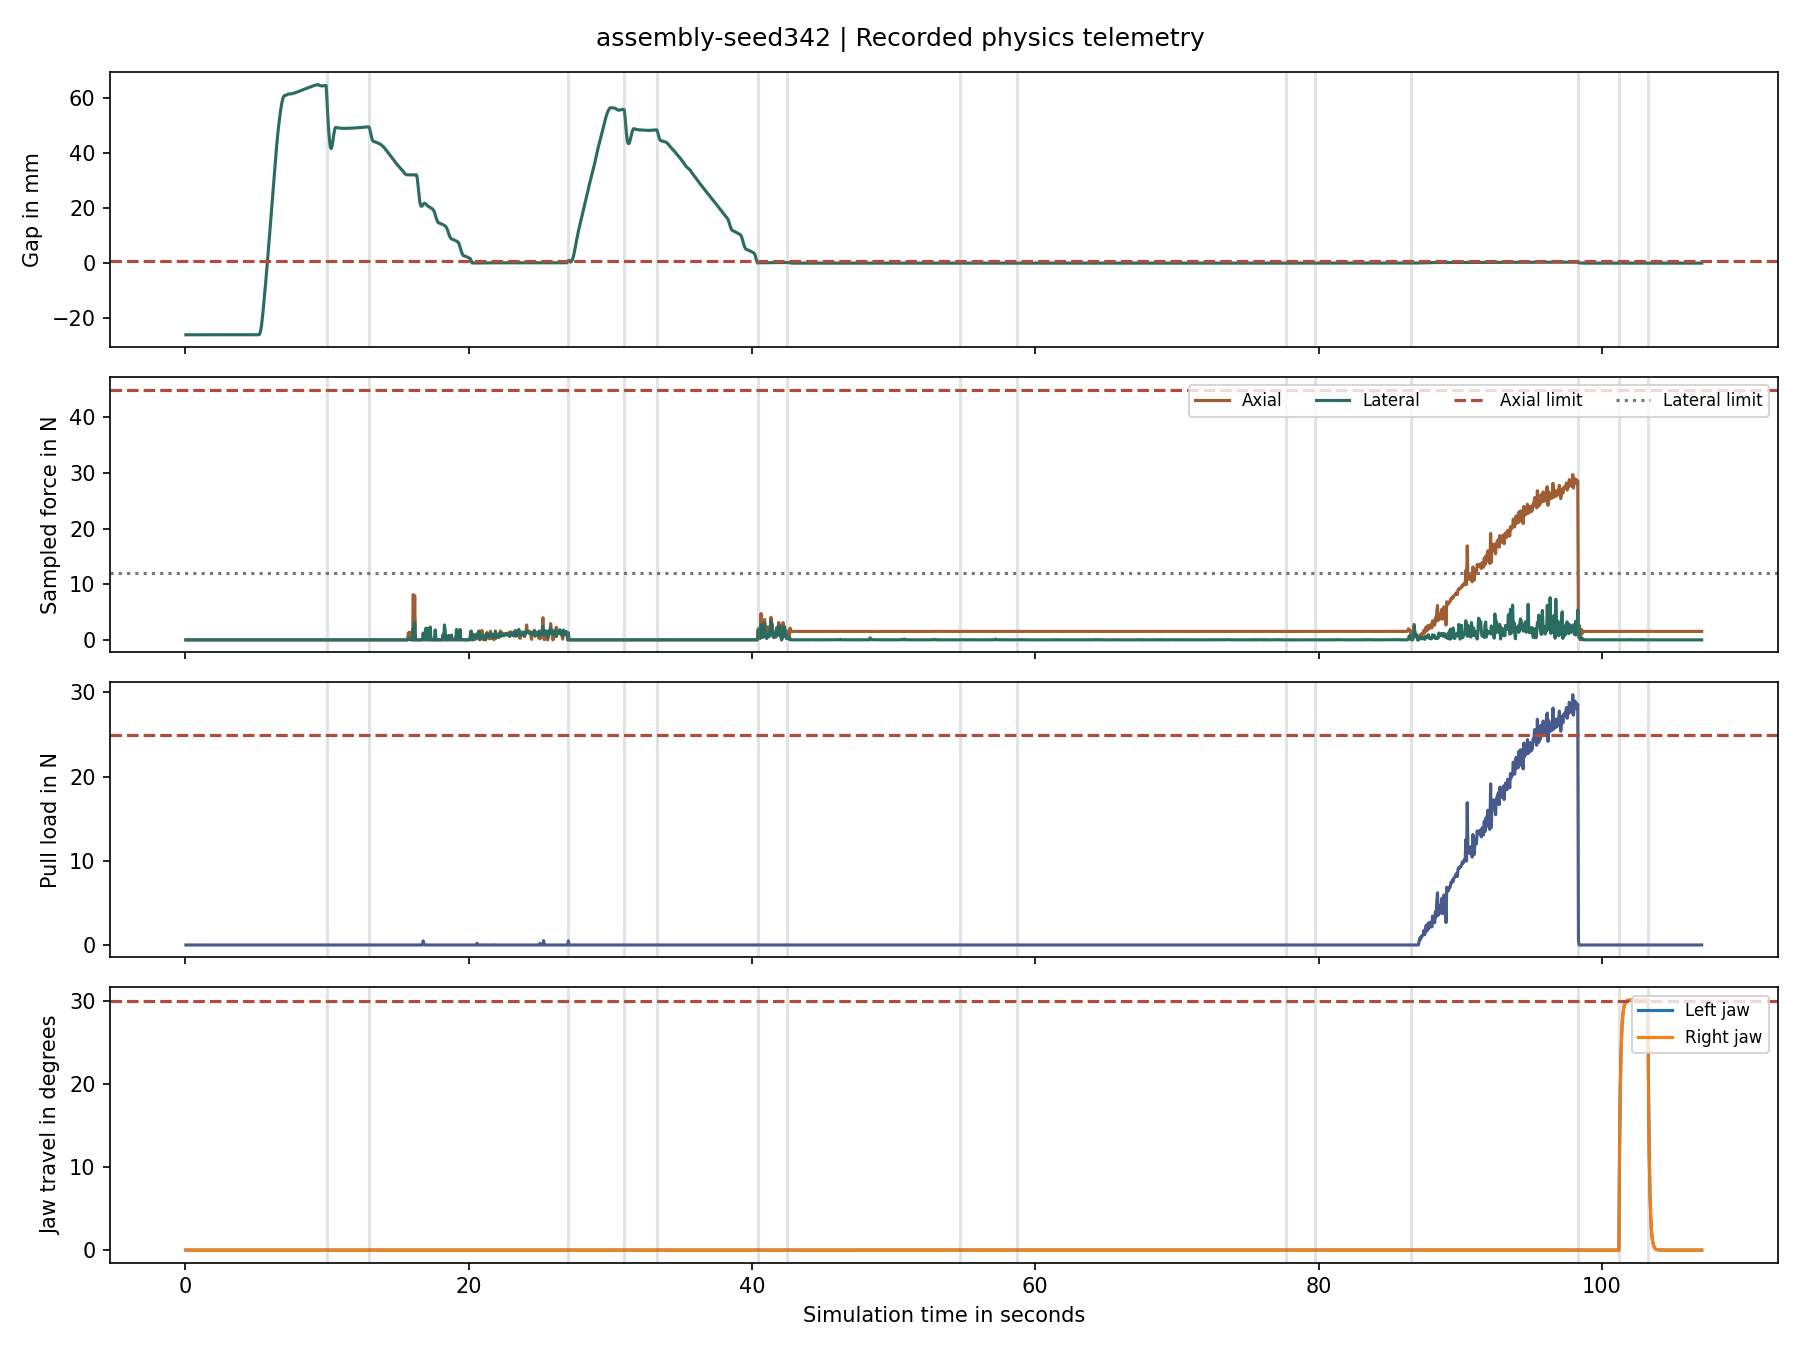
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 13.00000000000005,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 27.00000000000025,
      "phase": "retract",
      "reason": "Insertion timeout with unresolved gap"
    },
    {
      "time_s": 31.000000000000306,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 33.300000000000246,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 40.39999999999984,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 42.449999999999726,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 54.69999999999903,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 58.7499999999988,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 77.69999999999773,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 79.74999999999761,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 86.49999999999723,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 98.34999999999656,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 101.1999999999964,
      "phase": "motion_open",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 103.24999999999628,
      "phase": "motion_close",
      "reason": "Measured gripper joint travel is reaching 30 degrees"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": true,
    "seating": true,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": true,
    "observed_motion": true,
    "arms_released": true
  }
}
Recorded run: assembly-seed343
The run is ending in the Release phase. The independent verifier is reporting all implemented task checks passed.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
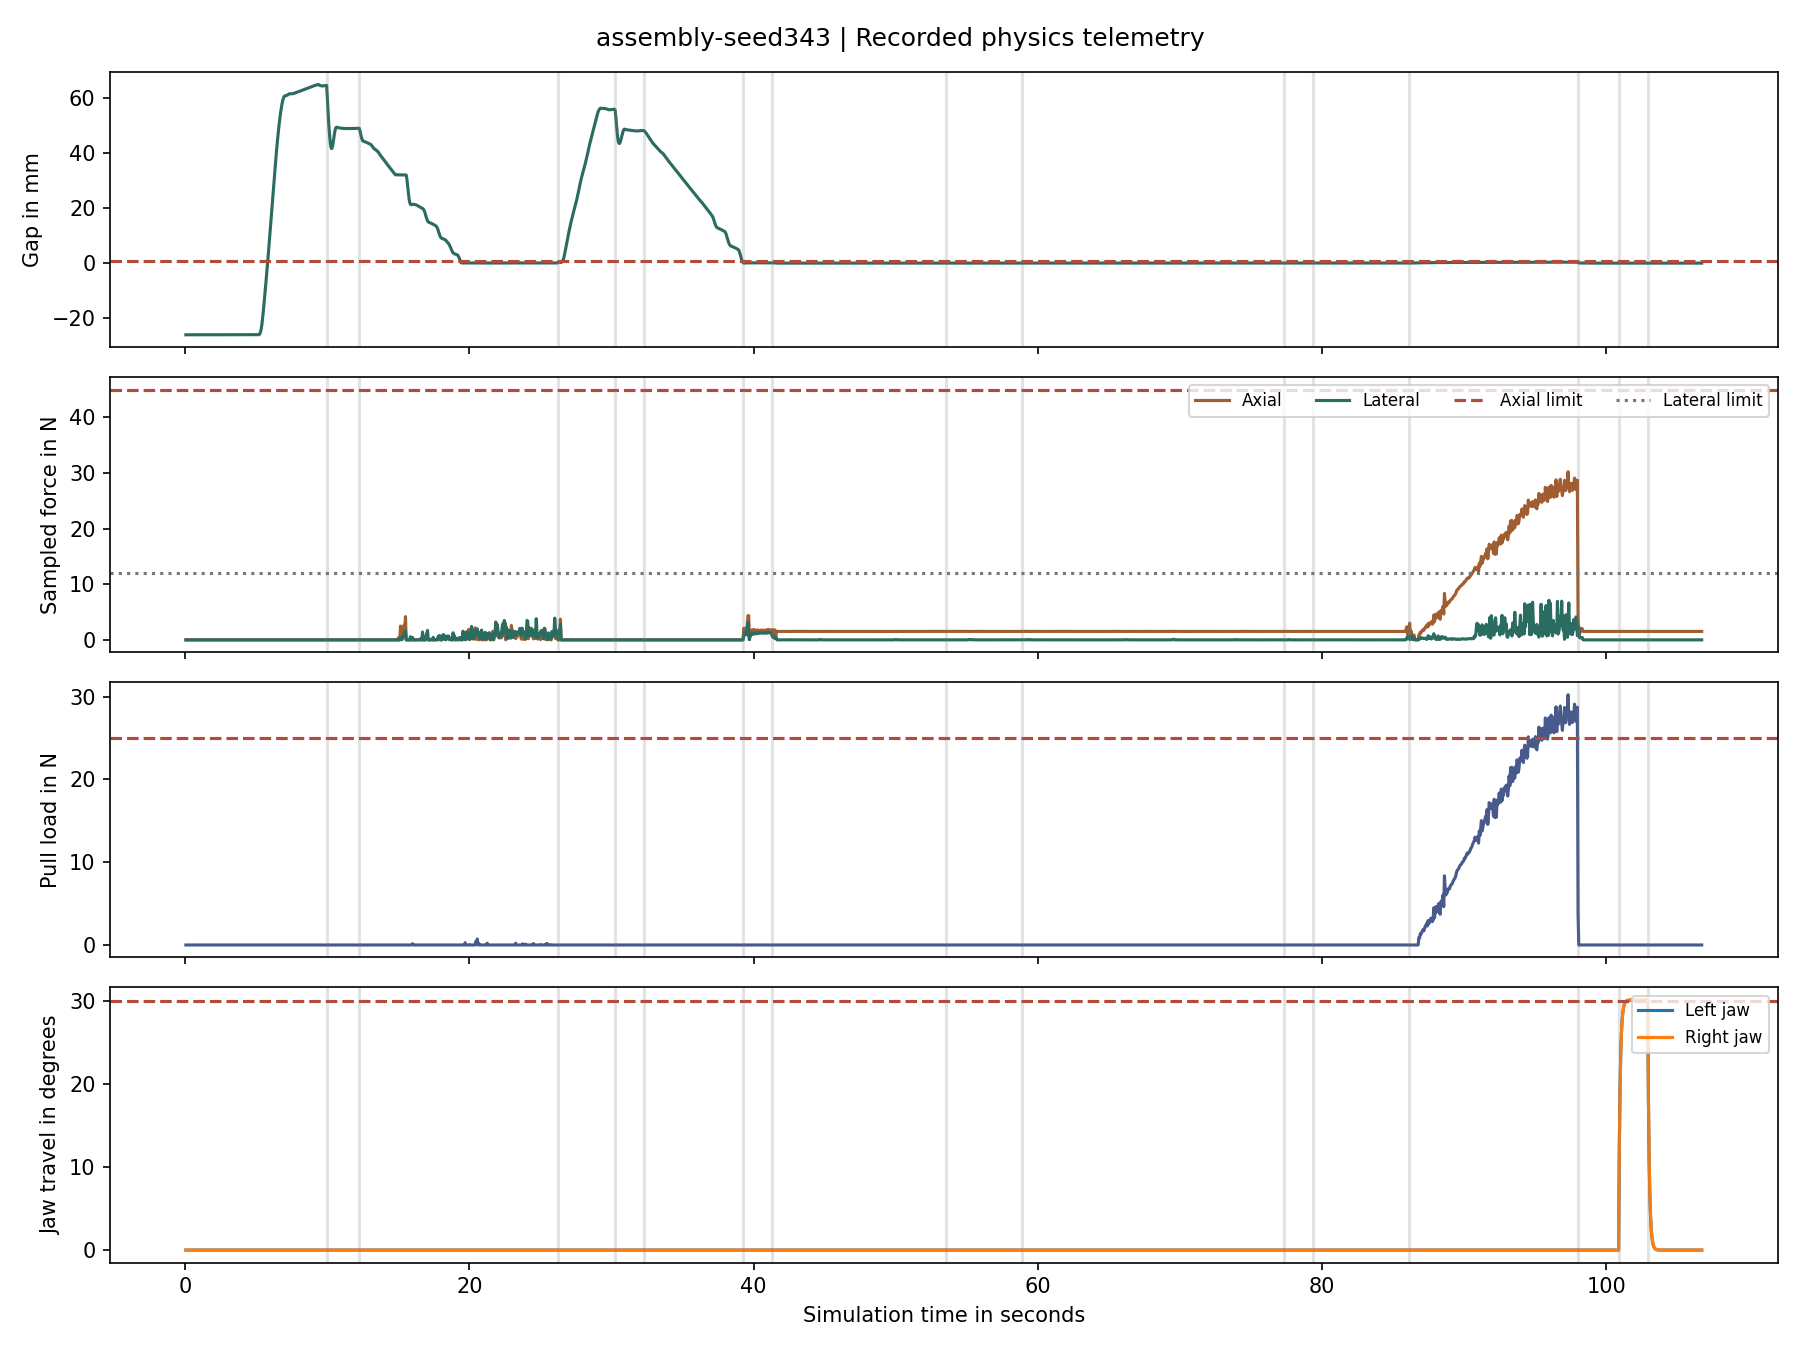
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.250000000000039,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 26.250000000000238,
      "phase": "retract",
      "reason": "Insertion timeout with unresolved gap"
    },
    {
      "time_s": 30.250000000000295,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 32.250000000000306,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 39.24999999999991,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 41.29999999999979,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 53.549999999999095,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 58.84999999999879,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 77.29999999999775,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 79.34999999999764,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 86.09999999999725,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 97.99999999999658,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 100.84999999999641,
      "phase": "motion_open",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 102.8999999999963,
      "phase": "motion_close",
      "reason": "Measured gripper joint travel is reaching 30 degrees"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": true,
    "seating": true,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": true,
    "observed_motion": true,
    "arms_released": true
  }
}
Recorded run: assembly-seed344
The run is ending in the Release phase. The independent verifier is reporting all implemented task checks passed.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
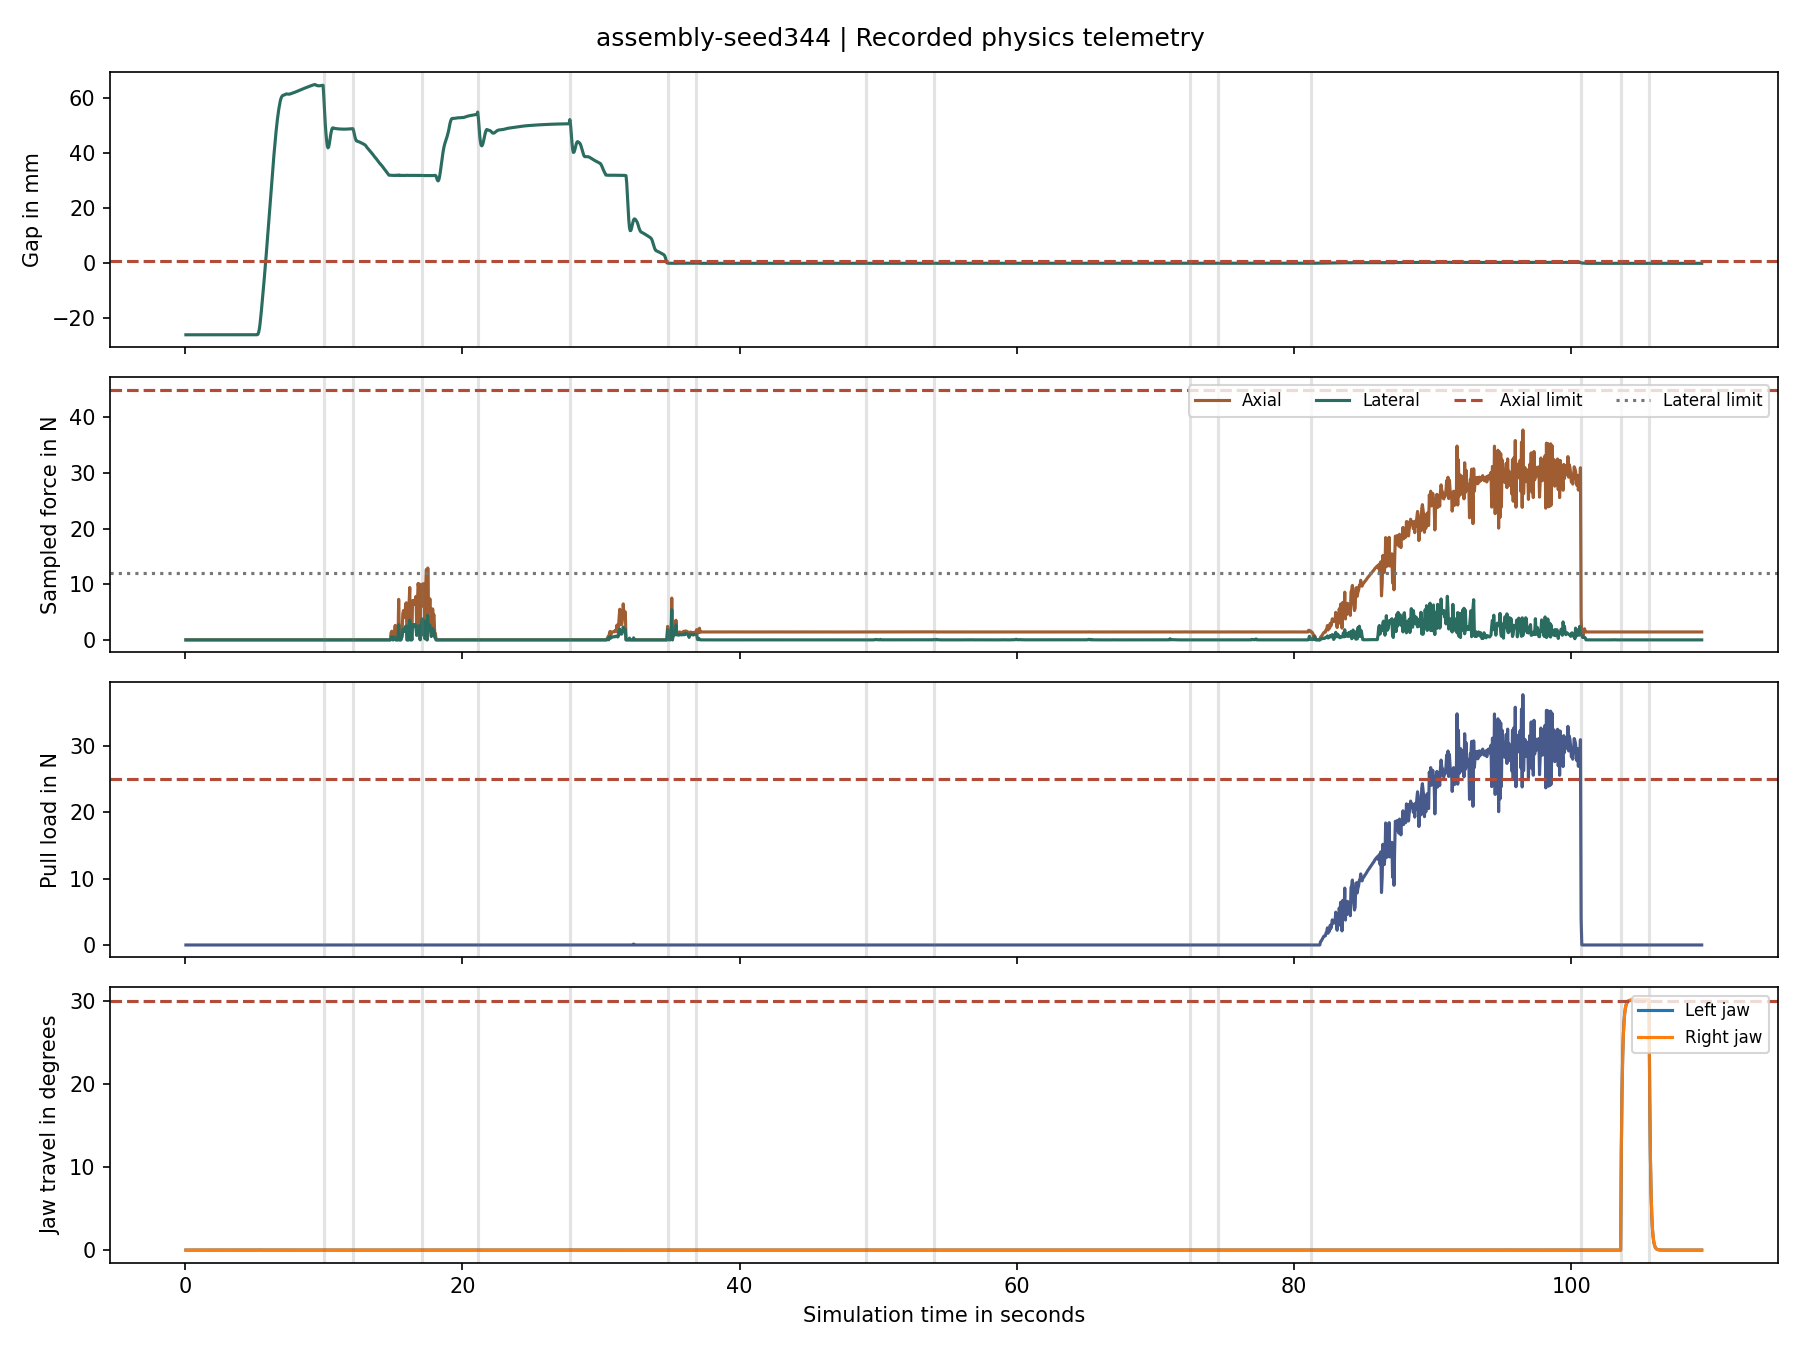
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.100000000000037,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 17.100000000000108,
      "phase": "retract",
      "reason": "Loaded insertion is showing less than 0.5 mm progress in one second"
    },
    {
      "time_s": 21.100000000000165,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 27.75000000000026,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 34.80000000000016,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 36.850000000000044,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 49.09999999999935,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 54.049999999999066,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 72.44999999999803,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 74.49999999999791,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 81.24999999999753,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 100.69999999999642,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 103.54999999999626,
      "phase": "motion_open",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 105.59999999999614,
      "phase": "motion_close",
      "reason": "Measured gripper joint travel is reaching 30 degrees"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": true,
    "seating": true,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": true,
    "observed_motion": true,
    "arms_released": true
  }
}
Recorded run: assembly-seed345
The run is ending in the Safe stop phase. The independent verifier is reporting complete_assembly_sequence, seating, pin_engagement, sustained_pull, observed_motion, arms_released.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
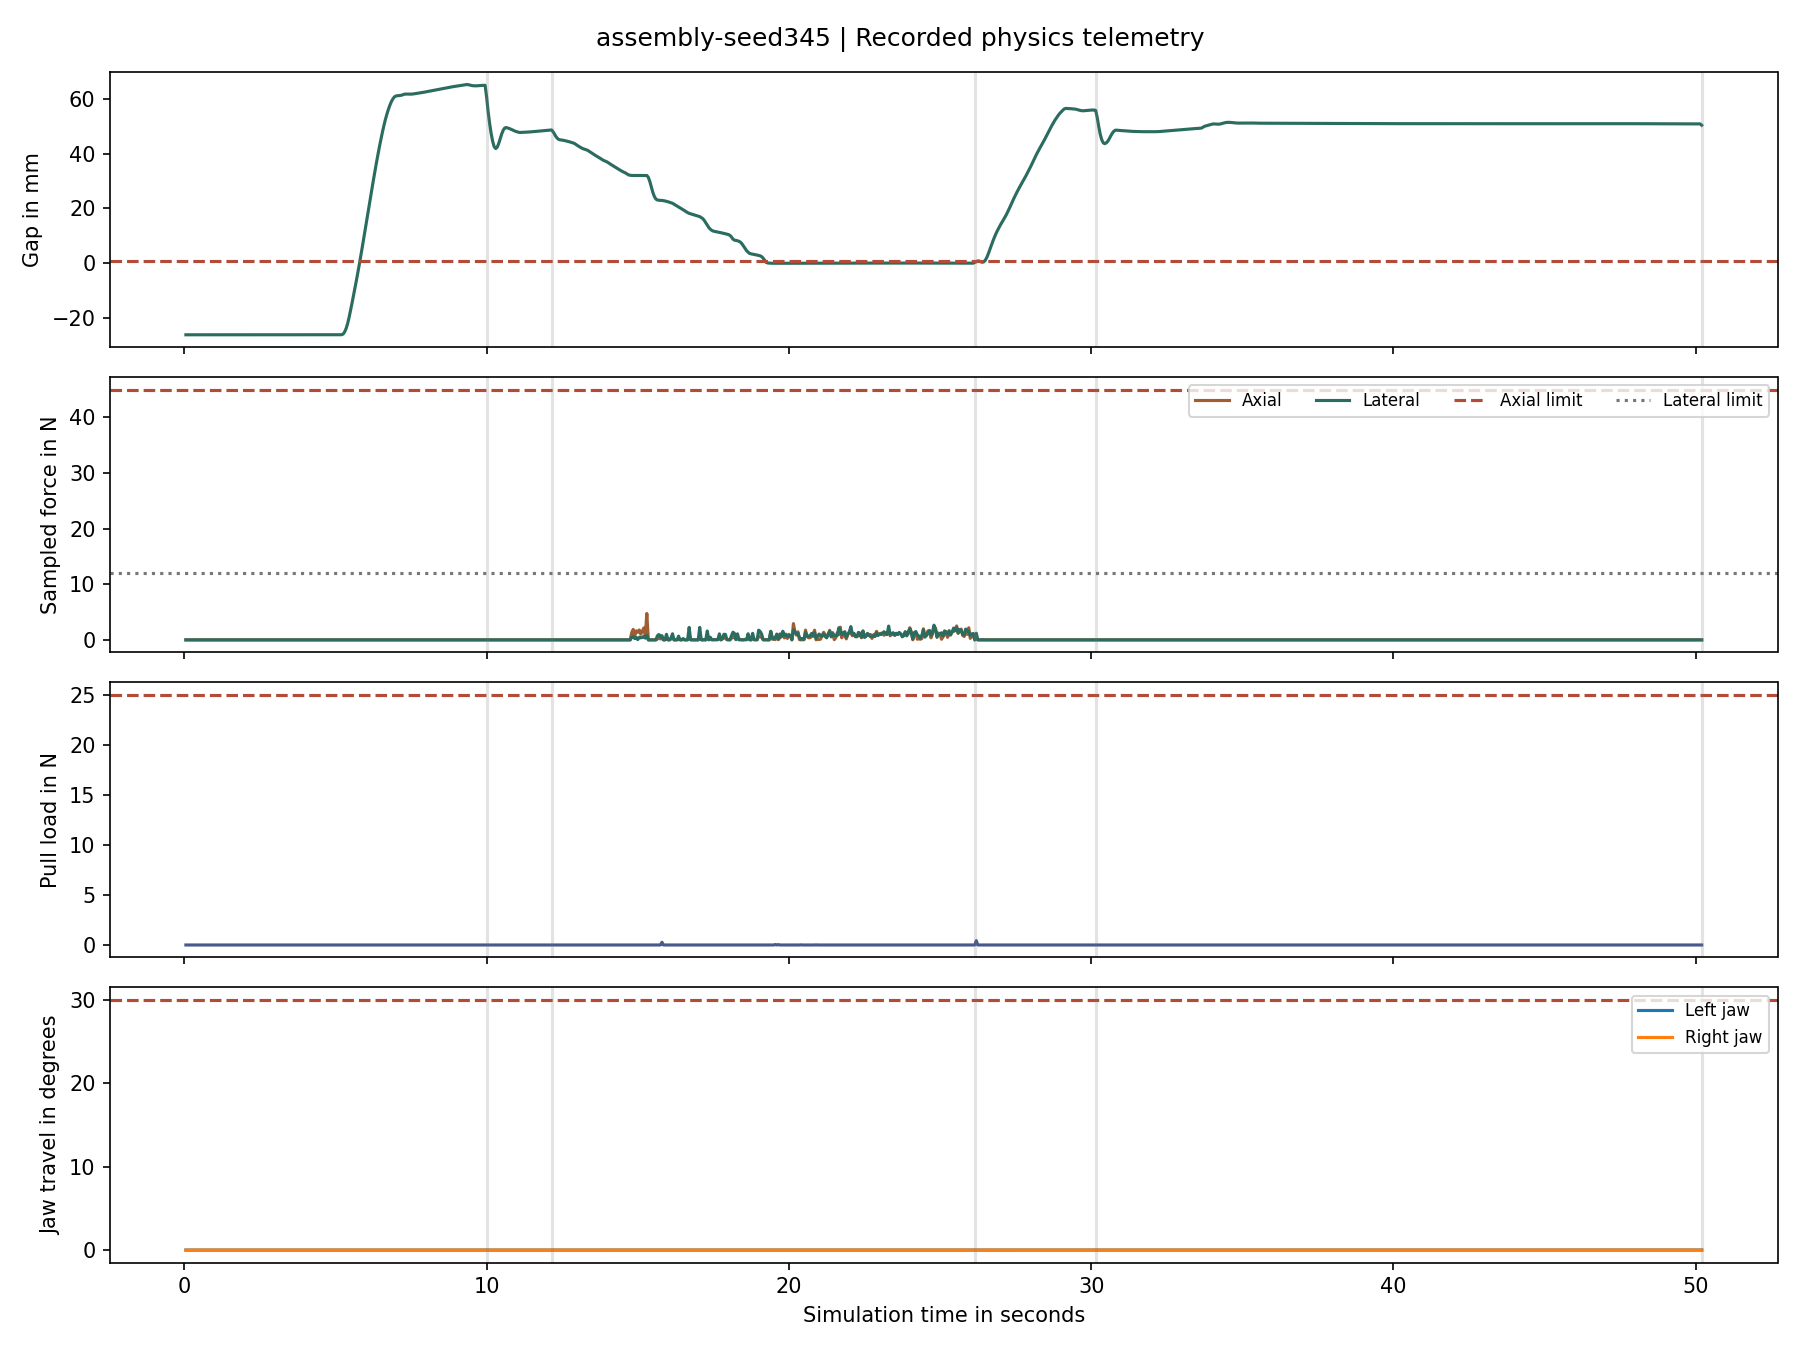
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.150000000000038,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 26.150000000000237,
      "phase": "retract",
      "reason": "Insertion timeout with unresolved gap"
    },
    {
      "time_s": 30.150000000000293,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 50.199999999999285,
      "phase": "safe_stop",
      "reason": "Alignment timeout"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": false,
    "seating": false,
    "pin_engagement": false,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": false,
    "observed_motion": false,
    "arms_released": false
  }
}
Recorded run: assembly-seed346
The run is ending in the Release phase. The independent verifier is reporting all implemented task checks passed.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
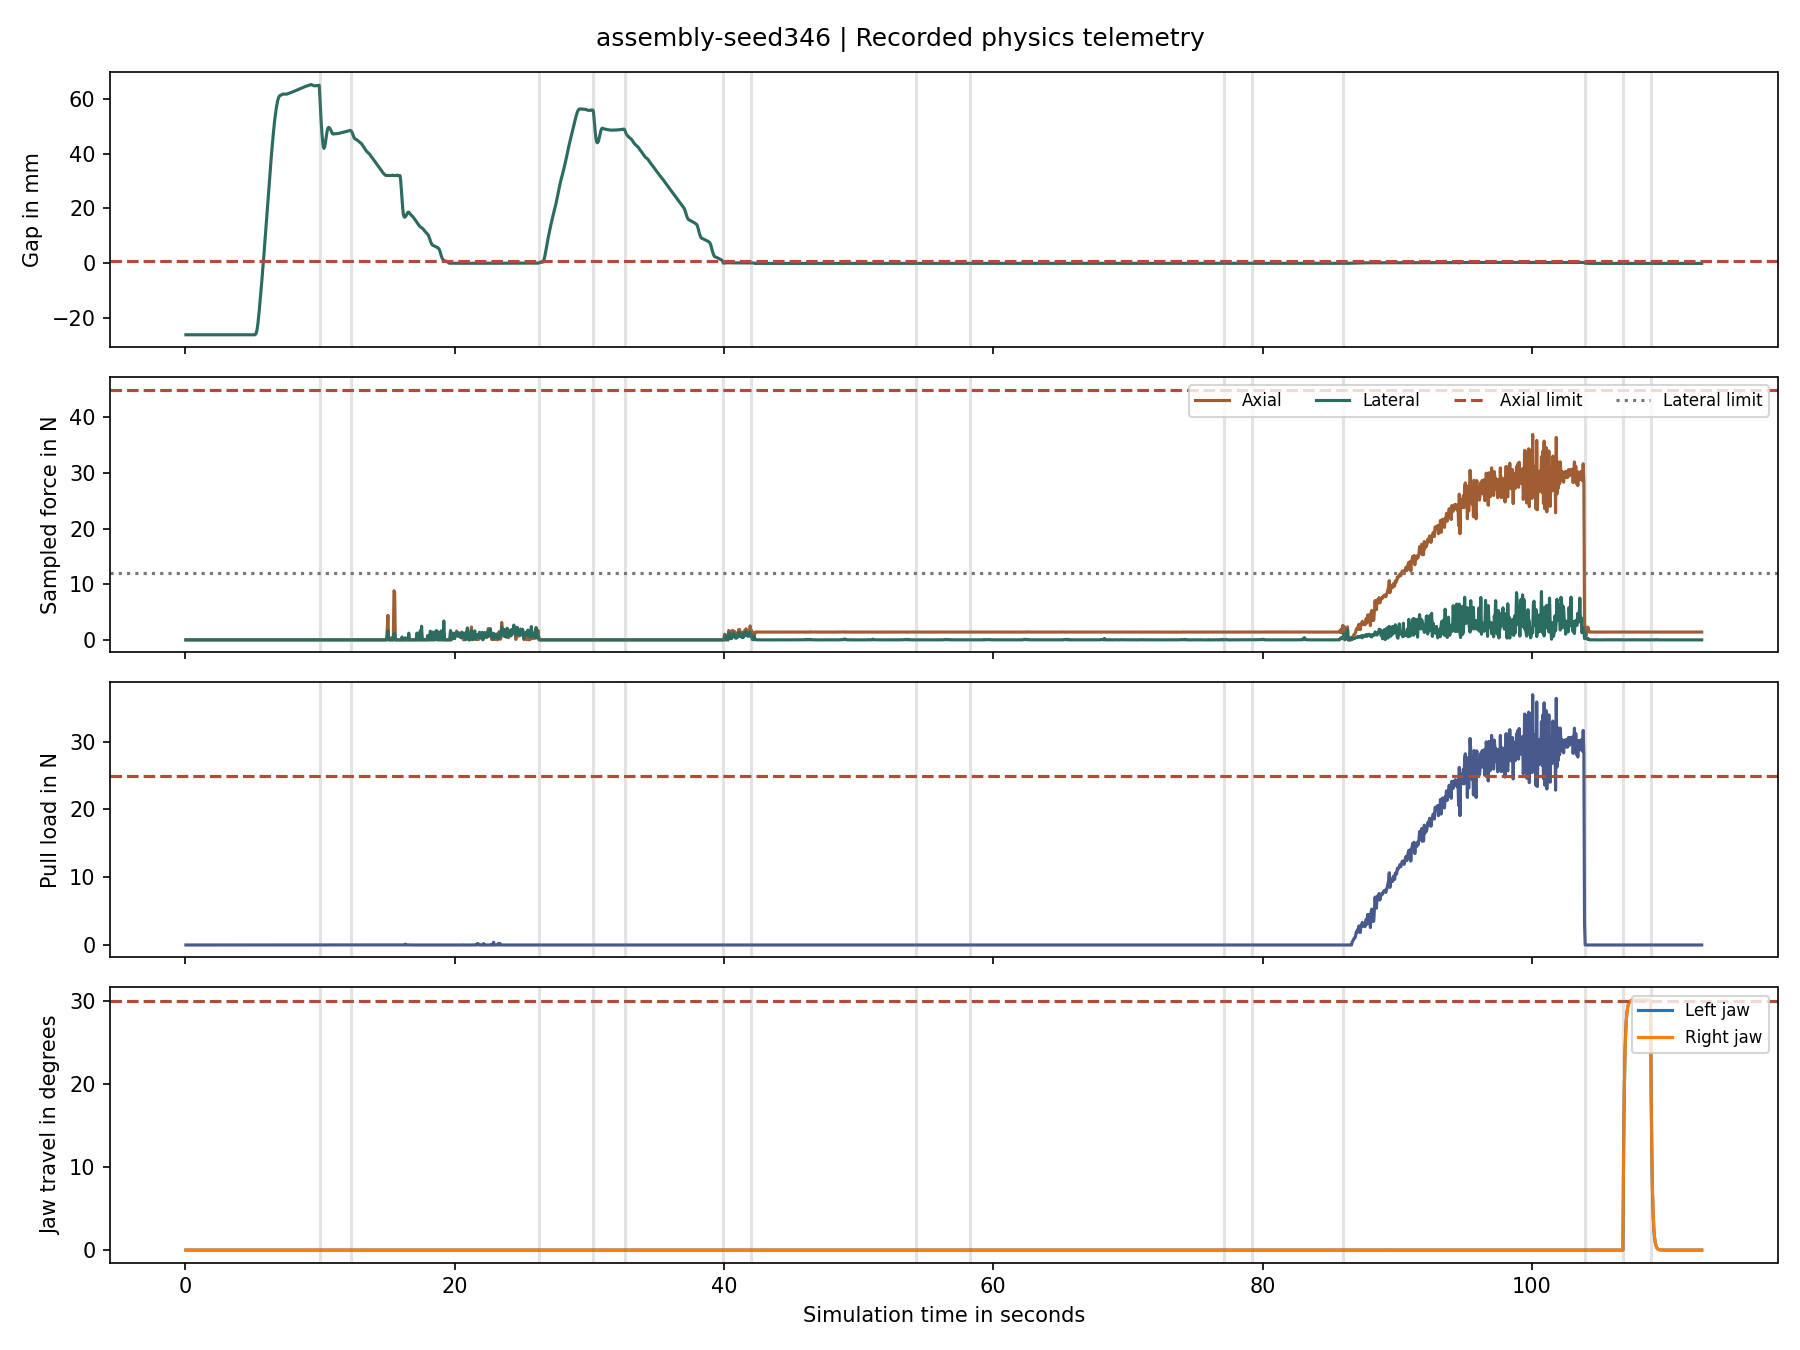
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.30000000000004,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 26.30000000000024,
      "phase": "retract",
      "reason": "Insertion timeout with unresolved gap"
    },
    {
      "time_s": 30.300000000000296,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 32.65000000000028,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 39.94999999999987,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 41.99999999999975,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 54.249999999999055,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 58.299999999998825,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 77.14999999999776,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 79.19999999999764,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 85.94999999999726,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 103.89999999999624,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 106.74999999999608,
      "phase": "motion_open",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 108.79999999999596,
      "phase": "motion_close",
      "reason": "Measured gripper joint travel is reaching 30 degrees"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": true,
    "seating": true,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": true,
    "observed_motion": true,
    "arms_released": true
  }
}
Recorded run: assembly-seed347
The run is ending in the Release phase. The independent verifier is reporting all implemented task checks passed.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
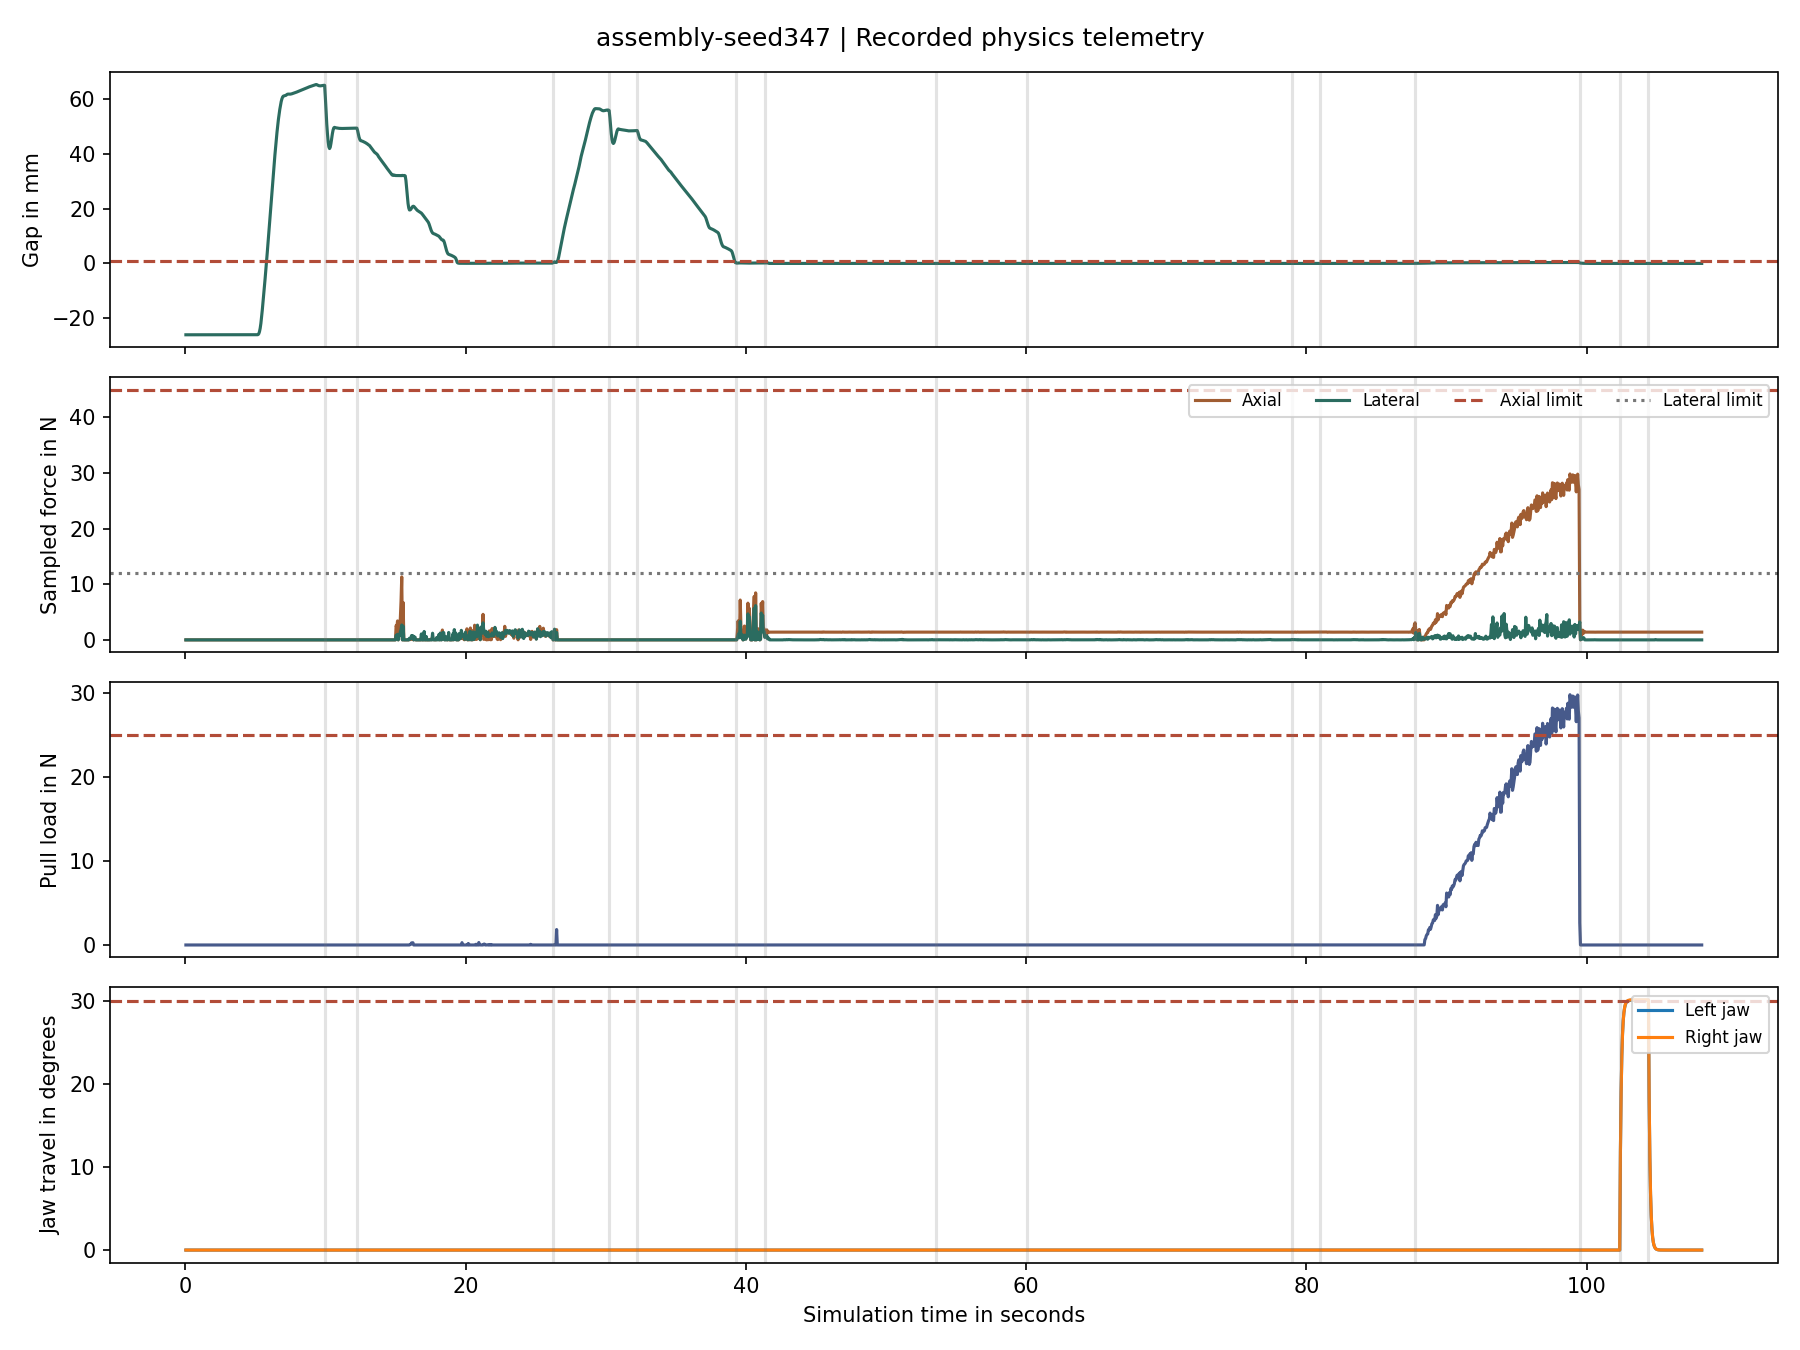
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.250000000000039,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 26.250000000000238,
      "phase": "retract",
      "reason": "Insertion timeout with unresolved gap"
    },
    {
      "time_s": 30.250000000000295,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 32.250000000000306,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 39.299999999999905,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 41.34999999999979,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 53.59999999999909,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 60.049999999998725,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 78.94999999999766,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 80.99999999999754,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 87.74999999999716,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 99.49999999999649,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 102.34999999999633,
      "phase": "motion_open",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 104.39999999999621,
      "phase": "motion_close",
      "reason": "Measured gripper joint travel is reaching 30 degrees"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": true,
    "seating": true,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": true,
    "observed_motion": true,
    "arms_released": true
  }
}
Recorded run: assembly-seed348
The run is ending in the Safe stop phase. The independent verifier is reporting complete_assembly_sequence, seating, pin_engagement, sustained_pull, observed_motion, arms_released.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
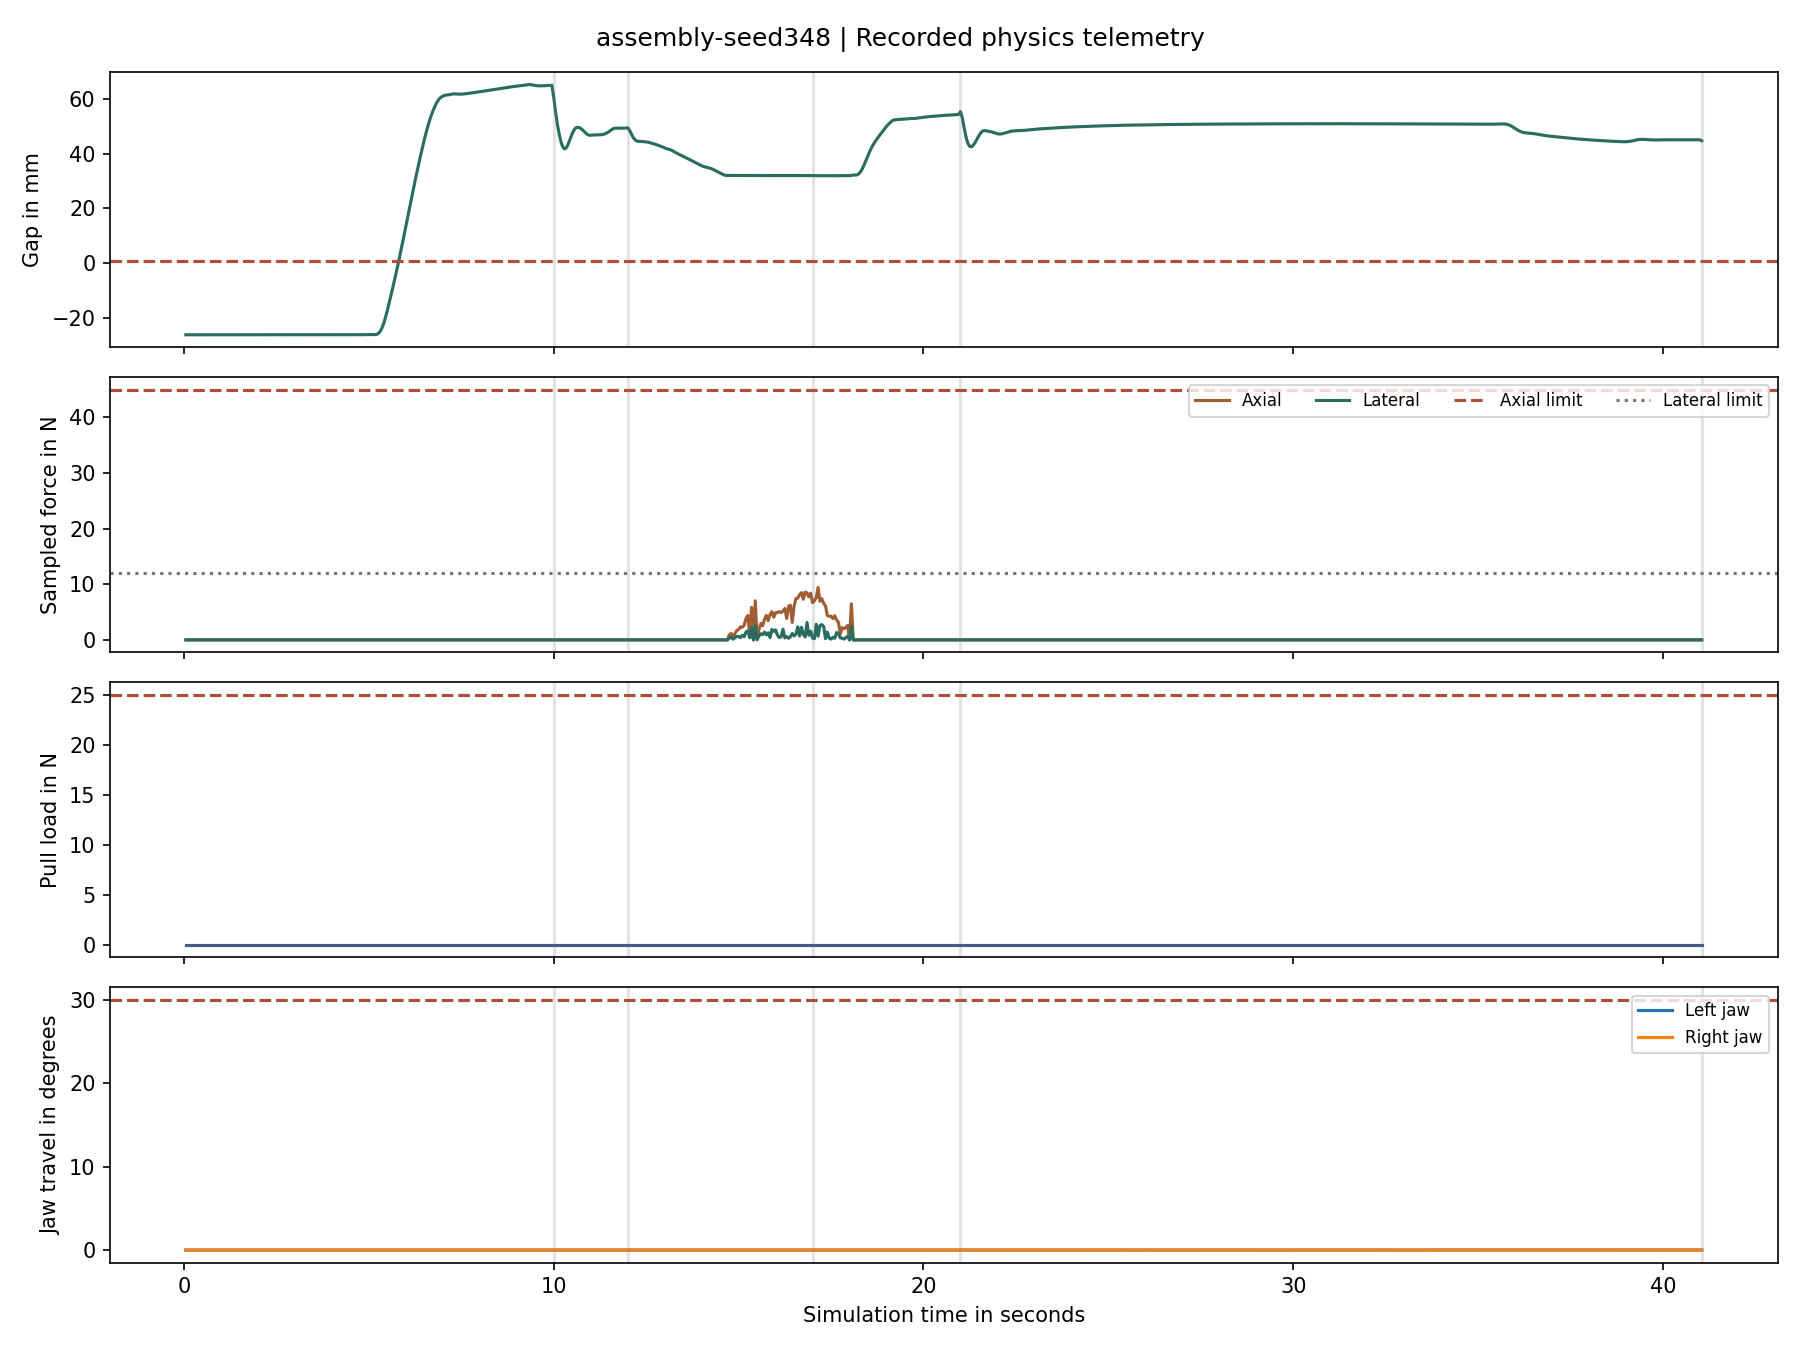
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.000000000000036,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 17.000000000000107,
      "phase": "retract",
      "reason": "Loaded insertion is showing less than 0.5 mm progress in one second"
    },
    {
      "time_s": 21.000000000000163,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 41.049999999999805,
      "phase": "safe_stop",
      "reason": "Alignment timeout"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": false,
    "seating": false,
    "pin_engagement": false,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": false,
    "observed_motion": false,
    "arms_released": false
  }
}
Recorded run: assembly-seed400
The run is ending in the Release phase. The independent verifier is reporting all implemented task checks passed.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
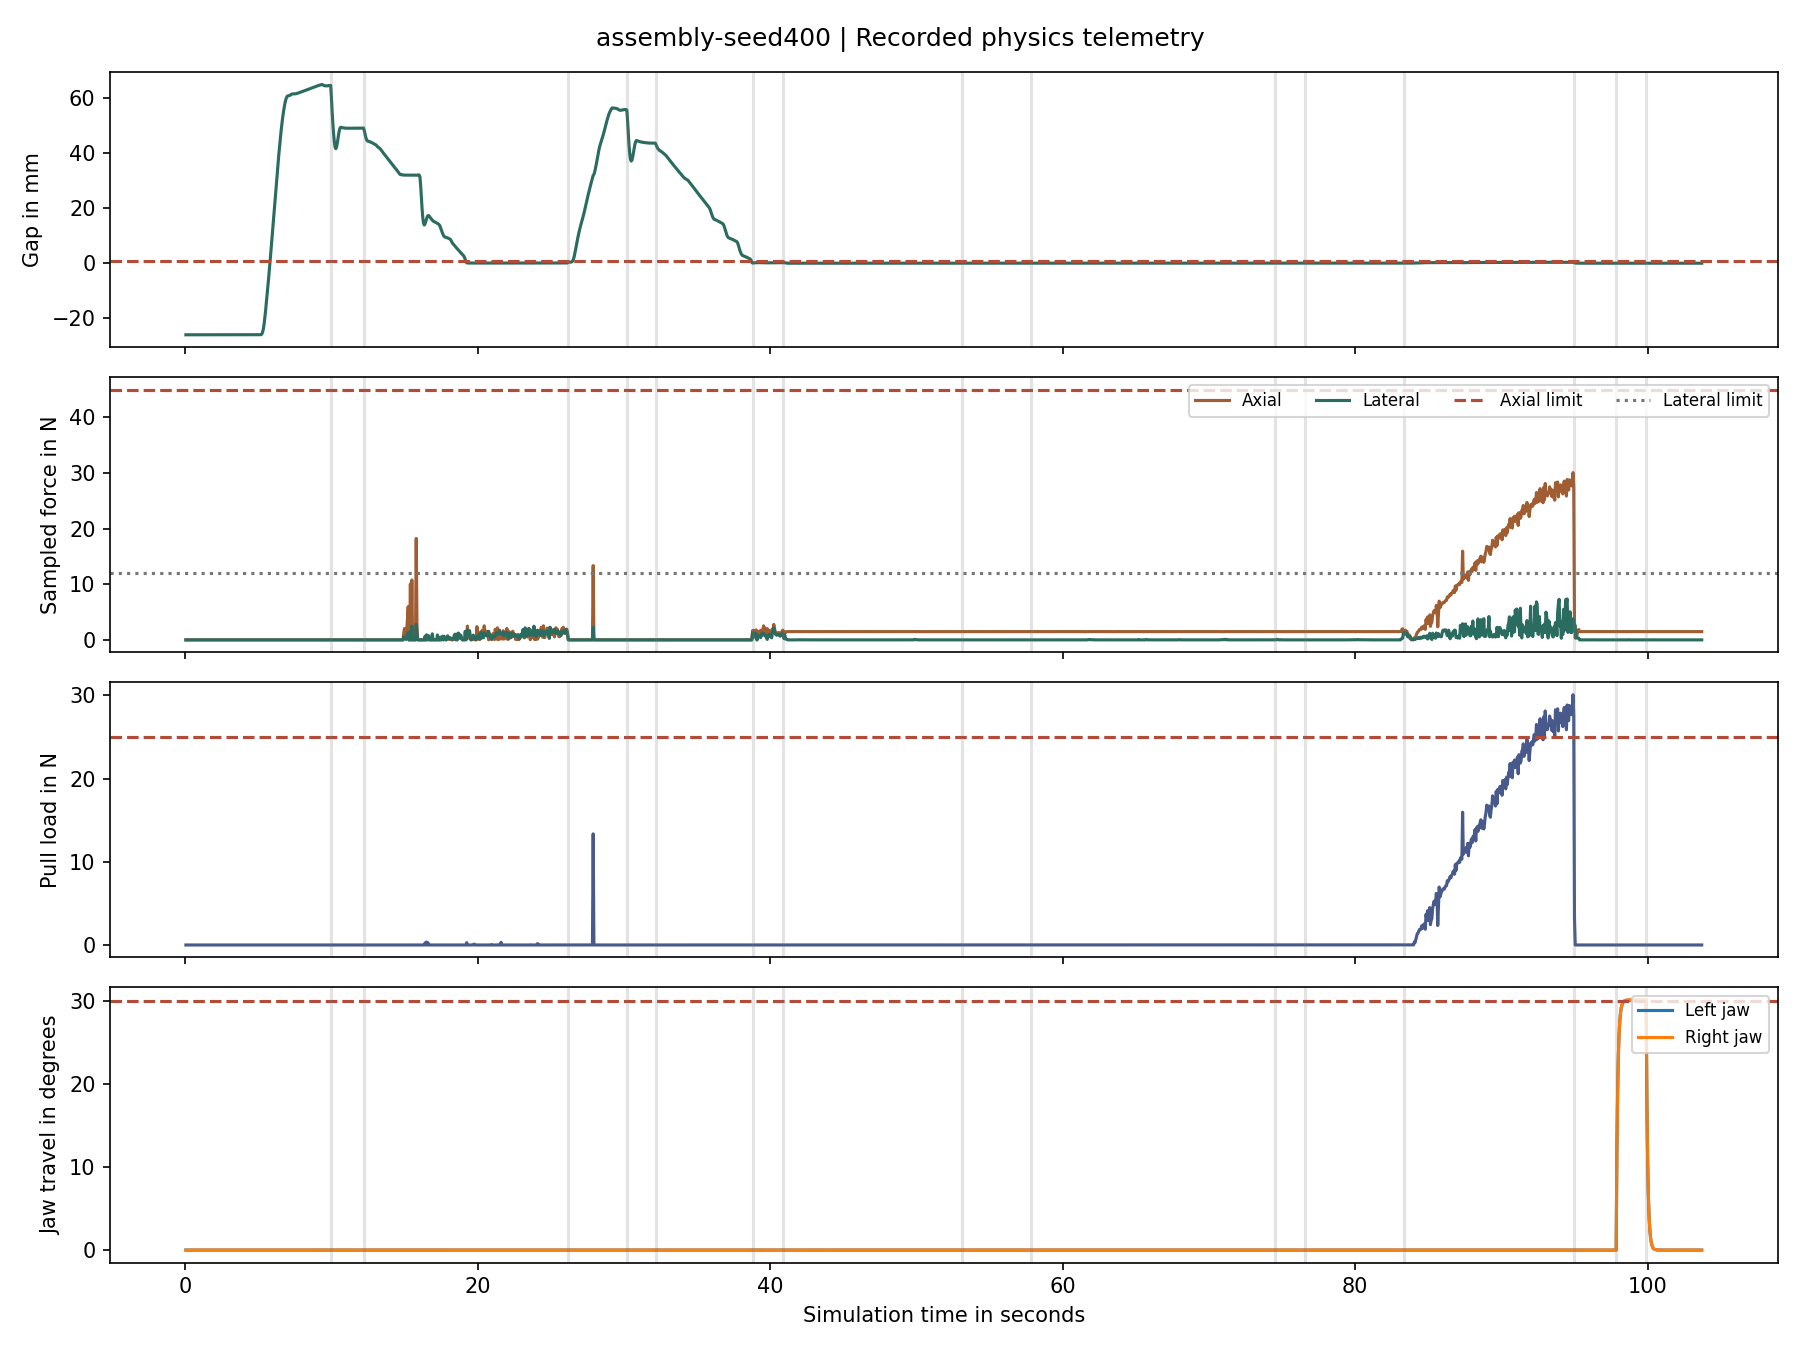
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.200000000000038,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 26.200000000000237,
      "phase": "retract",
      "reason": "Insertion timeout with unresolved gap"
    },
    {
      "time_s": 30.200000000000294,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 32.20000000000031,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 38.79999999999993,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 40.84999999999982,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 53.09999999999912,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 57.84999999999885,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 74.54999999999791,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 76.59999999999779,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 83.34999999999741,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 94.99999999999675,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 97.84999999999658,
      "phase": "motion_open",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 99.89999999999647,
      "phase": "motion_close",
      "reason": "Measured gripper joint travel is reaching 30 degrees"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": true,
    "seating": true,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": true,
    "observed_motion": true,
    "arms_released": true
  }
}
Recorded run: assembly-seed401
The run is ending in the Release phase. The independent verifier is reporting all implemented task checks passed.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
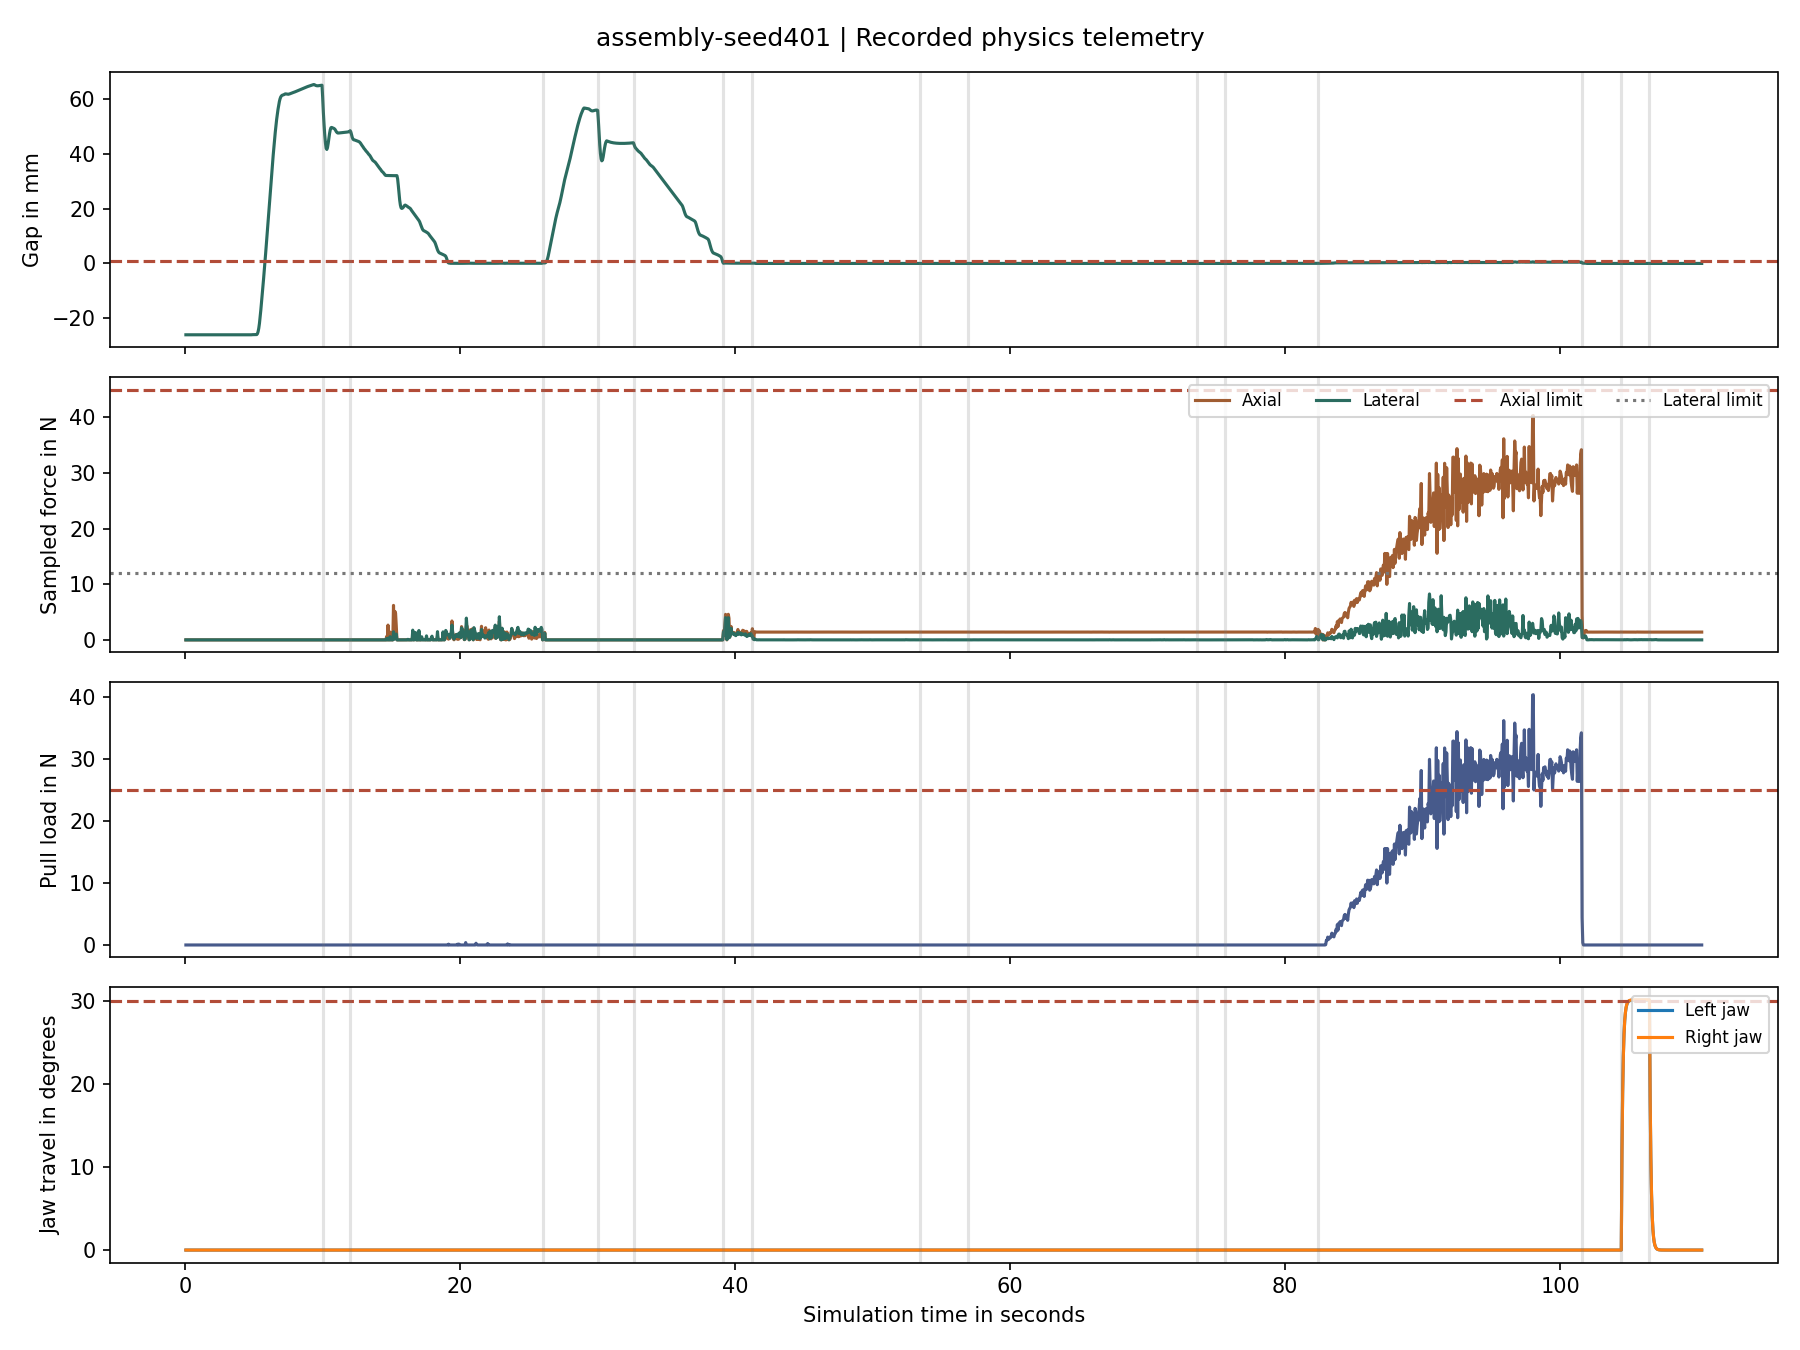
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.000000000000036,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 26.000000000000234,
      "phase": "retract",
      "reason": "Insertion timeout with unresolved gap"
    },
    {
      "time_s": 30.00000000000029,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 32.65000000000028,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 39.14999999999991,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 41.1999999999998,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 53.4499999999991,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 56.9499999999989,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 73.59999999999796,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 75.64999999999785,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 82.39999999999746,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 101.59999999999637,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 104.44999999999621,
      "phase": "motion_open",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 106.49999999999609,
      "phase": "motion_close",
      "reason": "Measured gripper joint travel is reaching 30 degrees"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": true,
    "seating": true,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": true,
    "observed_motion": true,
    "arms_released": true
  }
}
Recorded run: assembly-seed402
The run is ending in the Release phase. The independent verifier is reporting all implemented task checks passed.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
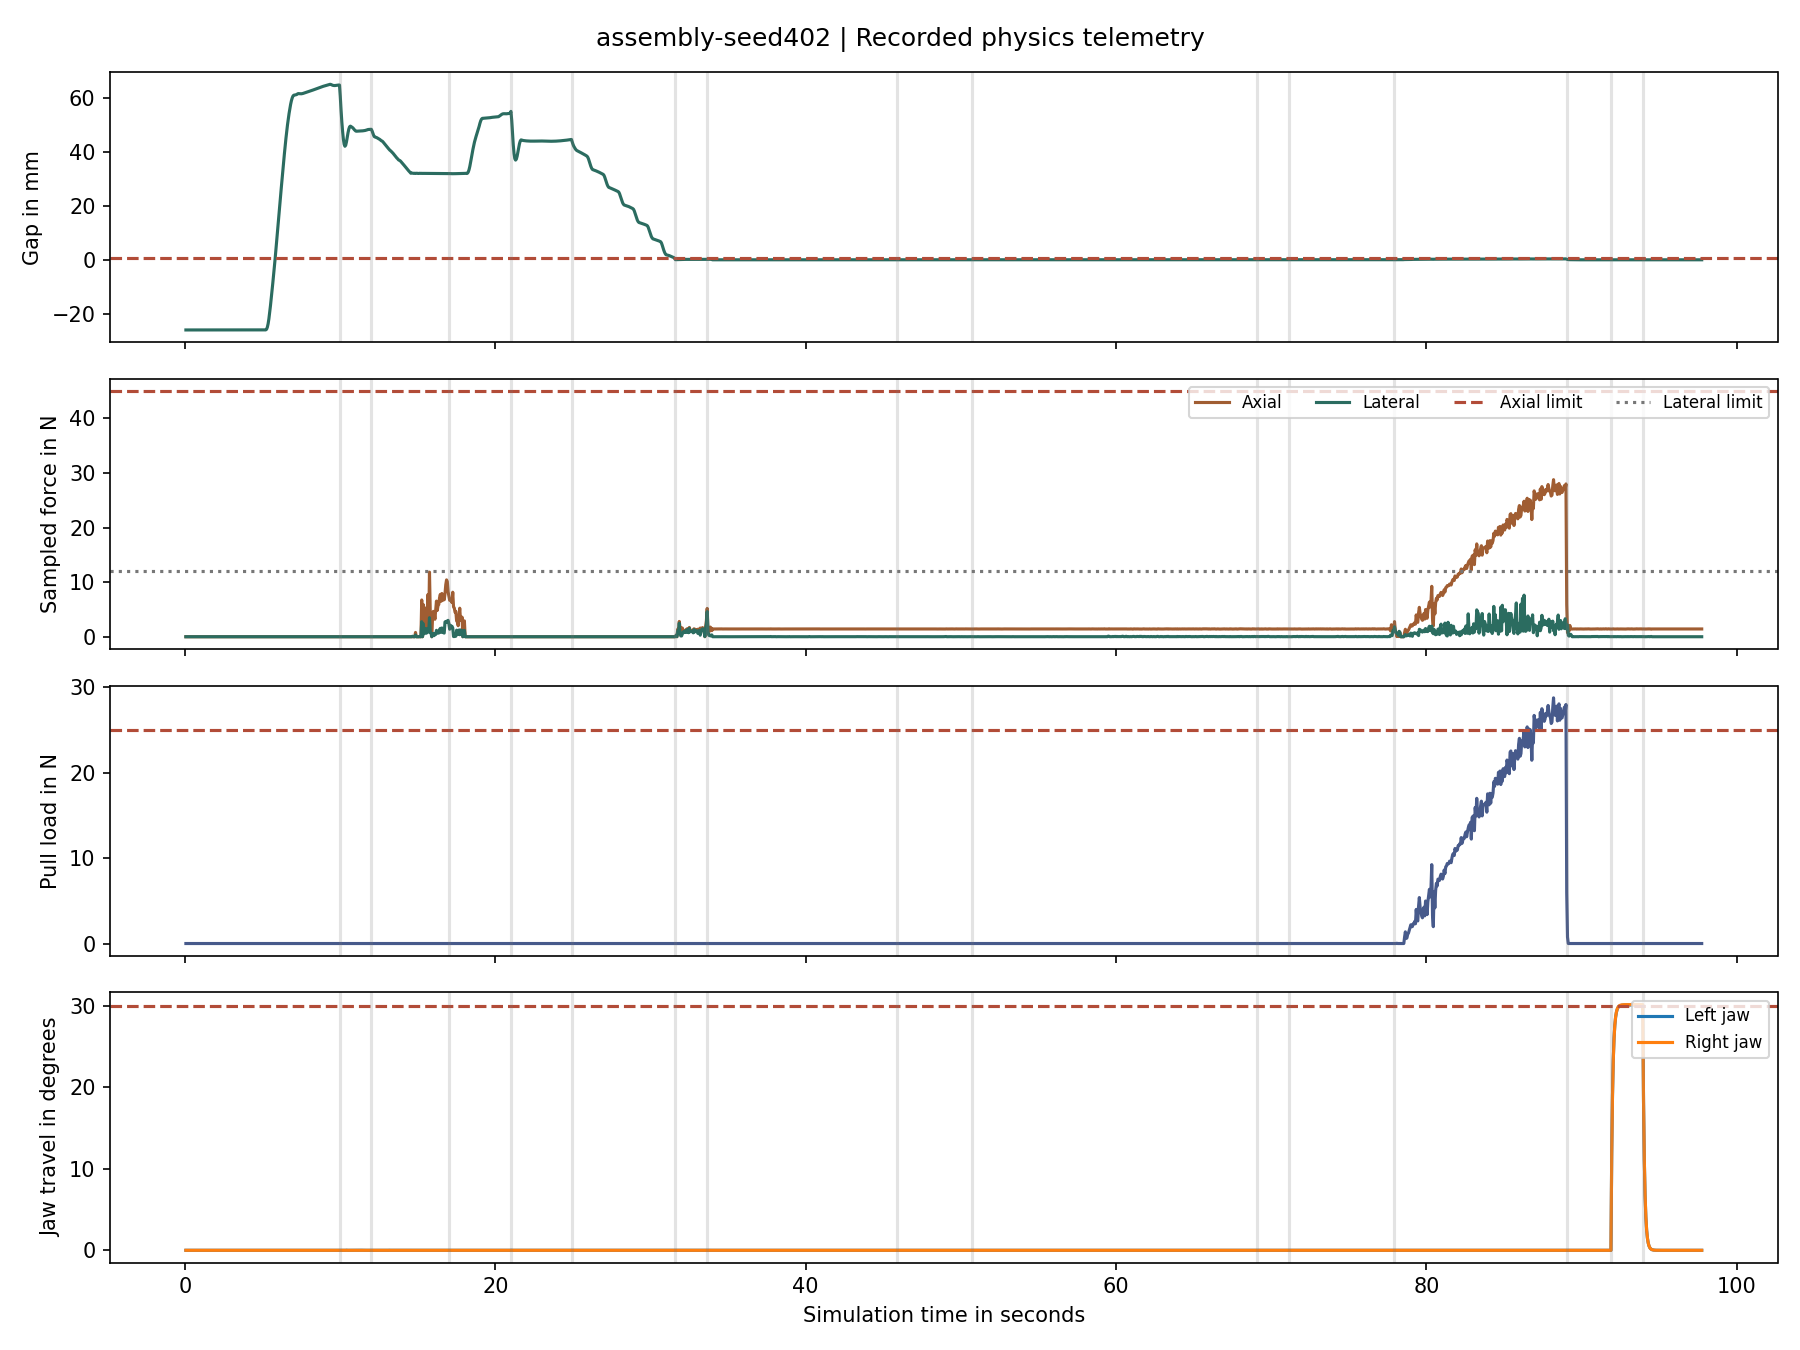
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.000000000000036,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 17.000000000000107,
      "phase": "retract",
      "reason": "Loaded insertion is showing less than 0.5 mm progress in one second"
    },
    {
      "time_s": 21.000000000000163,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 24.95000000000022,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 31.600000000000314,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 33.650000000000226,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 45.89999999999953,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 50.69999999999926,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 69.09999999999822,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 71.1499999999981,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 77.89999999999772,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 89.04999999999708,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 91.89999999999692,
      "phase": "motion_open",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 93.9499999999968,
      "phase": "motion_close",
      "reason": "Measured gripper joint travel is reaching 30 degrees"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": true,
    "seating": true,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": true,
    "observed_motion": true,
    "arms_released": true
  }
}
Recorded run: assembly-seed403
The run is ending in the Release phase. The independent verifier is reporting all implemented task checks passed.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
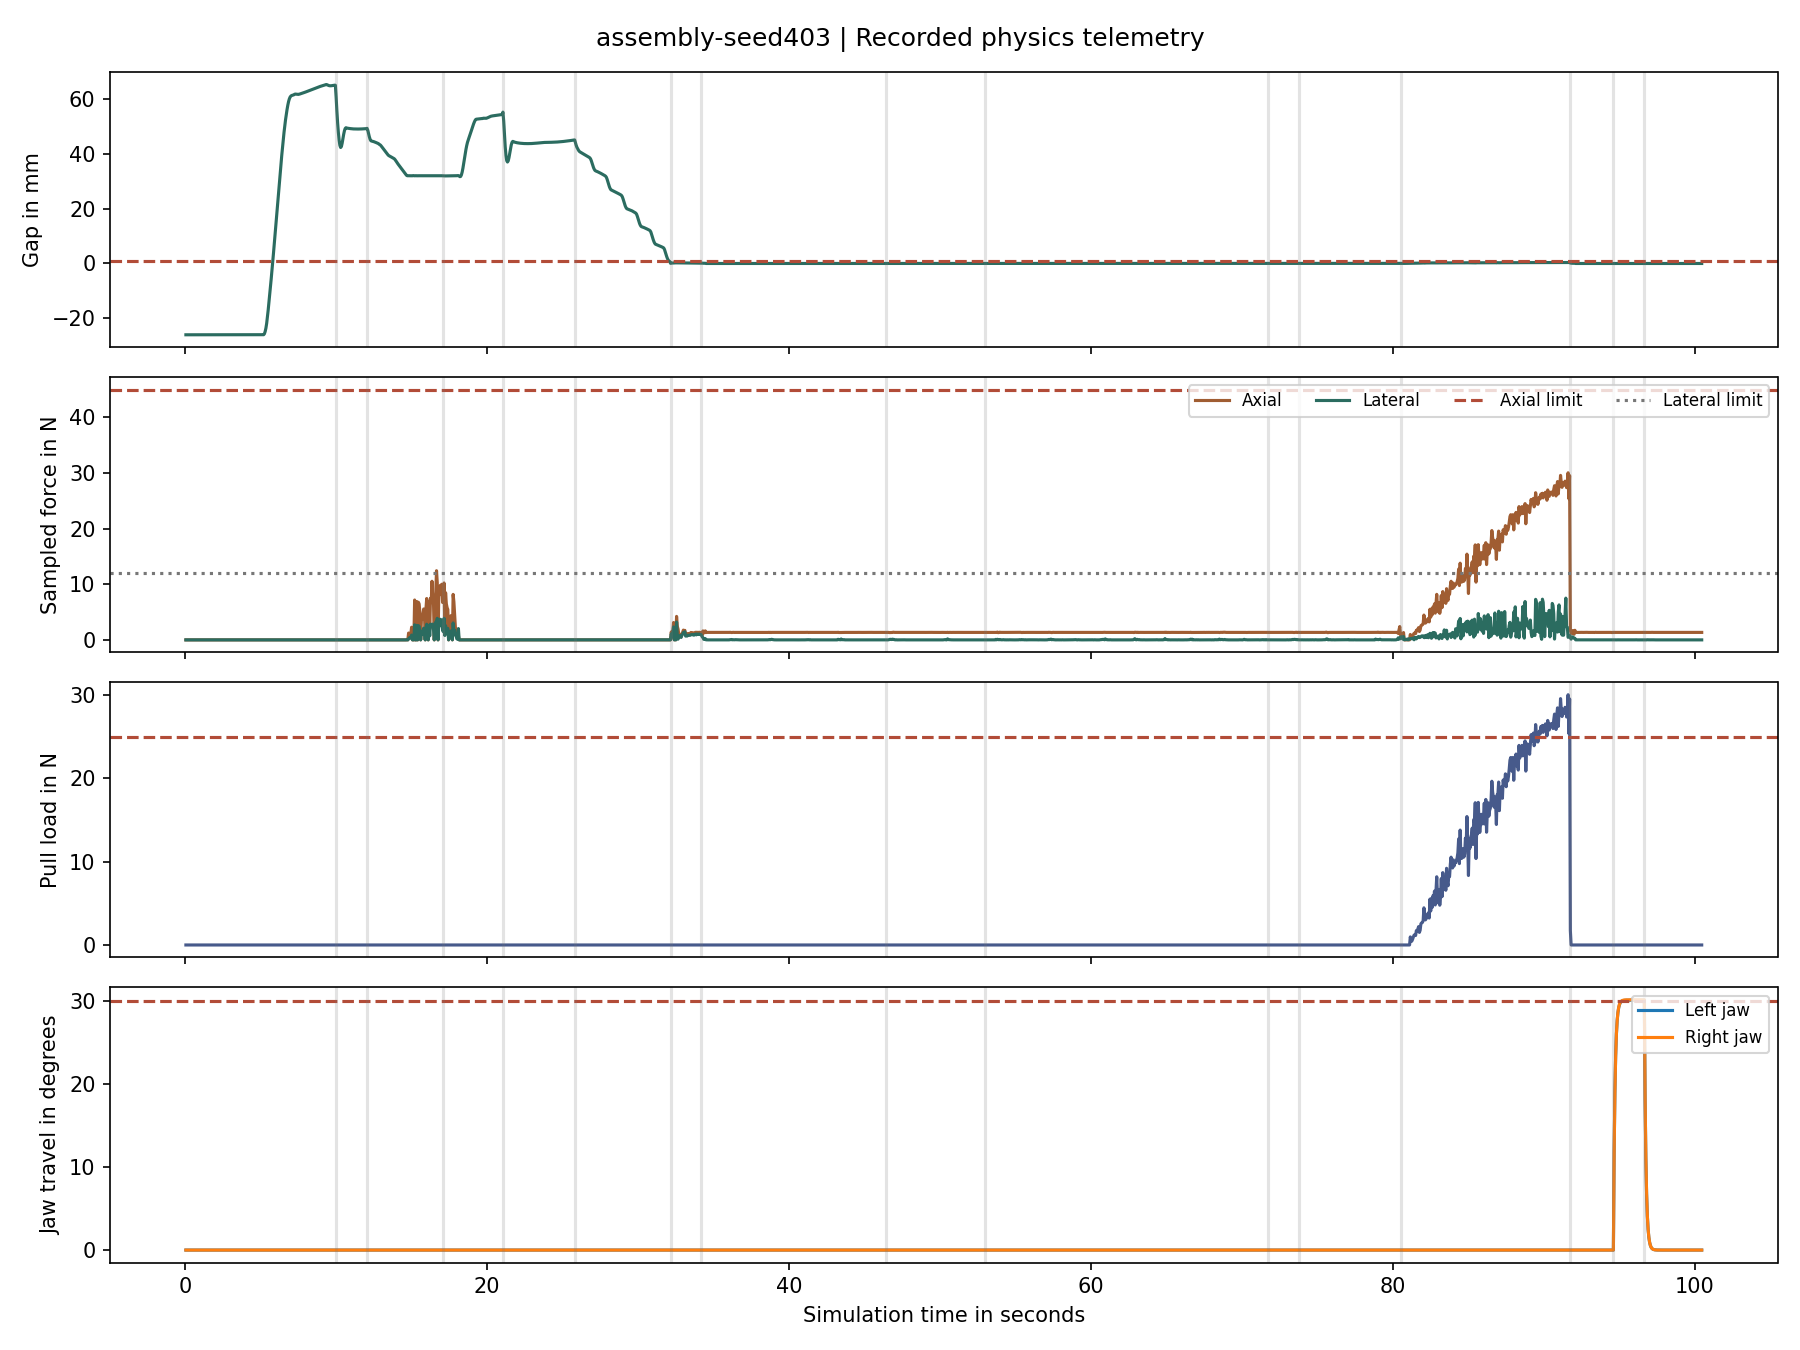
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.050000000000036,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 17.050000000000107,
      "phase": "retract",
      "reason": "Loaded insertion is showing less than 0.5 mm progress in one second"
    },
    {
      "time_s": 21.050000000000164,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 25.850000000000232,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 32.15000000000031,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 34.200000000000195,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 46.4499999999995,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 52.999999999999126,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 71.69999999999807,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 73.74999999999795,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 80.49999999999757,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 91.74999999999693,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 94.59999999999677,
      "phase": "motion_open",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 96.64999999999665,
      "phase": "motion_close",
      "reason": "Measured gripper joint travel is reaching 30 degrees"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": true,
    "seating": true,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": true,
    "observed_motion": true,
    "arms_released": true
  }
}
Recorded run: cli-alignment345-v20
The run is ending in the Release phase. The independent verifier is reporting all implemented task checks passed.
The composite is showing three recorded cameras with measured telemetry labels. The original uninterrupted camera recording is following below.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
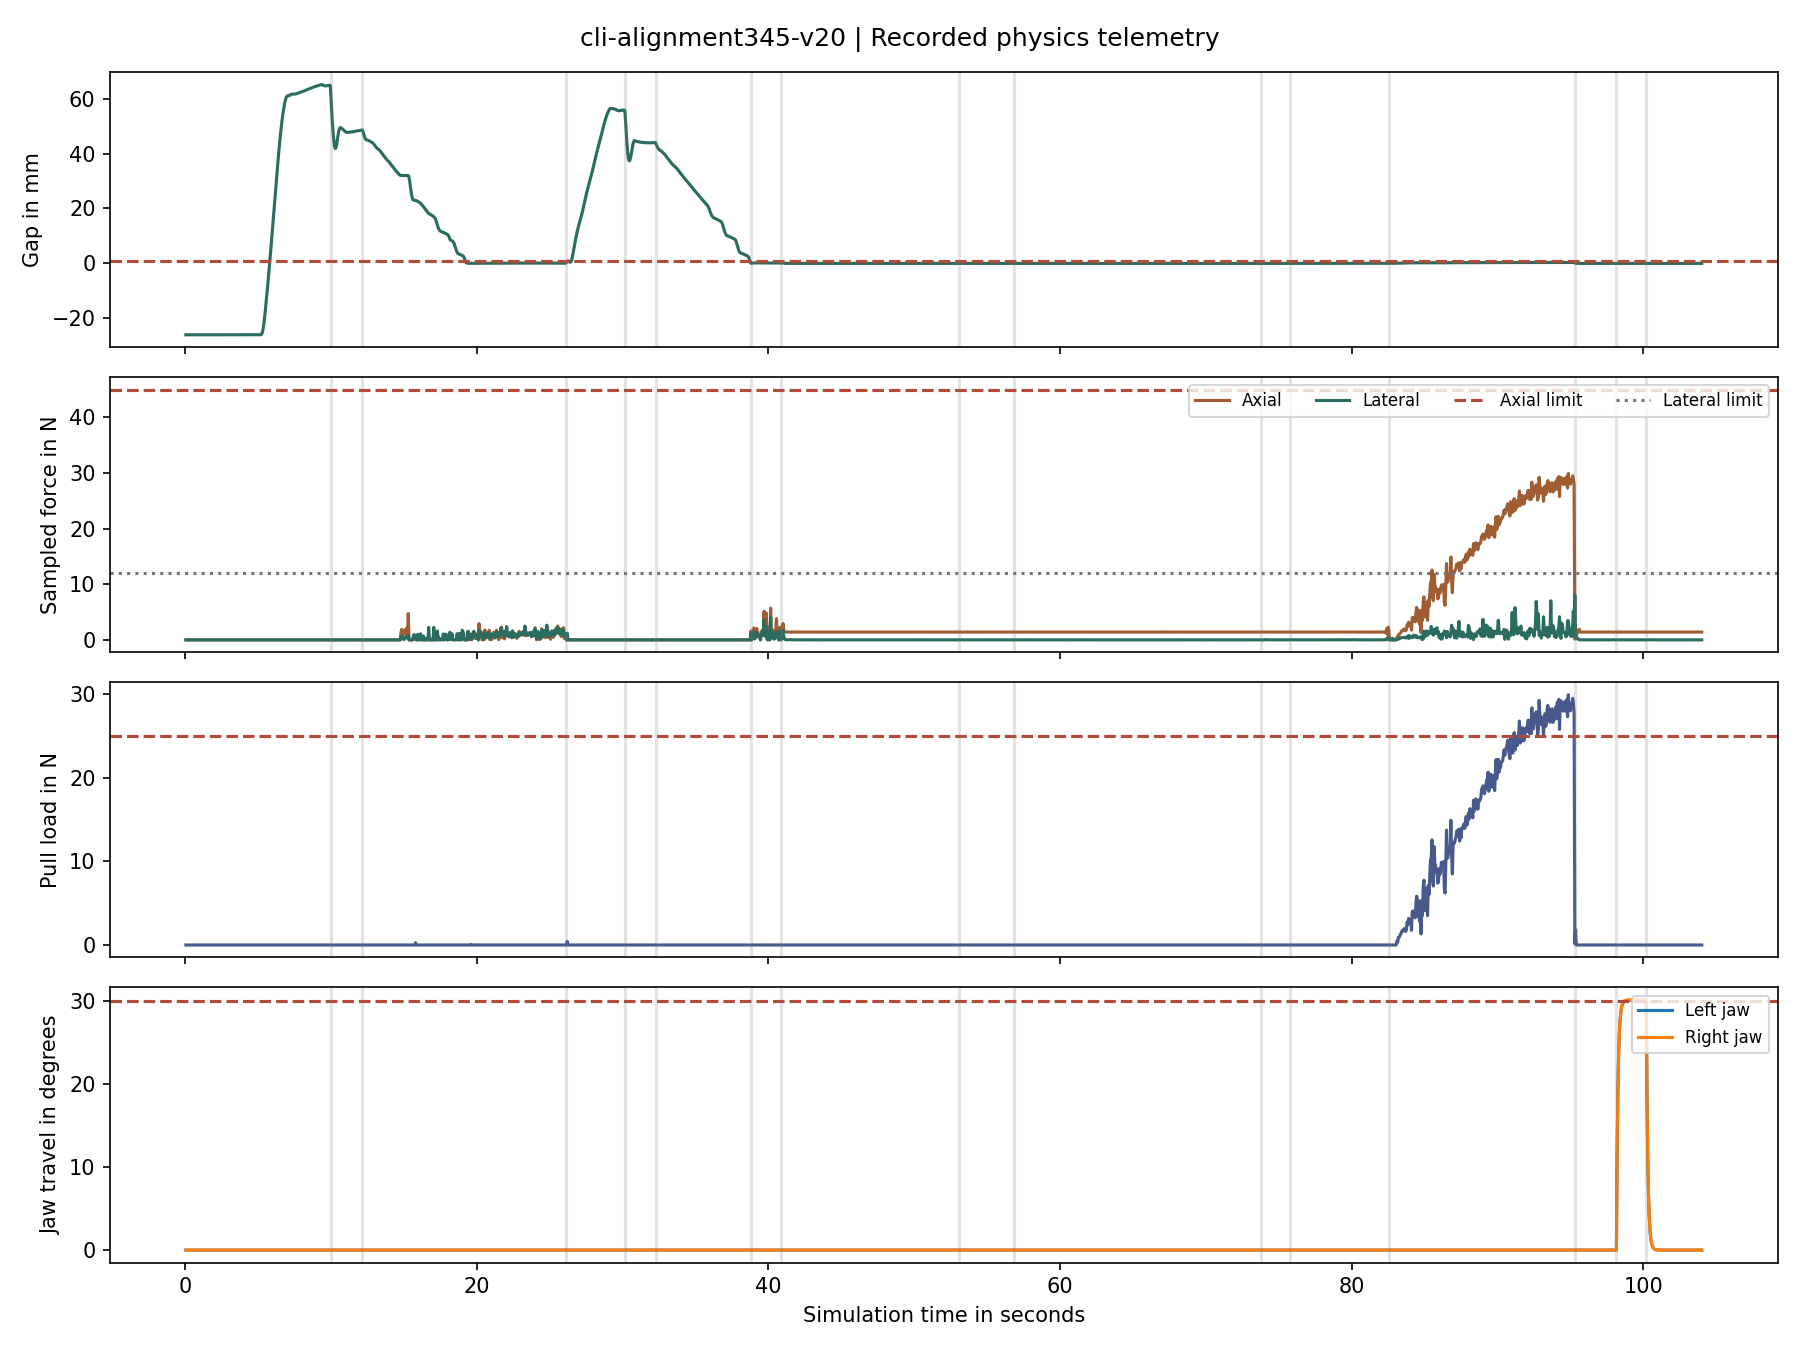
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.150000000000038,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 26.150000000000237,
      "phase": "retract",
      "reason": "Insertion timeout with unresolved gap"
    },
    {
      "time_s": 30.150000000000293,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 32.3000000000003,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 38.79999999999993,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 40.84999999999982,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 53.09999999999912,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 56.84999999999891,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 73.74999999999795,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 75.79999999999784,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 82.54999999999745,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 95.29999999999673,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 98.14999999999657,
      "phase": "motion_open",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 100.19999999999645,
      "phase": "motion_close",
      "reason": "Measured gripper joint travel is reaching 30 degrees"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": true,
    "seating": true,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": true,
    "observed_motion": true,
    "arms_released": true
  }
}
Recorded run: cli-alignment348-v20
The run is ending in the Release phase. The independent verifier is reporting all implemented task checks passed.
The composite is showing three recorded cameras with measured telemetry labels. The original uninterrupted camera recording is following below.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
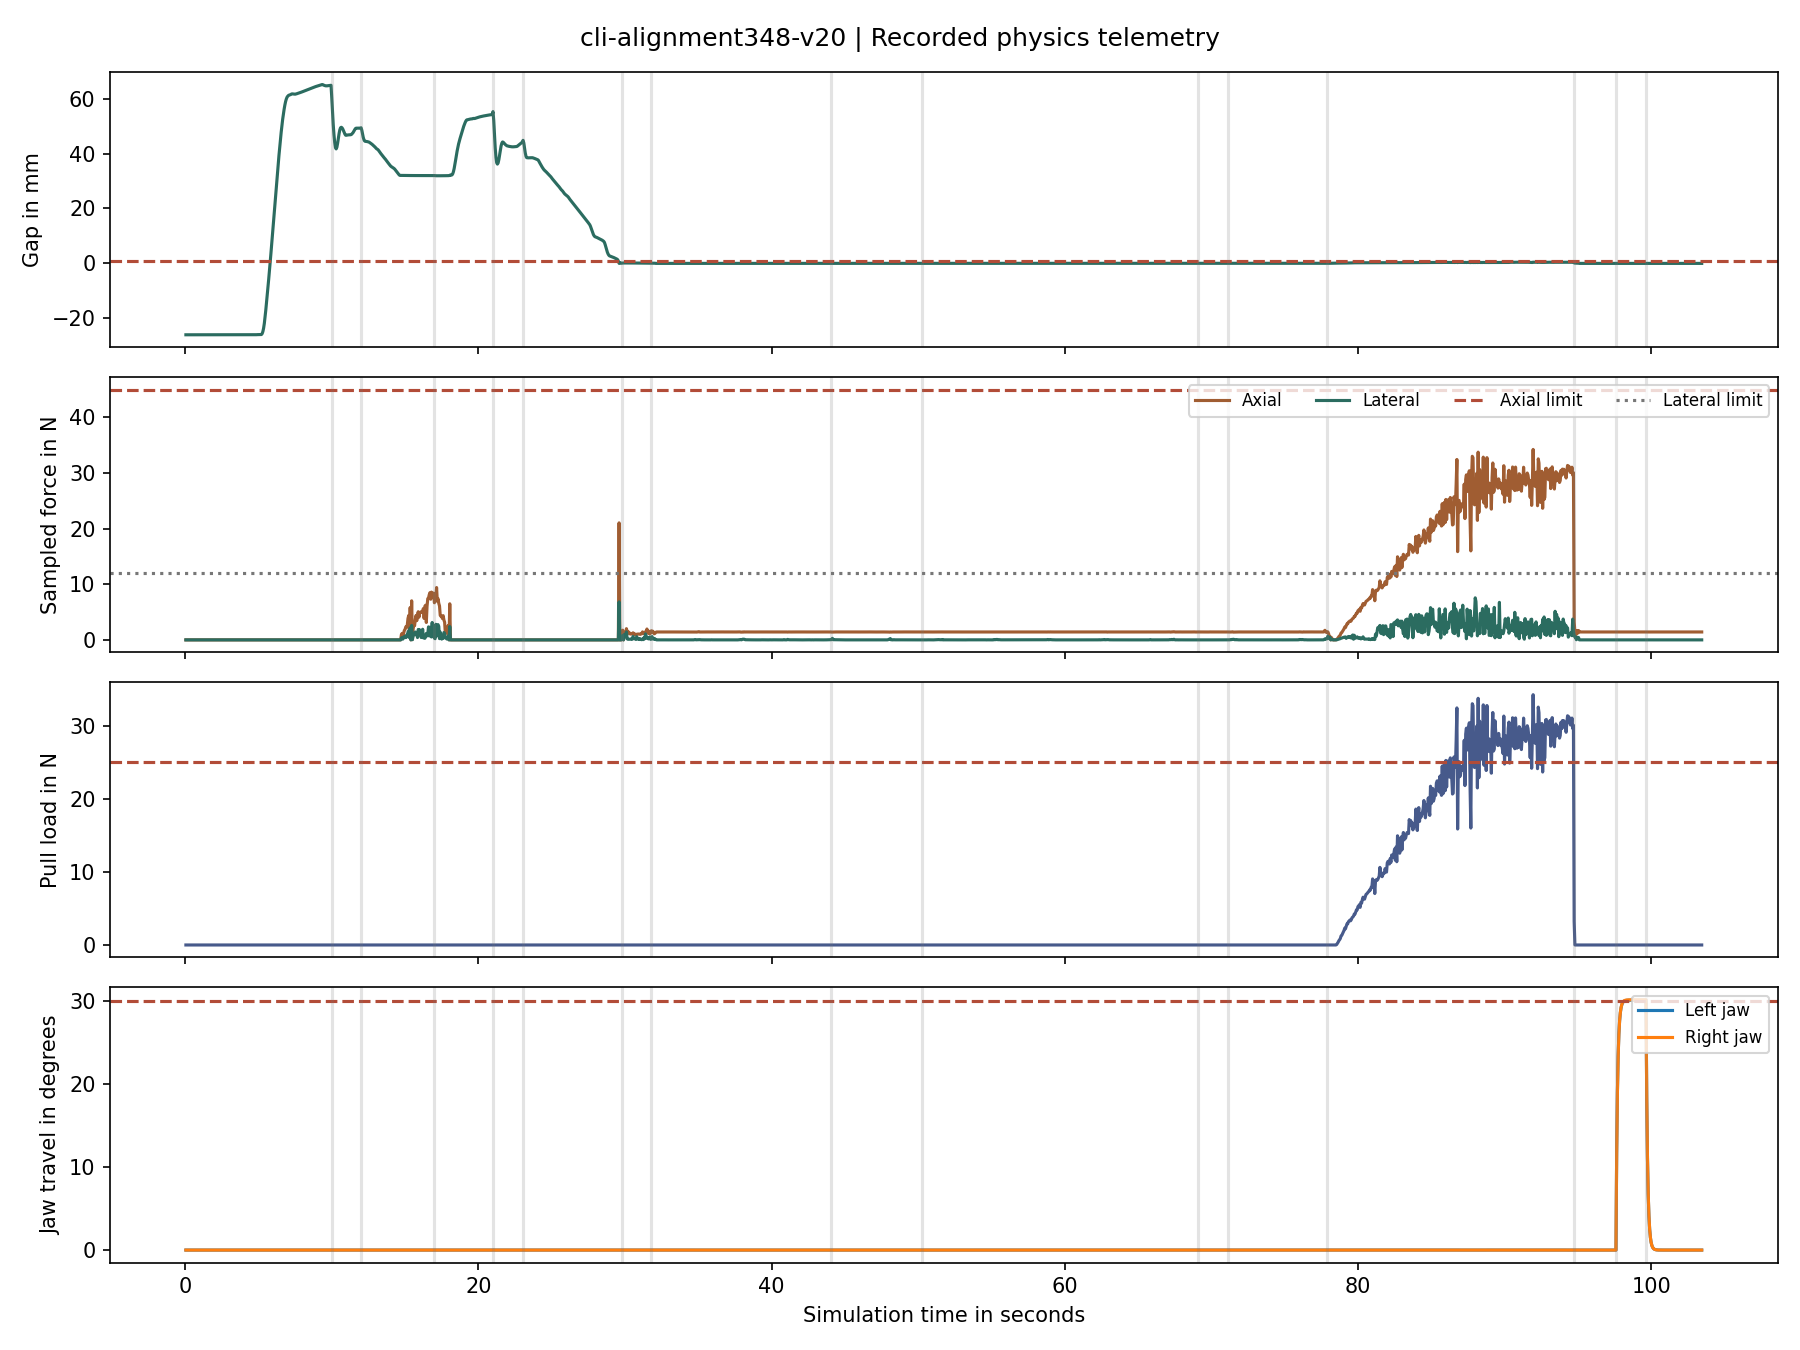
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.000000000000036,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 17.000000000000107,
      "phase": "retract",
      "reason": "Loaded insertion is showing less than 0.5 mm progress in one second"
    },
    {
      "time_s": 21.000000000000163,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 23.050000000000193,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 29.80000000000029,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 31.800000000000317,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 44.049999999999635,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 50.24999999999928,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 69.09999999999822,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 71.1499999999981,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 77.89999999999772,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 94.74999999999676,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 97.5999999999966,
      "phase": "motion_open",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 99.64999999999648,
      "phase": "motion_close",
      "reason": "Measured gripper joint travel is reaching 30 degrees"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": true,
    "seating": true,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": true,
    "observed_motion": true,
    "arms_released": true
  }
}
Recorded run: cli-grasp-v17
The run is ending in the Release phase. The independent verifier is reporting seating.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
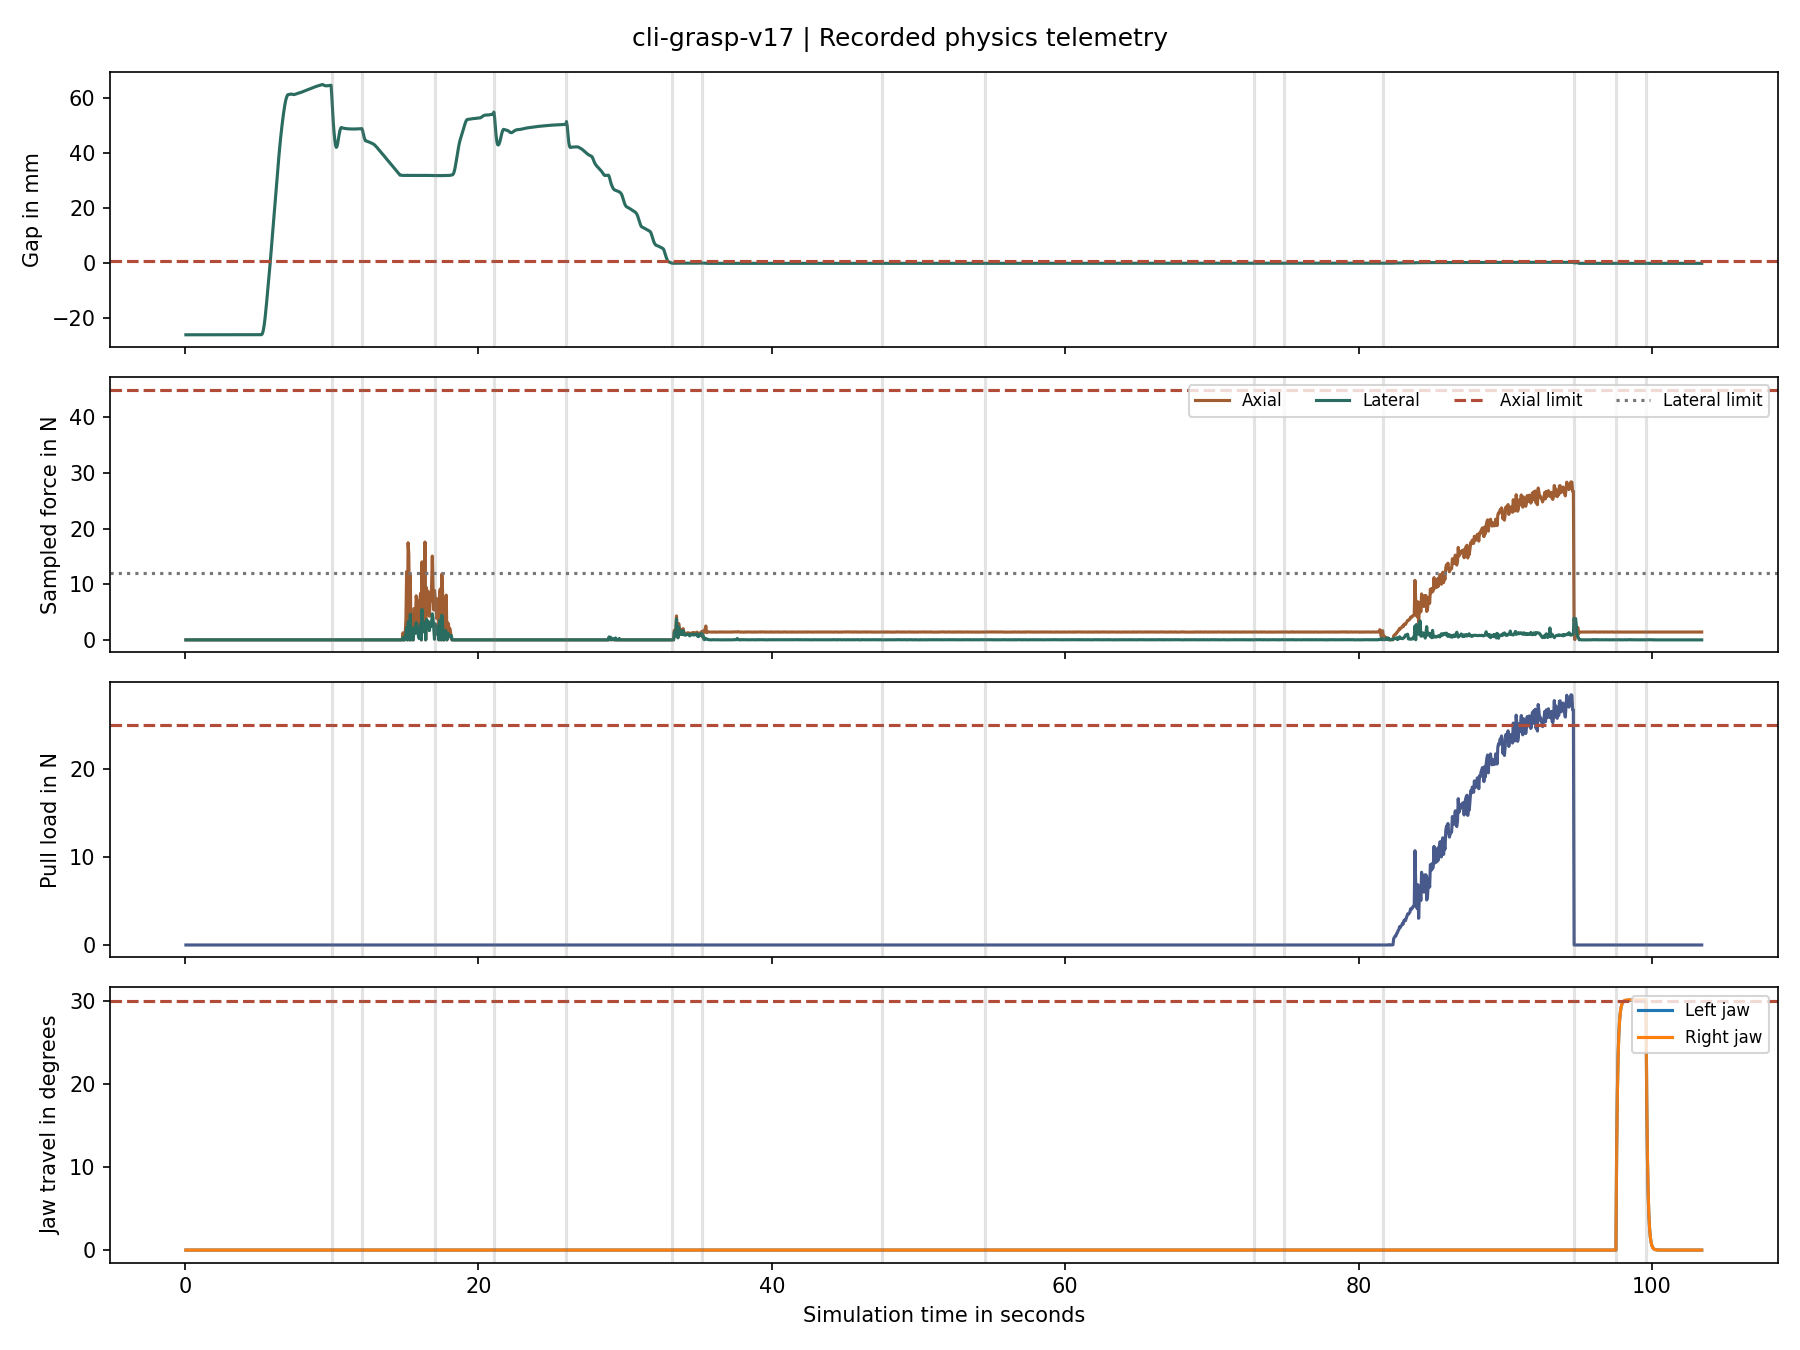
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.050000000000036,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 17.050000000000107,
      "phase": "retract",
      "reason": "Loaded insertion is showing less than 0.5 mm progress in one second"
    },
    {
      "time_s": 21.050000000000164,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 26.000000000000234,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 33.20000000000025,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 35.250000000000135,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 47.49999999999944,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 54.49999999999904,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 72.849999999998,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 74.89999999999789,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 81.6499999999975,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 94.69999999999676,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 97.5499999999966,
      "phase": "motion_open",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 99.59999999999648,
      "phase": "motion_close",
      "reason": "Measured gripper joint travel is reaching 30 degrees"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": true,
    "seating": false,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": true,
    "observed_motion": true,
    "arms_released": true
  }
}
Recorded run: cli-grasp-v18
The run is ending in the Release phase. The independent verifier is reporting all implemented task checks passed.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
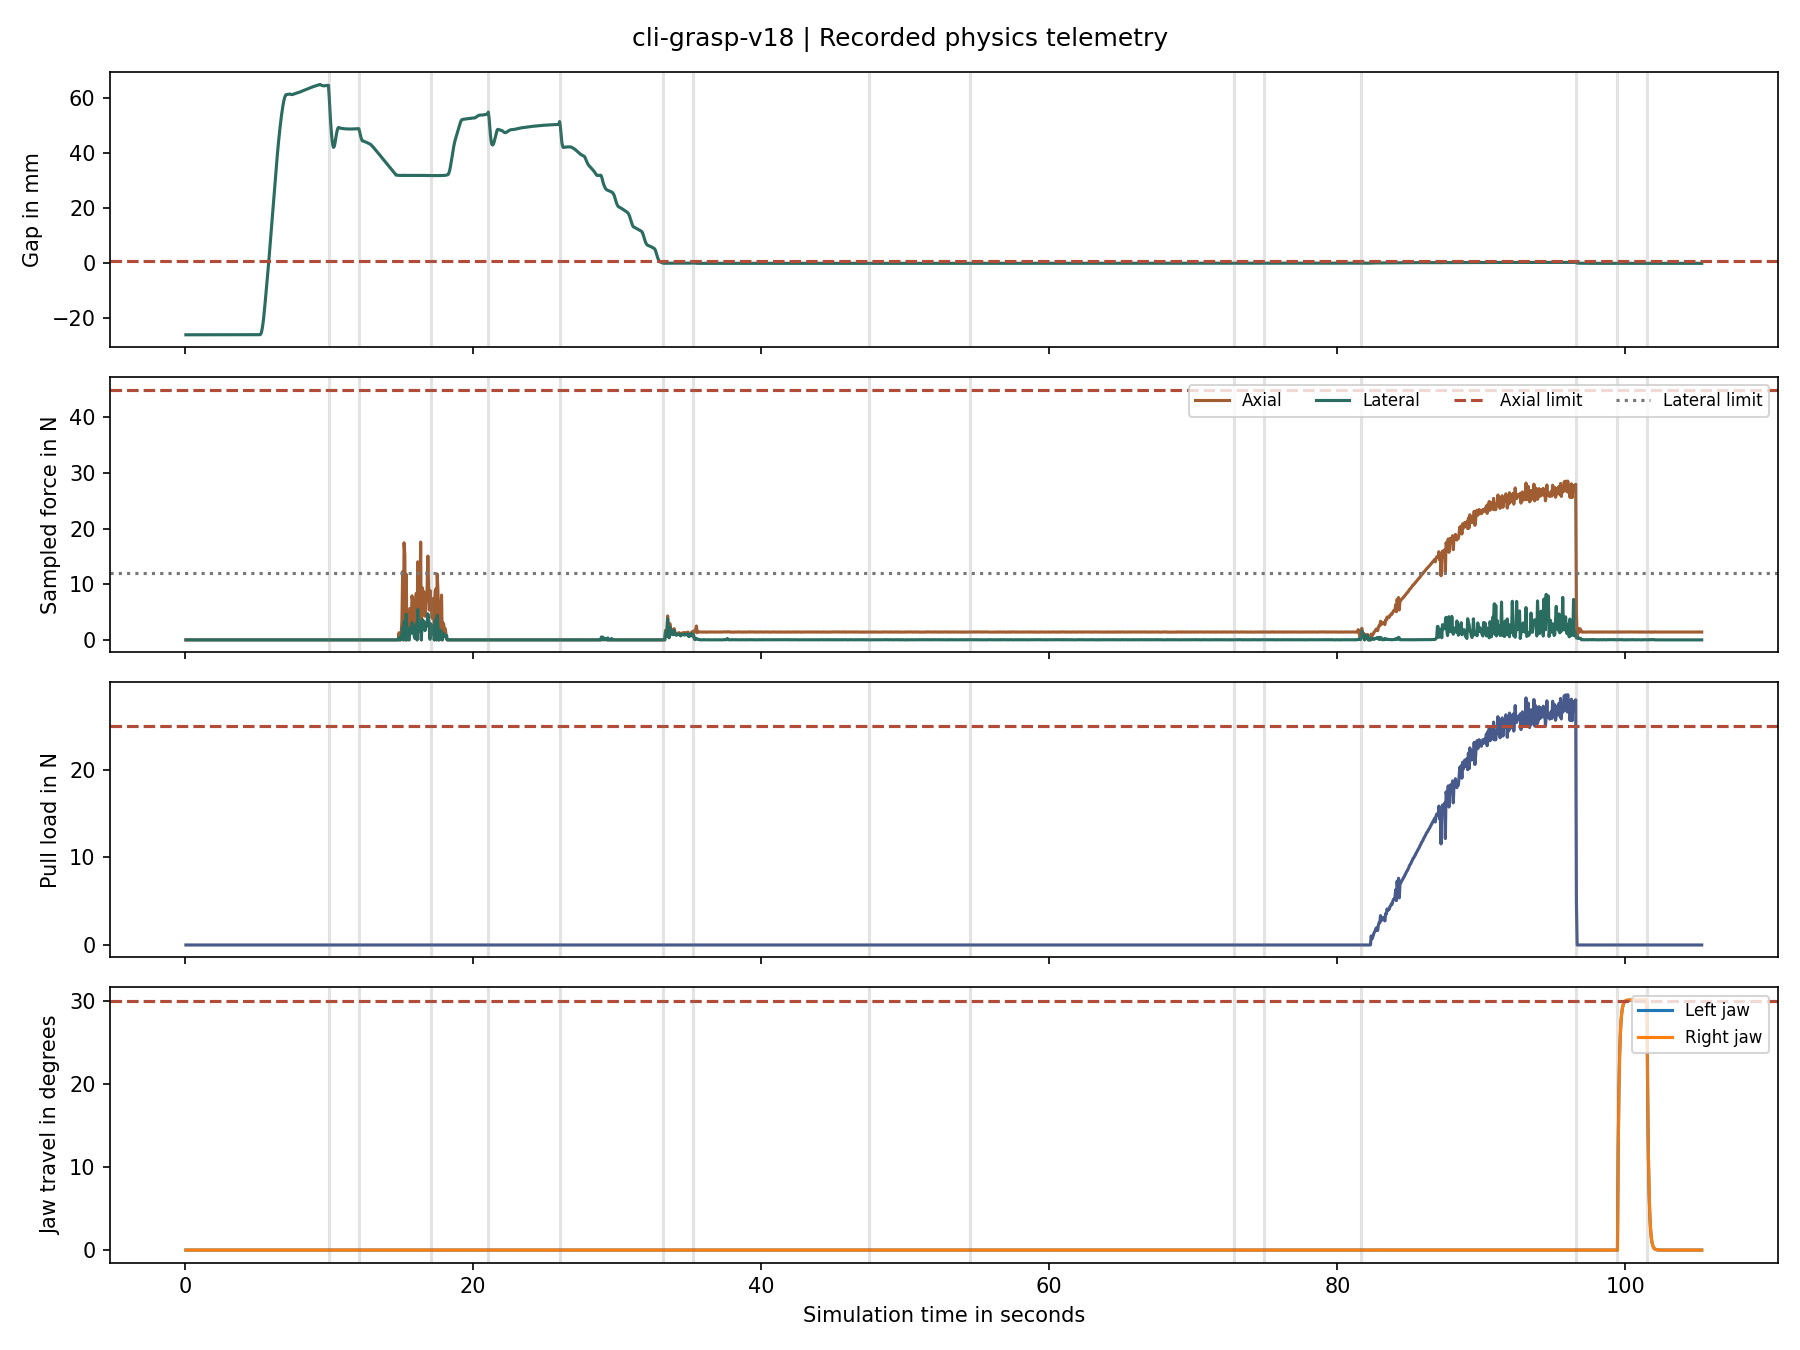
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.050000000000036,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 17.050000000000107,
      "phase": "retract",
      "reason": "Loaded insertion is showing less than 0.5 mm progress in one second"
    },
    {
      "time_s": 21.050000000000164,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 26.000000000000234,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 33.20000000000025,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 35.250000000000135,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 47.49999999999944,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 54.49999999999904,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 72.849999999998,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 74.89999999999789,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 81.6499999999975,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 96.59999999999665,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 99.44999999999649,
      "phase": "motion_open",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 101.49999999999638,
      "phase": "motion_close",
      "reason": "Measured gripper joint travel is reaching 30 degrees"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": true,
    "seating": true,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": true,
    "observed_motion": true,
    "arms_released": true
  }
}
Recorded run: cli-grasp-v19
The run is ending in the Release phase. The independent verifier is reporting all implemented task checks passed.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
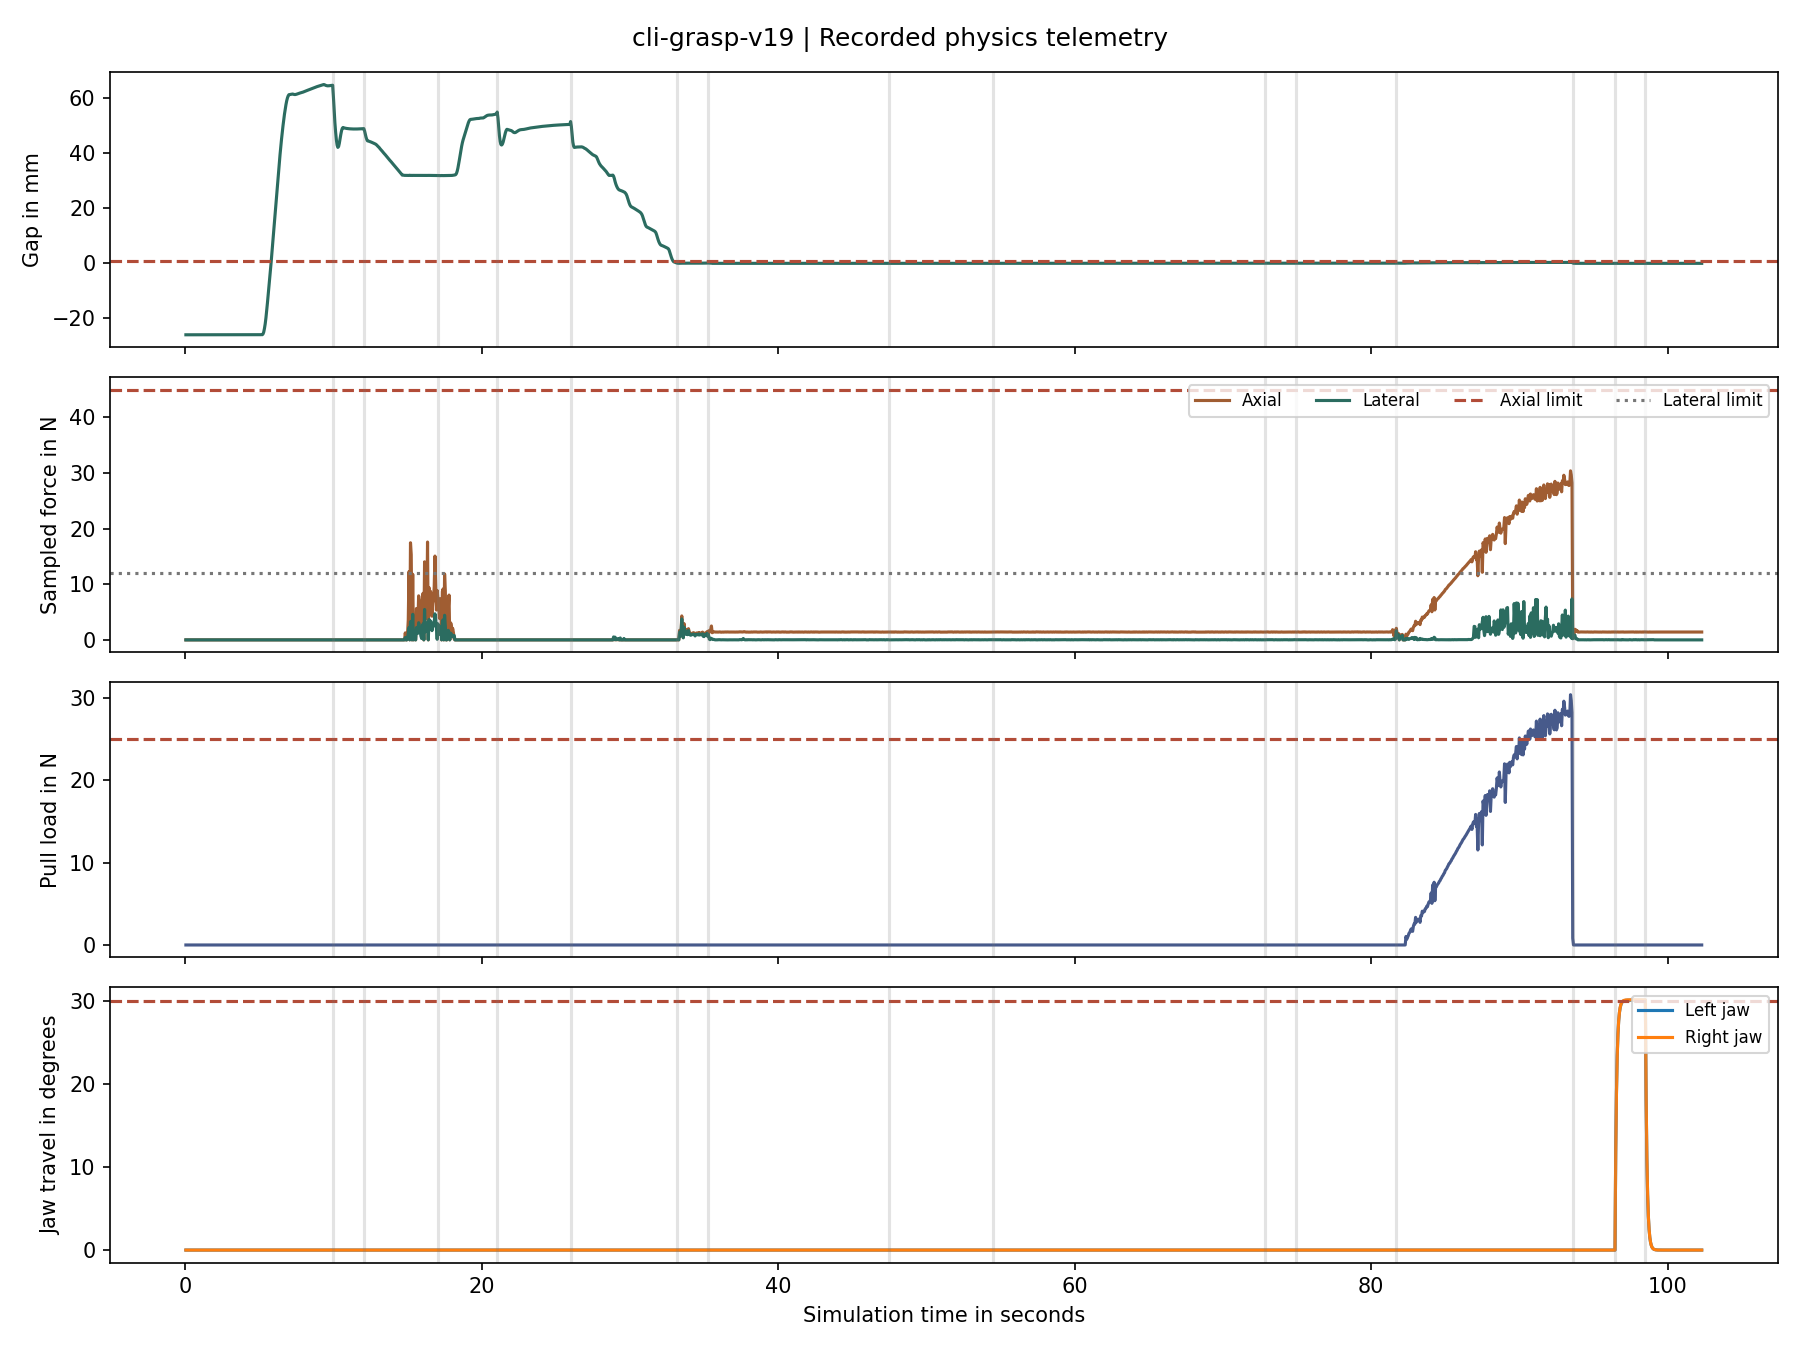
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.050000000000036,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 17.050000000000107,
      "phase": "retract",
      "reason": "Loaded insertion is showing less than 0.5 mm progress in one second"
    },
    {
      "time_s": 21.050000000000164,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 26.000000000000234,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 33.20000000000025,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 35.250000000000135,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 47.49999999999944,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 54.49999999999904,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 72.849999999998,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 74.89999999999789,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 81.6499999999975,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 93.59999999999683,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 96.44999999999666,
      "phase": "motion_open",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 98.49999999999655,
      "phase": "motion_close",
      "reason": "Measured gripper joint travel is reaching 30 degrees"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": true,
    "seating": true,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": true,
    "observed_motion": true,
    "arms_released": true
  }
}
Recorded run: cli-grasp205-v21
The run is ending in the Release phase. The independent verifier is reporting seating.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
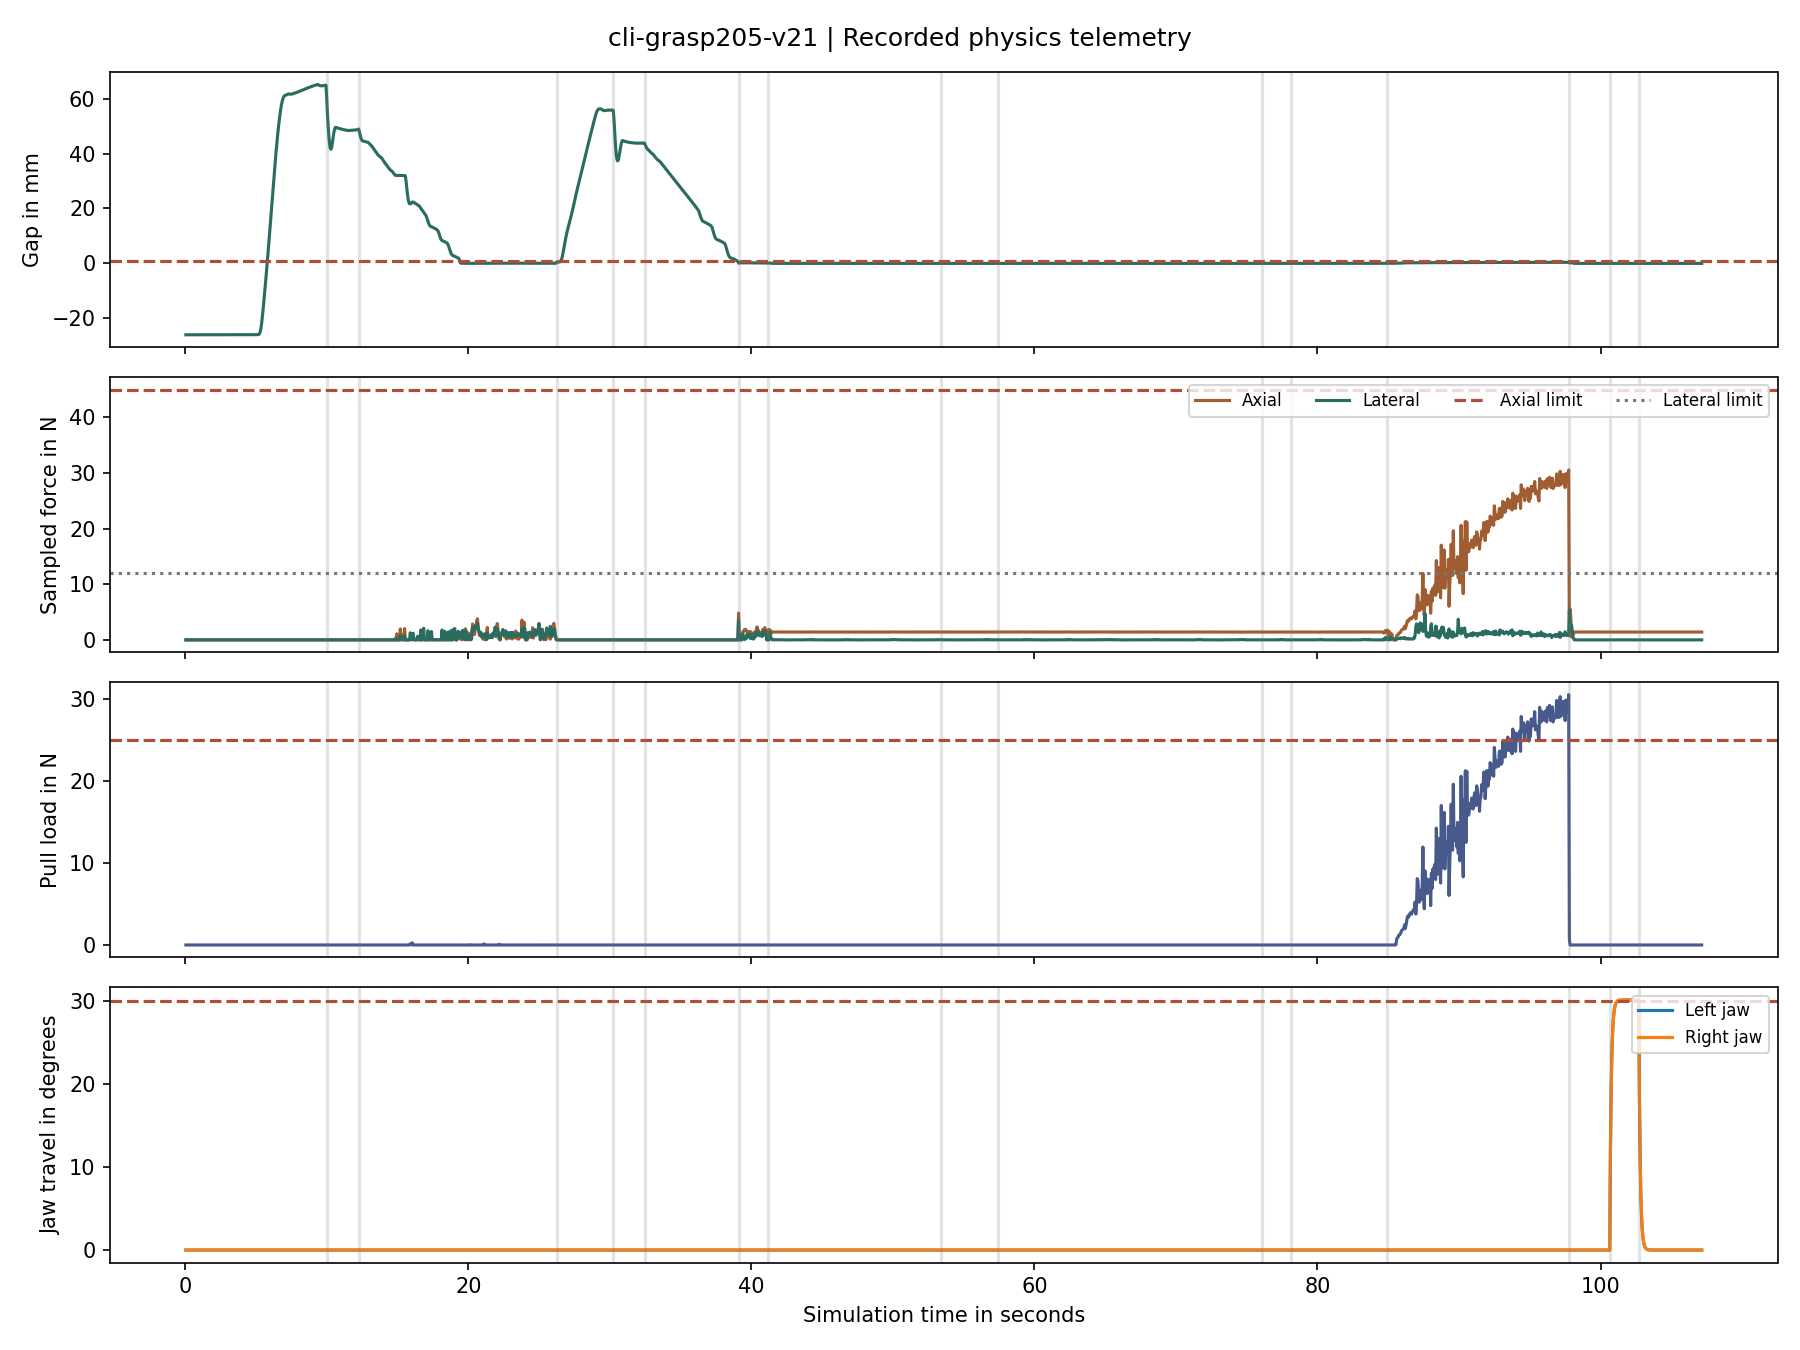
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.250000000000039,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 26.250000000000238,
      "phase": "retract",
      "reason": "Insertion timeout with unresolved gap"
    },
    {
      "time_s": 30.250000000000295,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 32.50000000000029,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 39.099999999999916,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 41.1499999999998,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 53.3999999999991,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 57.44999999999887,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 76.09999999999782,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 78.1499999999977,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 84.89999999999732,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 97.79999999999659,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 100.64999999999642,
      "phase": "motion_open",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 102.69999999999631,
      "phase": "motion_close",
      "reason": "Measured gripper joint travel is reaching 30 degrees"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": true,
    "seating": false,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": true,
    "observed_motion": true,
    "arms_released": true
  }
}
Recorded run: cli-grasp345-v21
The run is ending in the Release phase. The independent verifier is reporting seating.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
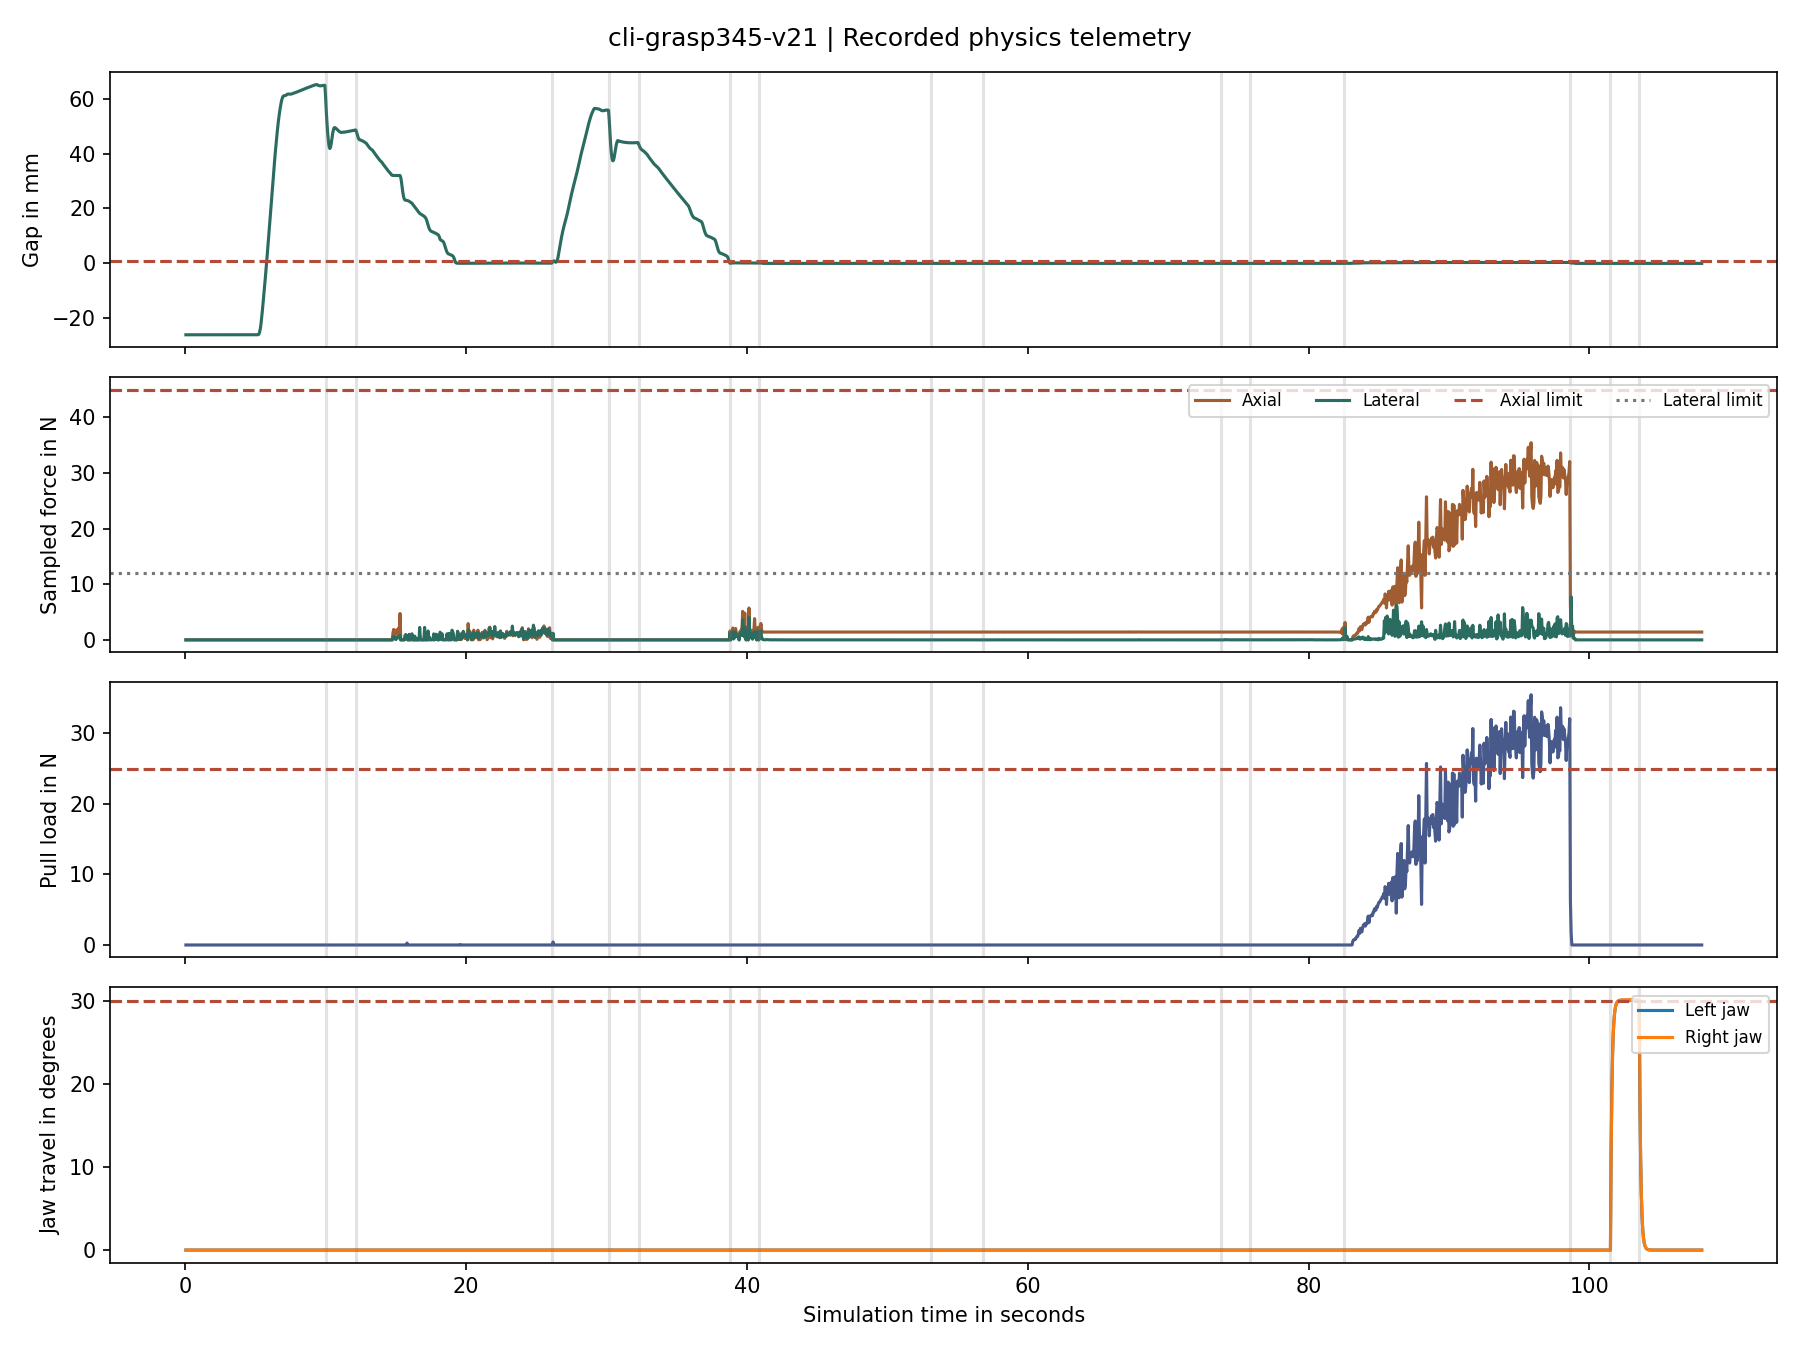
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.150000000000038,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 26.150000000000237,
      "phase": "retract",
      "reason": "Insertion timeout with unresolved gap"
    },
    {
      "time_s": 30.150000000000293,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 32.3000000000003,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 38.79999999999993,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 40.84999999999982,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 53.09999999999912,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 56.84999999999891,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 73.74999999999795,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 75.79999999999784,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 82.54999999999745,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 98.64999999999654,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 101.49999999999638,
      "phase": "motion_open",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 103.54999999999626,
      "phase": "motion_close",
      "reason": "Measured gripper joint travel is reaching 30 degrees"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": true,
    "seating": false,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": true,
    "observed_motion": true,
    "arms_released": true
  }
}
Recorded run: cli-grasp348-v21
The run is ending in the Release phase. The independent verifier is reporting seating.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
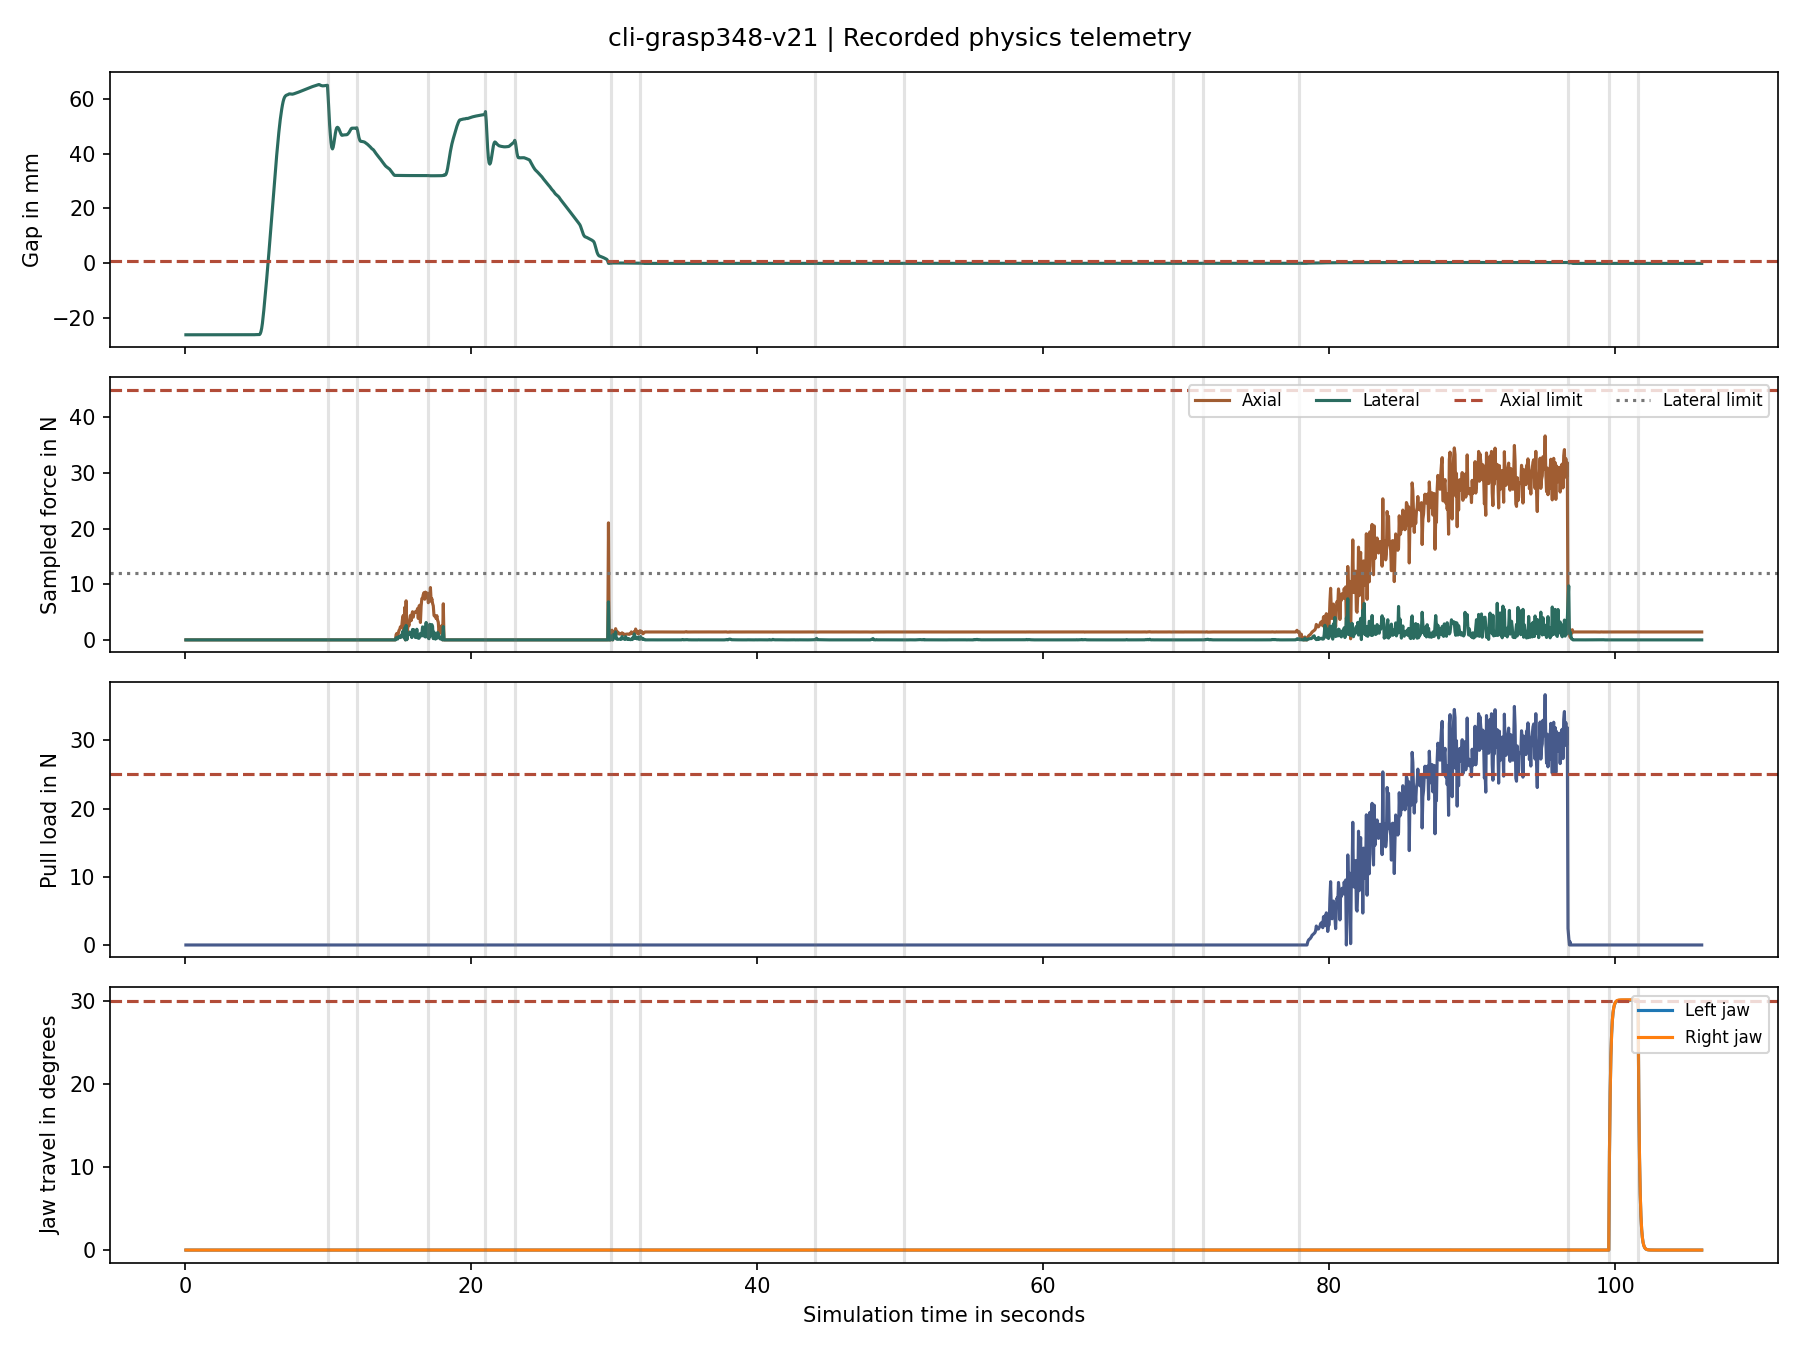
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.000000000000036,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 17.000000000000107,
      "phase": "retract",
      "reason": "Loaded insertion is showing less than 0.5 mm progress in one second"
    },
    {
      "time_s": 21.000000000000163,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 23.050000000000193,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 29.80000000000029,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 31.800000000000317,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 44.049999999999635,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 50.24999999999928,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 69.09999999999822,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 71.1499999999981,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 77.89999999999772,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 96.69999999999665,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 99.54999999999649,
      "phase": "motion_open",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 101.59999999999637,
      "phase": "motion_close",
      "reason": "Measured gripper joint travel is reaching 30 degrees"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": true,
    "seating": false,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": true,
    "observed_motion": true,
    "arms_released": true
  }
}
Recorded run: cli-grasp401-v21
The run is ending in the Release phase. The independent verifier is reporting seating.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
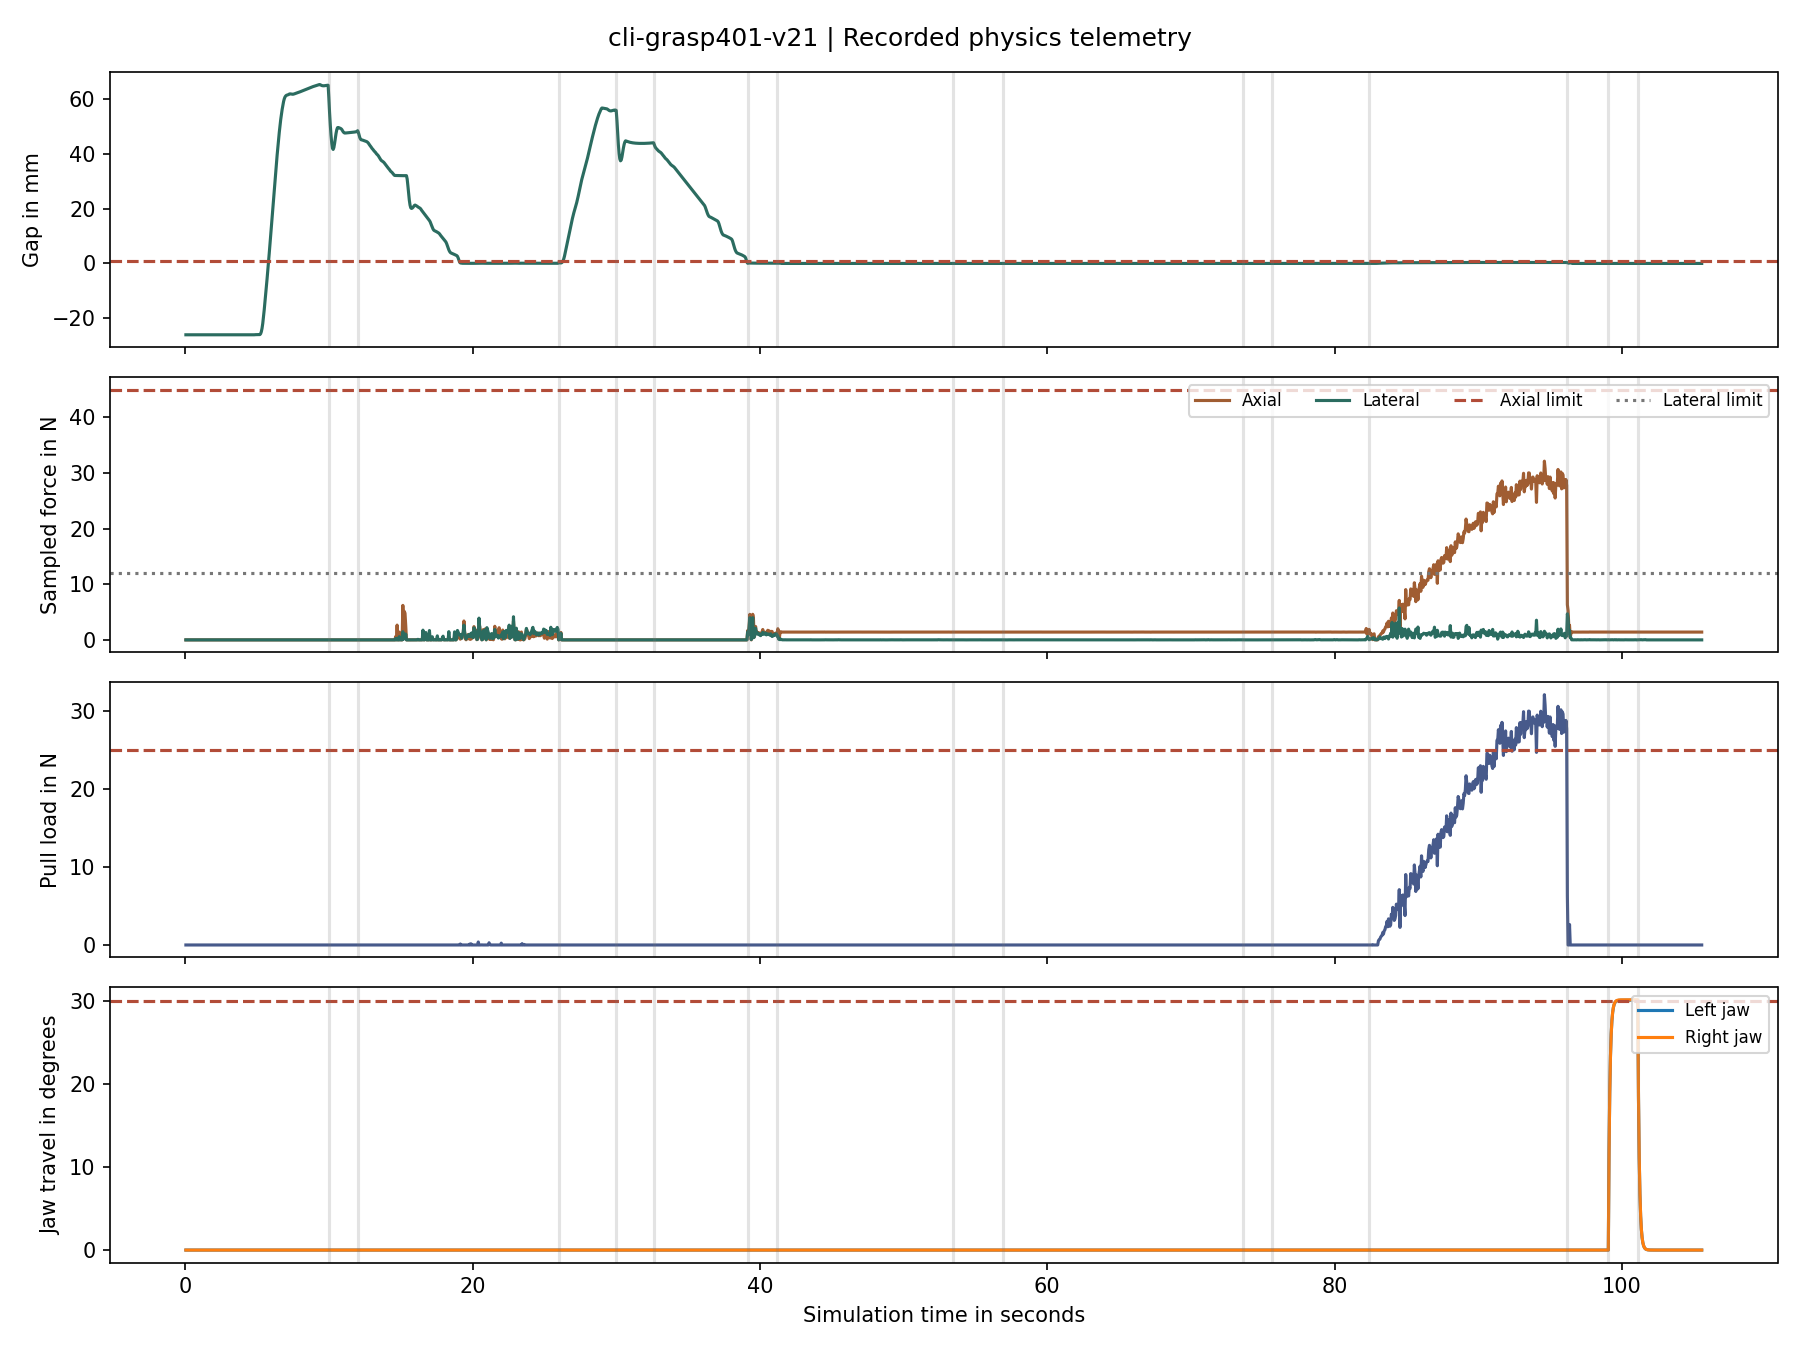
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.000000000000036,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 26.000000000000234,
      "phase": "retract",
      "reason": "Insertion timeout with unresolved gap"
    },
    {
      "time_s": 30.00000000000029,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 32.65000000000028,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 39.14999999999991,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 41.1999999999998,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 53.4499999999991,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 56.9499999999989,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 73.59999999999796,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 75.64999999999785,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 82.39999999999746,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 96.19999999999668,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 99.04999999999652,
      "phase": "motion_open",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 101.0999999999964,
      "phase": "motion_close",
      "reason": "Measured gripper joint travel is reaching 30 degrees"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": true,
    "seating": false,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": true,
    "observed_motion": true,
    "arms_released": true
  }
}
Recorded run: cli-hardened-v14
The run is ending in the Release phase. The independent verifier is reporting all implemented task checks passed.
The composite is showing three recorded cameras with measured telemetry labels. The original uninterrupted camera recording is following below.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
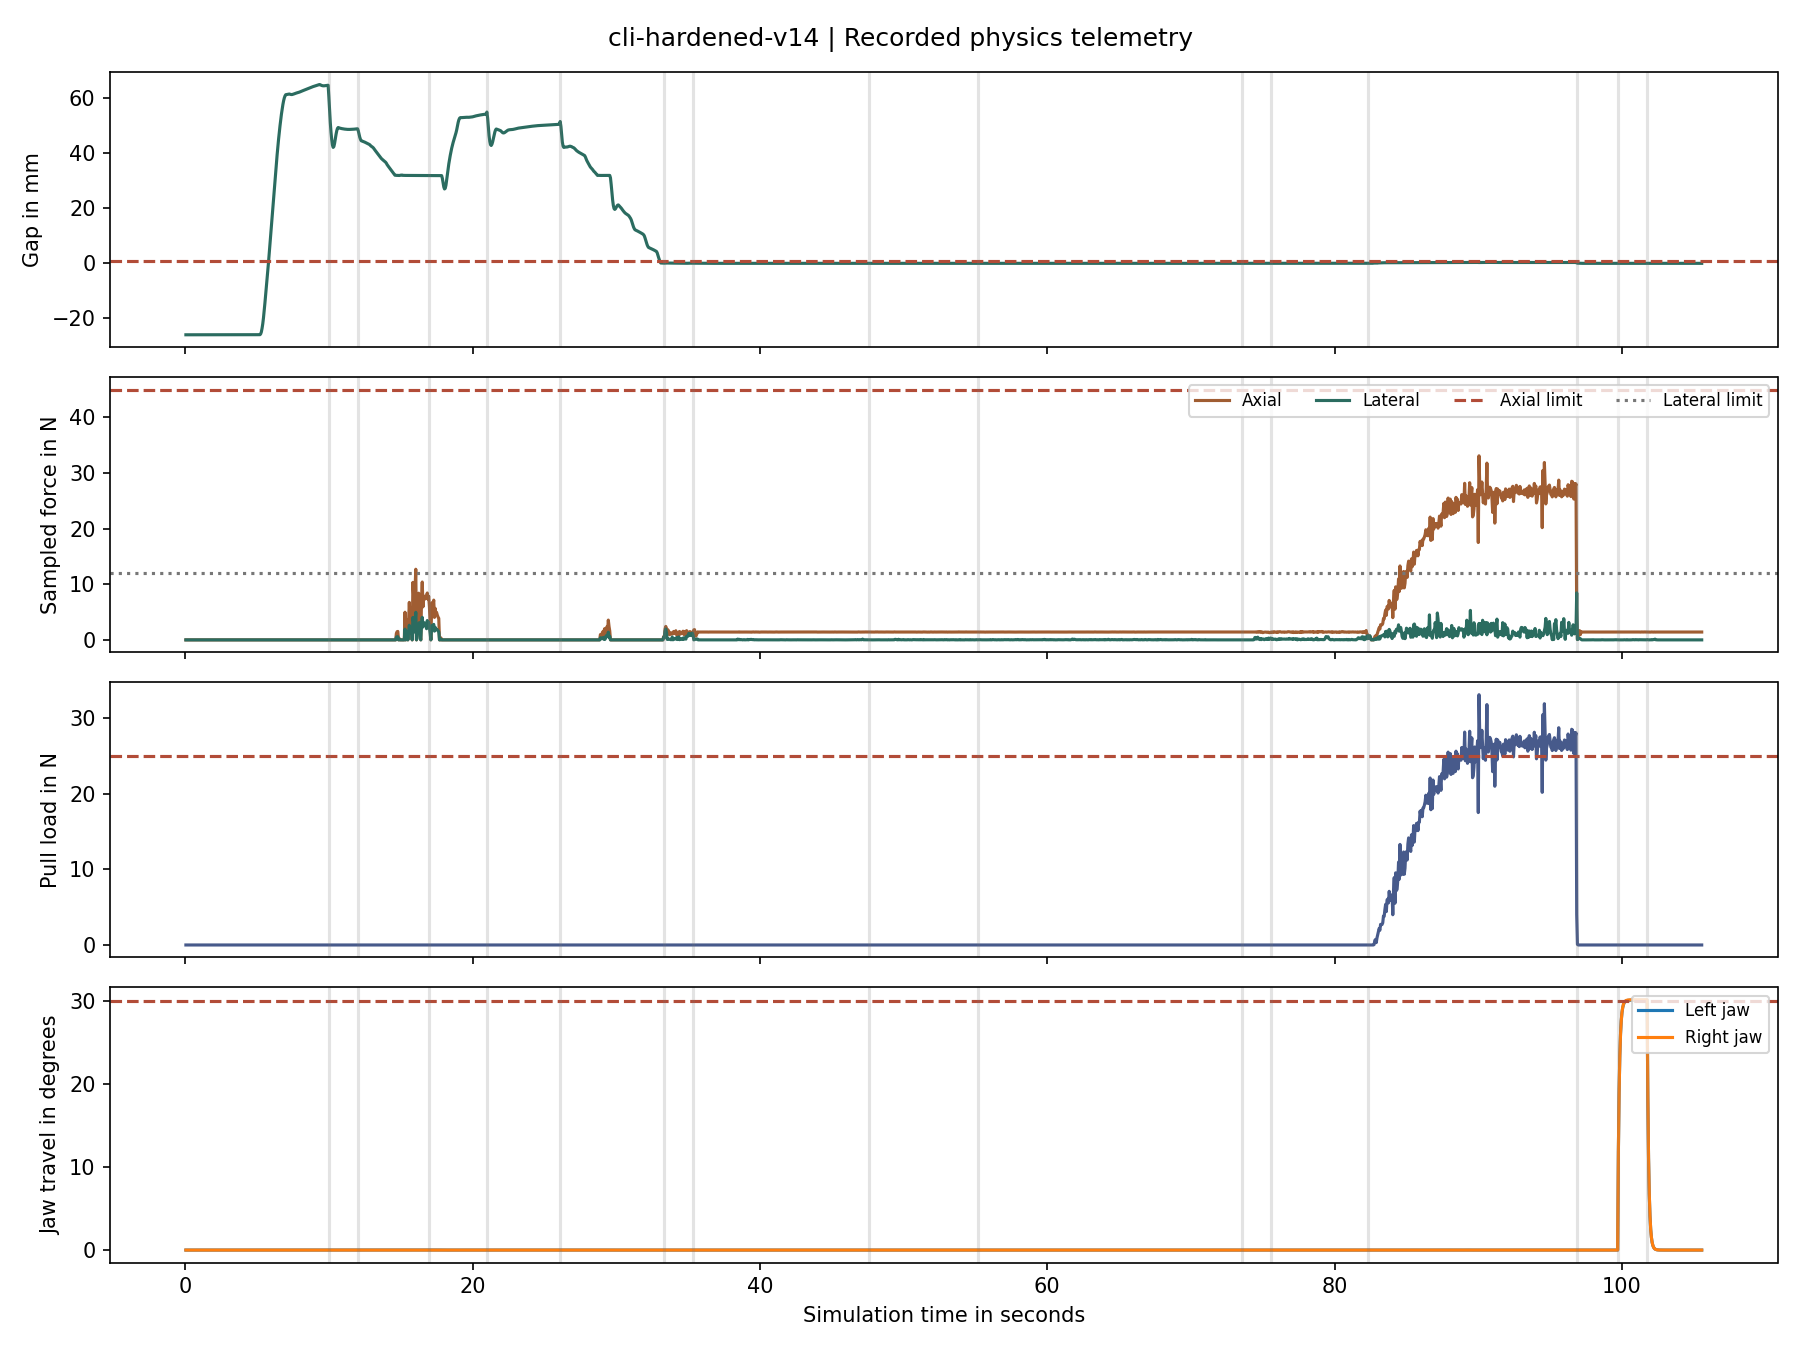
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.000000000000036,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 17.000000000000107,
      "phase": "retract",
      "reason": "Loaded insertion is showing less than 0.5 mm progress in one second"
    },
    {
      "time_s": 21.000000000000163,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 26.100000000000236,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 33.300000000000246,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 35.35000000000013,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 47.59999999999943,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 55.149999999999004,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 73.54999999999797,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 75.59999999999785,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 82.34999999999746,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 96.84999999999664,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 99.69999999999648,
      "phase": "motion_open",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 101.74999999999636,
      "phase": "motion_close",
      "reason": "Measured gripper joint travel is reaching 30 degrees"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": true,
    "seating": true,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": true,
    "observed_motion": true,
    "arms_released": true
  }
}
Recorded run: cli-nominal-v10
The run is ending in the Safe stop phase. The independent verifier is reporting complete_assembly_sequence, seating, pin_engagement, sustained_pull, observed_motion, arms_released.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
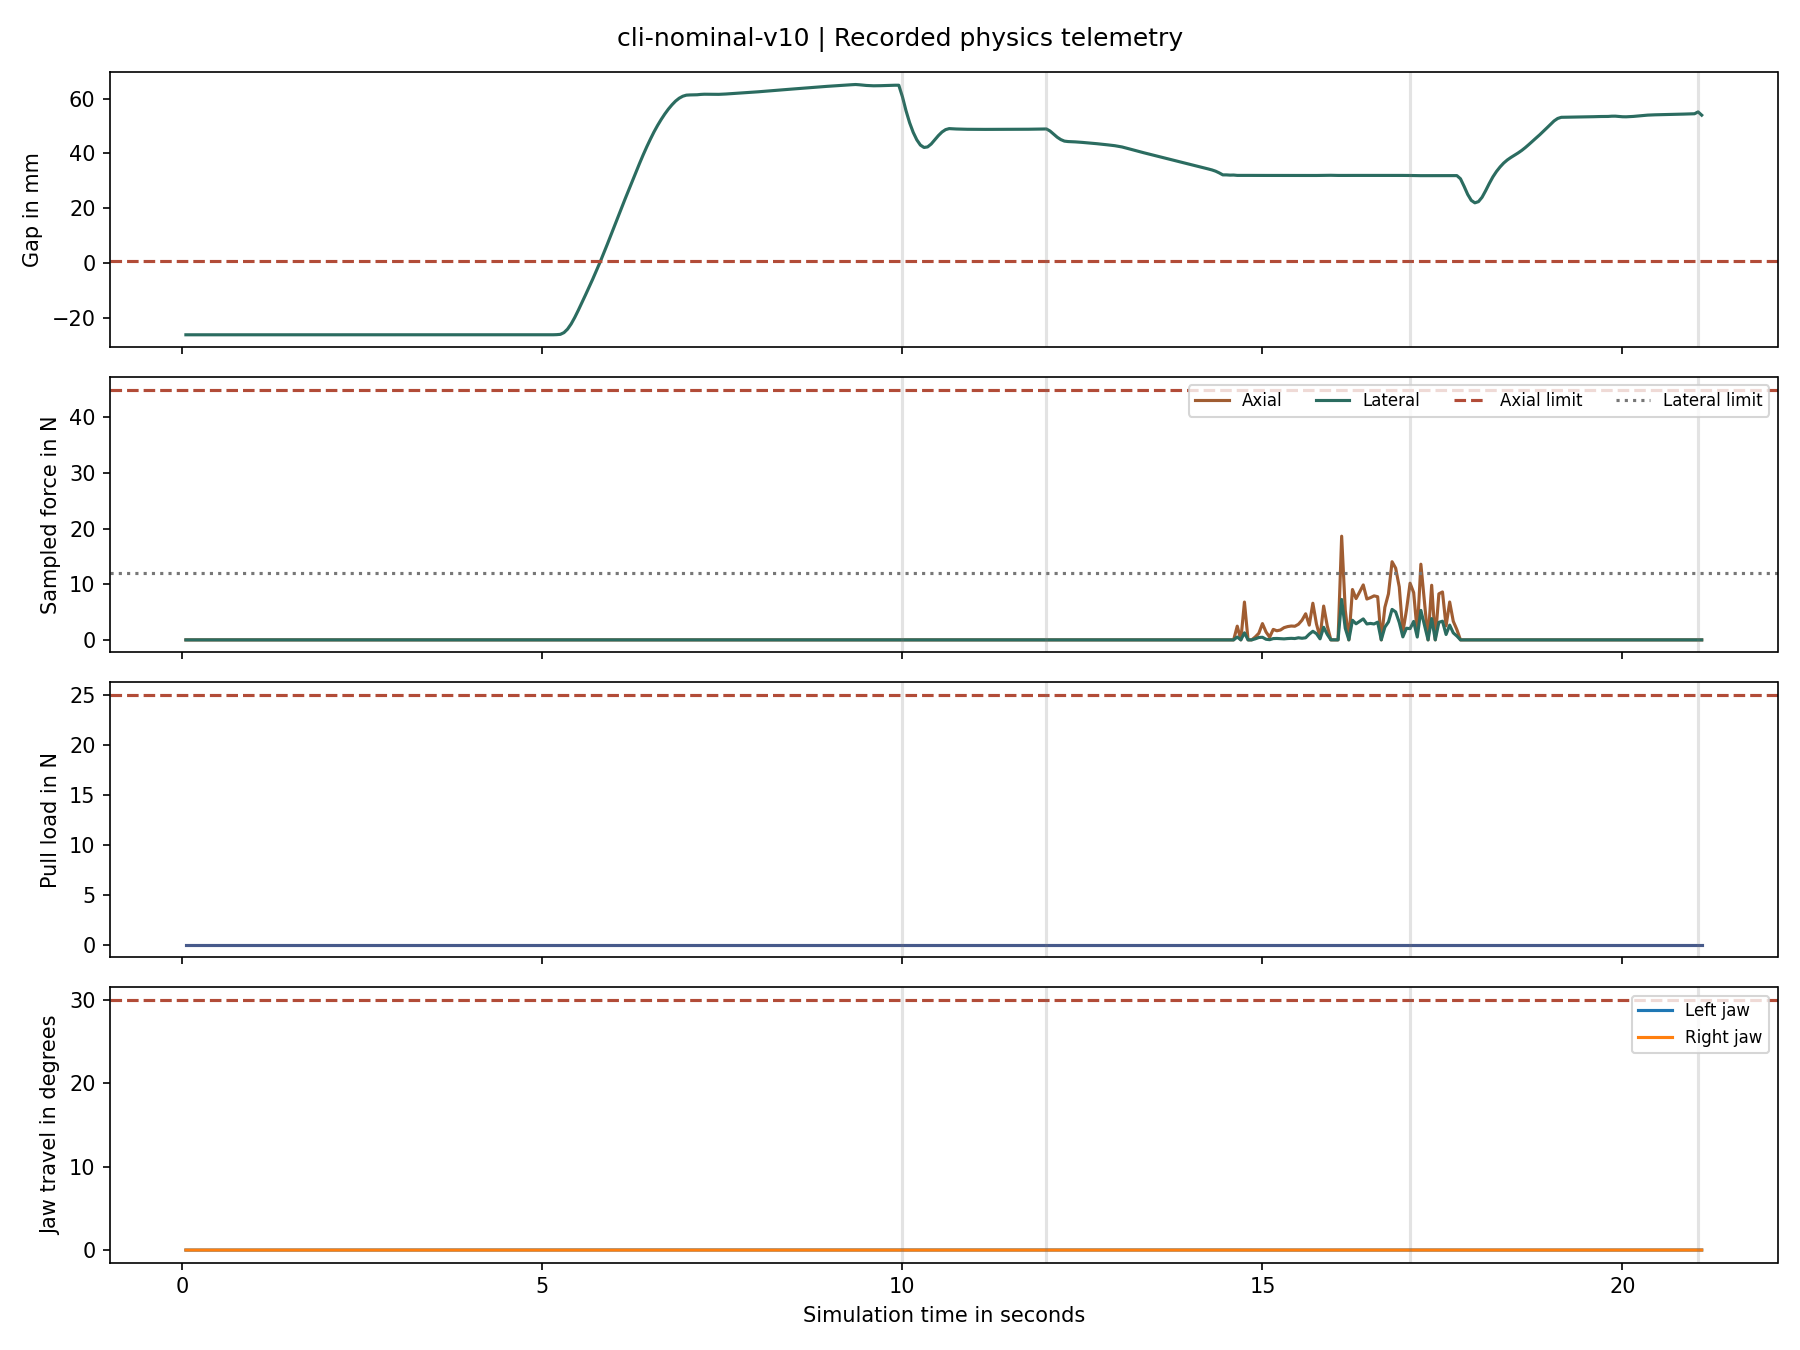
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.000000000000036,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 17.050000000000107,
      "phase": "retract",
      "reason": "Loaded insertion is showing less than 0.5 mm progress in one second"
    },
    {
      "time_s": 21.050000000000164,
      "phase": "safe_stop",
      "reason": "Bounded recovery budget check"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": false,
    "seating": false,
    "pin_engagement": false,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": false,
    "observed_motion": false,
    "arms_released": false
  }
}
Recorded run: cli-recovery-v11
The run is ending in the Safe stop phase. The independent verifier is reporting complete_assembly_sequence, sampled_force_limits, sustained_pull, observed_motion, arms_released.
The composite is showing three recorded cameras with measured telemetry labels. The original uninterrupted camera recording is following below.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
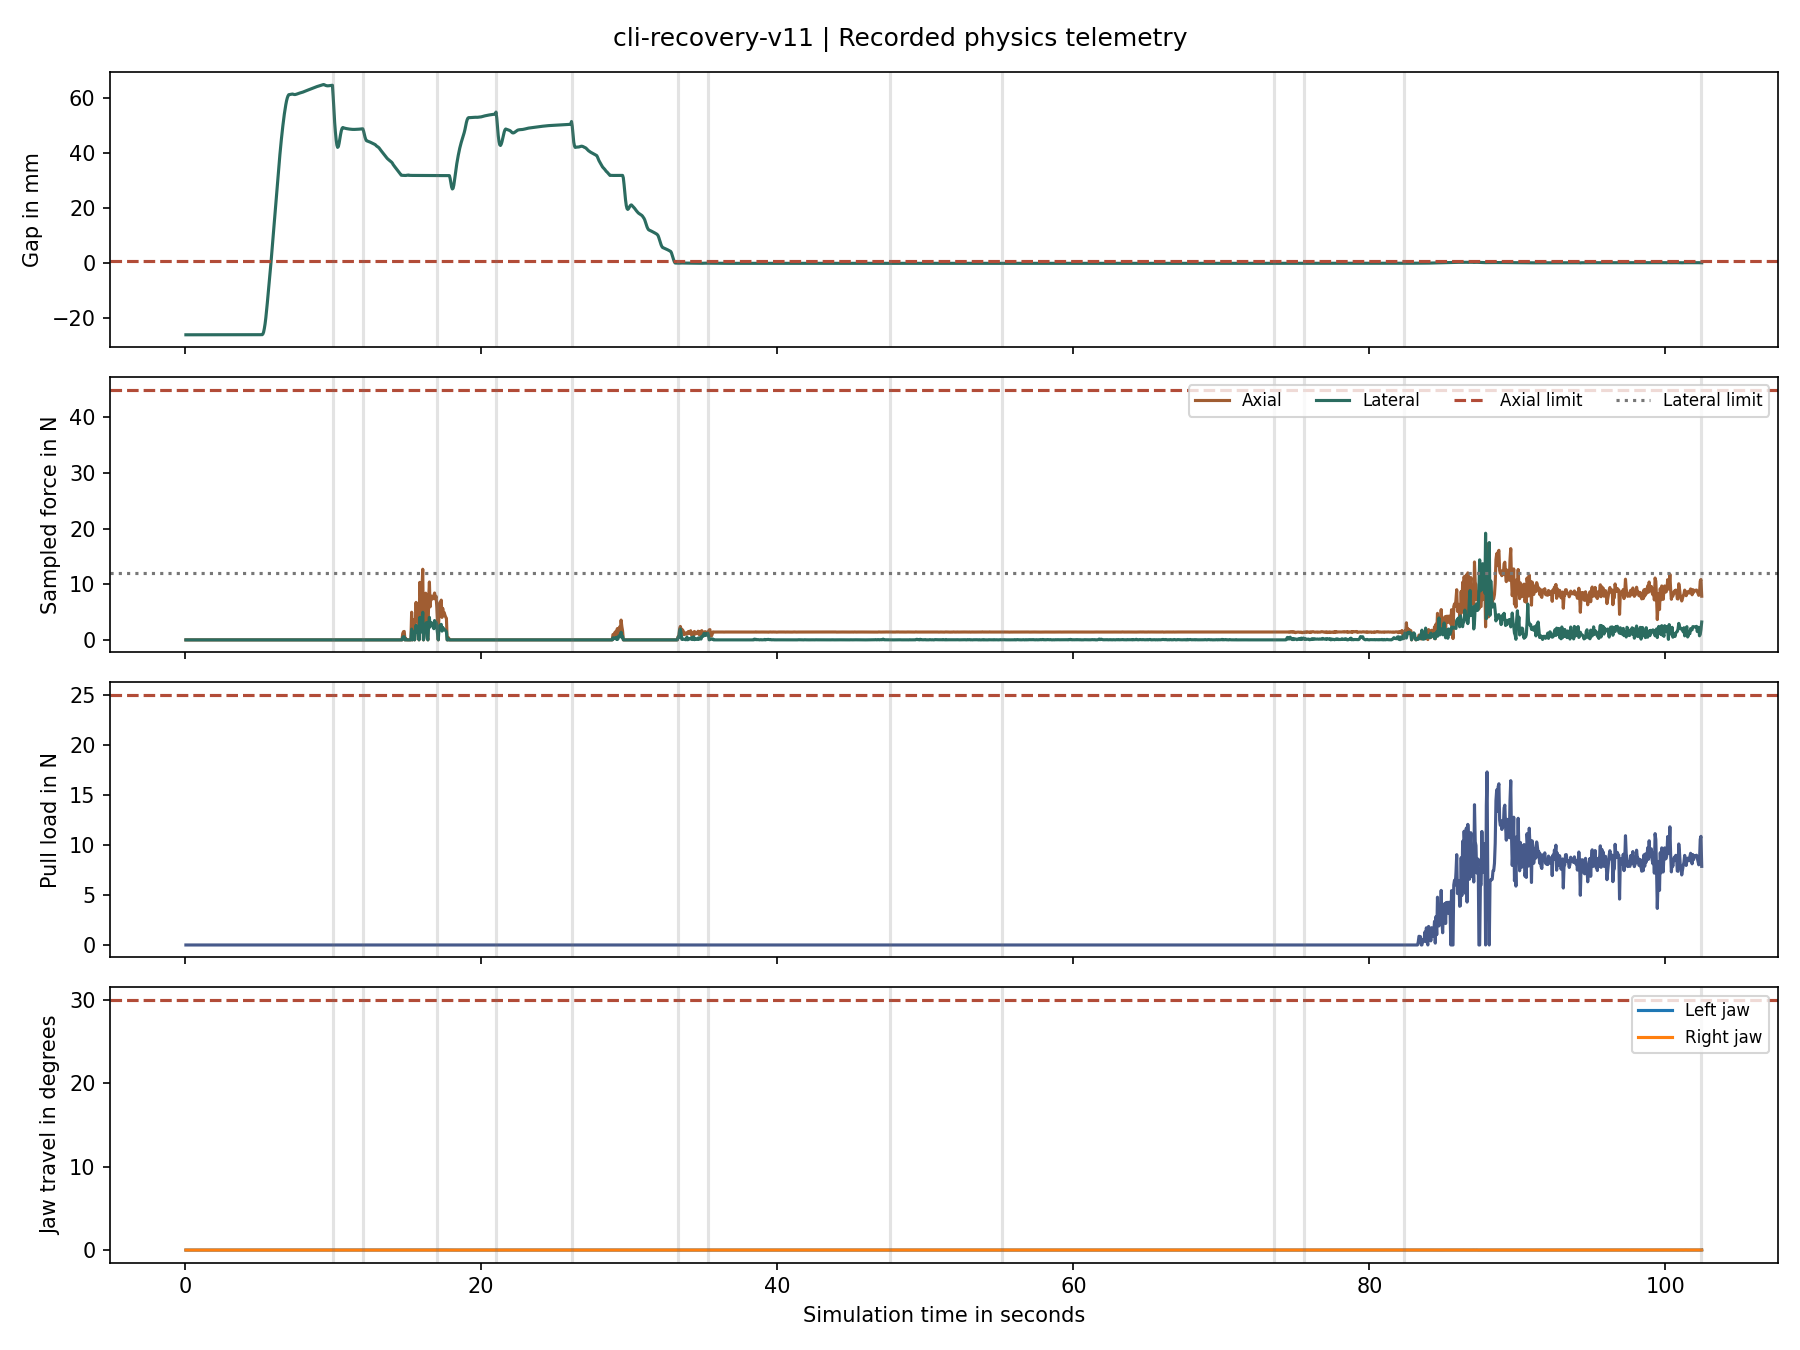
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.000000000000036,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 17.000000000000107,
      "phase": "retract",
      "reason": "Loaded insertion is showing less than 0.5 mm progress in one second"
    },
    {
      "time_s": 21.000000000000163,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 26.100000000000236,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 33.300000000000246,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 35.35000000000013,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 47.59999999999943,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 55.149999999999004,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 73.54999999999797,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 75.59999999999785,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 82.34999999999746,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 102.39999999999633,
      "phase": "safe_stop",
      "reason": "Pull proof timeout"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": false,
    "seating": true,
    "pin_engagement": true,
    "sampled_force_limits": false,
    "sampled_torque_limit": true,
    "sustained_pull": false,
    "observed_motion": false,
    "arms_released": false
  }
}
Recorded run: cli-regression205-v16
The run is ending in the Safe stop phase. The independent verifier is reporting complete_assembly_sequence, sustained_pull, observed_motion, arms_released.
The composite is showing three recorded cameras with measured telemetry labels. The original uninterrupted camera recording is following below.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
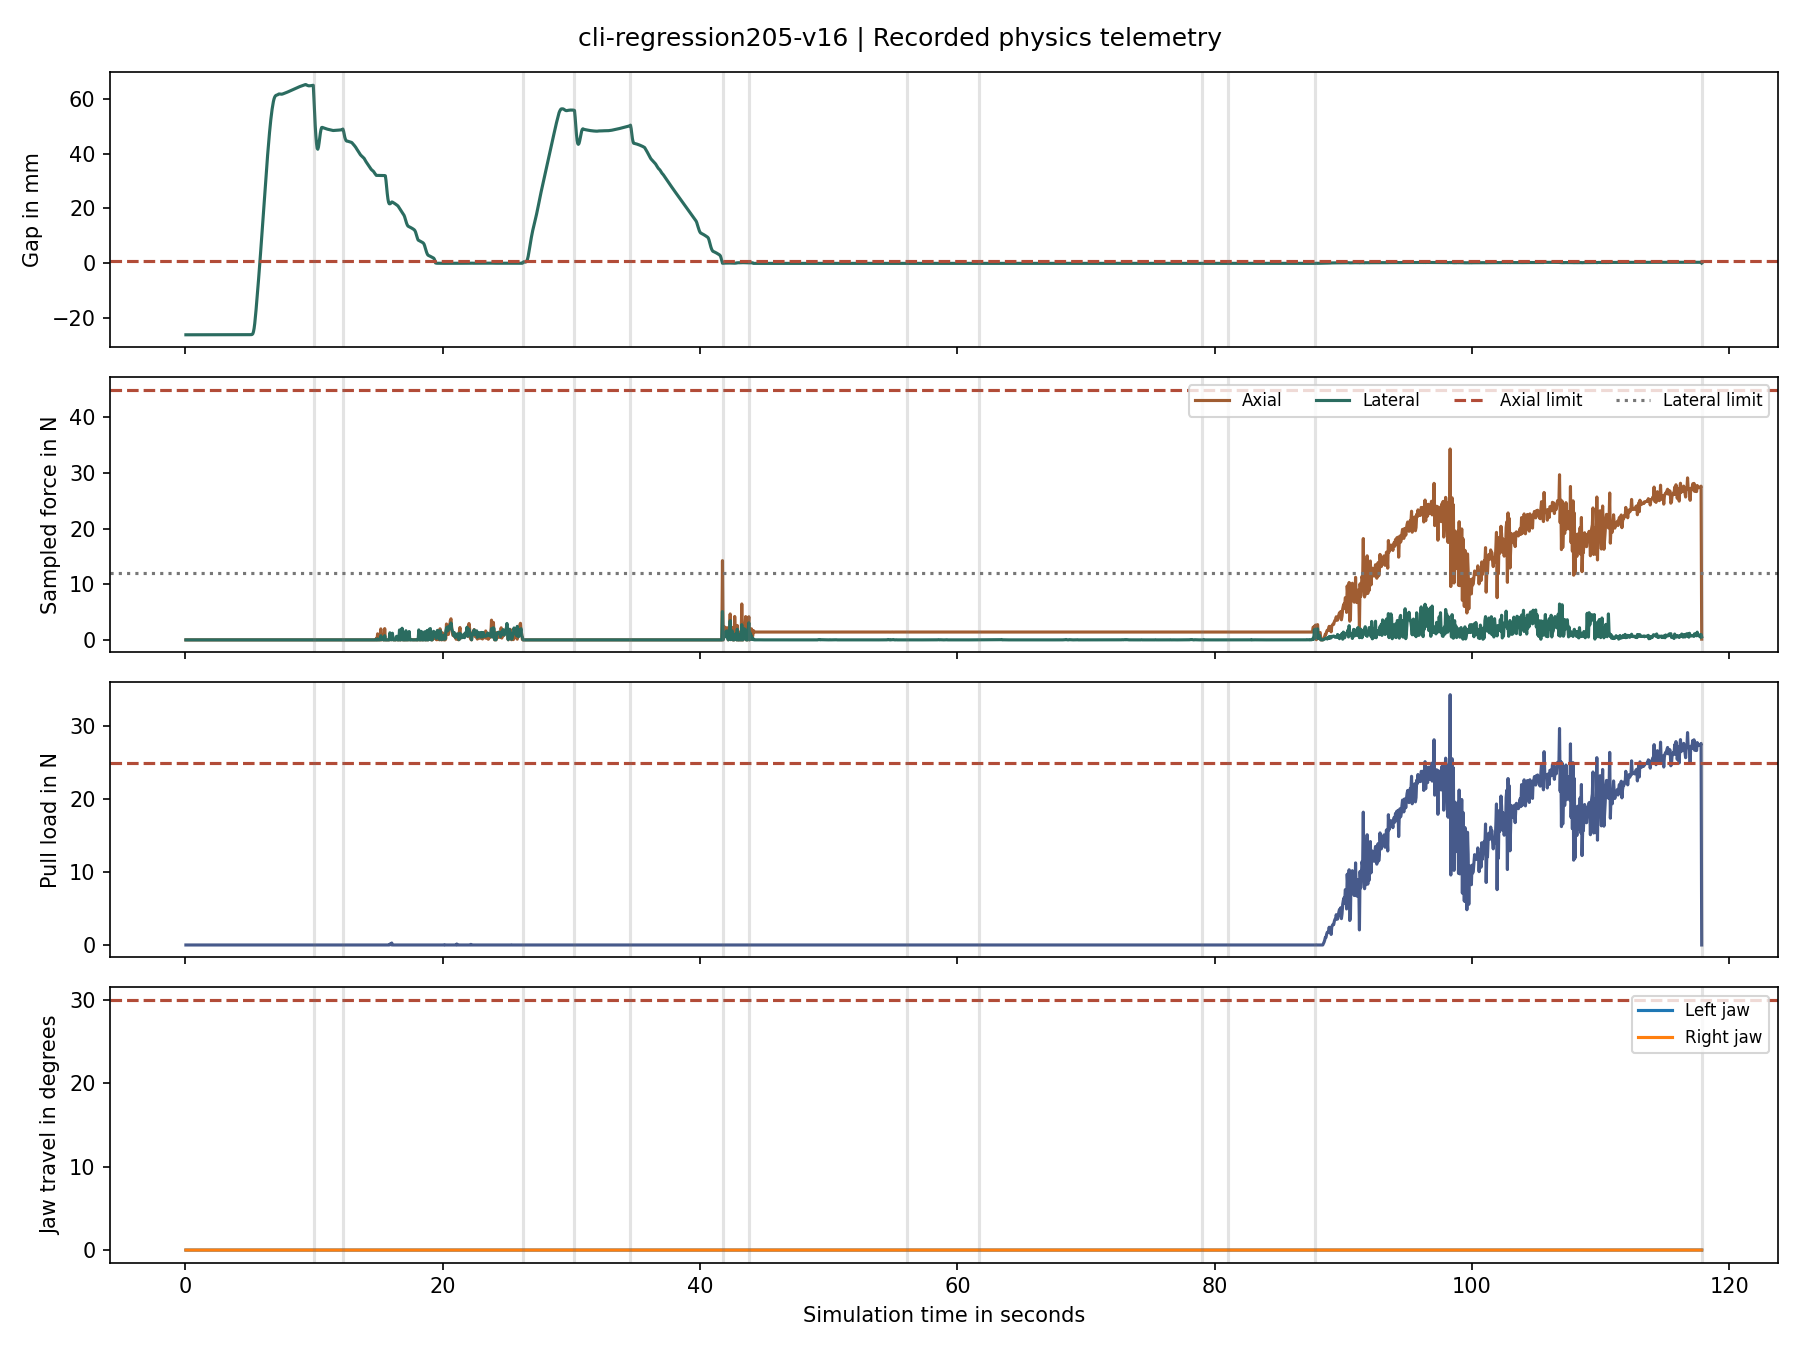
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.250000000000039,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 26.250000000000238,
      "phase": "retract",
      "reason": "Insertion timeout with unresolved gap"
    },
    {
      "time_s": 30.250000000000295,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 34.60000000000017,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 41.79999999999976,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 43.849999999999646,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 56.09999999999895,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 61.69999999999863,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 78.99999999999766,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 81.04999999999754,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 87.79999999999715,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 117.84999999999545,
      "phase": "safe_stop",
      "reason": "Pull proof timeout"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": false,
    "seating": true,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": false,
    "observed_motion": false,
    "arms_released": false
  }
}
Recorded run: cli-regression205-v17
The run is ending in the Insert phase. The independent verifier is reporting complete_assembly_sequence, seating, pin_engagement, sustained_pull, observed_motion, arms_released.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
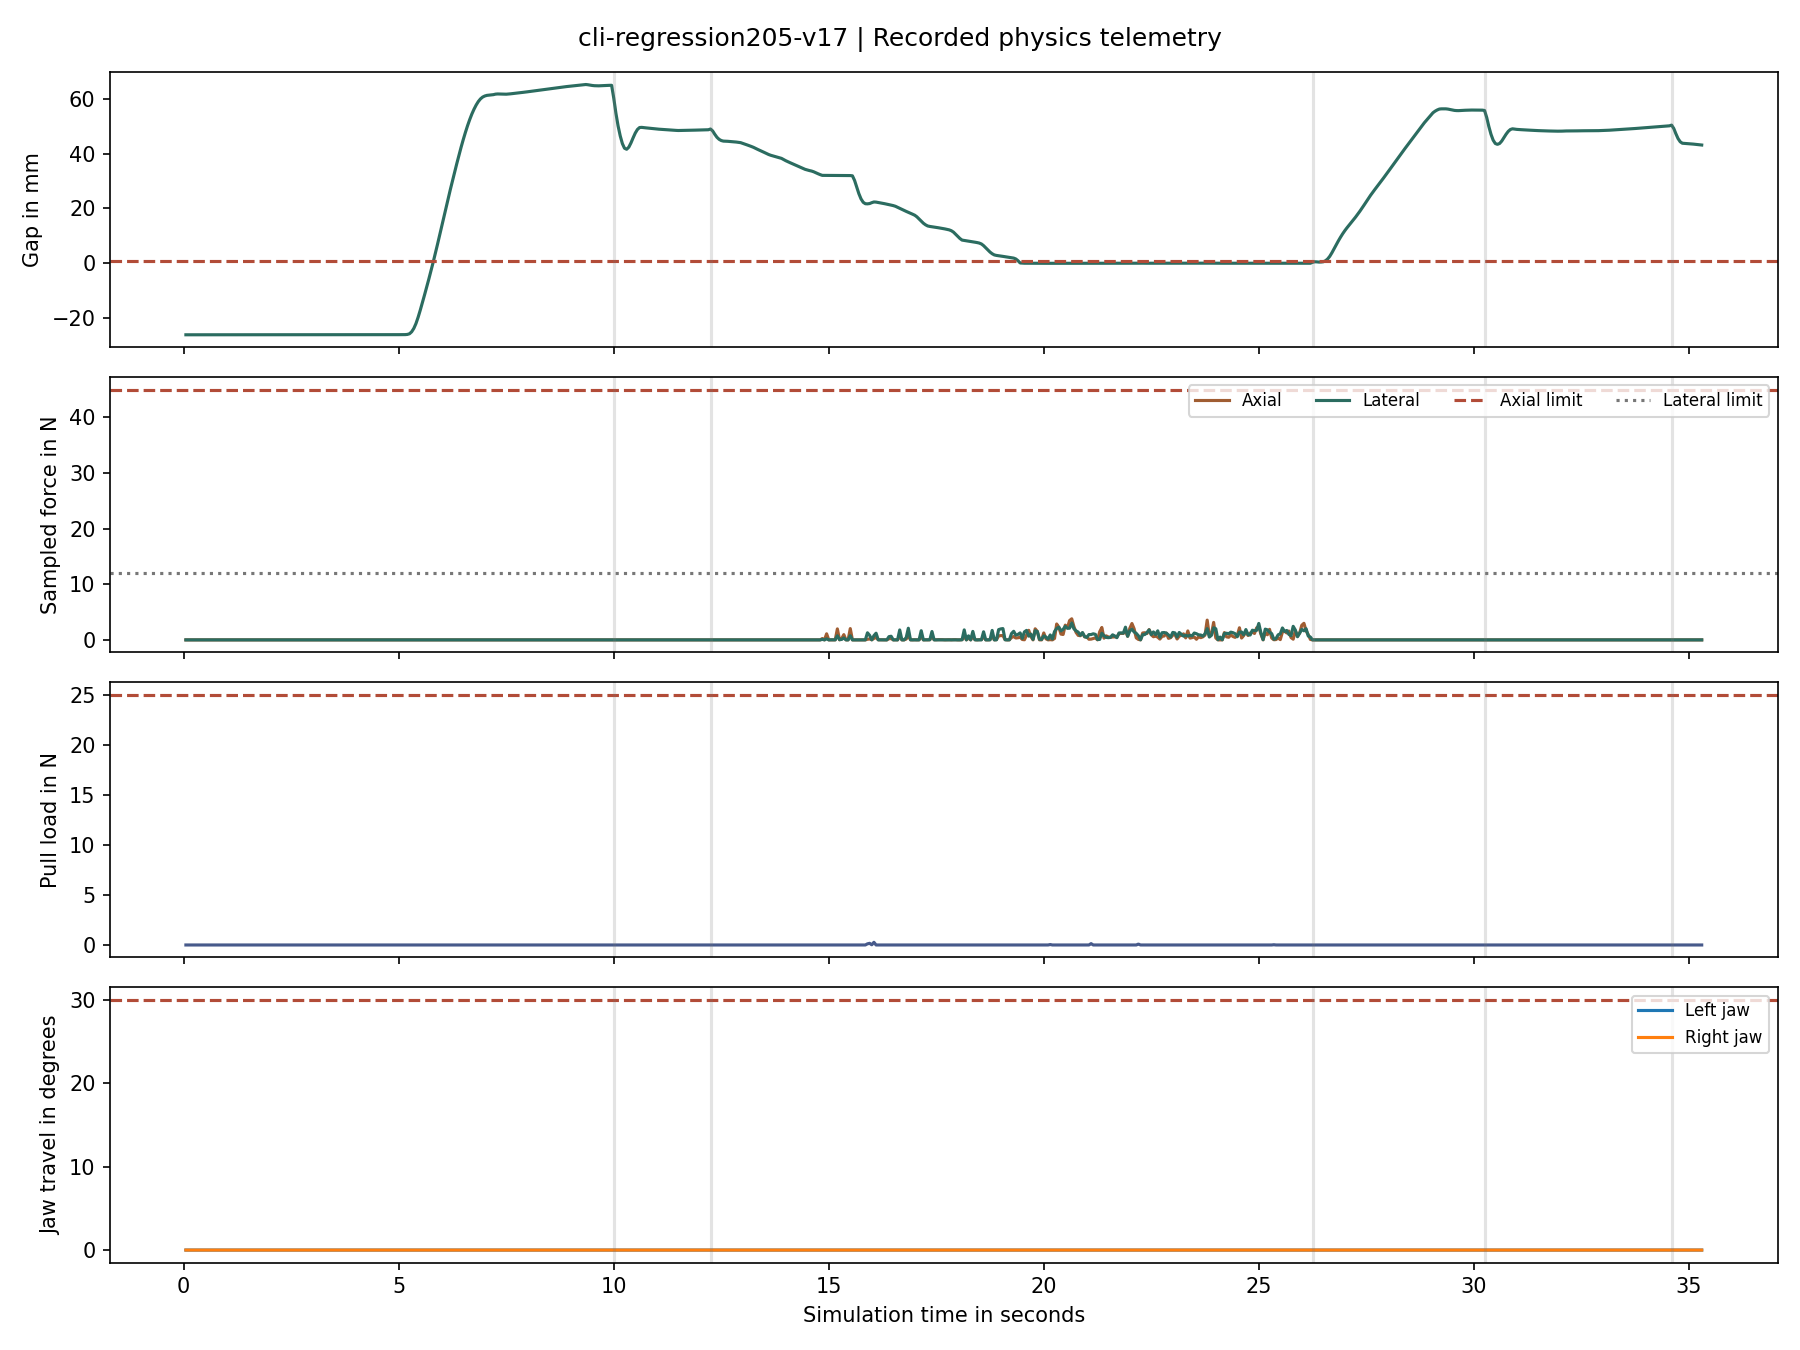
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.250000000000039,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 26.250000000000238,
      "phase": "retract",
      "reason": "Insertion timeout with unresolved gap"
    },
    {
      "time_s": 30.250000000000295,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 34.60000000000017,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": false,
    "seating": false,
    "pin_engagement": false,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": false,
    "observed_motion": false,
    "arms_released": false
  }
}
Recorded run: cli-regression205-v18
The run is ending in the Safe stop phase. The independent verifier is reporting complete_assembly_sequence, sustained_pull, observed_motion, arms_released.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
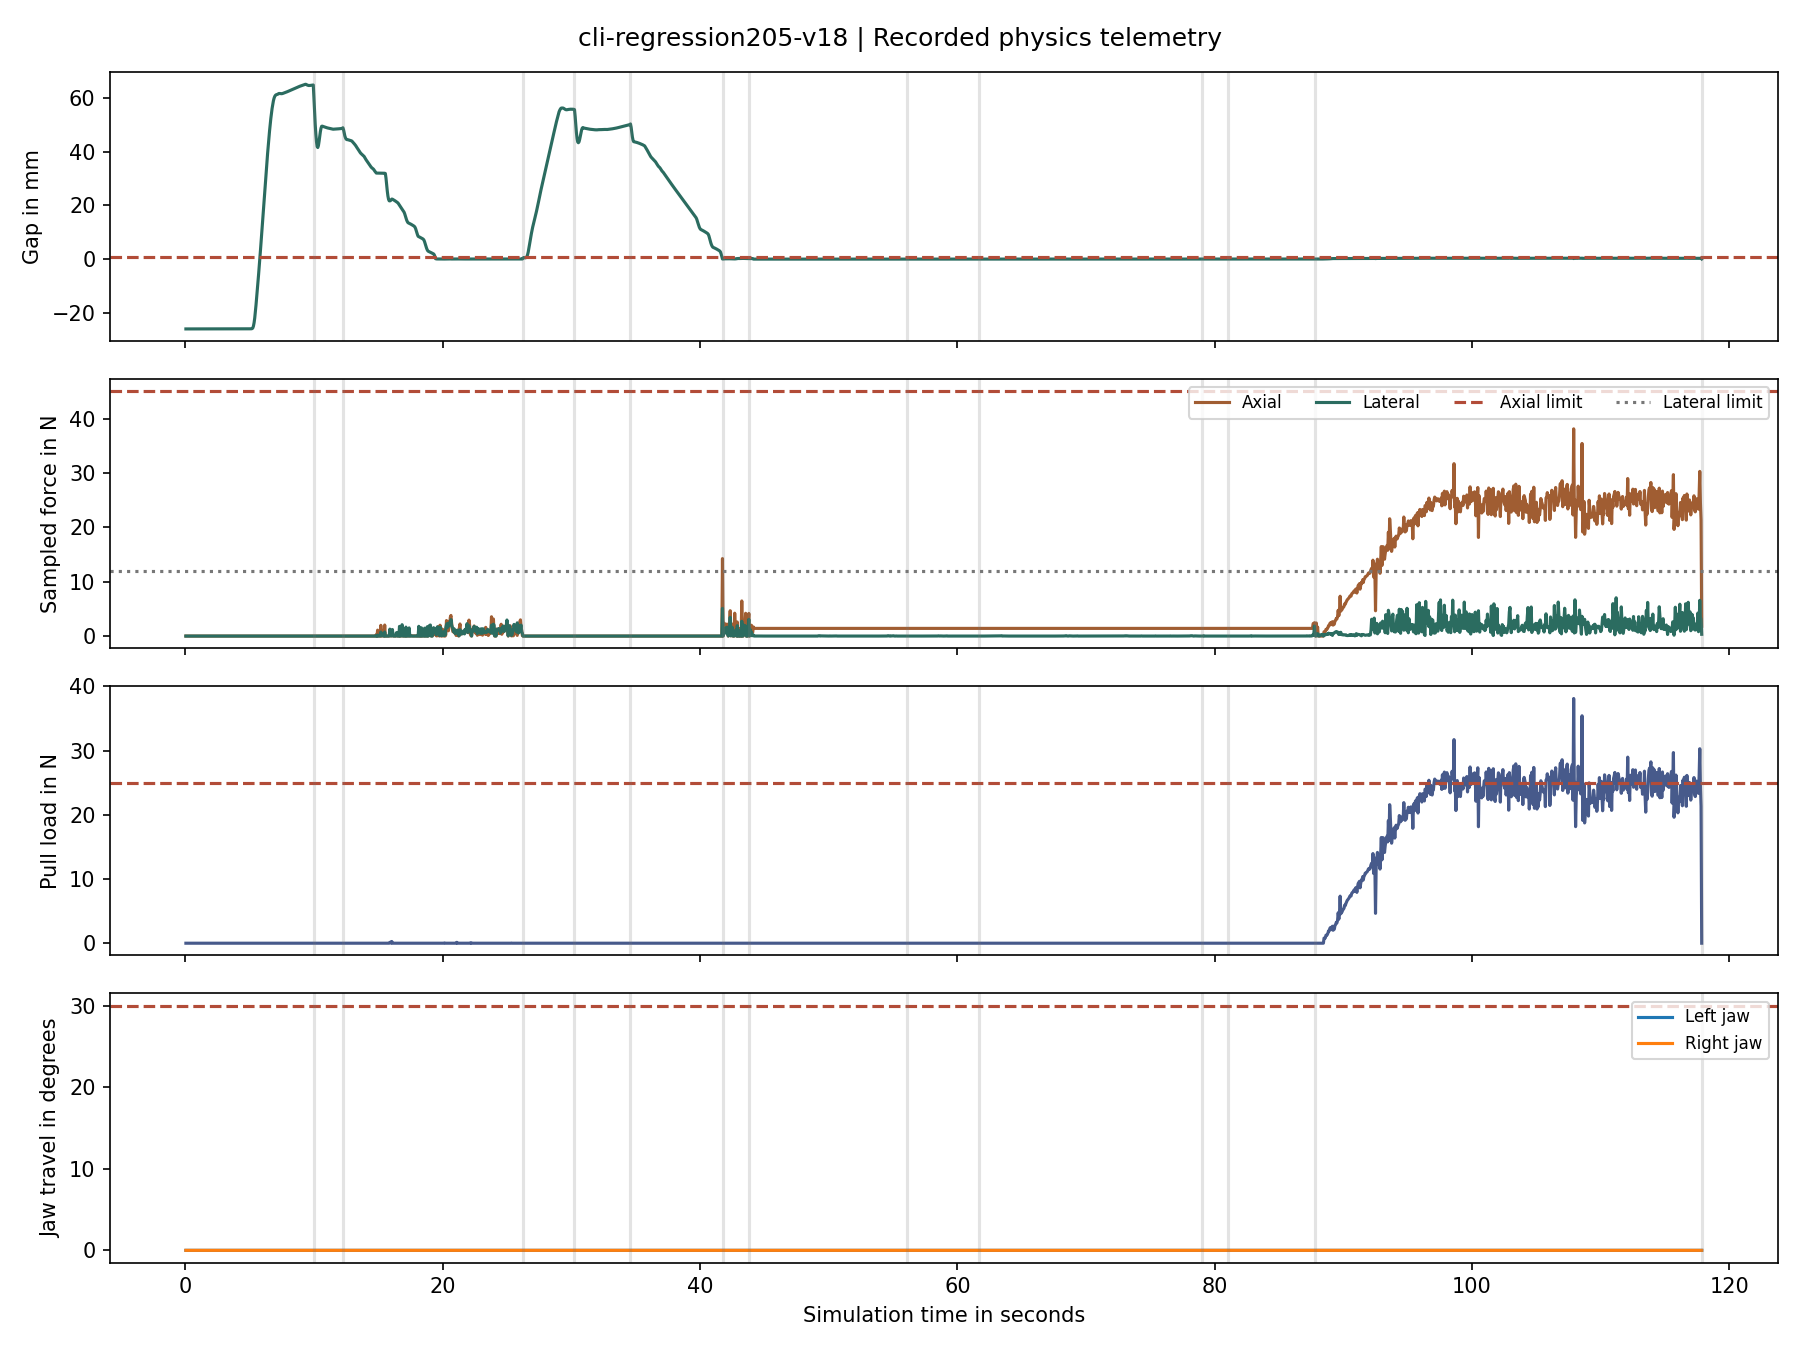
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.250000000000039,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 26.250000000000238,
      "phase": "retract",
      "reason": "Insertion timeout with unresolved gap"
    },
    {
      "time_s": 30.250000000000295,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 34.60000000000017,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 41.79999999999976,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 43.849999999999646,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 56.09999999999895,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 61.69999999999863,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 78.99999999999766,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 81.04999999999754,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 87.79999999999715,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 117.84999999999545,
      "phase": "safe_stop",
      "reason": "Pull proof timeout"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": false,
    "seating": true,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": false,
    "observed_motion": false,
    "arms_released": false
  }
}
Recorded run: cli-regression205-v19
The run is ending in the Release phase. The independent verifier is reporting all implemented task checks passed.
The composite is showing three recorded cameras with measured telemetry labels. The original uninterrupted camera recording is following below.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
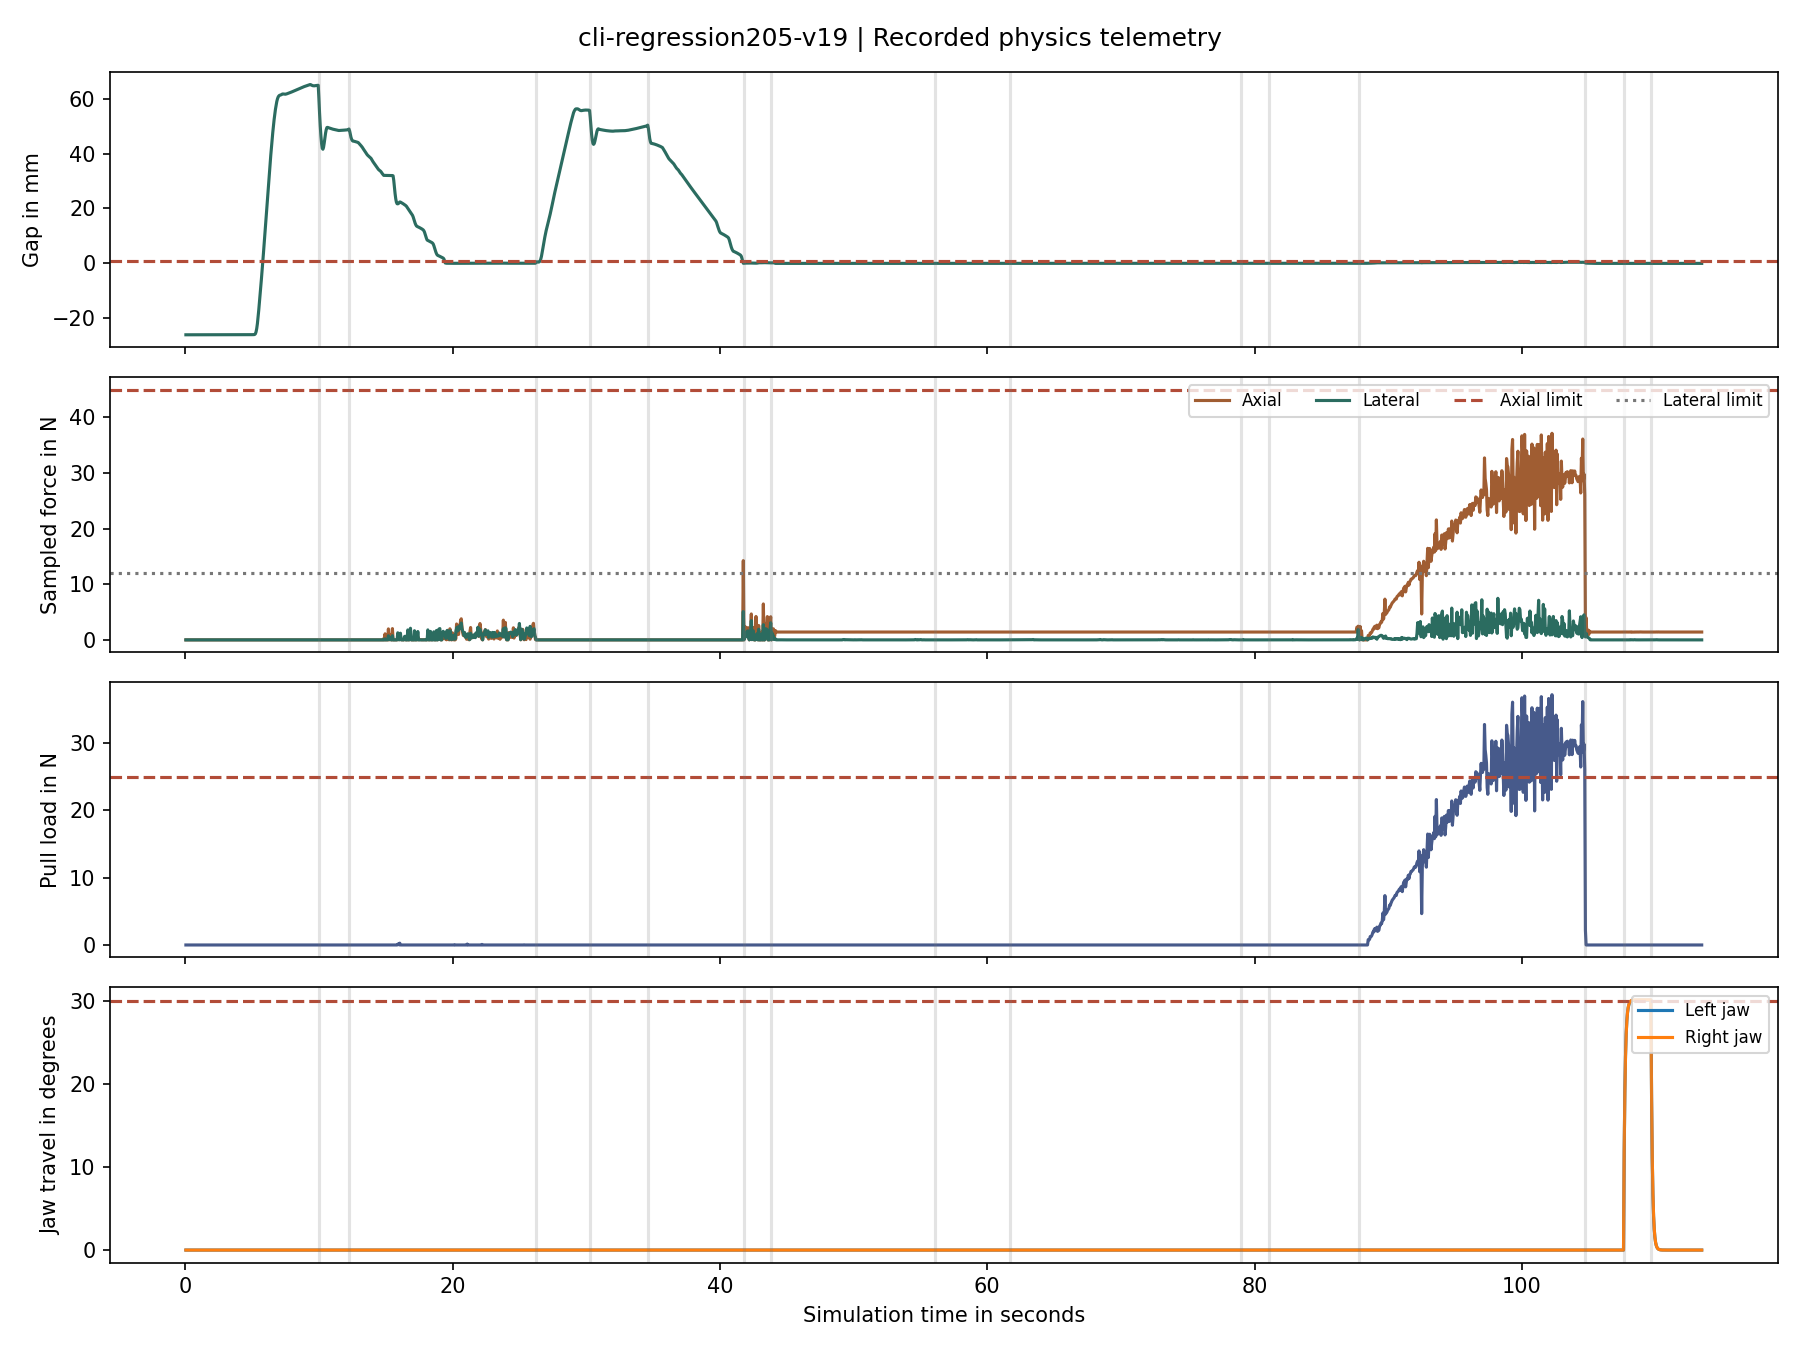
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.250000000000039,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 26.250000000000238,
      "phase": "retract",
      "reason": "Insertion timeout with unresolved gap"
    },
    {
      "time_s": 30.250000000000295,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 34.60000000000017,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 41.79999999999976,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 43.849999999999646,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 56.09999999999895,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 61.69999999999863,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 78.99999999999766,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 81.04999999999754,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 87.79999999999715,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 104.74999999999619,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 107.59999999999603,
      "phase": "motion_open",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 109.64999999999591,
      "phase": "motion_close",
      "reason": "Measured gripper joint travel is reaching 30 degrees"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": true,
    "seating": true,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": true,
    "observed_motion": true,
    "arms_released": true
  }
}
Recorded run: cli-retry-v13
The run is ending in the Release phase. The independent verifier is reporting all implemented task checks passed.
The composite is showing three recorded cameras with measured telemetry labels. The original uninterrupted camera recording is following below.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
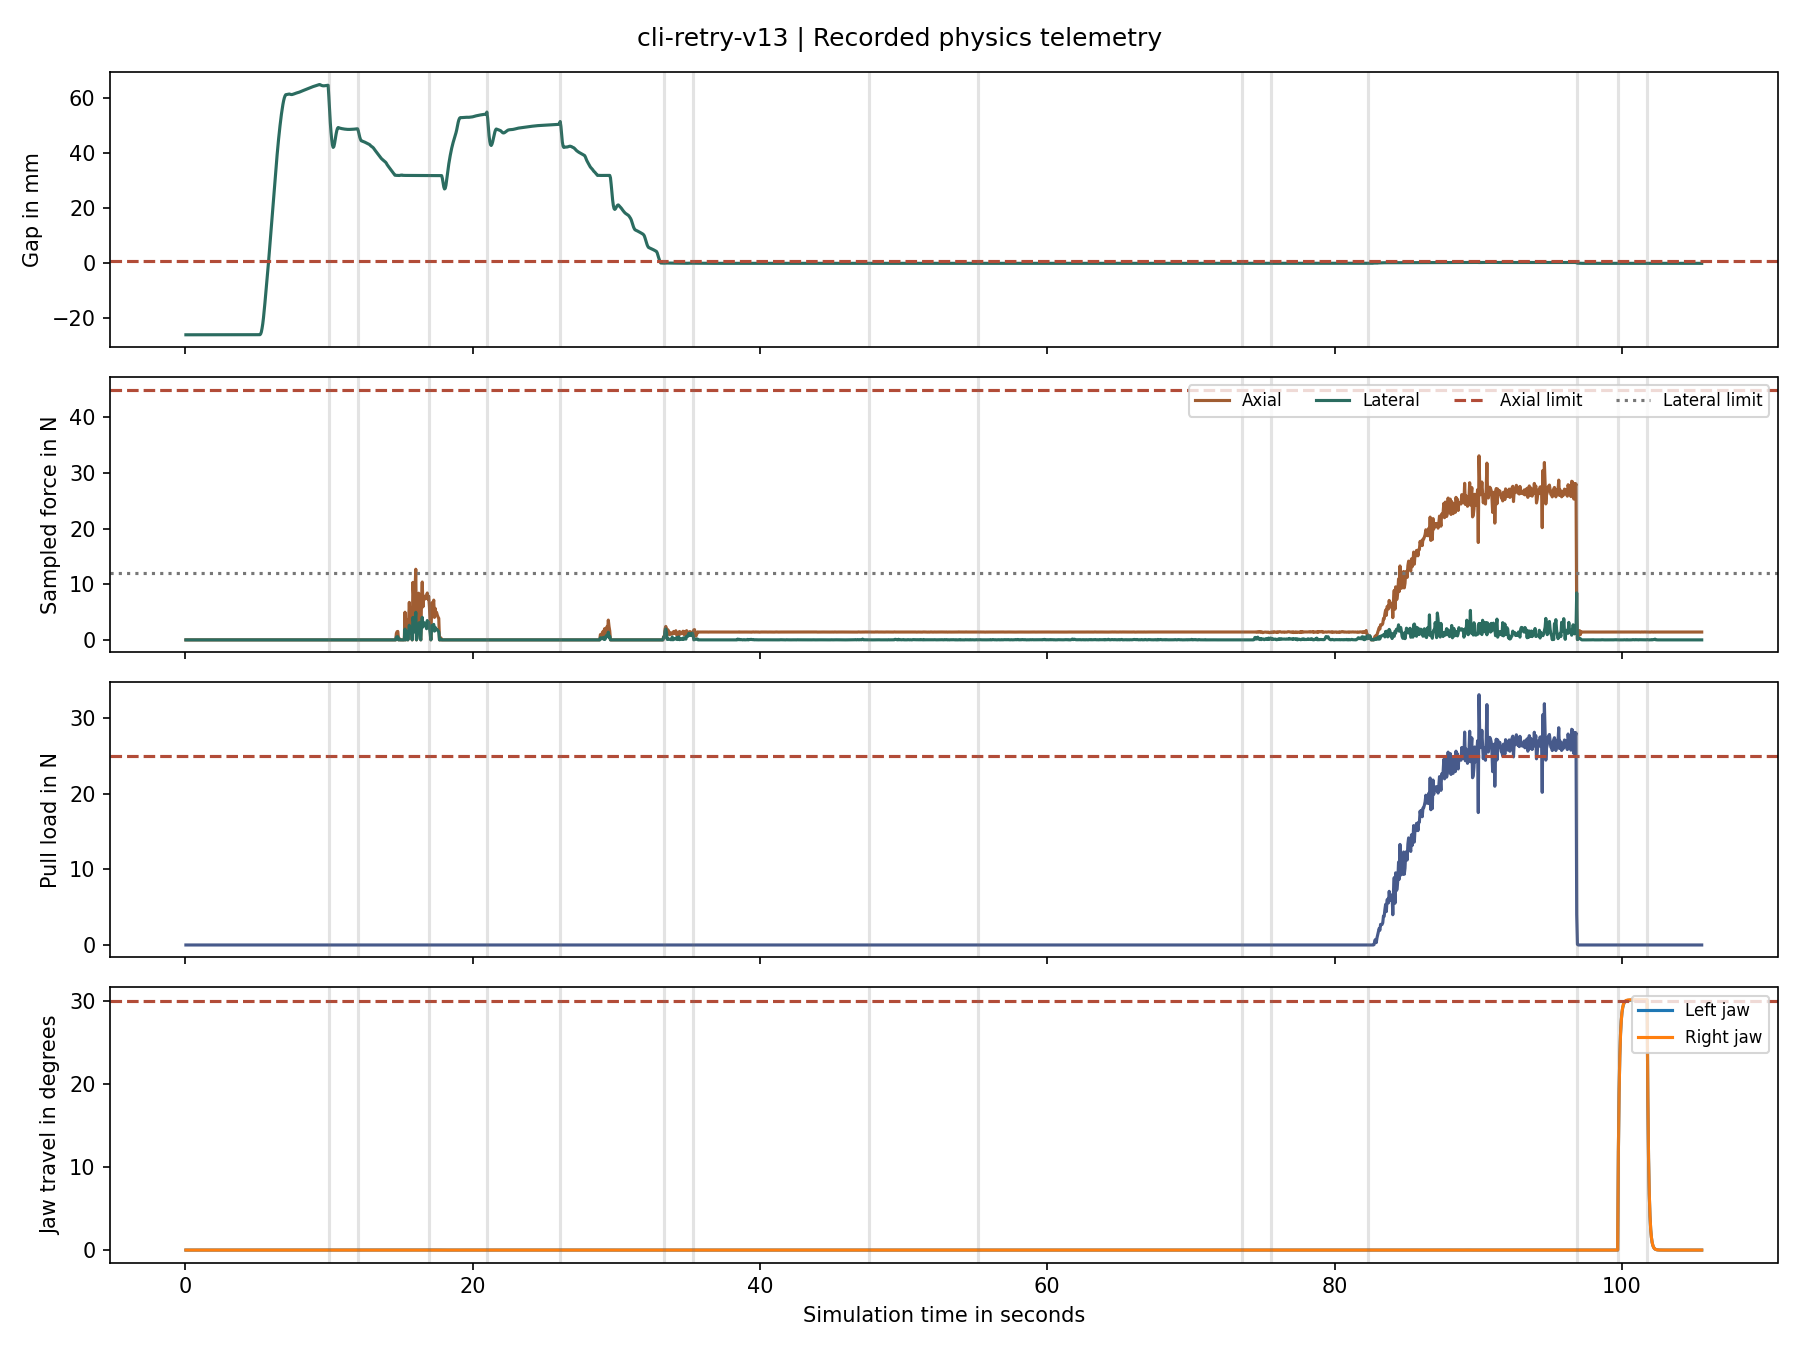
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.000000000000036,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 17.000000000000107,
      "phase": "retract",
      "reason": "Loaded insertion is showing less than 0.5 mm progress in one second"
    },
    {
      "time_s": 21.000000000000163,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 26.100000000000236,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 33.300000000000246,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 35.35000000000013,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 47.59999999999943,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 55.149999999999004,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 73.54999999999797,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 75.59999999999785,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 82.34999999999746,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 96.84999999999664,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 99.69999999999648,
      "phase": "motion_open",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 101.74999999999636,
      "phase": "motion_close",
      "reason": "Measured gripper joint travel is reaching 30 degrees"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": true,
    "seating": true,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": true,
    "observed_motion": true,
    "arms_released": true
  }
}
Recorded run: cli-stabilized-v15
The run is ending in the Release phase. The independent verifier is reporting all implemented task checks passed.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
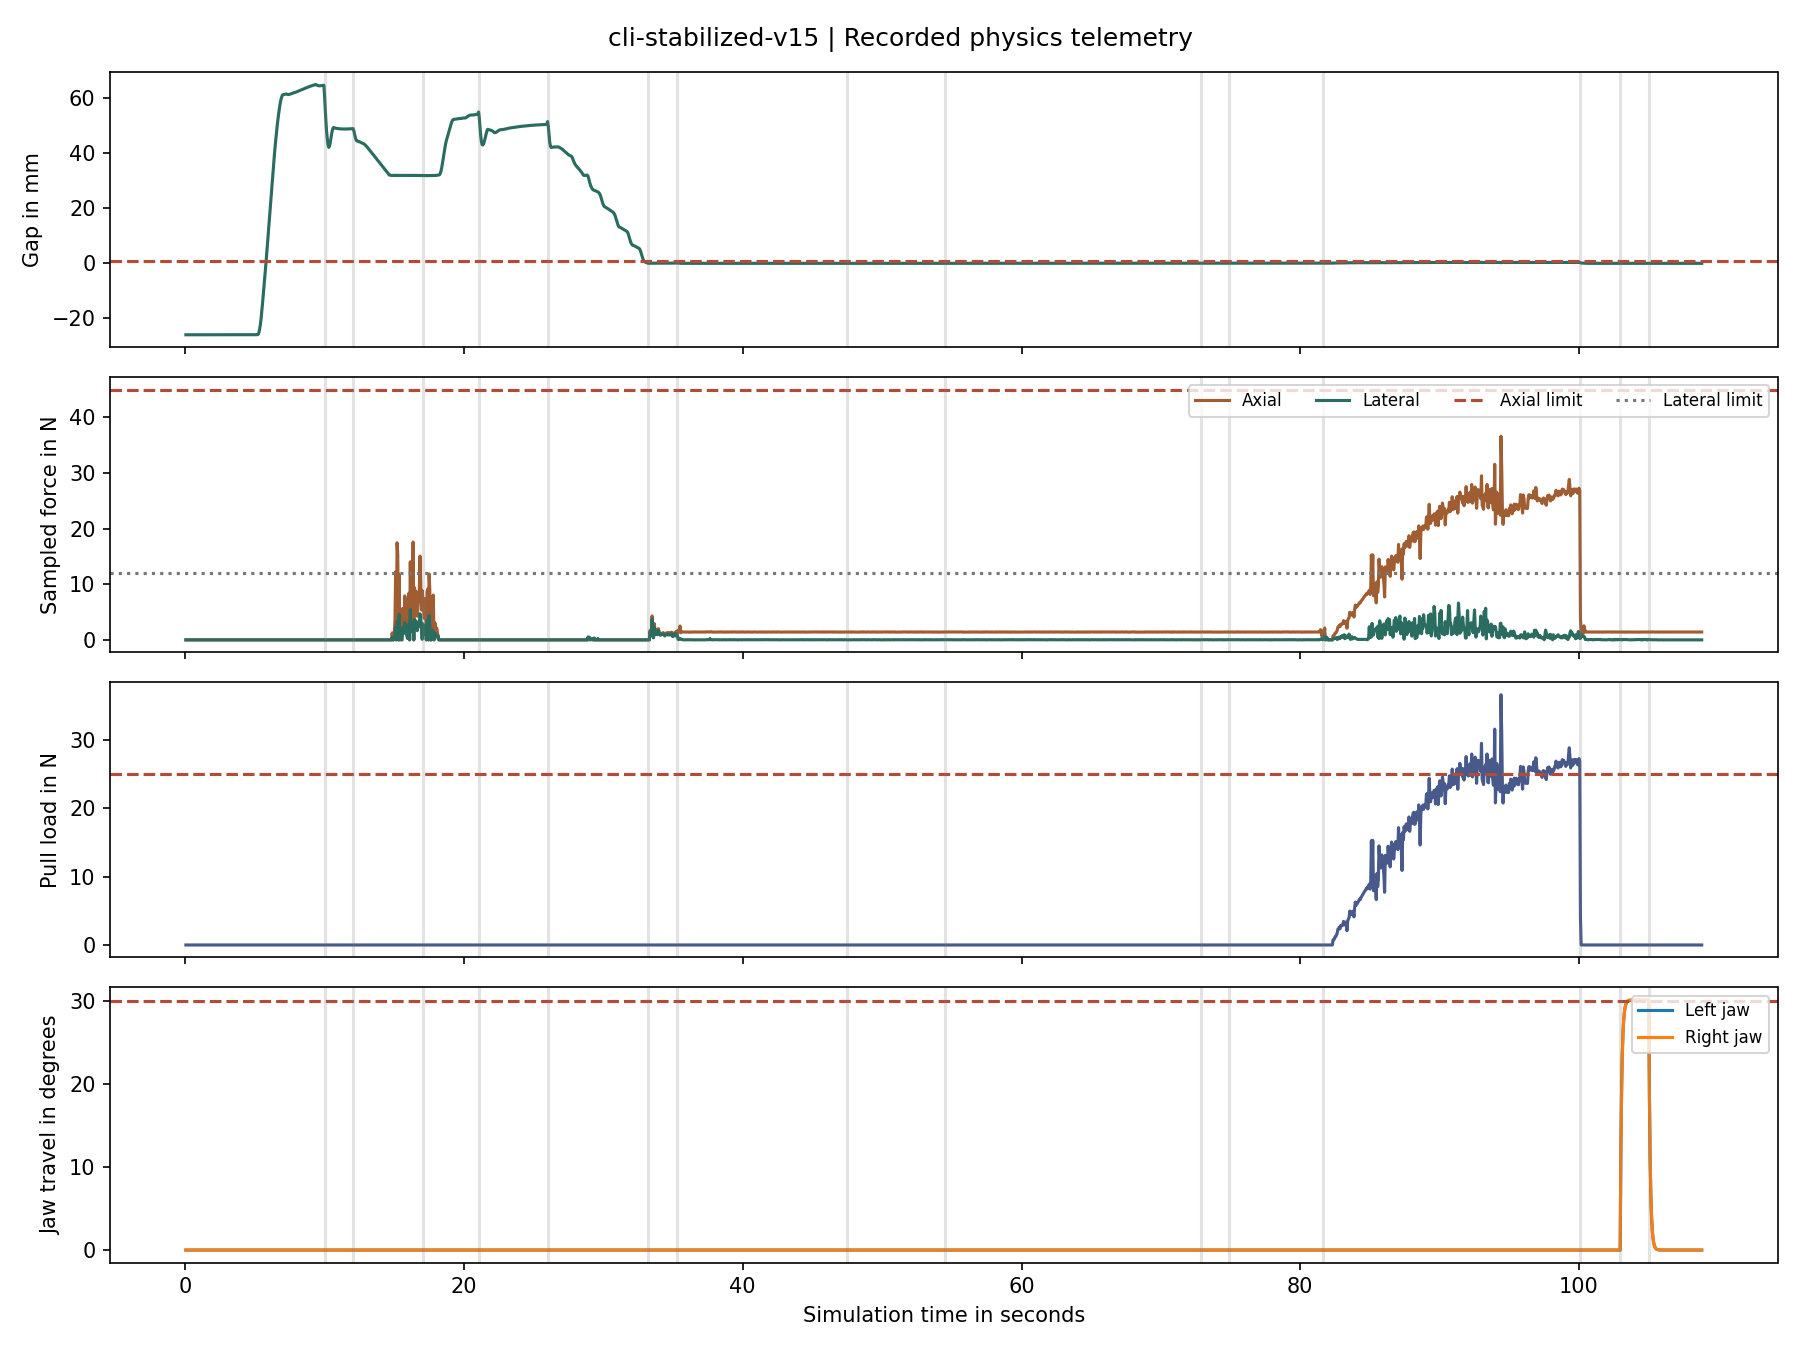
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.050000000000036,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 17.050000000000107,
      "phase": "retract",
      "reason": "Loaded insertion is showing less than 0.5 mm progress in one second"
    },
    {
      "time_s": 21.050000000000164,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 26.000000000000234,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 33.20000000000025,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 35.250000000000135,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 47.49999999999944,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 54.49999999999904,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 72.849999999998,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 74.89999999999789,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 81.6499999999975,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 100.09999999999646,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 102.9499999999963,
      "phase": "motion_open",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 104.99999999999618,
      "phase": "motion_close",
      "reason": "Measured gripper joint travel is reaching 30 degrees"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": true,
    "seating": true,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": true,
    "observed_motion": true,
    "arms_released": true
  }
}
Recorded run: feedback-v3
The run is ending in the Align phase. The independent verifier is reporting telemetry_finite, telemetry_contiguous, contact_force_available, contact_torque_available, complete_assembly_sequence, seating, pin_engagement, sampled_force_limits, sampled_torque_limit, sustained_pull, observed_motion, arms_released.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
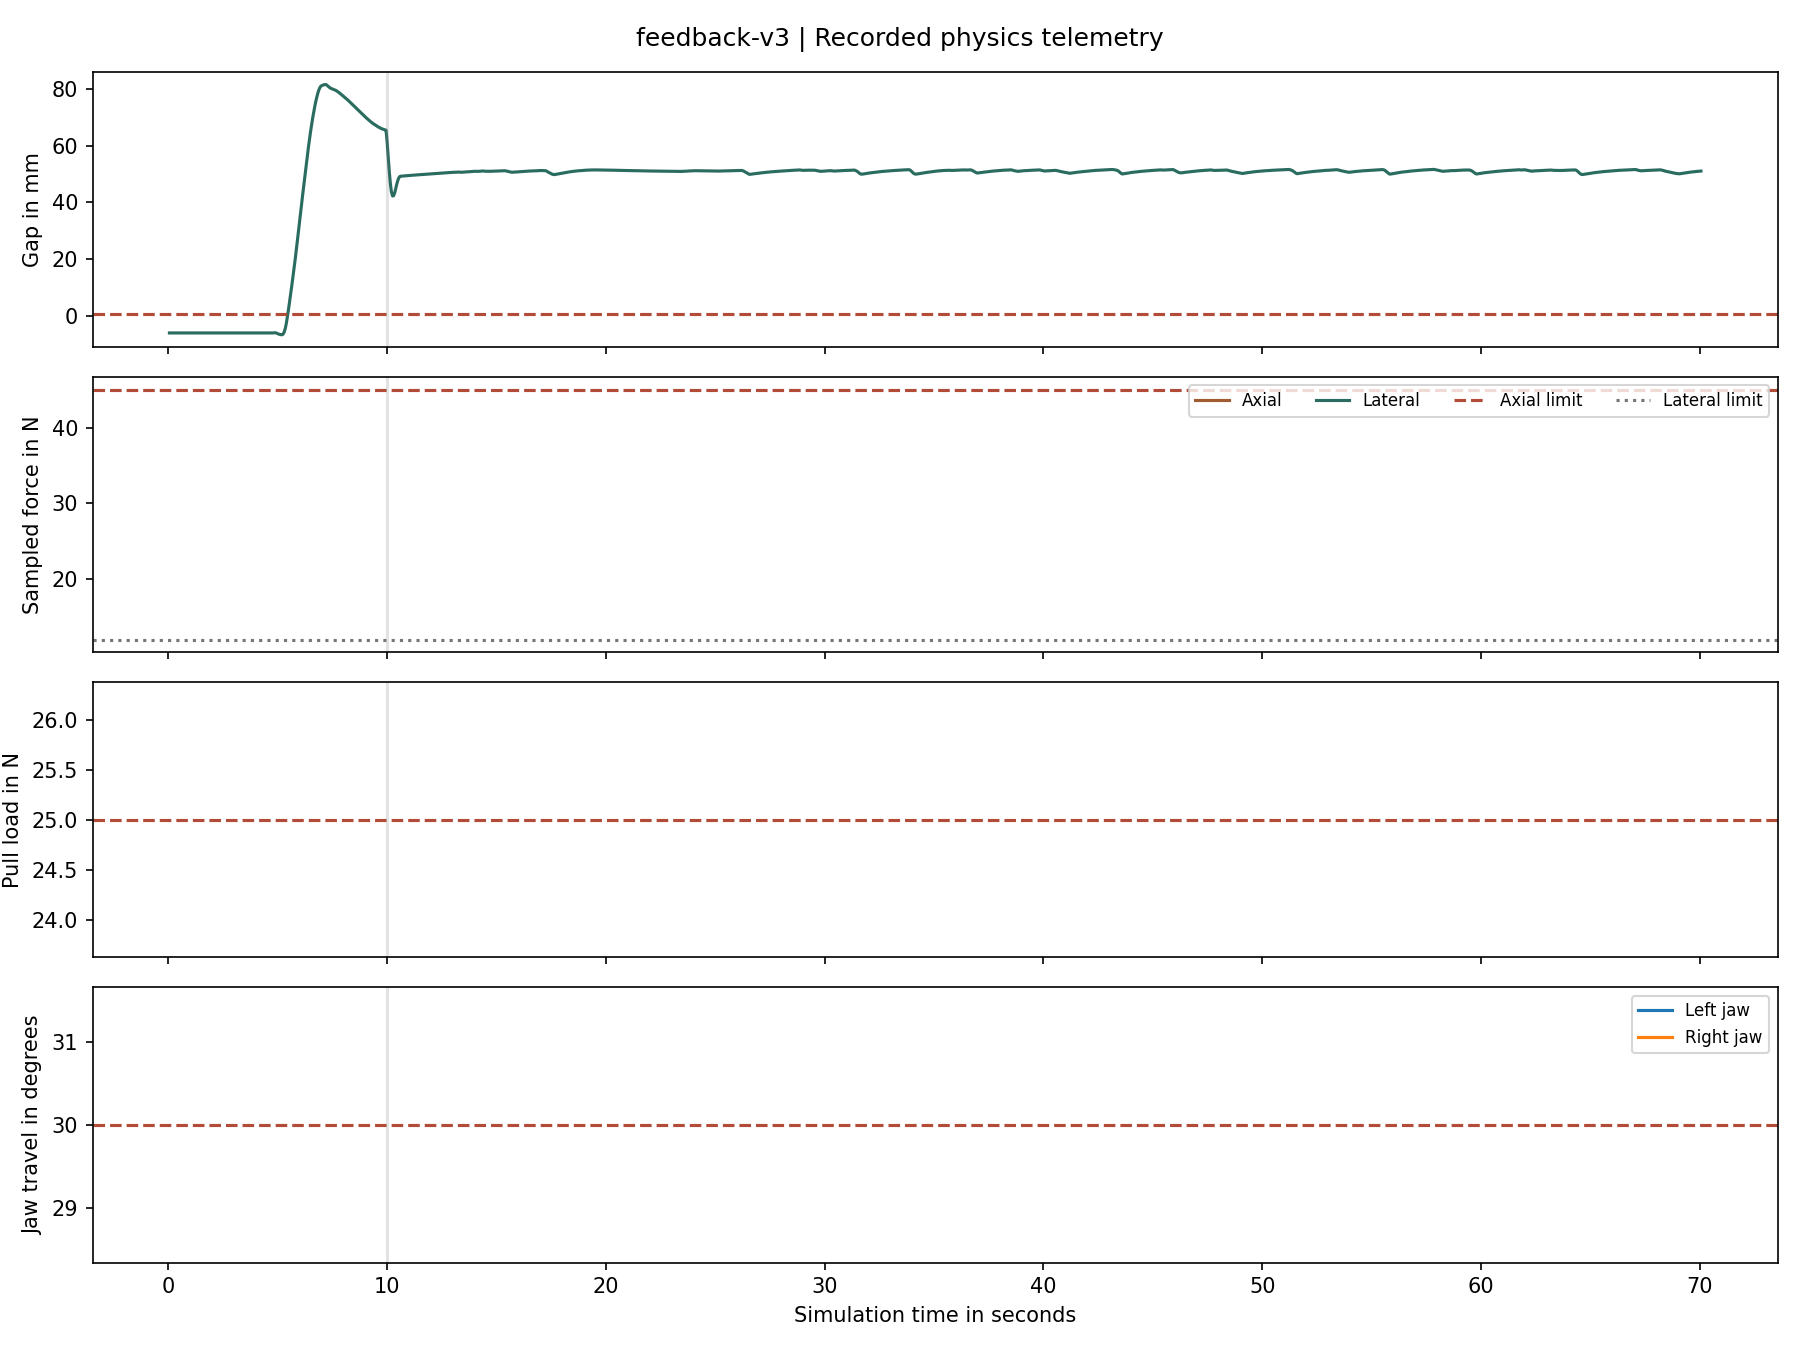
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    }
  ],
  "checks": {
    "telemetry_finite": false,
    "telemetry_contiguous": false,
    "contact_force_available": false,
    "contact_torque_available": false,
    "no_sensor_errors": true,
    "complete_assembly_sequence": false,
    "seating": false,
    "pin_engagement": false,
    "sampled_force_limits": false,
    "sampled_torque_limit": false,
    "sustained_pull": false,
    "observed_motion": false,
    "arms_released": false
  }
}
Recorded run: feedback-v4
The run is ending in the Retract phase. The independent verifier is reporting telemetry_finite, telemetry_contiguous, contact_force_available, contact_torque_available, complete_assembly_sequence, seating, pin_engagement, sampled_force_limits, sampled_torque_limit, sustained_pull, observed_motion, arms_released.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
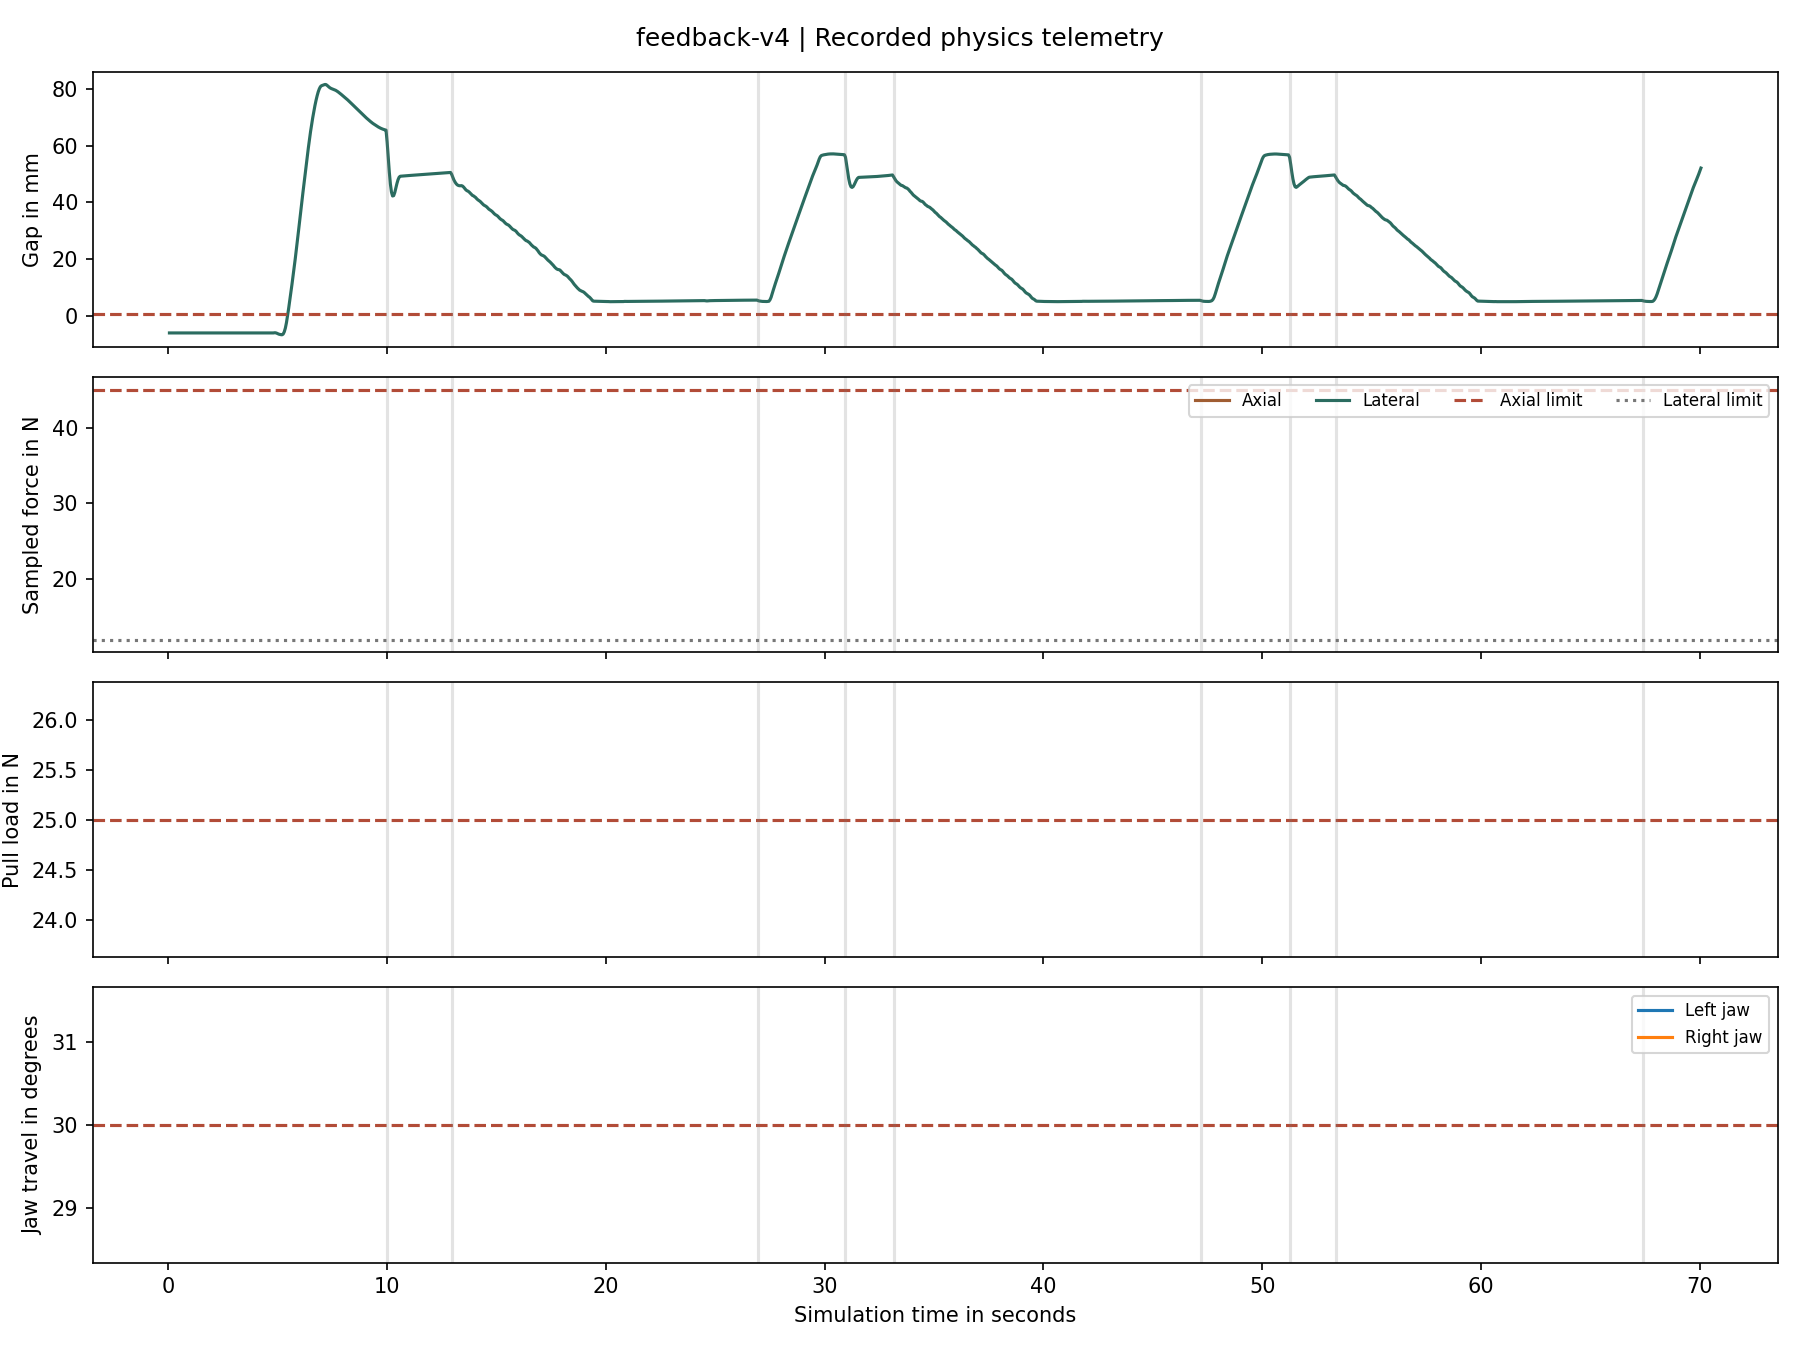
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.950000000000049,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 26.950000000000248,
      "phase": "retract",
      "reason": "Insertion timeout with unresolved gap"
    },
    {
      "time_s": 30.950000000000305,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 33.150000000000254,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 47.199999999999456,
      "phase": "retract",
      "reason": "Insertion timeout with unresolved gap"
    },
    {
      "time_s": 51.249999999999226,
      "phase": "align",
      "reason": "Bounded recovery budget check"
    },
    {
      "time_s": 53.349999999999106,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 67.39999999999831,
      "phase": "retract",
      "reason": "Insertion timeout with unresolved gap"
    }
  ],
  "checks": {
    "telemetry_finite": false,
    "telemetry_contiguous": false,
    "contact_force_available": false,
    "contact_torque_available": false,
    "no_sensor_errors": true,
    "complete_assembly_sequence": false,
    "seating": false,
    "pin_engagement": false,
    "sampled_force_limits": false,
    "sampled_torque_limit": false,
    "sustained_pull": false,
    "observed_motion": false,
    "arms_released": false
  }
}
Recorded run: full-v9
The run is ending in the Safe stop phase. The independent verifier is reporting contact_torque_available, complete_assembly_sequence, sampled_torque_limit, sustained_pull, observed_motion, arms_released.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
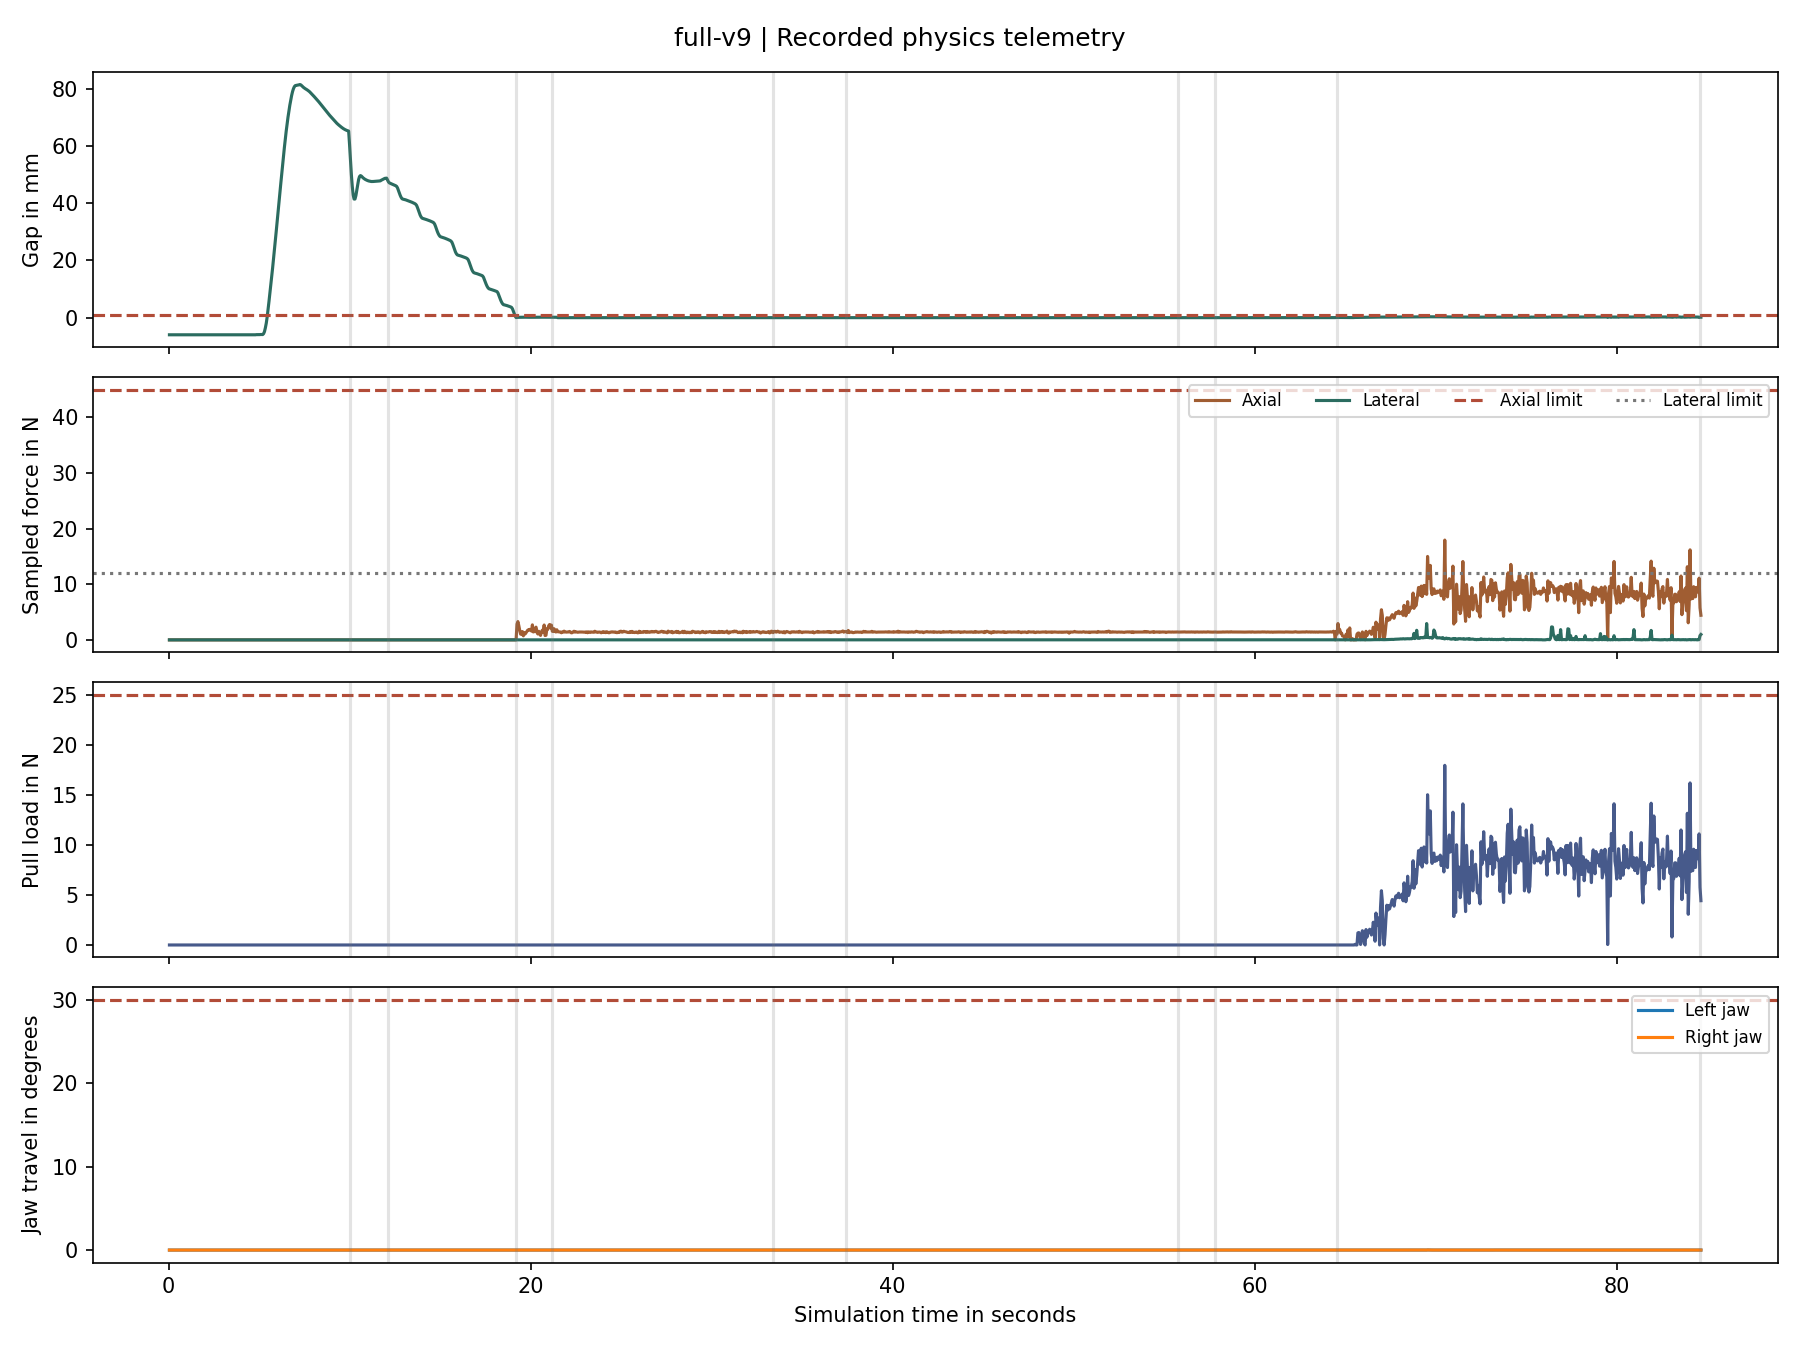
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.100000000000037,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 19.200000000000138,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 21.200000000000166,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 33.40000000000024,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 37.40000000000001,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 55.74999999999897,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 57.79999999999885,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 64.54999999999848,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 84.59999999999734,
      "phase": "safe_stop",
      "reason": "Pull proof timeout"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": false,
    "no_sensor_errors": true,
    "complete_assembly_sequence": false,
    "seating": true,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": false,
    "sustained_pull": false,
    "observed_motion": false,
    "arms_released": false
  }
}
Recorded run: geometry-v2
The run is ending in the Approach phase. The independent verifier is reporting telemetry_finite, telemetry_contiguous, contact_force_available, contact_torque_available, no_sensor_errors, complete_assembly_sequence, seating, pin_engagement, sampled_force_limits, sampled_torque_limit, sustained_pull, observed_motion, arms_released.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
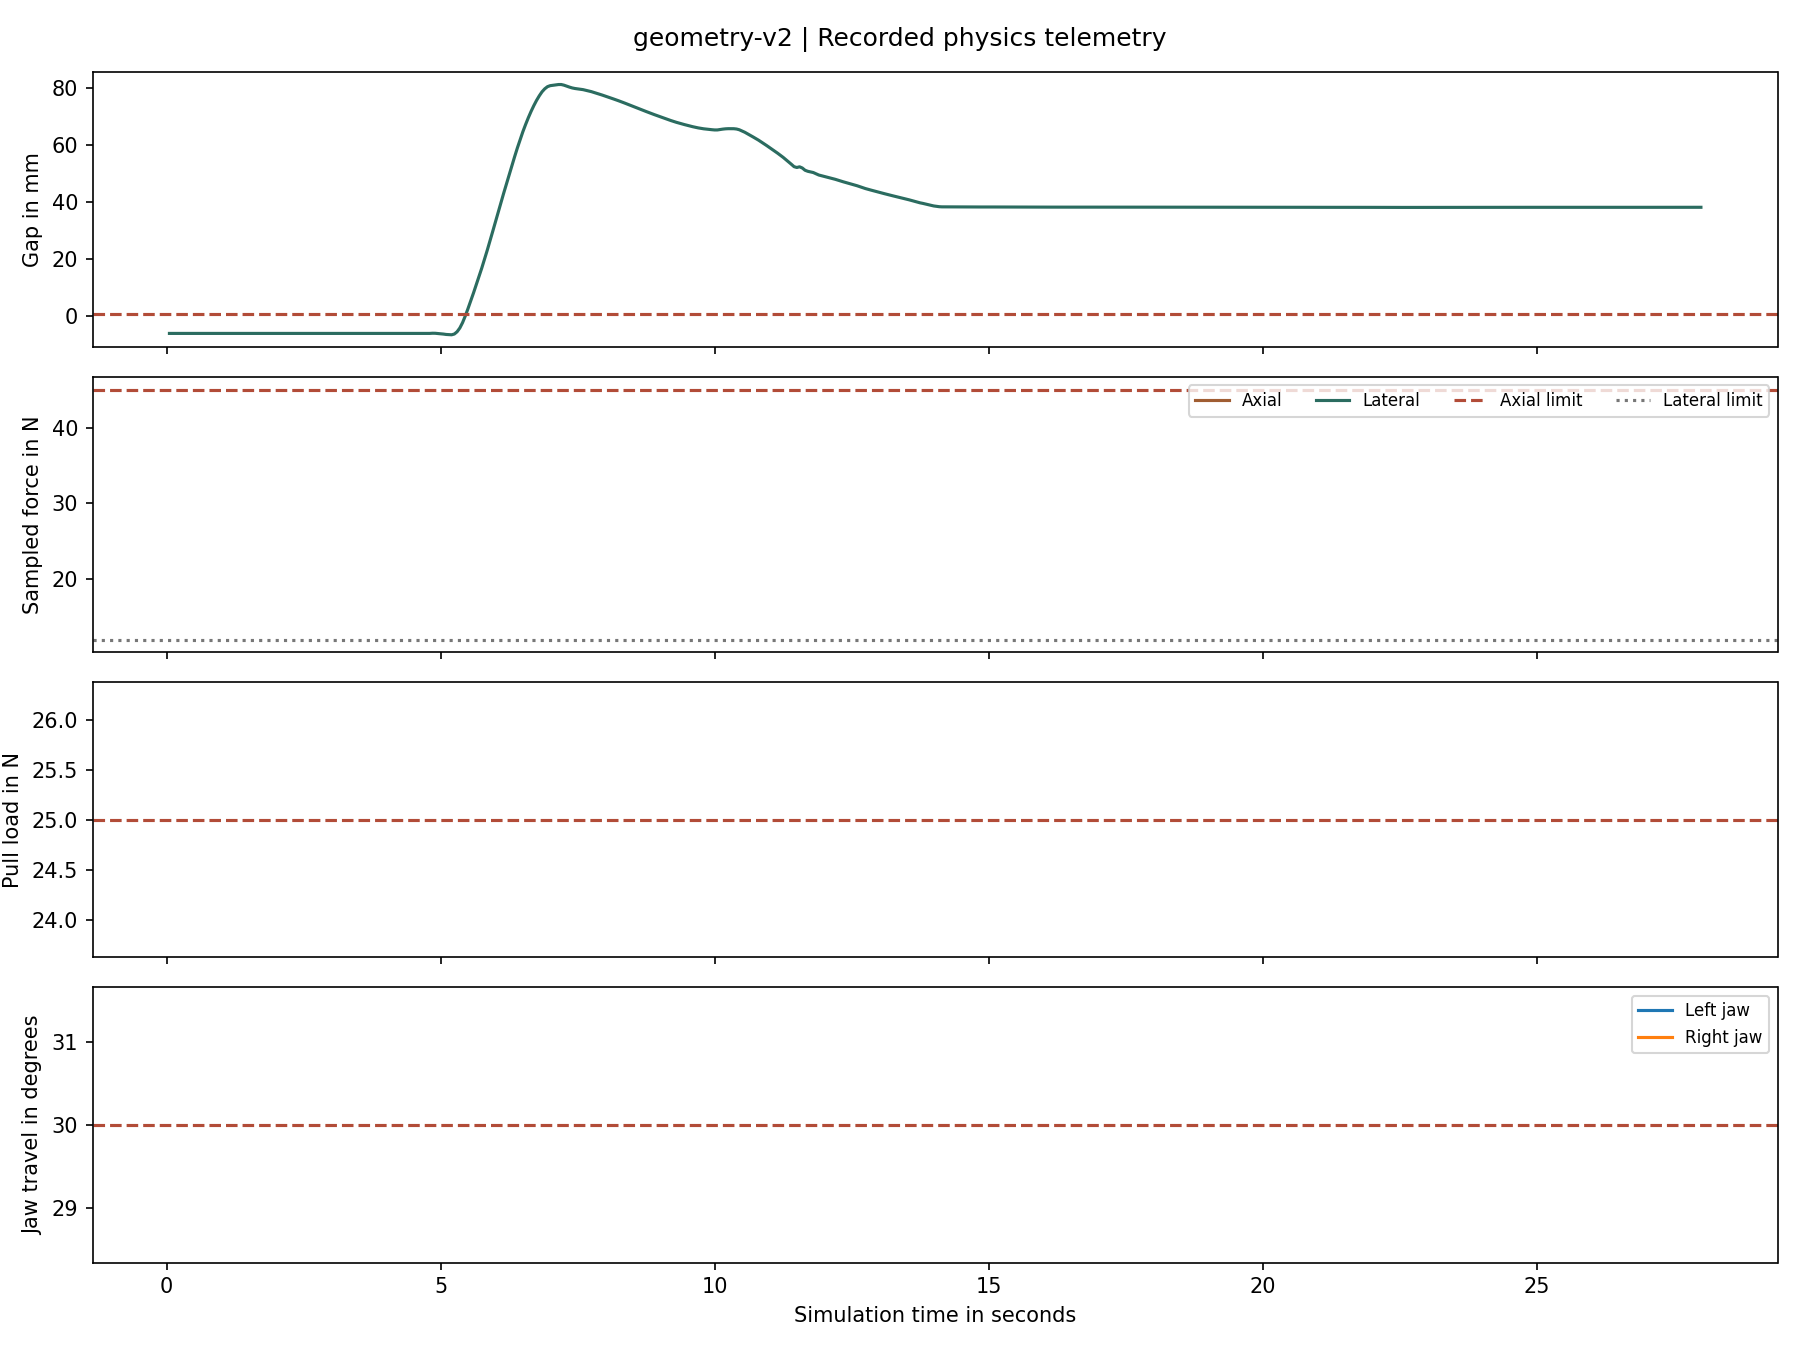
Controller events and independent acceptance checks
{
  "events": [],
  "checks": {
    "telemetry_finite": false,
    "telemetry_contiguous": false,
    "contact_force_available": false,
    "contact_torque_available": false,
    "no_sensor_errors": false,
    "complete_assembly_sequence": false,
    "seating": false,
    "pin_engagement": false,
    "sampled_force_limits": false,
    "sampled_torque_limit": false,
    "sustained_pull": false,
    "observed_motion": false,
    "arms_released": false
  }
}
Recorded run: pin-v6
The run is ending in the Safe stop phase. The independent verifier is reporting telemetry_finite, telemetry_contiguous, contact_force_available, contact_torque_available, complete_assembly_sequence, seating, sampled_force_limits, sampled_torque_limit, sustained_pull, observed_motion, arms_released.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
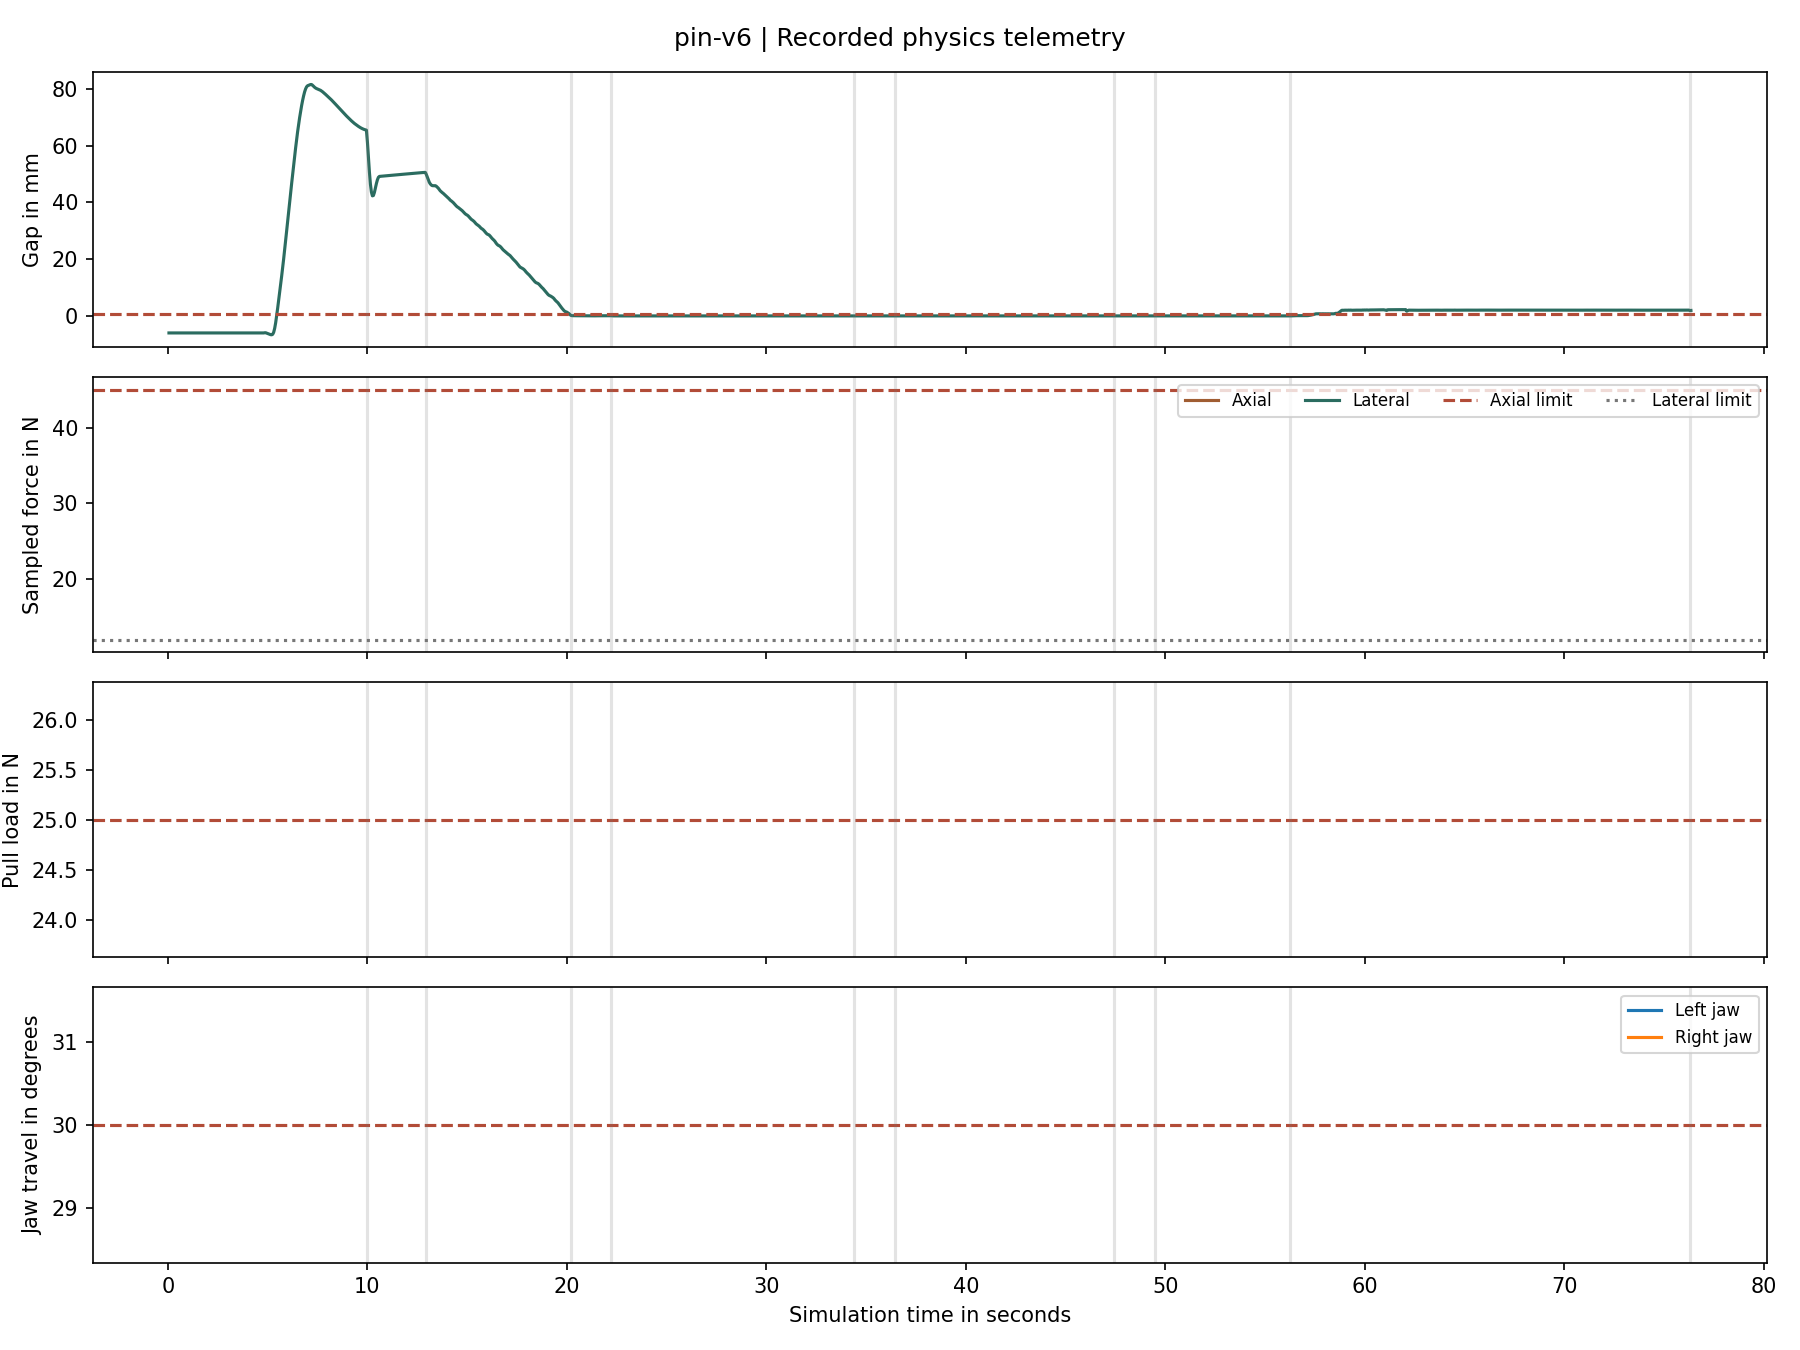
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 12.950000000000049,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 20.200000000000152,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 22.20000000000018,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 34.40000000000018,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 36.45000000000007,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 47.44999999999944,
      "phase": "verify_pin",
      "reason": "Measured cross pin position is within tolerance"
    },
    {
      "time_s": 49.499999999999325,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 56.24999999999894,
      "phase": "pull_test",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 76.29999999999781,
      "phase": "safe_stop",
      "reason": "Pull proof timeout"
    }
  ],
  "checks": {
    "telemetry_finite": false,
    "telemetry_contiguous": false,
    "contact_force_available": false,
    "contact_torque_available": false,
    "no_sensor_errors": true,
    "complete_assembly_sequence": false,
    "seating": false,
    "pin_engagement": true,
    "sampled_force_limits": false,
    "sampled_torque_limit": false,
    "sustained_pull": false,
    "observed_motion": false,
    "arms_released": false
  }
}
Recorded run: pin-v7
The run is ending in the Safe stop phase. The independent verifier is reporting telemetry_finite, telemetry_contiguous, contact_force_available, contact_torque_available, complete_assembly_sequence, seating, pin_engagement, sampled_force_limits, sampled_torque_limit, sustained_pull, observed_motion, arms_released.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
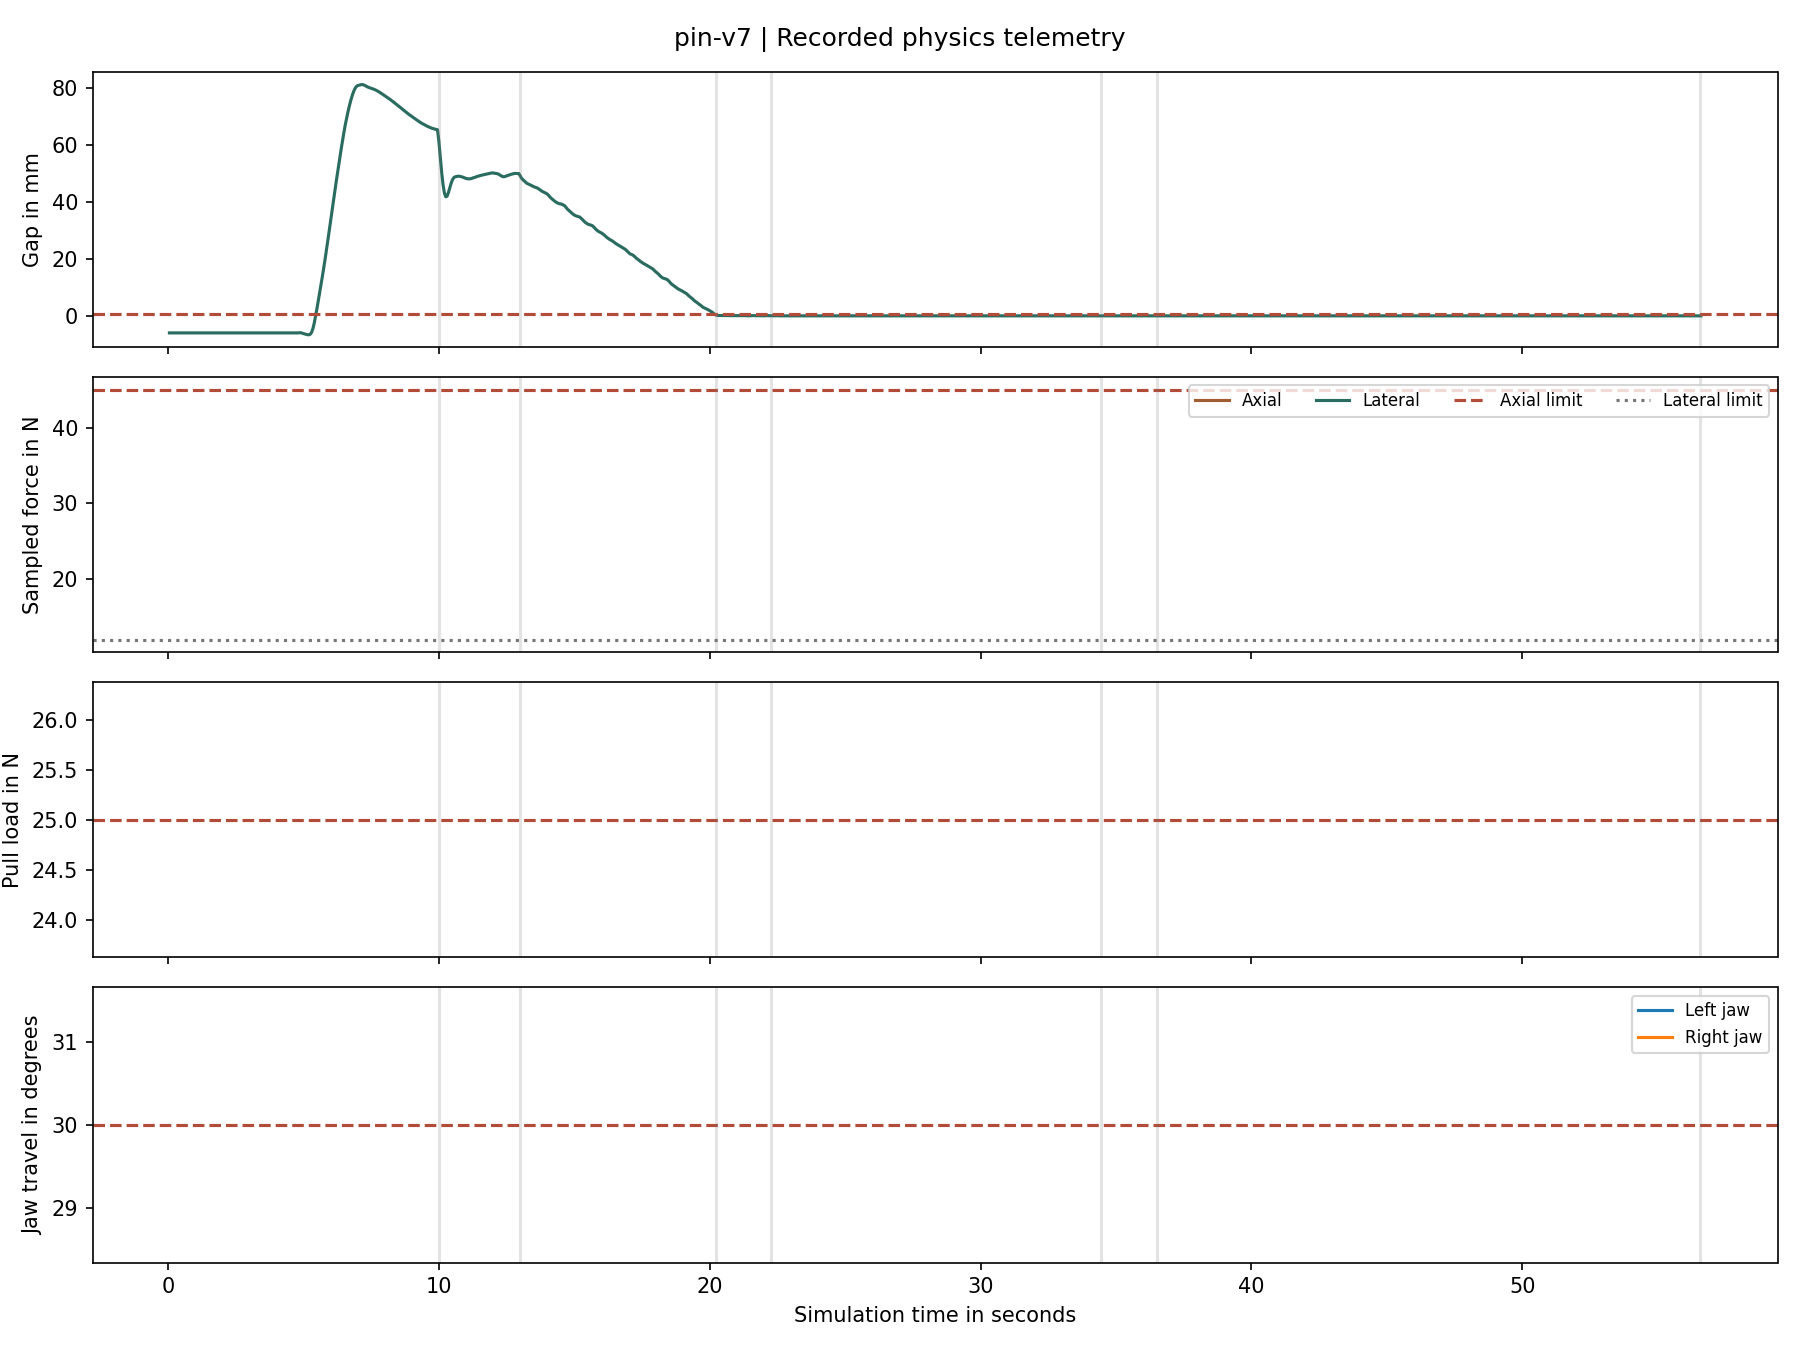
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 13.00000000000005,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 20.250000000000153,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 22.25000000000018,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 34.45000000000018,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 36.500000000000064,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 56.549999999998924,
      "phase": "safe_stop",
      "reason": "Physical retaining pin did not seat"
    }
  ],
  "checks": {
    "telemetry_finite": false,
    "telemetry_contiguous": false,
    "contact_force_available": false,
    "contact_torque_available": false,
    "no_sensor_errors": true,
    "complete_assembly_sequence": false,
    "seating": false,
    "pin_engagement": false,
    "sampled_force_limits": false,
    "sampled_torque_limit": false,
    "sustained_pull": false,
    "observed_motion": false,
    "arms_released": false
  }
}
Recorded run: pin-v8
The run is ending in the Safe stop phase. The independent verifier is reporting telemetry_finite, telemetry_contiguous, contact_force_available, contact_torque_available, complete_assembly_sequence, seating, pin_engagement, sampled_force_limits, sampled_torque_limit, sustained_pull, observed_motion, arms_released.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
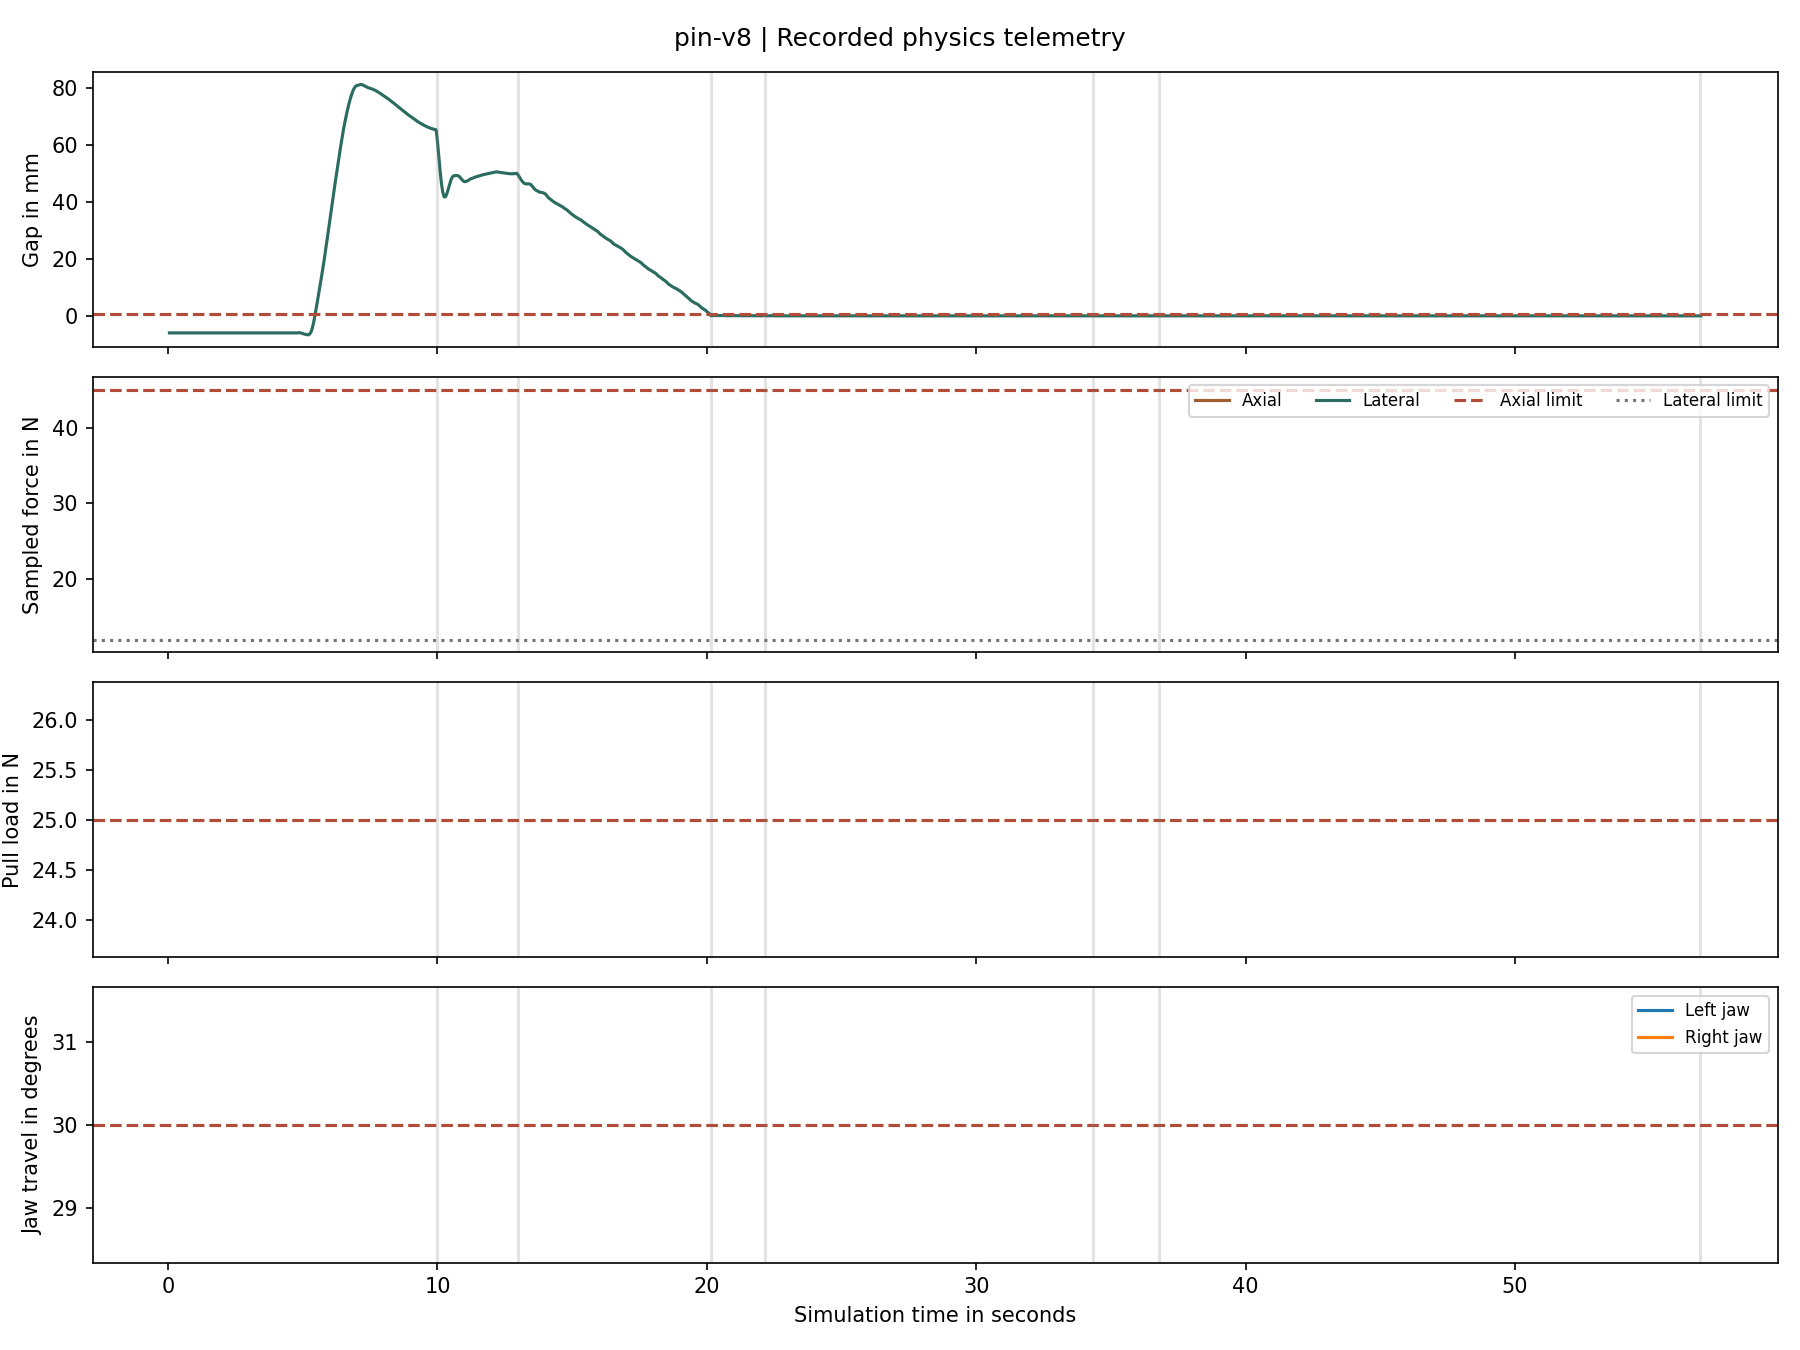
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 13.00000000000005,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 20.15000000000015,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    },
    {
      "time_s": 22.15000000000018,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 34.350000000000186,
      "phase": "pin_align",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 36.80000000000005,
      "phase": "pin_insert",
      "reason": "Physical pin is aligned with cross holes"
    },
    {
      "time_s": 56.84999999999891,
      "phase": "safe_stop",
      "reason": "Physical retaining pin did not seat"
    }
  ],
  "checks": {
    "telemetry_finite": false,
    "telemetry_contiguous": false,
    "contact_force_available": false,
    "contact_torque_available": false,
    "no_sensor_errors": true,
    "complete_assembly_sequence": false,
    "seating": false,
    "pin_engagement": false,
    "sampled_force_limits": false,
    "sampled_torque_limit": false,
    "sustained_pull": false,
    "observed_motion": false,
    "arms_released": false
  }
}
Recorded run: pull-controller-probe-v12
The run is ending in the Safe stop phase. The independent verifier is reporting complete_assembly_sequence, observed_motion, arms_released.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
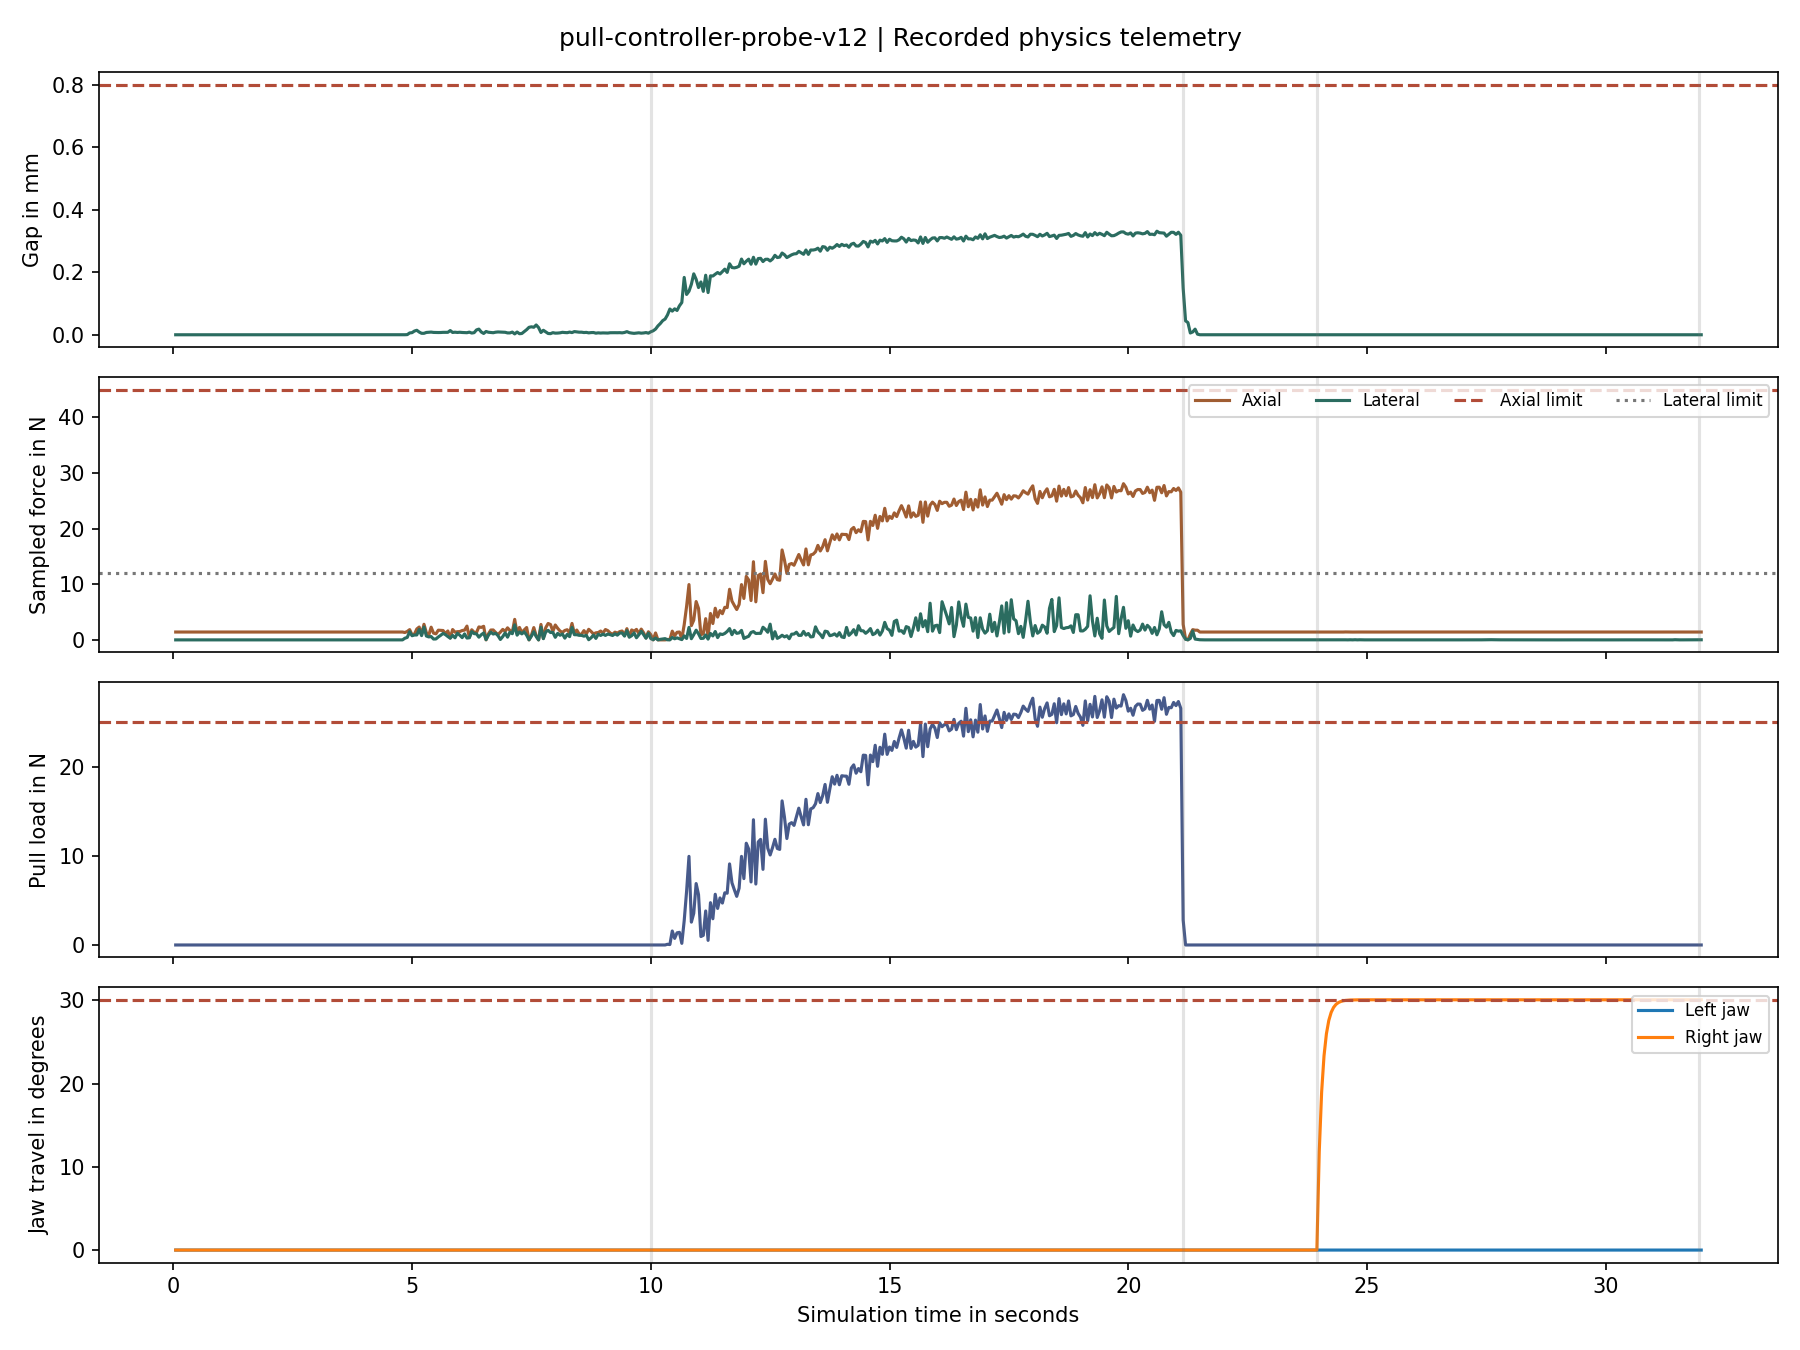
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "pull_test",
      "reason": "Grasp completed"
    },
    {
      "time_s": 21.150000000000166,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 23.950000000000205,
      "phase": "motion_open",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 31.95000000000032,
      "phase": "safe_stop",
      "reason": "Gripper motion did not reach commanded angle"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": false,
    "seating": true,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": true,
    "observed_motion": false,
    "arms_released": false
  }
}
Recorded run: pull-controller-probe-v13
The run is ending in the Release phase. The independent verifier is reporting complete_assembly_sequence.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
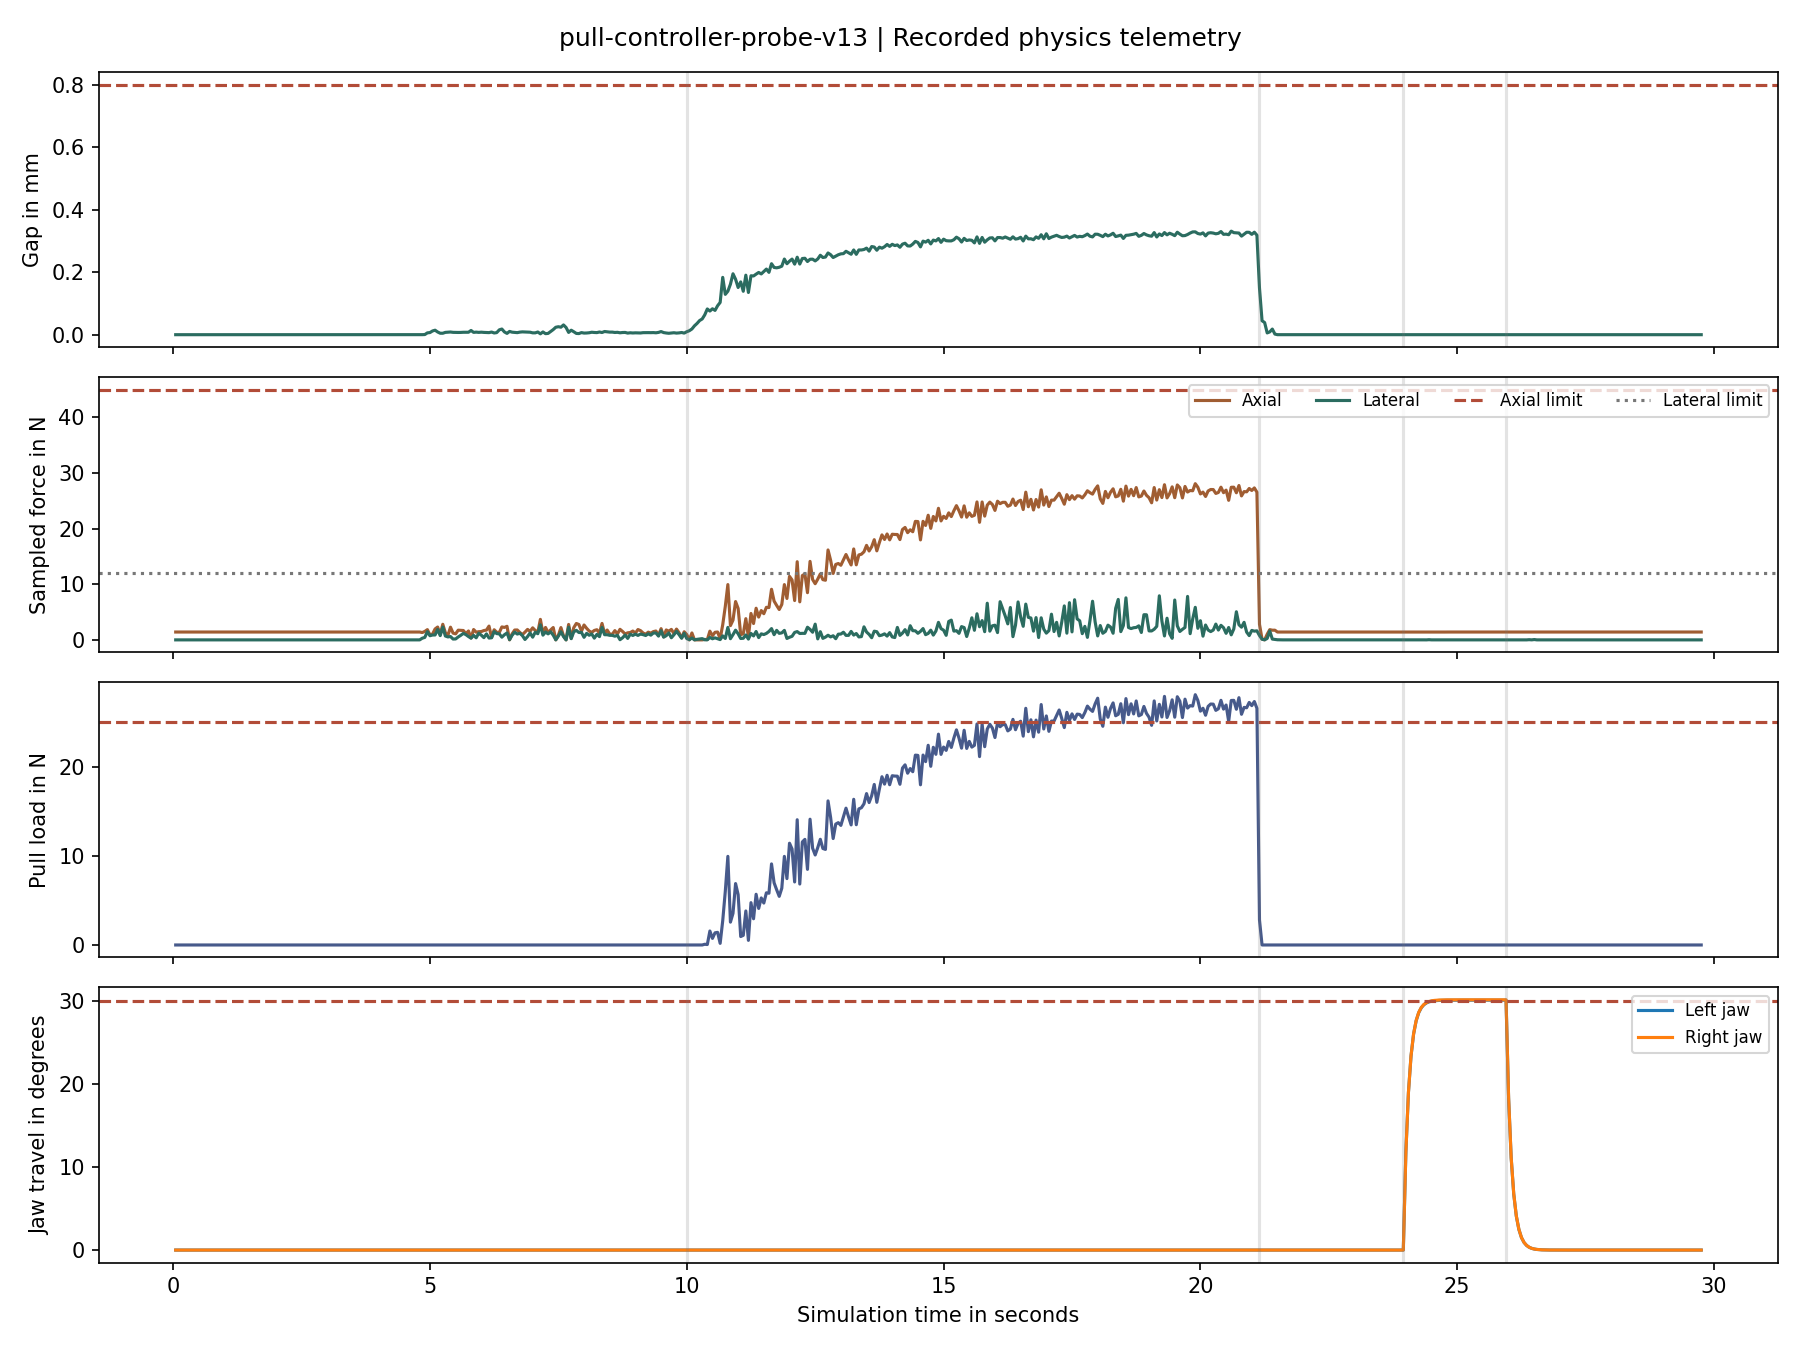
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "pull_test",
      "reason": "Grasp completed"
    },
    {
      "time_s": 21.150000000000166,
      "phase": "transfer",
      "reason": "Executing bounded collision clearance waypoints"
    },
    {
      "time_s": 23.950000000000205,
      "phase": "motion_open",
      "reason": "Waypoint transfer completed"
    },
    {
      "time_s": 25.950000000000234,
      "phase": "motion_close",
      "reason": "Measured gripper joint travel is reaching 30 degrees"
    }
  ],
  "checks": {
    "telemetry_finite": true,
    "telemetry_contiguous": true,
    "contact_force_available": true,
    "contact_torque_available": true,
    "no_sensor_errors": true,
    "complete_assembly_sequence": false,
    "seating": true,
    "pin_engagement": true,
    "sampled_force_limits": true,
    "sampled_torque_limit": true,
    "sustained_pull": true,
    "observed_motion": true,
    "arms_released": true
  }
}
Recorded run: seating-v5
The run is ending in the Verify seating phase. The independent verifier is reporting telemetry_finite, telemetry_contiguous, contact_force_available, contact_torque_available, complete_assembly_sequence, pin_engagement, sampled_force_limits, sampled_torque_limit, sustained_pull, observed_motion, arms_released.
This recording is showing the actual bimanual YAM scene. It is retaining the full recorded sequence. Playback is using the recorded 20 Hz control rate.
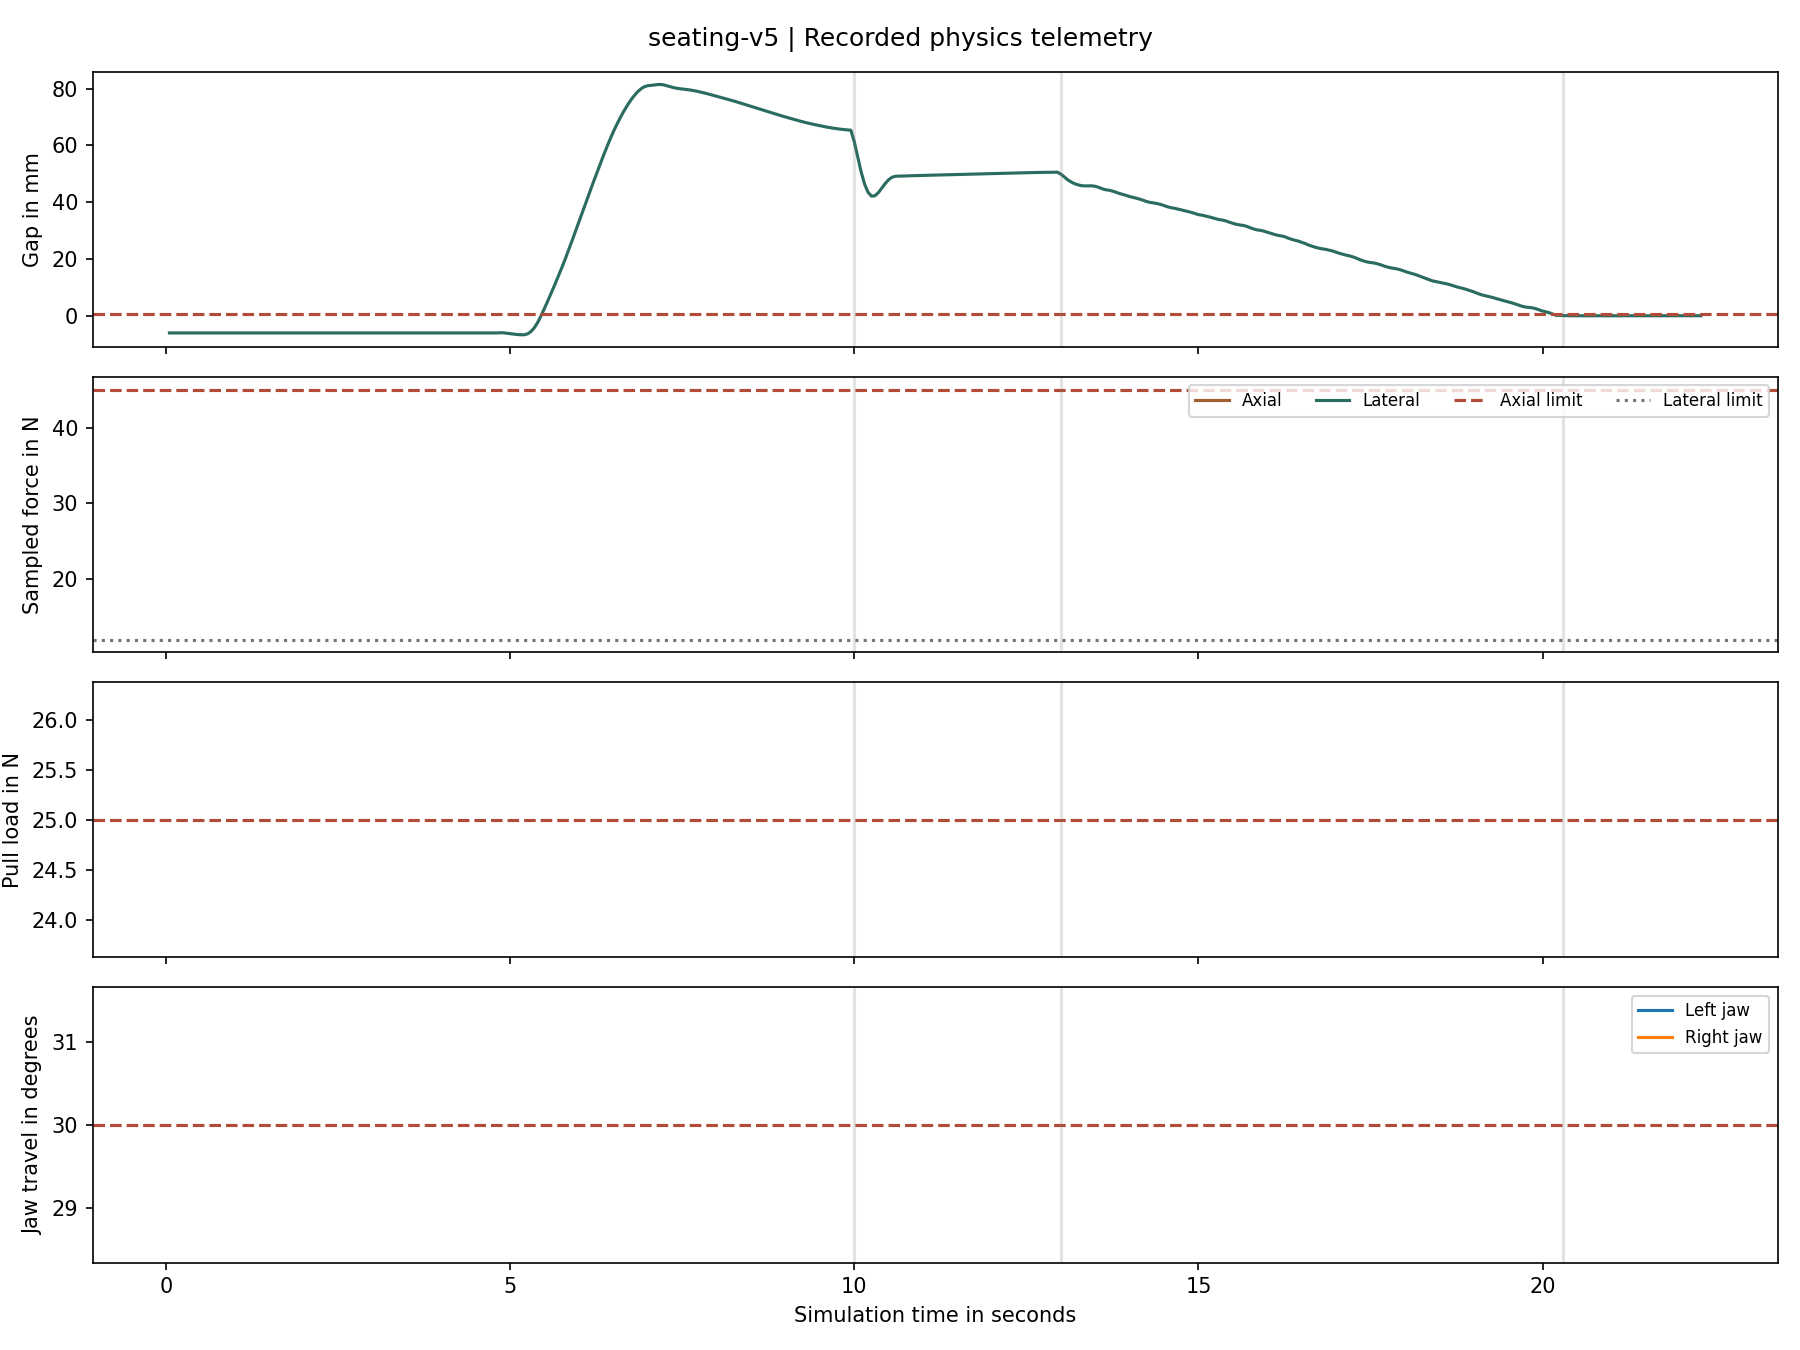
Controller events and independent acceptance checks
{
  "events": [
    {
      "time_s": 10.000000000000007,
      "phase": "align",
      "reason": "Transport completed. Using measured relative pose."
    },
    {
      "time_s": 13.00000000000005,
      "phase": "insert",
      "reason": "Measured alignment is within 1 mm and 1 degree"
    },
    {
      "time_s": 20.300000000000153,
      "phase": "verify_seating",
      "reason": "Measured seating geometry is within tolerance"
    }
  ],
  "checks": {
    "telemetry_finite": false,
    "telemetry_contiguous": false,
    "contact_force_available": false,
    "contact_torque_available": false,
    "no_sensor_errors": true,
    "complete_assembly_sequence": false,
    "seating": true,
    "pin_engagement": false,
    "sampled_force_limits": false,
    "sampled_torque_limit": false,
    "sustained_pull": false,
    "observed_motion": false,
    "arms_released": false
  }
}
A recorded safety failure is driving the final correction
Randomized trial assembly-seed205 is recording 47.44 N of pull load against the 45 N axial limit. The older controller is entering a generic retraction path. The trial is being retained as a failed attempt and is being terminated after the violation.
The hardened controller is stopping on missing wrench data and on axial force or lateral force or torque violations. The software replay is feeding the exact recorded failure observation into that guard. It is requesting a stop while preserving measured joint targets. This is a software decision replay and is not claiming a new physics episode or a hardware emergency stop test.
{
  "phase": "safe_stop",
  "request_stop": true,
  "reason": "Axial interface force exceeds 45 N"
}Repeated seeds are exposing sensitivity
The MVTec experiment is covering the metal nut category only. It is not reporting an aggregate over the entire MVTec AD benchmark. The repeated runs are sharing the official image test sets while varying normal fitting and calibration membership. Their scores are therefore correlated. The table is showing observed ranges rather than treating seeds as independent production trials.
| Dataset | Runs | AUROC range | Recall range | Missed anomaly range |
|---|---|---|---|---|
| ksdd2 | 5 | 0.926 to 0.936 | 0.664 to 0.700 | 33 to 37 |
| mvtec-metal-nut | 5 | 0.973 to 0.977 | 0.903 to 0.935 | 6 to 9 |
| voraus-ad | 5 | 0.980 to 0.991 | 0.486 to 0.734 | 201 to 388 |